
5. Programming and Control
5.1Common Programming Commands
This section presents the usage methods for various commonly used programming command on the teach pendant. It covers the meaning of parameters, data types, value ranges, the context of instruction usage, usage recommendations, and important considerations.
5.1.1 Basic motion commands
Basic motion commands are fundamental commands used to control the robot's main body in performing basic trajectory movements. These trajectories encompass point, line, circle, circular arc, curve, spiral, arch, and interpolation motions. The set of commands include: MovJ, MovL, MovC, MovJRel, MovLRel, MovJSearch, MovLSearch, MovLOffset, MovLW, MovCW, MovH, MovArch, OnDistance, OnParameter, and more.
The following section provides a detailed overview of these commands:
MovJ - Joint motion command
It indicates that each joint of the robot performs point-to-point motion. The end trajectory of the robot is an irregular curve, and the IO command can be operated when the command operates to an end, as shown in figure below.
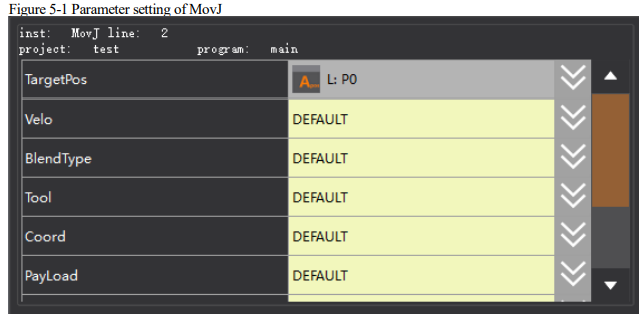
⚫ Target Position: The designated endpoint position for the command, , of which the type can be APOS.
Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can selected the system pre-defined one, or create it by yourself; the item per controls the MovJ command, which is the percentage of the global speed.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
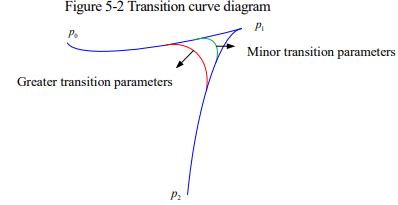
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself; when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO commands: Executing IO operation. The IO commands currently available are SetDo, SetAo, SetSimDo, SetSimAo, PulseOut, PulseSimOut, SetDO8421, SetSimDO8421, SetDIEdge, and SetSimDIEdge.
[Note]
⚫ The SPEED variables have the parameters detailed as below:
per: The percentage, which affects mainly the motion in the joint coordinates, e.g. MovJ, etc.
tcp: The linear speed of the end, which affects mainly the motion in Cartesian coordinates, e.g. MovL, MovC, etc.
ori: The end posture speed, which affects mainly the motion in the Cartesian coordinates, e.g. MovL, MovC, etc.
exj_l: The external axis linear speed (invalid if no external axis)
exj_r: The rotating speed of external axis (invalid if no external axis)
⚫ The ZONE variables have the following parameters:
per: The percentage, of which the relative transition type is the turning area
dis: The absolute distance, of which the absolute transition type is turning area
vConst: Low-speed constant transition enable state, indicating that the transition speed is constant if it is 1, and track the change of the transition parameters if it is 0.
Example 1:
MovJ (P1, V50, ”RELATIVE”, C100)
The robot travels to point P1 at the speed of V50, and there is a transition with the next path. The
transition value is 100%.
Example 2:
MovJ (P2, V50, ”RELATIVE”, C0)Do SetDo(DO0,0)
The robot travels to point P2 at the speed of V50 without transition. Set DO0 to 0 when it travels to
point P2.
MovL- Linear motion command
MovL is the linear motion command, through which the TCP point of the robot can be moved linearly to the target position at the set speed. If the start and end postures of the motion differ, then during operation the posture will synchronously rotate to the ending posture along with the position. It is the same as MovJ. An additional IO operation can be performed when the command is executed. The parameter setting of MovL is similar to MovJ, but its target speed is an absolute speed value, rather than the percentage.
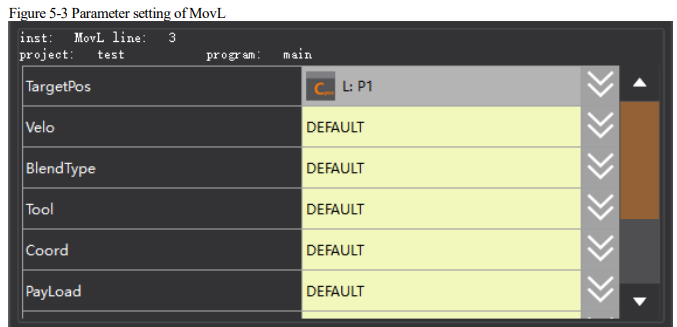
⚫ Target Position: The commanded ending position, which can be of type APOS or CPOS.
Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
When selecting a variable of type CPOS, the target position is influenced by the configuration of the confdata.
However, if the mode value is set to -1, the endpoint position is not constrained by the confdata values. Instead, the robot will arrive at the target position using the most optimal solution available.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can selected the system pre-defined one, or create it by yourself; the item per controls the MovJ command, which is the percentage of the global speed.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO commands: Executing IO operation. The IO commands currently available are SetDo, SetAo, SetSimDo, SetSimAo, PulseOut, PulseSimOut, SetDO8421, SetSimDO8421, SetDIEdge, and SetSimDIEdge.
MovC - Arc motion command
Arc command refers to the circular motion made by the robot’s TCP point from the starting position to the target by passing through the middle position. If the start and end postures of the motion are different, the posture will rotate to the end posture synchronously with the position, but it may not necessarily pass through the middle position.
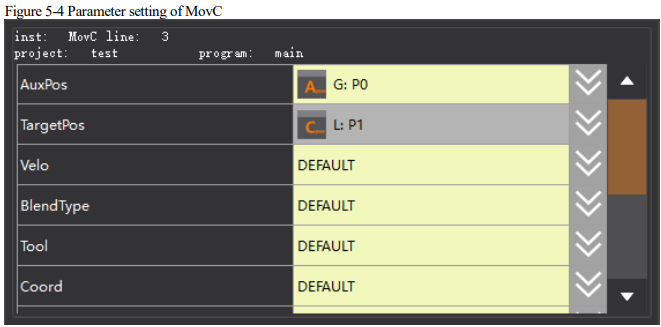
⚫ Middle position: The position of the auxiliary point in the middle of the arc.
⚫ Target position: The final position of the arc.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
When it is set to external tool coordinates, the motion of robot is relative to the external tool coordinates, and the target speed of command is relative to the external tool coordinates. External TCP functions support only the transition between the reference coordinate system is the same external tool coordinates.
When setting it to the positioner coordinates, the robot’s motion is relative to the positioner coordinates, and the target speed of command is relative to the positioner flange. The POSITIONER function supports only the transition between the same positioner
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Rate type: Whether the robot's commanded speed is affected by the global multiplier of the teach pendant when executing this path.
DEFAULT: Same as GOVRON, i.e. the commanded speed is affected by the global multiplier of the teach pendant.
GOVRON: The commanded speed is affected by the global multiplier of the teach pendant.
GOVROFF: The commanded speed is not affected by the global multiplier of the teach pendant.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO Command: Executing IO operation.
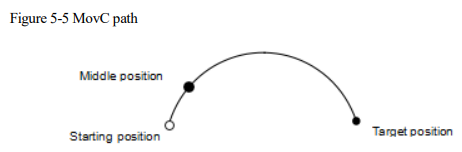
This command must satisfy following requirements: When the end of the robot TCP performs a full circular motion, two MovC commands must be executed or the MovCircle command must be used.
MovCircle - Circular motion command
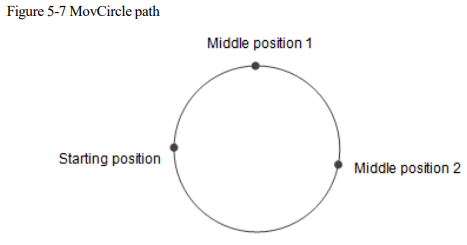
MovCircle command means that the robot TCP point moves in a full circle from the start position to the start position through the auxiliary point 1 and auxiliary point 2 positions, with the pose remaining constant during the movement.
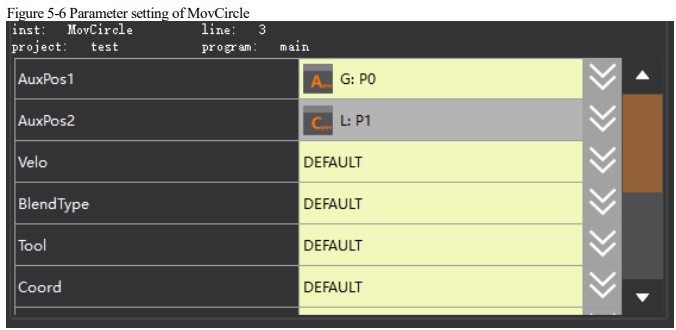
⚫ Middle Position 1: The position 1 of the middle auxiliary point of the full circle, which is used to determine the size and movement direction of the arc. The pose of this point will not affect the final trajectory.
⚫ Middle Position 2: The position 2 of the middle auxiliary point of the full circle, which is used to determine the size and movement direction of the arc. The pose of this point will not affect the final trajectory.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
When it is set to external tool coordinates, the motion of robot is relative to the external tool coordinates, and the target speed of command is relative to the external tool coordinates. External TCP functions support only the transition between the reference coordinate system is the same external tool coordinates.
When setting it to the positioner coordinates, the robot’s motion is relative to the positioner coordinates, and the target speed of command is relative to the positioner flange. The POSITIONER function supports only the transition between the same positioner.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Rate type: Whether the robot's commanded speed is affected by the global multiplier of the teach pendant when executing this path.
DEFAULT: Same as GOVRON, i.e. the commanded speed is affected by the global multiplier of the teach pendant.
GOVRON: The commanded speed is affected by the global multiplier of the teach pendant.
GOVROFF: The commanded speed is not affected by the global multiplier of the teach pendant.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO Command: Executing IO operation.
MovJRel - Joint space position offset command
The MovJ interpolation relative offset command. It works by taking the current robot position or the target position of the previous motion command as the starting point, and then perform the robot’s relative motion operation.
Unlike the commands such as MovJ, the target relative position value used by this command cannot be obtained through teaching. User needs to create a new joint relative position variable in the list of variables before, and then select it from the drop-down list.
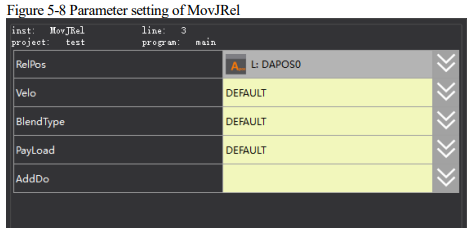
⚫ Target Relative Position: The position increment the robot will move when executing this command.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ AddDo: Robot will perform IO operation after executing this command.
MovLRel - Cartesian space position offset command
The MovJ interpolation relative offset command. It works by taking the current robot position or the target position of the previous motion command as the starting point, and then performs an offset motion relative to the coordinate system or tool.
Unlike the commands such as MovL, the target relative position value used by this command cannot be obtained through teaching. User needs to create a new joint relative position variable in the list of variables before, and then select it from the drop-down list.
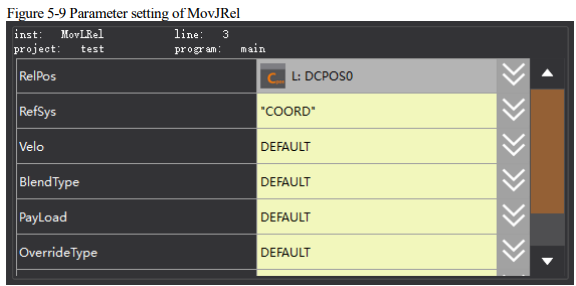
⚫ Target Relative Position: The position increment the robot will move when executing this command.
⚫ Reference Coordinates: coordinate system offset or tool offset selection;
Coord: offset relative to the current user coordinates;
Tool: offset relative to the tool coordinates, i.e. translation or rotation with reference to Tx, Ty, Tz.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Rate type: Whether the robot’s commanded speed is affected by the global multiplier.
DEFAULT: Same as GOVRON, i.e. the commanded speed is affected by the global multiplier of the teach pendant.
GOVRON: The commanded speed is affected by the global multiplier.
GOVROFF: The commanded speed is not affected by the global multiplier.
⚫ Rate type: Whether the robot's commanded speed is affected by the global multiplier of the teach pendant when executing this path.
DEFAULT: Same as GOVRON, i.e. the commanded speed is affected by the global multiplier of the teach pendant.
GOVRON: The commanded speed is affected by the global multiplier of the teach pendant.
GOVROFF: The commanded speed is not affected by the global multiplier of the teach pendant.
⚫ AddDo: Robot will perform IO operation after executing this command.
MovJSearch - Joint searching command
A search command, which performs IO detection or torque detection when executing the MovJ
command.
When the search condition is IO detection and the value of index IO reaches the triggered value, stop running the command and continue to execute the next command.
When the search condition is torque detection and the value of the index axis torque reaches the triggered value, stop running the command and continue to execute the next command.
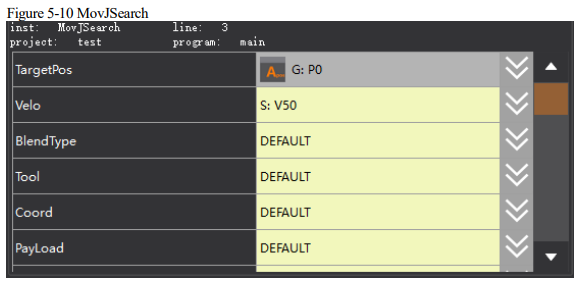
⚫ Target Position, Target Speed, Tool Parameters, Coordinate System Parameters, Workpiece Load, and AddDo: These parameters carry the same meanings as in the MovJ command.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
Note: In the current version, MovJSearch does not support transitional planning with the subsequent motion command.
⚫ Type of detection:
DITrig: Physical digital IO input detection.
AITrig: Physical analogue IO input detection.
SIMDITrig: Virtual digital IO input detection.
SIMAITrig: Virtual analogue IO input detection.
TorqTrig: Torque detection.
⚫ Trigger index:
−For InputTrig, this parameter indicates the IO port number to be detected.
−For TorqTirg, this parameter indicates the axis number to be detected.
⚫ Trigger value:
−For InputTrig, the threshold for IO detection.
−For TorqTirg the threshold for torque detection, which is expressed in thousandths of the rated torque.
⚫ STOP type: The way to stop when a signal is detected.
DEFAULT: Stops immediately;
HARDSTOP: Stops immediately;
SOFTSTOP: Stop at reduced speed.
⚫ Decel Factor: The value is valid when "SOFTSTOP" is selected as "Stop Type". It is used to adjust the Decel/Accel factor, the greater the value, the faster the deceleration.
⚫ Return Value: A return value of 1 indicates successful signal detection during searching, while a return value of 0 signifies the absence of signal detection.
[Note]
In the current version, MovJSearch does not support transitional planning with the subsequent motion command.
MovLSearch - Linear search command
The Search Command refers to IO detection or torque detection while executing this MovL command, which is similar to MovJSearch.
[Note]
In the current version, MovLSearch does not support transitional planning with the subsequent motion command.
MovLOffset - Linear offset motion command
MovL Interpolation Relative Offset command. This command specifies a reference position as the starting position for an offset movement relative to the coordinates or tool.
It differs from MovLRel only in that it specifies the starting point of the offset movement, not necessarily the current position or the endpoint of the previous command, and all other functions are the same.
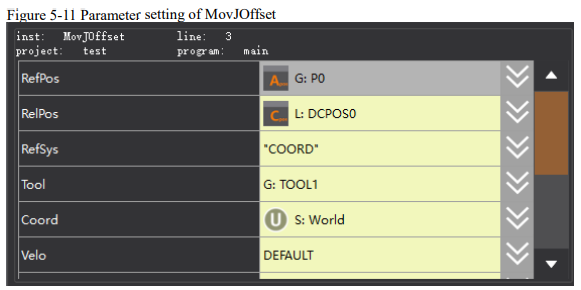
The new command parameters compared to MovLRel are as follows:
⚫ Reference position: The starting point of the offset movement (APos or CPos).
⚫ Tool parameters: Information on the tool to which the reference position belongs.
⚫ Coordinate system parameters: Information on the coordinate system to which the reference position belongs.
MovLW - Linear weave command
Weave command, which performs the arc swinging motion in the forward direction based on the set swing frequency and amplitude.
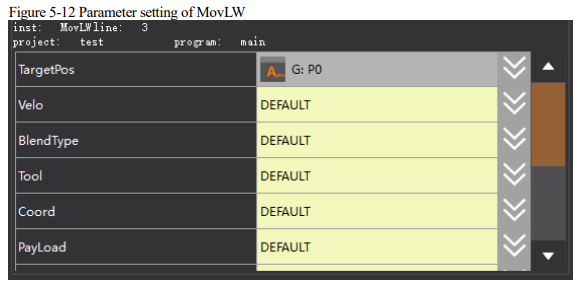
⚫ Target position: The final position of the command (the position point of APOS or CPOS).
Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
When setting it to the positioner coordinates, the robot’s motion is relative to the positioner coordinates, and the target speed of command is relative to the positioner flange. The POSITIONER function supports only the transition between the same positioner.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Swinging arc variable: The weaving parameter.
The swing frequency, amplitude, stop time, rotation, etc. can be set.
⚫ Rate type: Whether the robot's commanded speed is affected by the global multiplier of the teach pendant when executing this path.
DEFAULT: Same as GOVRON, i.e. the commanded speed is affected by the global multiplier of the teach pendant.
GOVRON: The commanded speed is affected by the global multiplier of the teach pendant.
GOVROFF: The commanded speed is not affected by the global multiplier of the teach pendant.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO Command: Executing IO operation.
[Note]
The WEAVE variable has the following parameters:
⚫ Type: Weave type of robot. It is a sine Weave when the value is 1, and is a triangular Weave when the value is 2.
⚫ Freq: The frequency when the robot weaves, in Hz.
⚫ Amp_L: The left amplitude when the robot weaves, in mm.
⚫ Amp_R: The right amplitude when the robot weaves, in mm.
⚫ StopTime_L: The time when robot stops at wave peak. It refers to the time in ms at which the weaving stops when it reaches the left amplitude.
⚫ StopTime_C: The time when robot stops at the middle. It refers to the time in ms at which the weaving stops when it reaches the middle position.
⚫ StopTime_R: The time when robot stops at wave trough. It refers to the time in ms at which the weaving stops when it reaches the right amplitude.
⚫ RotAngle_X: The rotating angle of the weaving reference plane around the weaving direction. This parameter is used to determine the final weaving plane, in deg.
⚫ RotAngle_Z: The rotating angle around the normal vector of the weaving plane, which determines the shape of the sine weave, in deg.
[Caution]
⚫ The normal vector of the plane determined by the motion path and the Tz direction of tool coordinates, and the plane formed by the motion path is the reference plane for weaving.
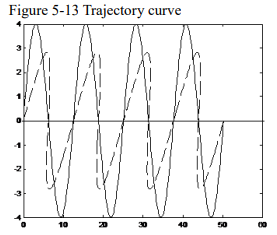
⚫ The function of RotAngle_Z is in the figure below: it is indicated by a solid line if RotAngle_Z=0 is a solid line, and a dotted line if it is not 0.
MovCW - Arc weave motion command
Similar to MovLW.
MovCircleW - Circular weave motion command
Similar to MovLW.
MovH - Helical motion command
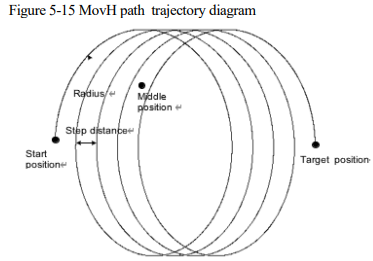
The helical motion command, through which the TCP point of the robot can perform Helical motion to the target position. If the start and end postures of the motion are different, the posture will rotate to the ending posture synchronously with the position.
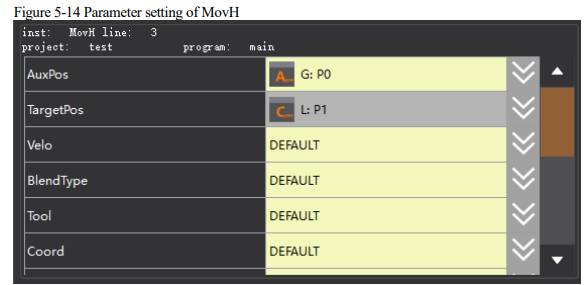
⚫ Middle position: The position of the helical middle auxiliary point. The auxiliary point is used to determine the helical plane and the helical direction (precession in clockwise and counterclockwise). The helical movement may not pass through the auxiliary point
⚫ Target position: Helical end position
⚫ Target speed: the speed at which the command position is run, where the parameter tcp is valid for the linear speed of the command and ori is valid for the posture speed. The maximum path linear speed of the helical line is 0.25 times the maximum system speed
⚫ Transition type: Transition not supported
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
When setting it to the positioner coordinates, the robot’s motion is relative to the positioner coordinates, and the target speed of command is relative to the positioner flange. The POSITIONER function supports only the transition between the same positioner.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the workpiece load of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Radius: Helical line radius, in mm
⚫ Stepping distance: The stepping distance when the helical line makes one revolution, in mm
⚫ AddDo: The robot can perform IO operations after executing this command
[Note]
For Helical motion, the transition and WaitFinish are not supported.
Example:
MovL (P1, V50, ”RELATIVE”, C50)
MovH (P2,P3, V100, ”FINE”,nullTool,World,PayLoad0,10,5)
The robot will move to point P1 at the speed of V50, and then when executing the Helical command
by taking point P1 as the starting point of the motion, and determining the Helical motion plane
using the three points P1, P2, and P3, while determining the precession direction using point P2.
Then, perform the precession to the endpoint P3 at a helical radius of 10mm and the step distance of
5mm. The entire helical motion is finished by this moment.
MovArch - Arch-shaped motion command
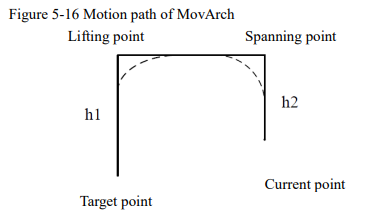
MovArch is an arch-shaped motion command, through which the TCP point of the robot will be elevated to a certain height from the current point or the end point of the previous path at a set speed, then move linearly to the point of the same height of the target position, and descend to such height to reach the target point. Same as the normal motion commands, additional IO operation can be performed when the command is executed. The target speed of the command denoted as the
percentage.
The figure below illustrates the full motion path. The robot raises the height h1 from the current point to reach the lifting point, then pans to the span point, and finally lowers to the target point with a height of h2. The full motion path becomes a “door-shaped”. If the turning parameters are required, it will turn according to the dotted line shown in the figure. For the Scara model, only the joint 3 move in the lifting and lowering process, and only the joint 1, 2 and 4 move in the translation process. The entire motion process is a point-to-point joint motion.
[Note]
This command is only for scara model currently.
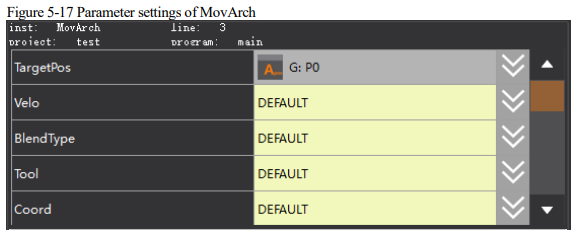
⚫ Target position: The final position of the command (the position point of APOS or CPOS).
Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
⚫ Target speed: The running speed of the command (see MovJ notes for details).
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
⚫ Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
When it is set to TOOL variable, you can selected the system pre-defined one, or create it by yourself. When using a coordinate system different from the current tool parameters, the system will switch the tool parameters to the set ones. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
When setting it to “DEFAULT”, the tool coordinate system set last time will be continuously used.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
⚫ Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫ Lifting height: The height that the robot needs to elevate when performing arching motion.
⚫ Rotating angle value: The value (variable) that the robot needs to rotate when performing arching motion.
⚫ AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO Command: Executing IO operation.
OnDistance - Distance trigger command
The distance trigger command. The controller can trigger some operations when moving a certain distance from the starting point or to the end point by not interrupting the transition, e.g. assigning values, setting IO and so on.
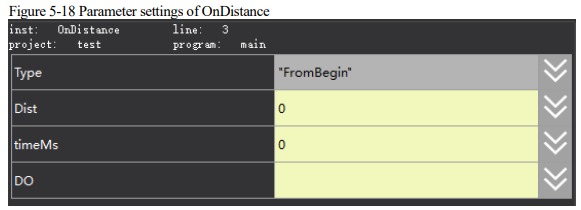
When the trigger type is set to judge from the starting point, the controller will enter the trigger waiting after the robot moves to the set distance, and after delaying the trigger time, it will start to perform the related trigger operations.
When the trigger type is set to judge from the endpoint, the controller will enter the trigger waiting after the robot moves to the set distance, and after delaying the trigger time, it will start to perform the related trigger operations.
⚫ Trigger type: Specify whether the current trigger is made at a certain distance from the start point or at a distance to the endpoint.
⚫ Trigger distance: The distance parameter for the trigger.
⚫ Trigger time: The time delayed for trigger after the trigger condition is met.
It means to trigger earlier when being set to negative number.
⚫ Trigger operation: The robot needs to perform the trigger operations after the trigger condition is met.
Example 1: The Do operation is executed at a distance of 200ms from the starting point of the path from P1 to P2, with a delay of 100ms.

Example 2: The Do operation is executed at a distance of 200ms from the end point of the path from P1 to P2, with a delay of 100ms.

[Caution]
⚫ When the distance trigger is met and the time trigger is still delayed, if the robot has completed the current path, the trigger will be executed later after the conditions for triggering is satisfied.
⚫ When the set trigger distance exceeds the path length, there will be two cases: when it is the start point trigger, the trigger judgment will be executed when the robot moves to the endpoint. When it is the endpoint trigger, the trigger judgment will be executed at the starting point. Trigger immediately when the relevant conditions are met.
⚫ There’re multiple trigger commands between the two paths. The respective detections will be made before the trigger execution. They works in a way not interfering with each other.
⚫ Execute the motion commands in Cartesian coordinates before executing OnDistance, otherwise OnDistance will not work, and the status bar will prompt that the operation is invalid, but the system operation will not be affected.
⚫ Only waiting commands can be inserted between OnDistance and the next motion command in Cartesian coordinate system, otherwise an error will be reported. The waiting commands can be Wait, Waitcondition WaitFinish and so on.
OnParameter - Distance percentage trigger command
The distance percentage trigger command. It is used to trigger some operations (e.g. assignment, setting IO and other shortcut operations) at a certain point of the linear path without interrupting the transition.
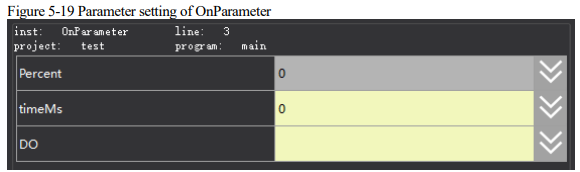
When the robot moves to the set path of trigger percentage, the controller enters the trigger waiting, and it starts to execute the related trigger operation after the trigger time is delayed.
⚫ Path percentage: The percentage of the path that needs to be triggered.
⚫ Trigger time: The time delayed for trigger after the trigger condition is met.
It means to trigger earlier when being set to negative number.
⚫ Trigger operation: The robot needs to perform the trigger operations after the trigger condition is met.
Example: When traveling to a distance of 60% from P1 to P2, the DO operation will be executed with a delay of 500ms.

5.1.2 Basic commands of arc welding
This section provides an introduction to fundamental arc welding commands. These commands are frequently used by users in arc welding scenarios and are designed specifically for the EWAS Arc
Welding Teach Pendant.
These commands include as follows:
ARC_ON,ARC_OFF,ARC_SET,ARC_WireFeed,ARC_WireFeedBack,ARC_WireSpeed,ARC_Ga sFeed,ARC_Line,ARC_Circ,SetWeaveCFG,ARC_StichL,ARC_SegmentL,ARC_StichC,ARC_LW ,ARC_CW,ARC_Fast,WaitArcOn,SetBlendParam,SetBurnTime,ARC_Count,SetCloosJOB.
These commands are described in detail below:
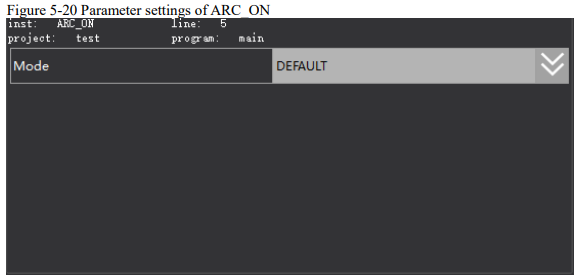
ARC_ON
Arc striking command, as shown in figure below.
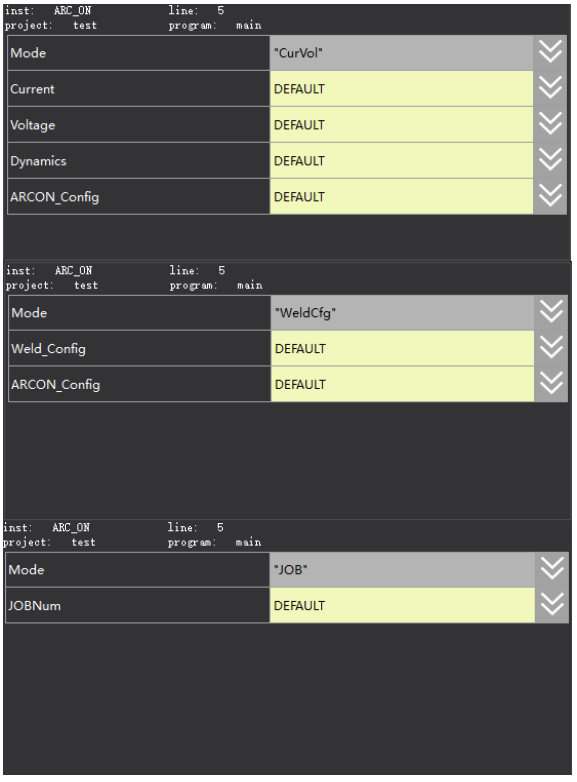
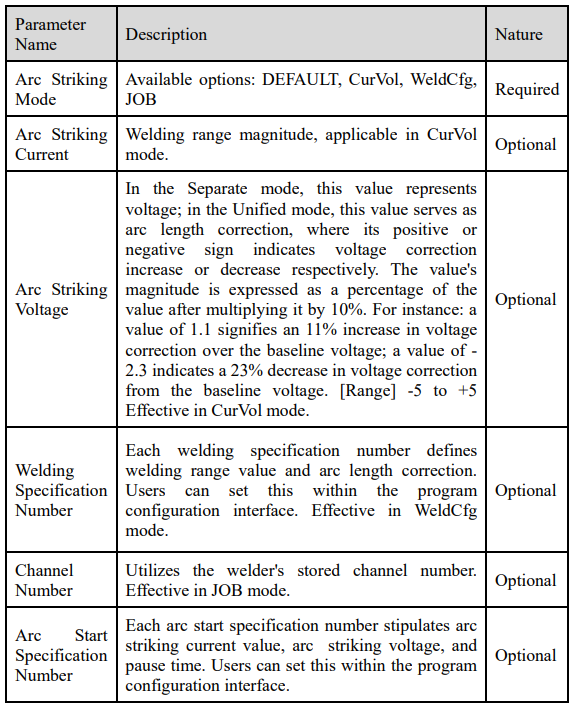
ARC_OFF
Arc stopping command, as shown in figure below
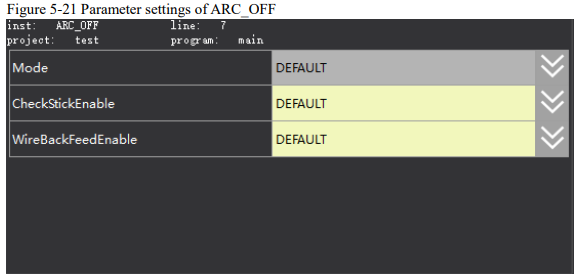
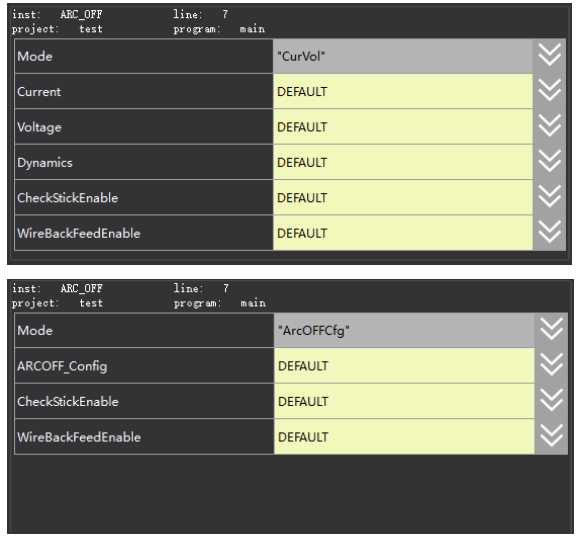
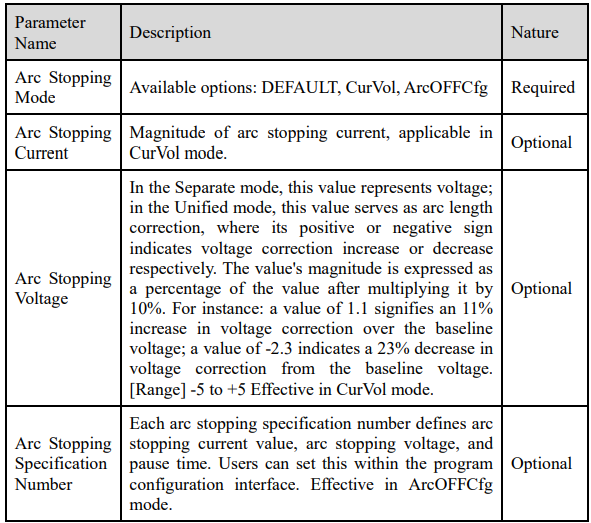
ARC_SET - Welding arc striking and arc stopping current and voltage settings
The command for setting welding arc striking and arc stopping current and voltage, as shown in figure below.
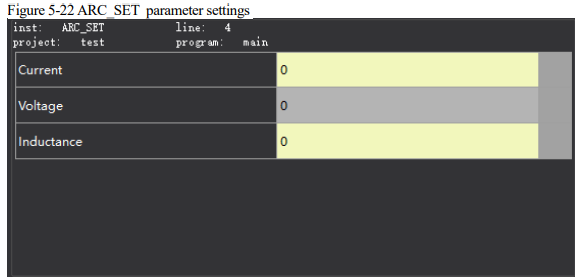
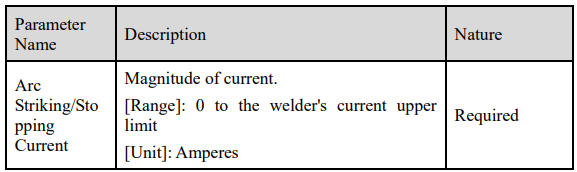
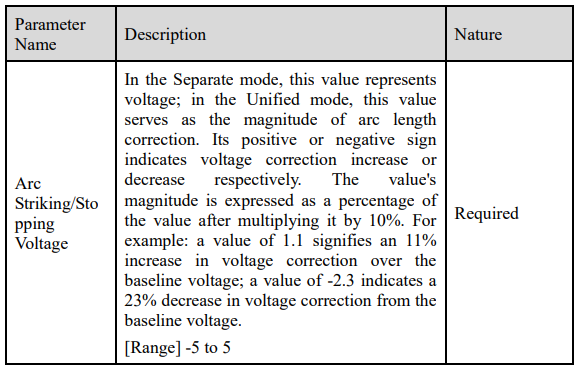
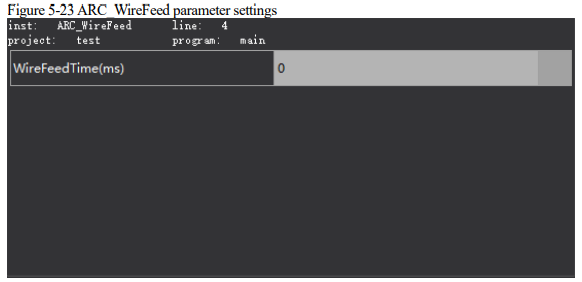
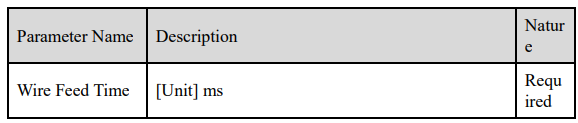
ARC_WireFeed
The wire feed command, as shown in figure below.
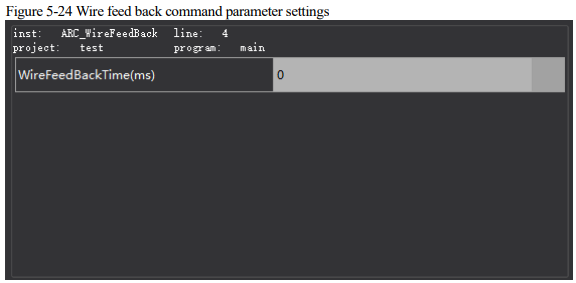
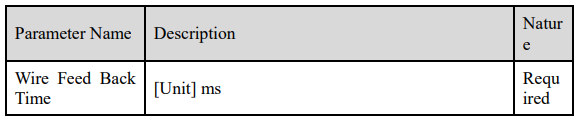
ARC_WireFeedBack
The wire feed back command, as shown in figure below
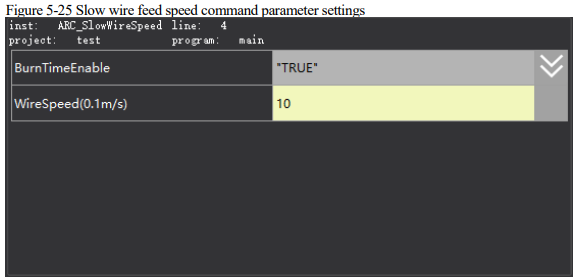
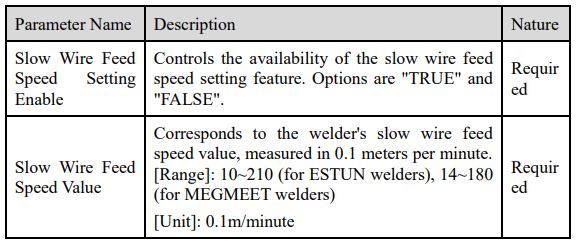
ARC_SlowWireSpeed
The slow wire feed command, as shown in figure below.
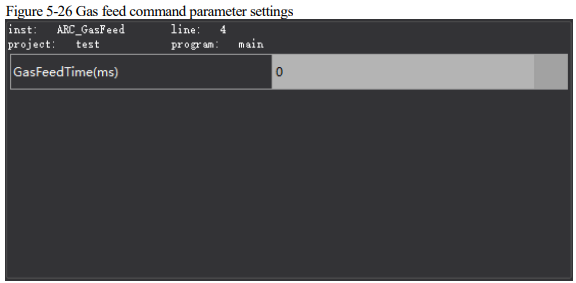
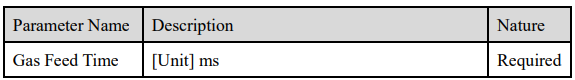
ARC_GasFeed
The gas feed command, as shown in figure below.
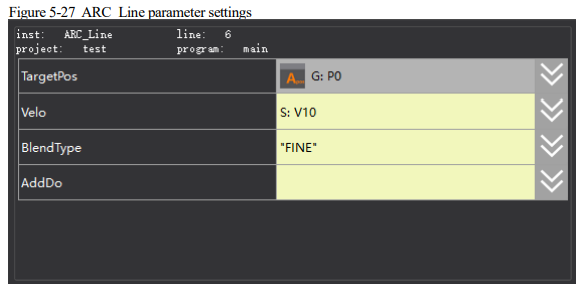
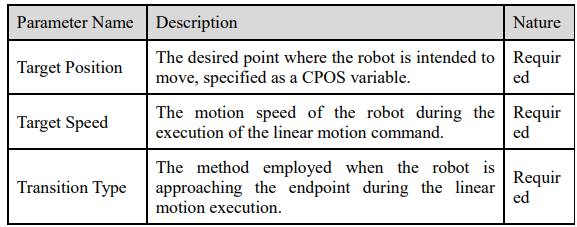
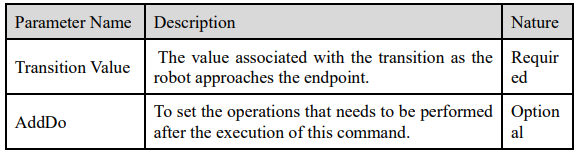
ARC_Line
The linear motion command, which enables the robot's Tool Center Point (TCP) end-effector to
move linearly to a target position at a constant speed. In the scenario where the TCP's orientation at
the starting point differs from that at the target point, the TCP's orientation will transition smoothly
from the starting orientation to the target orientation through continuous interpolation of
orientations during the linear motion from the starting position to the target position.
Unlike the MovL system command, the ARC_Line command specifies a target speed that remains
unaffected by the global speed percentage.
ARC_Circ
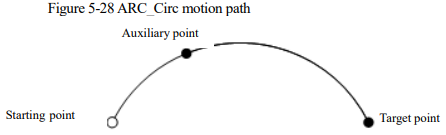
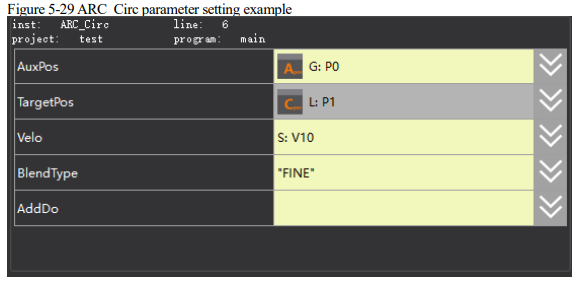
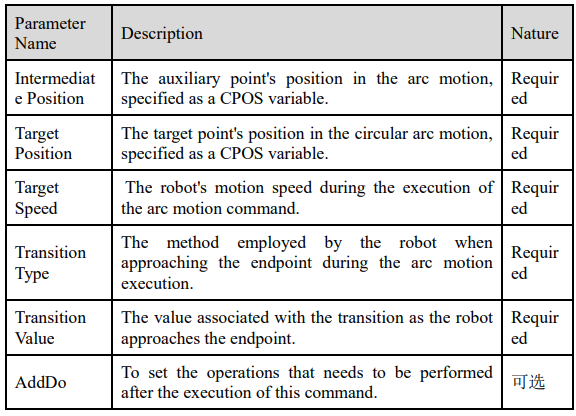
The circular motion command, which enables the robot's TCP end-effector to execute an arc motion, moving from the starting point through an auxiliary point to the target point, as shown in figure below.
The following rules must be observed when using this command:
⚫ For the robot's TCP end-effector to perform a complete circular motion, two arc motion commands must be executed.
⚫ In the arc motion command, the starting position, auxiliary position, and target position must be clearly distinguishable.
[Caution]
The starting position corresponds to either the target position of the previous motion command or the current TCP position of the robot.
Differing from the system's native arc command, MovC, the ARC_Circ command allows specifying the target velocity value independent of the global speed setting. Refer to the diagram below, where P0 represents the auxiliary point in the robot's arc motion, and P1 signifies the target point of the arc motion.
ARC_SegmentC
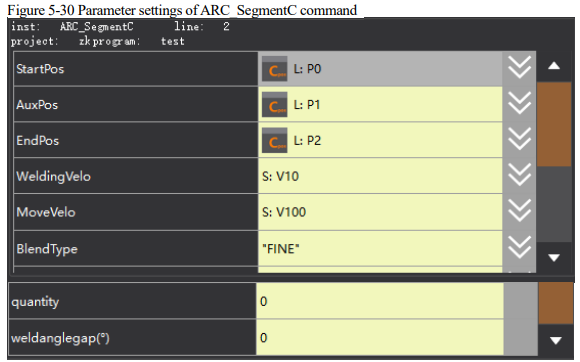
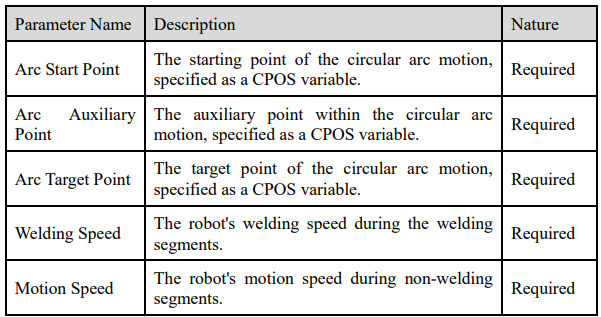
The command to invoke arc intermittent welding, as shown in figure below.
SetWeaveCFG
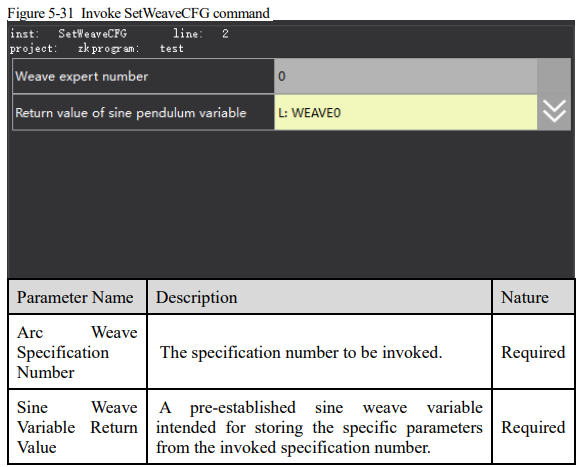
The command to invoke arc weave specification number, as shown in figure below.
ARC_StichL
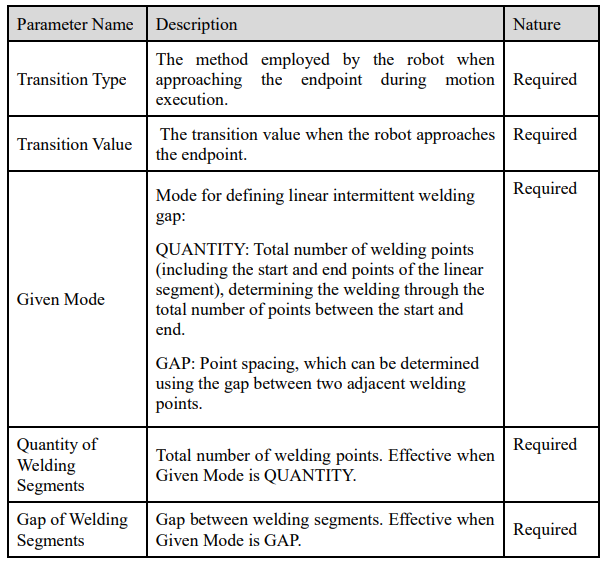
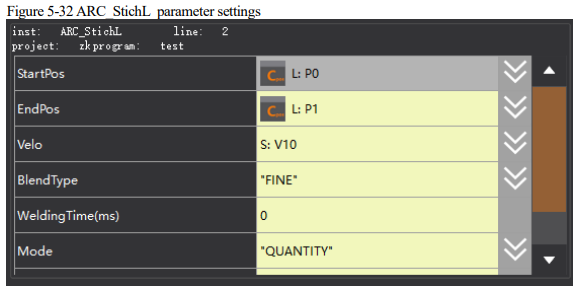
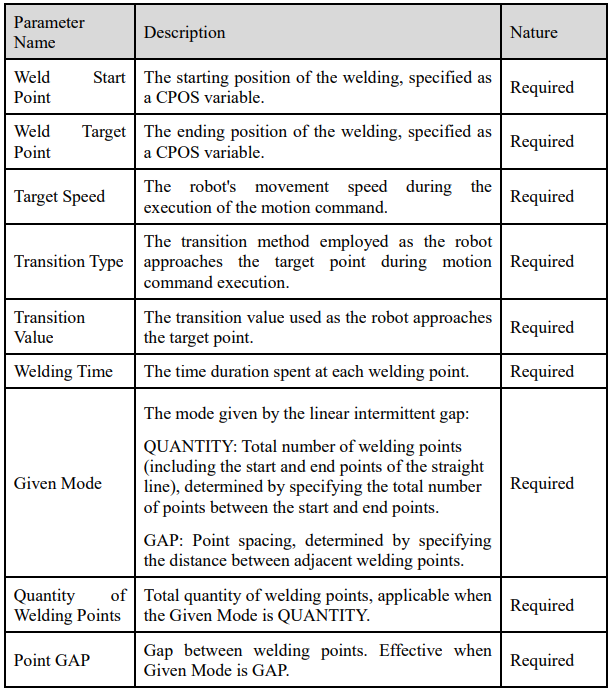
The linear intermittent spot welding command, which incorporates the arc striking and stopping commands, and does not need to add additional arc striking commands. To use this command, first teach the starting and ending points of the straight-line path. Next, select the welding mode between (QUANTITY and GAP, based on your requirements. Set the corresponding parameters depending on the chosen welding mode, including the number of welding points or the gap between points, along with the welding time. As shown in figure below.
ARC_SegmentL
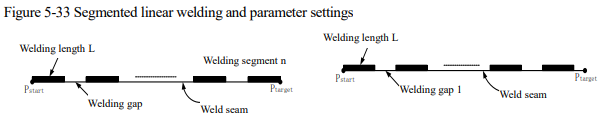
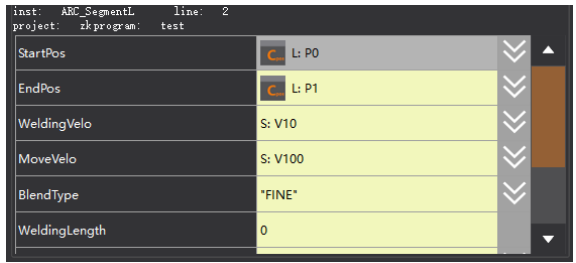
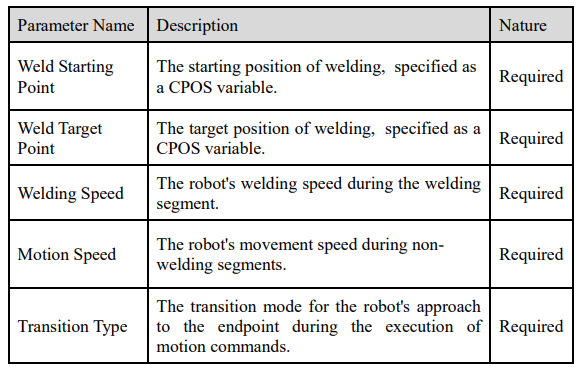
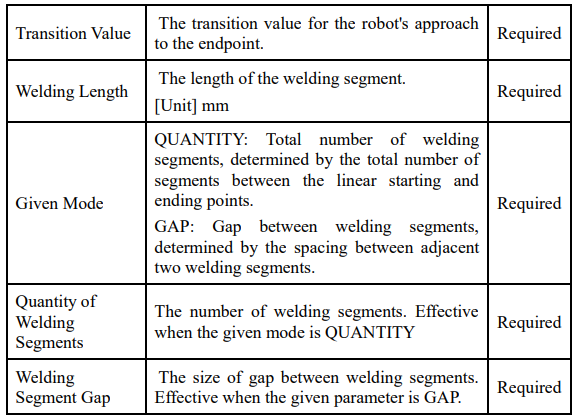
The linear segmented welding command. The proper use of this command requires the setup of
welding start and end points, the length of welding segments, the gap between welding segments, as well as the robotic welding and normal motion speed. The command is illustrated in Figure 3-14.
Segmented linear welding is applied in cases where there are gaps between welding segments along a straight bead welding path between the starting and target points. In practical applications, there are two variations: one involves specifying the number of welding segments, and the other involves specifying the welding gap.
When specifying the number of welding segments, the controller automatically calculates intermediate point information based on the linear length, welding length, and the desired number of welding segments. In this scenario, both ends of the line must be welded. When specifying the welding gap, the controller calculates intermediate point information based on the linear length, welding length, and welding gap, where the starting end of the straight path must be welded.
Whether the end is welded depends on the calculated results. This is illustrated in the figure below:
ARC_StichC
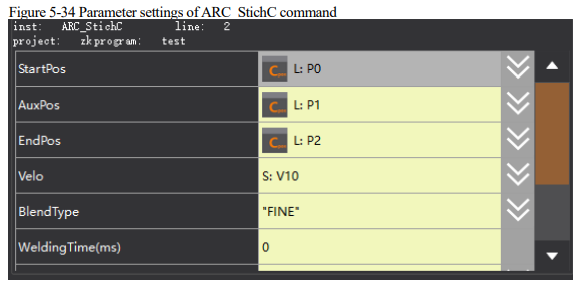
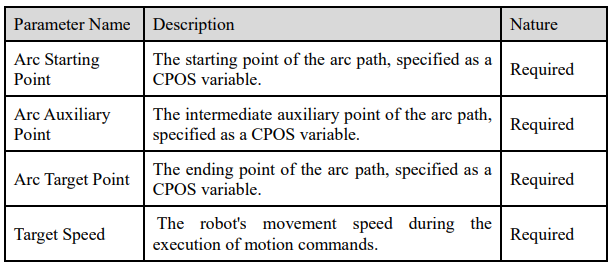
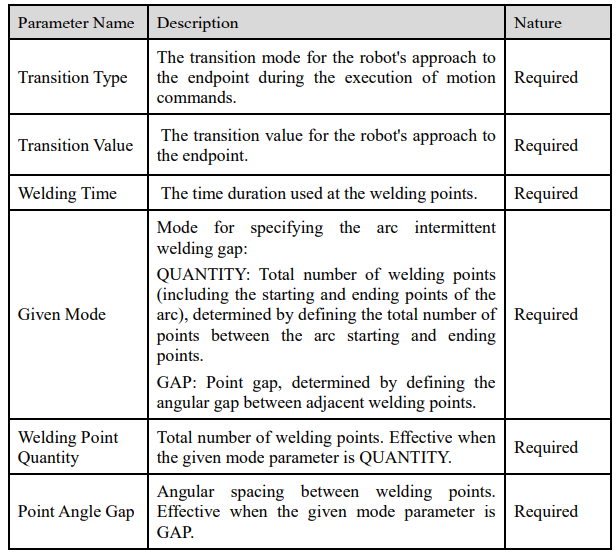
The arc intermittent spot welding command, which integrates the arc ON and arc OFF commands, and does not need to add additional striking and stopping commands. When using this command, first teach the transition point and endpoint of the arc; then, choose between the "QUANTITY" mode and the "Point GAP" mode. Set the corresponding parameters: the number of welding points or the angular spacing between welding points, along with the welding time. As shown in figure below.
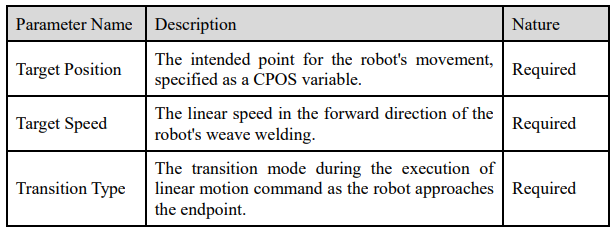
ARC_LW
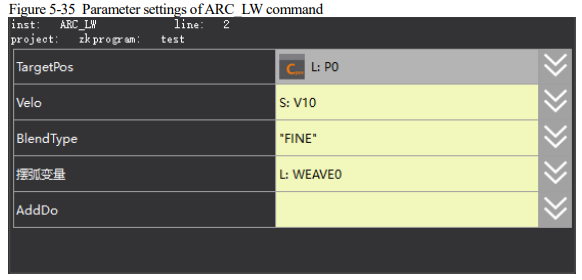
The linear welding weave command. Calling this command enables the welding path to follow a linear weave path.
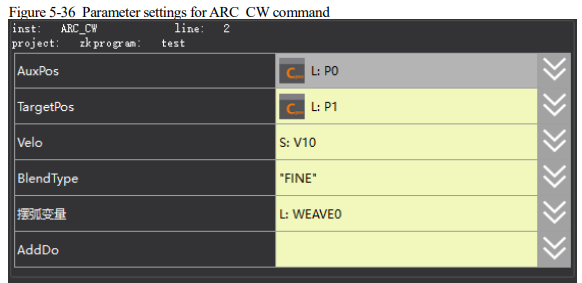
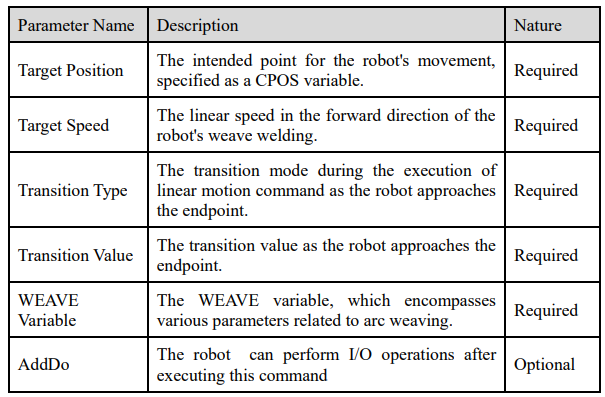
ARC_CW
The welding arc weave command. Calling this command enables the welding path to follow a arc weaving path, as shown in figure below.
ARC_Fast
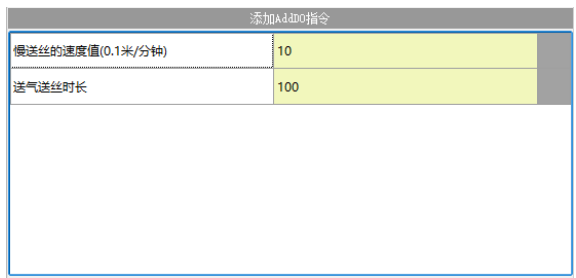
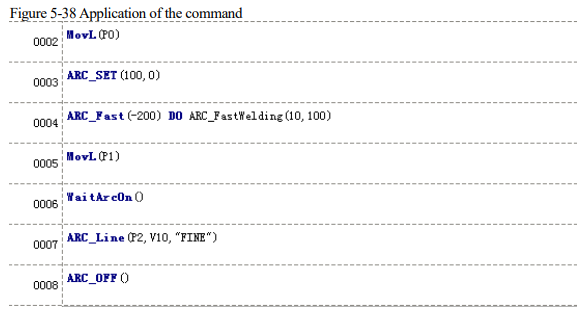
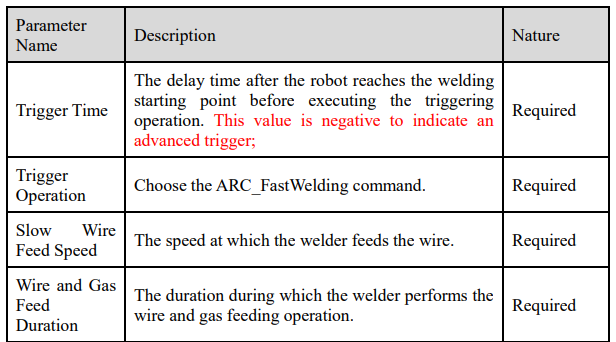
The fast arc striking command. When this command is invoked, the robot moves to the welding starting point within a certain time period. The welder initiates gas feeding, full wire feeding, and arc striking in advance, aimed at accelerating production takt. As shown in figure below.
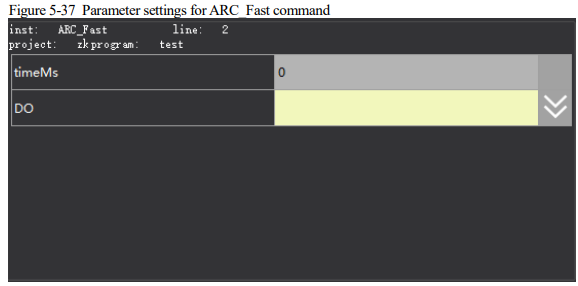
For instance, in the following program sequence, where P0 represents a safety point, P1 is the welding starting point, and P2 is the welding endpoint, the ARC_Fast command is inserted before the welding starting point P1. The robot moves to P1 200ms before reaching it, and the welder initiates gas feeding, full wire feeding, and arc striking.
WaitArcOn
The command used to wait for successful arc striking.
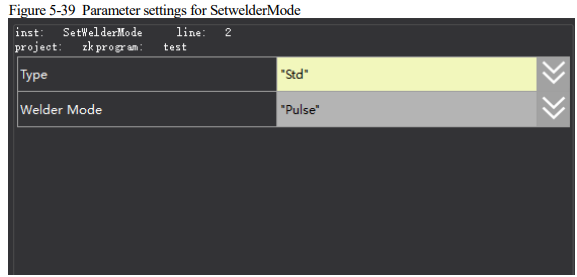
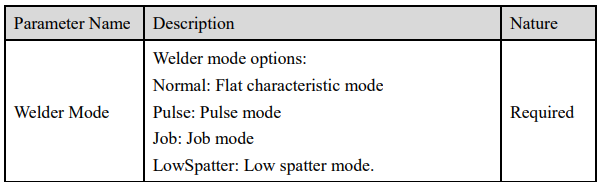
SetwelderMode
This command is used to set the welder working mode.
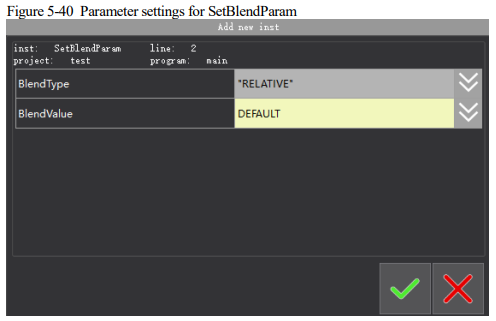
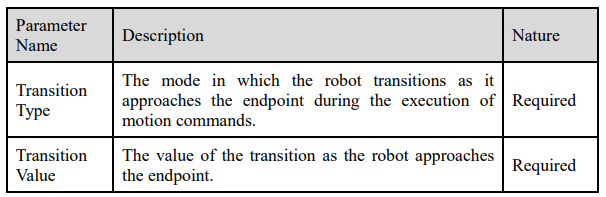
SetBlendParam
This command is used to set the transition parameters. The set transition parameters for this command take effect only when the default transition type for Arc_line and Arc_Circ commands is set to "FINE."
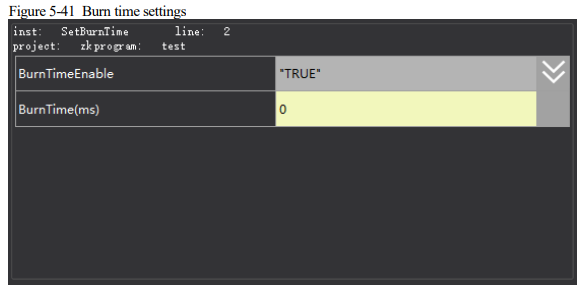
SetBurnTime
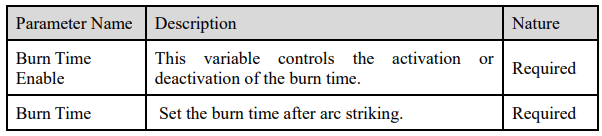
To set the burning parameters. This command allows enabling and setting the burn time.
ARC_Count
The command for welded workpiece counting. This command is used to tally completed welding workpiece information.
This command must be effective in automatic or remote mode, and with welding enabled.
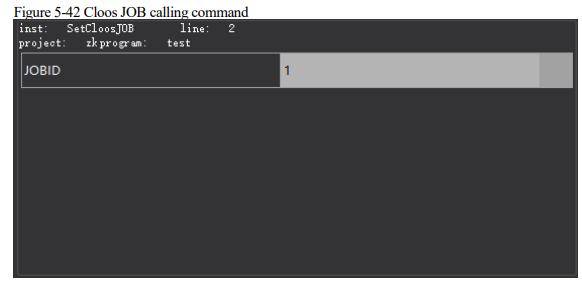
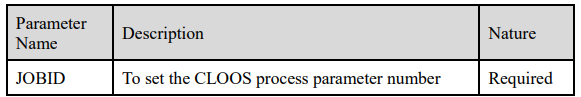
Cloos JOB Calling Command: SetCloosJOB
The command for calling a Cloos JOB.
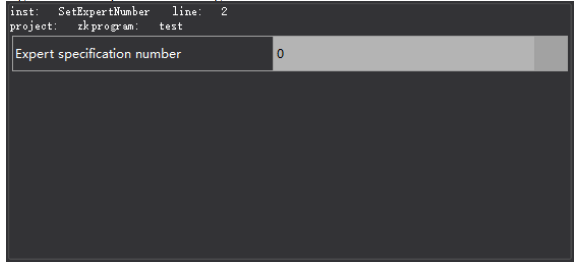
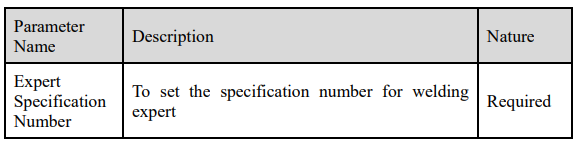
SetExpertNumber
5.1.3 Origin detection command
The origin detection functionality is a reserved feature and is not available in this version.
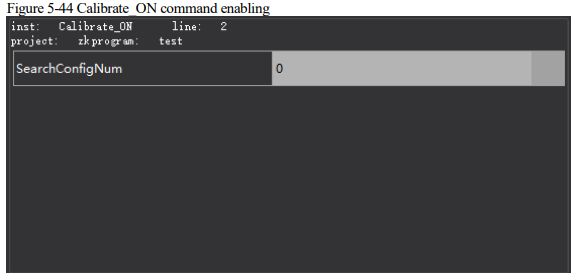
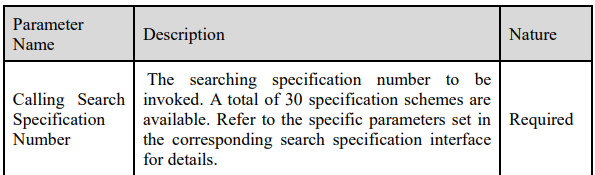
Calibrate_ON
The origin detection functionality calibration command, as shown in figure below.
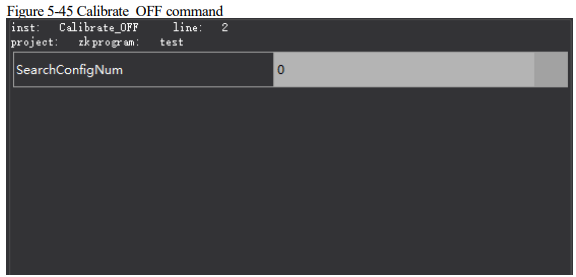
Calibrate_OFF
The origin detection functionality calibration OFF enable command, as shown in figure below.
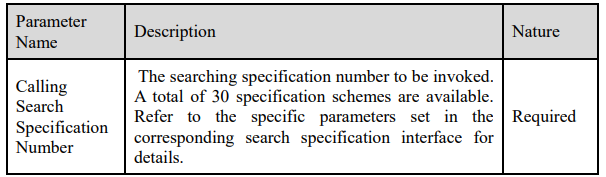
Search_ON
The origin detection searching enable command, as shown in figure below.
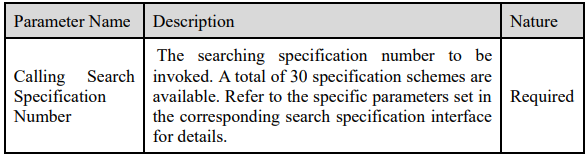
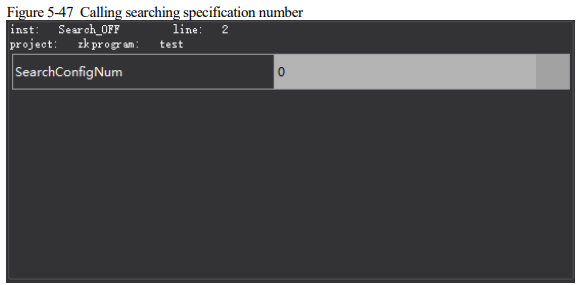
Search_OFF
The origin detection searching OFF enabling command, as shown in figure below
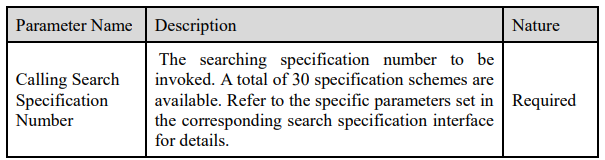
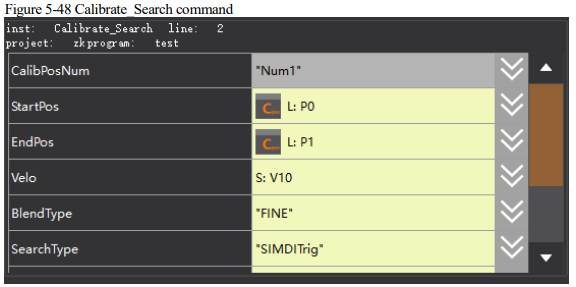
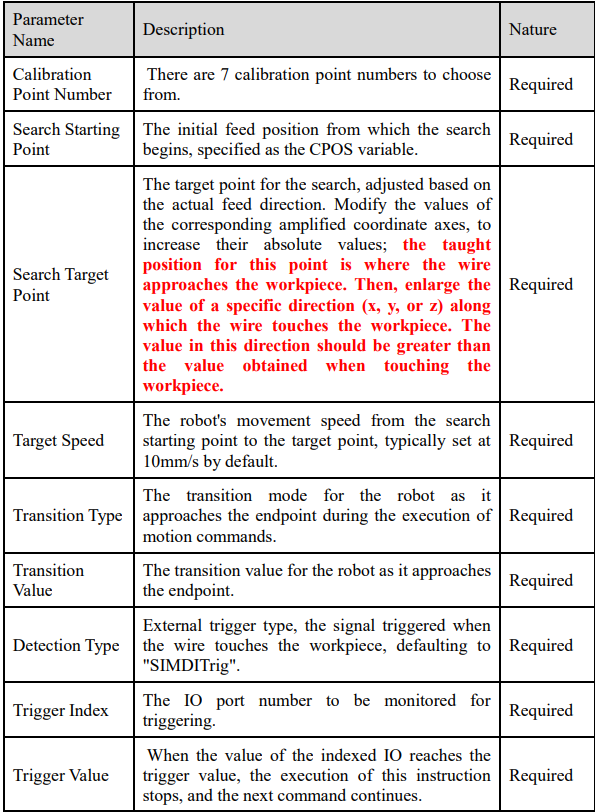
Calibrate_Search
The origin detection functionality calibration command, as shown in figure below.
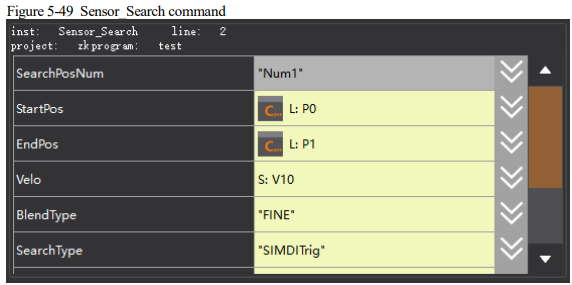
Sensor_Search
The origin detection search command, as shown in figure below.
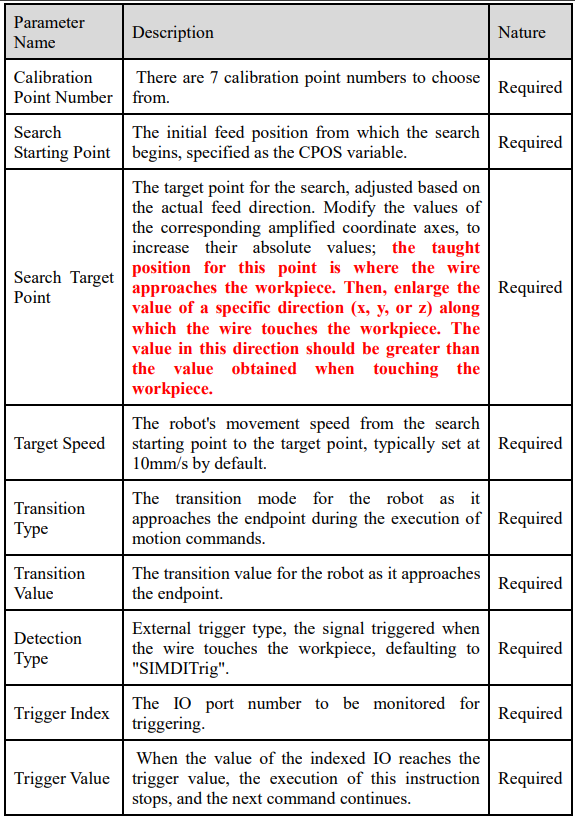
TouchOffset_ON
The command to enable coordinate system offset, as shown in figure below.
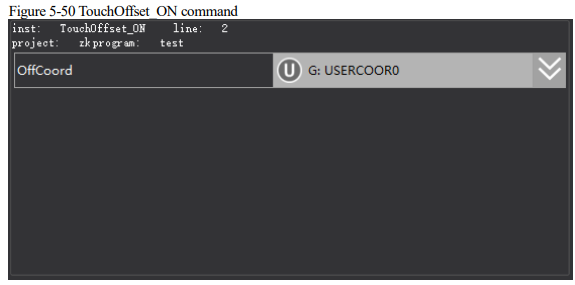
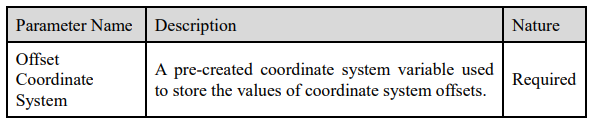
TouchOffset_OFF
The command to enable coordinate system offset OFF. This command has no parameters.
5.1.4 Line laser commands
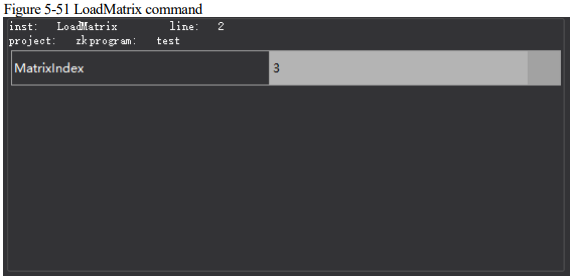
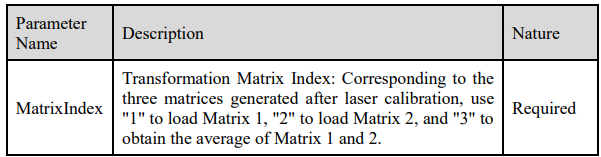
LoadMatrix
The command to load transformation matrix, as shown in figure below.
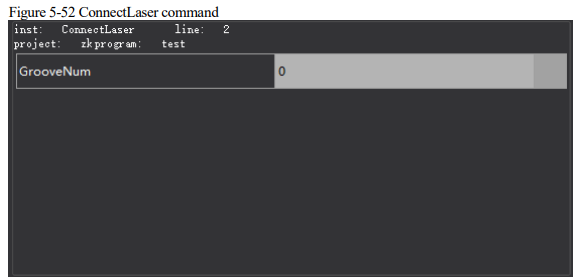
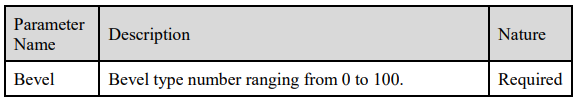
ConnectLaser
The command to connect to the laser, and to set bevel type, as shown in figure below.
DisConnectLaser
This command is used to disconnect from the laser. There’re no parameters for this command.
OpenLaser
Activate the laser beam.
CloseLaser
Deactivate the laser beam.
MuteLaser
Turn off the laser.
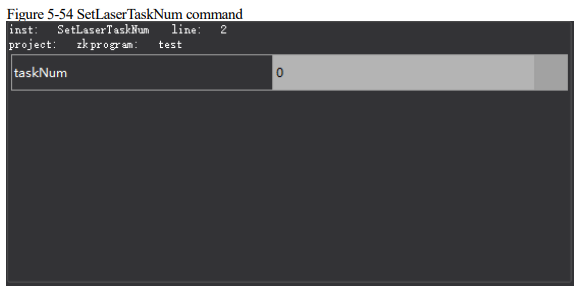
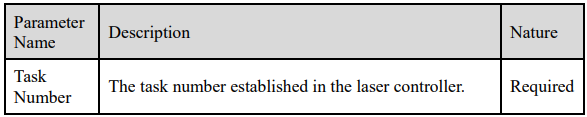
SetLaserTaskNum
Set the laser task number, as shown in the figure below.
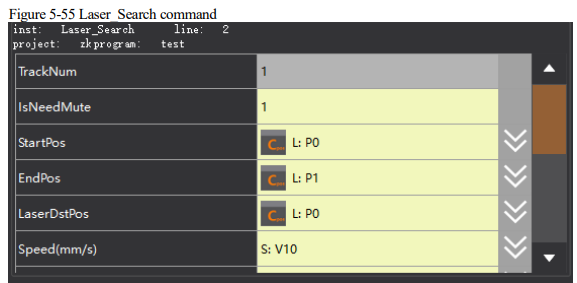
Laser_Search
The laser search command, which is used to search the starting position of the weld seam using a laser, as shown in figure below
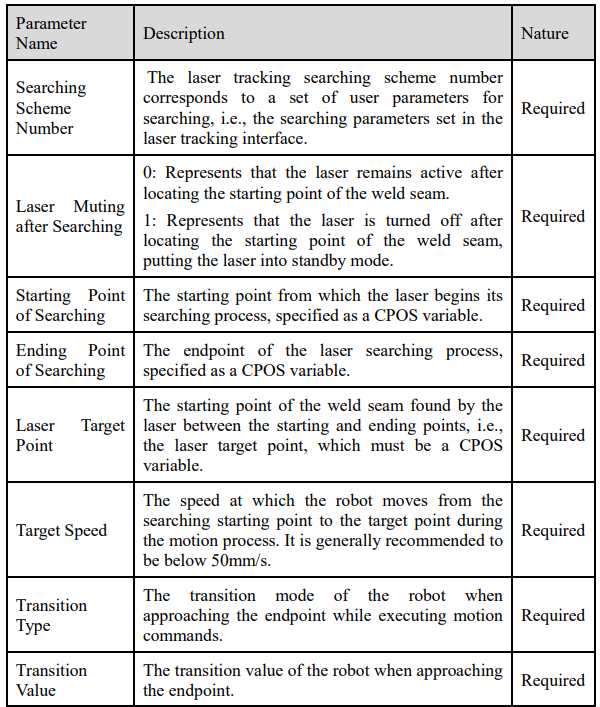
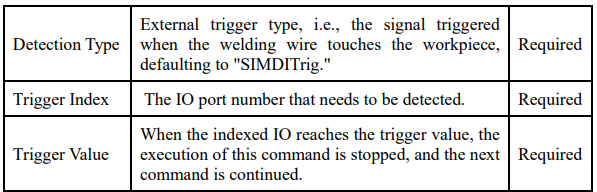
MovLTrack
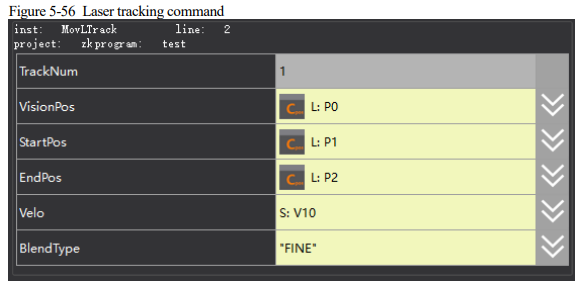
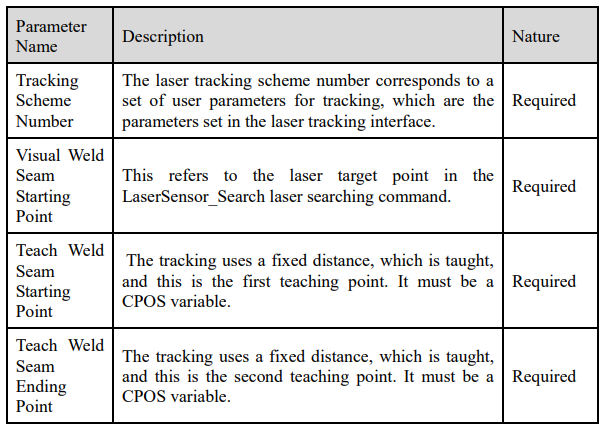
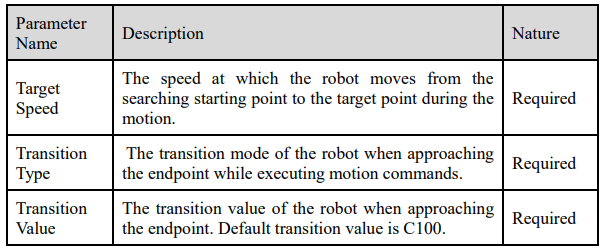
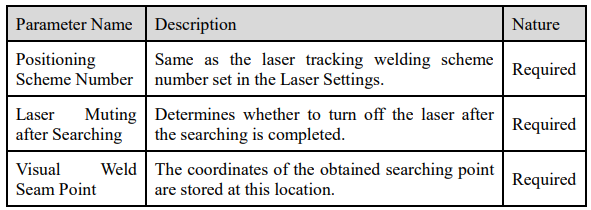
The laser tracking command. This command is used for laser scanning of the weld seam and transmitting the scanned points to the robot, enabling the robot to follow the weld seam's movement. It should be used in conjunction with the Laser_Search command. Additionally, this command integrates arc striking and arc stopping commands. If welding enablement is turned on, arc striking occurs at the starting point of the tracking command, and arc stopping occurs at the endpoint of tracking. Parameter descriptions are as shown in the figure below..
GetLaserPos
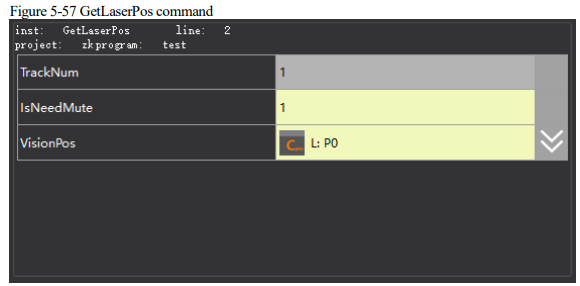
The command to get laser point position, as shown in the figure below.
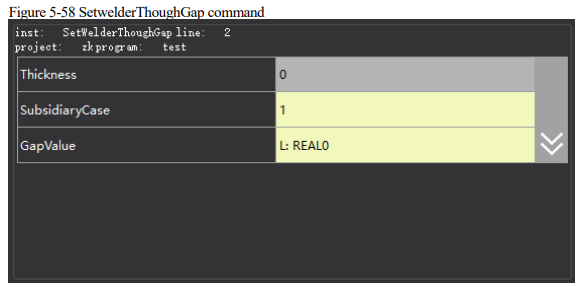
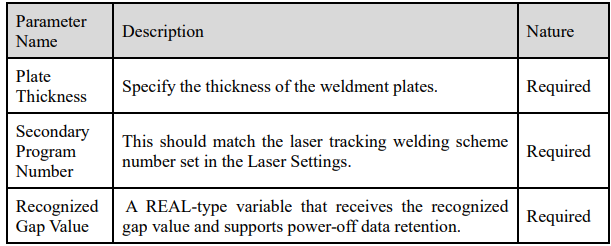
SetwelderThoughGap
The command to set welder through gap.
5.1.5 Control commands
Control commands are used to manage the path and execution of a program. They include commands that control program routes and states. Some of these commands are used in pairs to form code blocks. Here is a detailed explanation of several common control commands:
LABEL,GOTO,IF,ELSE,WHILE,CALL,RUN,KILL,RETURN,…=…,/*…*/. The following provides a detailed description:
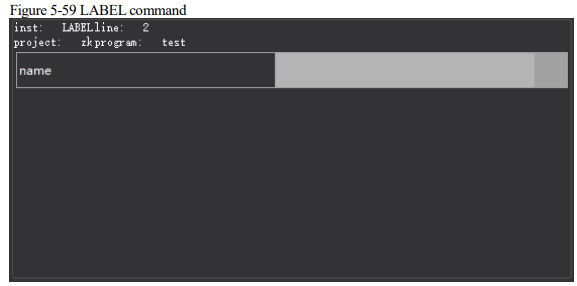
LABEL
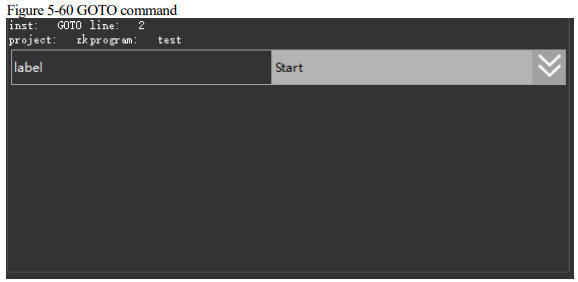
Label command is used to define the jump target of GOTO.
GOTO
GOTO command is used to jump to different parts of the program. The jump target is defined by the LABEL. It is not allowed to jump from the external into the internal program blocks. The internal block may be a WHILE cycle block or an IF block.
IF
IF command is used for jump control of the conditional judgment expression. When the result of the conditional judgment expression is TRUE, the program executes the block content under IF.
Similar to the IF statement in c++. The result of the IF condition judgment expression must be of BOOL type. For every IF command, any conditional judgment block must be ended with the
keyword ENDIF.
After selecting "Control Commands→ IF", you will enter the setting interface of IF statements, as shown in figure below.
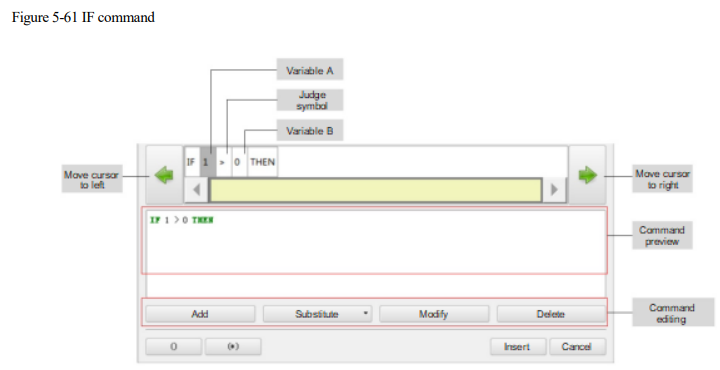
⚫ Variable A and Variable B can be set as constants or parameters: Click "Replace", and choose the constant, variable or function for replacement. To modify the value of a variable, you can move the cursor to the variable that needs to be modified, then click "Modify", and set the value in the pop-up dialog box.
⚫ The judgment symbol is used to judge the relationship between Variable A and Variable B. If it is TRUE, the command behind THEN is executed; if it is FALSE, the command behind THEN is skipped. To modify the judgement symbol, you can move the cursor to the judgement symbol, then click "Modify", and select the required symbol in the pop-up dialogue box.
⚫ Click "Add" to add a new "+" at the current position of the cursor, of which "+" denotes an operator, and "" denotes an operand.
◼ Click "+", then click "Modify" and select the desired operator in the pop-up soft keyboard, as shown in figure below.
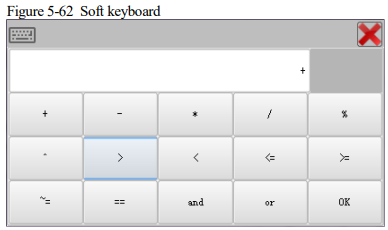 Click "", and then click "Replace" or "Modify" to change the operand to the desired constant, variable or function.
⚫ Click the operator or operand you would like to delete, and then click "Delete" to delete such operator and the subsequent operands.
⚫ Click an operator, and then click "()" to add a bracket to the operand in front of and behind the current operator. Click an operand and then click "()" to add a bracket to the current operand.
⚫ To delete the bracket, click the operator or operand, and then click "(*)" to delete the selected operator or operand response bracket.

[Note]
⚫ To delete an IF command, you need to click "Select Multi-line" in the program editing interface, then click the control statement between IF and END_IF, and then click "Edit → Delete" on the right menu.
⚫ When making replacement, you can select "mathematical function" or "character function". The functions are detailed in the Mathematical Operation Function and Character String Commands.
ELSEIF
⚫ ELSIF relies upon the IF command. It follows closely the IF command block. When the IF logic is not established, the ELSIF logic judgment is performed.
⚫ The way to set the ELSIF expression is the same as that of the IF expression.
⚫ Followings shall be noted when using this command:
⚫ ELSIF can be added behind the IF command block, but cannot be added separately.
⚫ ELSIF can also be added behind the ELSIF command block, of which one IF command block is followed by multiple ELSIF blocks.
⚫ ELSIF can be added in a nested way, which means that IF and ELSIF commands can be added in IF or ELSIF block.
⚫ After the IF logic is TRUE, the subsequent ELSIF commands will not be executed, but executing ENDIF directly.
⚫ After the IF logic is FALSE, the subsequent ELSIF commands will be executed; and if the ELSIF logic is FALSE, the subsequent ELSIF commands will then be executed.
⚫ After the IF logic is FALSE, the subsequent ELSIF command will be executed, and the ELSIF logic will be TRUE. The subsequent ELSIF commands will not, after execution, be executed, but executing ENDIF directly.
ELSE
ELSE command relies on the IF or ELSIF command. It is registered behind the IF or ELSIF block.
The statement will be executed when the IF or ELSIF condition judgment is not established.
WHILE
WHILE command executes sub-statements in loops when the conditions are met. The loop control expression must be of BOOL type. This command must end with the keyword ENDWHILE as the loop control.
The way to set WHILE expression is the same as that of IF expression.
For example:
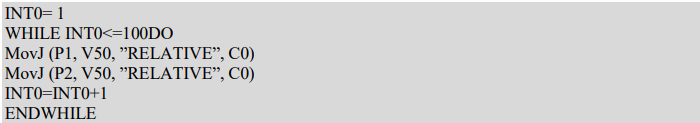
This command executes the cyclic motion of 100 times between two points.
CALL
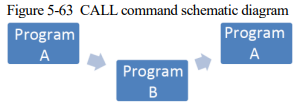
The CALL command. The current program jumps to another sub program in the same project, and jump back to the current program after the subroutine is executed. If the program to be called is program1, the command produced in the program is:

RUN
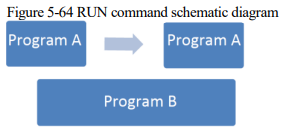
The program parallel running command. It enables the robot to run other programs while running the current program (the current program continues to run while starting another program without jumping) and the running program must be in the same project. If the program to be run is

[Note]
Currently, the controller supports 8 parallel running programs.
KILL
The command to stop parallel running. It enables the robot to stop running other programs while running the current program. The program stopped must be in the same project and in the running state. If the program that needs to be stopped is program1, the command produced in the program is:

RETURN
The RETURN command. In general, the program will jump to the end of the program after executing this command. If the RETURN is used in the CALL command, it will then return to the upper level program of the CALL command.
…=…
Establish an expression to assign a value to a variable, as shown in figure below.
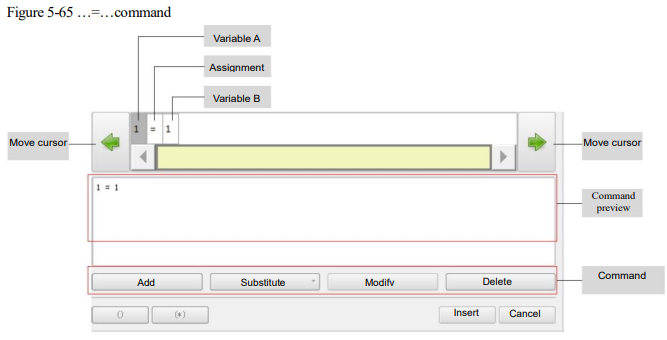
⚫ Variable A and Variable B can be set as constants or parameters: Click "Replace", and choose the constant, variable or function for replacement.
To modify the value of a variable, you can move the cursor to the variable that needs to be modified, then click "Modify", and set the value in the pop-up dialog box.
⚫ To add an assignment, move the cursor to "Variable B", and then click "Add", the expression will automatically add a new empty value, and the operator is "+" in default.
⚫ Click the operator "+", and then click "Modify" to select the desired operator.
⚫ Choose a new operator or subsequent variables, and then click "Delete" to delete the new operator and subsequent variables.
[Note]
When making replacement, you can select "mathematical function" or "character function". The functions are detailed in the Mathematical Operation Function and Character String Commands.
/*…*/
COMMENT command, to add definitions or remarks to the program.
This command will not affect the operation of the program, but only for reading and understanding the program.
5.1.6 SET commands
SetTool
Select the command of Tool Coordinates. Refer to the description in 2.6 Tool Coordinates for the way of tool coordinates settings. For example:

SetCoord
Select the command of User Coordinates. Refer to the description in the User Coordinates for the
way of user coordinates settings. For example:

SetExternalTCP
It is used to set the reference coordinates of the system to external tool coordinates. After command
execution, the system will switch the reference coordinates to the external tool coordinates. The robot will then move relative to the external tool coordinates. For example:

SetPositioner
It is used to set the reference coordinates of the system to POSITIONER coordinates. After command execution, the system will switch the reference coordinates to the POSITIONER coordinates. The robot will then move relative to the POSITIONER coordinates. For example:

[Note]
POSITIONER0 is of a positioner variable. The content in "POSITIONER data type" gives a detailed description.
SetJointDyn
It is used to set dynamic joint parameters, including Acceleration, Deceleration, Jerk, and Torque.
After running the command, the subsequent motion commands will all run using such dynamic parameters.
⚫ Acceleration: The percentage of the maximum acceleration of the joint.
⚫ Deceleration: The percentage of joint maximum deceleration.
⚫ Jerk: The percentage of the maximum jerk of the joint.
⚫ Torque: The percentage of the maximum torque of the joint.

SetCartDyn
Set the dynamic parameters in Cartesian space. After running this command, the subsequent motion commands will run using this dynamic parameter.
⚫ Acceleration: The percentage of the maximum acceleration in linear motion.
⚫ Deceleration: The percentage of the maximum deceleration in linear motion.
⚫ Jerk: The percentage of the maximum jerk in linear motion.
⚫ Posture Acceleration: The percentage of the maximum rotating acceleration of the posture.
⚫ Posture Deceleration: The percentage of the maximum rotating deceleration of the posture.
⚫ Posture Jerk: The percentage of the maximum rotating jerk of the posture.
⚫ Torque: The percentage of the maximum torque of the joint

SetBlendParam
It is used to set the transition parameters. After running this command, subsequent motion commands are run with this transition parameter. The command parameters are detailed below:
⚫ BlendType
Data type: enum (FINE/RELATIVE/DEFAULT)
Parameter meaning: The transition mode of the robot when approaching the endpoint
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ BlendValue
Data type: ZONE
Parameter meaning: The transition value when the robot is approaching the end point.

Example
SetBlendParam("RELATIVE",C20)
After this command is run, subsequent motion commands are run using this transition parameter.
SetOverRide
Override setting. Set the "Override" to an appropriate percentage value. For example:
SetOverRide (20)
SetOverRide (INT0) // Set the speed multiplier to the value in the INT0 variable
SetPayload
Select the workpiece load parameter command. For example:
SetPayload (PAYLOAD0)
GetCurOverRide
Get the current override. Get the "Current Override" as an appropriate percentage value and output
it to the int variable. For example:
GetCurOverRide (INT0)
Hand
Set the left and right hand system. It is only applicable to SCARA models. Set the parameter value
of “Left/Right Hand System” to "Lefty", "Righty" or "Default". For example:
Hand (“Lefty”)
/* After this command is executed, the subsequent motion commands will use the left-hand
setting.*/
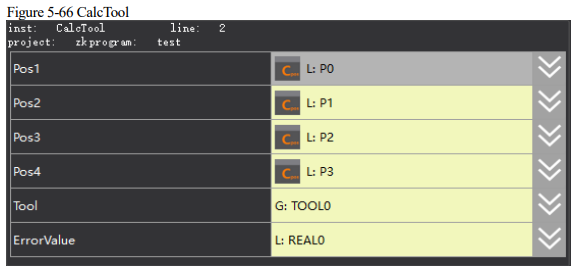
CalcTool
It calculates the tool parameters according to the four "calibration points", and saves them to the
coordinate system set by the "tool parameters".
For example:
CalcTool (P1, P2, P3, P4, TOOL1)
/*After this command is executed, calculate the tool parameters according to the four calibration points, and be saved to TOOL1*/
CalcCoord
Using this command, you can calculate the user coordinate system parameters according to the set "origin", "RX direction calibration point" and "RXRY plane calibration point", and saves them to the coordinate system set by the "user parameters"
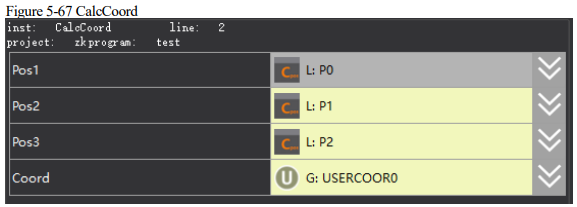
For example:
CalcCoord (P1, P2, P3, USERCOORD1)
/*After this command is executed, you can calculate the user coordinate system parameters using the three calibration points, and save it to the USERCOORD1*/
SetRtToErr
Enable the robot to stop running and issue an error message. For example:
SetRtToErr (“halt”, 100000)
SetRtInfo
Set the prompt message but does not affect the robot operation. For example:
SetRtInfo (“Info”, 70001)
SetRtWarning
Set the warning message but does not affect the robot operation. For example:
SetRtWarning (“Warning”, 80001)
Stop
Stop the execution of all the activated programs.
Stop ()
RefRobotAxis
A command to set the robot's single-axis homing, which can only be created with administrator permission.
RefRobotAxis (1,500)
/* After this command is executed, set the 1-axis servo of robot to zero point at the single-turn value of 500 */
SetMotionMode
This command can only be created in administrator permission. When setting the running mode, select "STANDARD" and "LOW_OSCILLATION" (low vibration). For example:
SetMotionMode (“STANDARD”)
AutoGainEnable
The command to enable servo self-adjustment. After executing this command, the system will optimize the subsequent motion commands at low speed according to the incoming LsScale and
LsThresh parameters. For details on how to use this command, please refer to "12.23 Servo parameters self-adjustment".
AutoGainEnable(LsScale0,LsThresh0)
/* Enable the servo parameter self-adjustment function*/
AutoGainDisable
The command to end the servo parameter self-adjustment. After executing the servo parameter self-adjustment ON command, execute this command to turn off the servo parameter selfadjustment function. For example:
AutoGainDisable()
/*Disable the servo parameter self-adjustment function*/
SetSingularPass
Set the cross-wrist singular function switch command with the options "OPEN" and "CLOSE". For example:
SetSingularPass("OPEN")/*Enable the cross-wrist singular pass function*/
SetColliEnable
A command to set the collision detection enable.
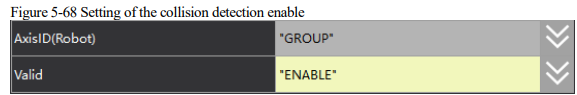
Axis number parameter: "GROUP, A1, A2, A3, A4, A5, A6". When the axis number is "GROUP", all axes are involved;
Enable parameter: "ENABLE, DISABLE".
SetColliEnable("GROUP","ENABLE")/*Enable the collision detection for all axes */
SetAxisColliParam
A command used to set the collision detection sensitivity value.
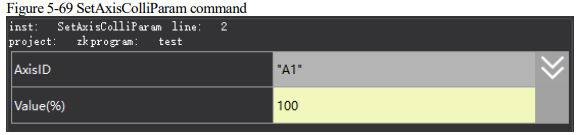
Axis number parameter: " A1, A2, A3, A4, A5, A6";
Sensitivity parameter: in percentage, parameter range [1,500].
SetAxisColliParam ("A1",200)/*Set the collision detection sensitivity value for axis 1 to 200*/
SetRestorePC
This command sets the pc pointer when the run program goes from Halt/Stop to run. Please note that this command is only valid for use in run programs. The command parameters are detailed as below:
⚫ Program pointer: The line number when the run program resumes running.
Example:
SetRestorePC(3)
/* The program pointer will run from line 3 when the run program is transferred from Halt/Stop state to run. */
SetAxisVibraBLevel
The command to set the vibration suppression level. It is only valid for input shaping.
⚫ Axis number: The axis number to which the vibration suppression level will be set (A1/A2/A3/A4/A5/A6)
⚫ Level: The level of vibration suppression to be set. (Highest/High/Default/Low/Lowest)
Example:
SetAxisVibraBLevel(A1,High)
/* Set the vibration suppression level for Axis 1 to medium-high. */
5.1.7 WAIT commands
Wait
It is used to set the robot wait time in ms, either as an int constant or as an INT variable. If you set the wait time to 1s, the two ways to generate the command are:
Wait(INT0)
// Use of constants
Wait(1000)
// Use of variables
INT0.value = 1000
Wait(INT0)
WaitFinish
It is used to synchronize the motion of the robot and program execution.
As shown in the example, the SetDO command will trigger when the first MovL command reaches 20%. The second MovL command will be execute after the first MovL command execution is finished.
If WaitFinish (20) is deleted, SerDO will be executed after the first MovL command is executed, followed by the second MovL command. In this case, there is no transition but hold between the two MovL commands.
MovL (P1, V1000,”RELATIVE”, C100)
WaitFinish (20)
SetDO (DO1, 1)
MovL (P2, V1000,”RELATIVE”, C100)
WaitCondition
Set the conditions for the robot to wait for execution. If the condition is not satisfied within the set time, it will return to the timeout state.
⚫ Execute the next command only when the "judgement condition" is TRUE, otherwise the program will continue to wait until the expression becomes TRUE.
⚫ "Duration" refers to the time required to execute the WAIT, in ms.
If the value of this parameter is 0, the next command can only be executed when the condition for judgment condition is TRUE.
If the value of this parameter is not 0, even if the condition for judgment is still not TRUE, the system will skip the command after waiting for a given period of time and continue to execute the next command.
⚫ Interrupt enabling: Set whether or not to continue timing after the program resumes during the waiting process.
0: Stop timing when the program stops, and continue timing before the program stopped when being resumed.
1: When the program stops, stop timing, and continue timing when being resumed.
⚫ Timeout judgment value: Choose a variable and assign a value to it in the following two cases.
If the input condition is TRUE and the command is executed, assign a value of 0 to the variable;
When the command is executed due to timeout, assign 1 to the variable.
⚫ Tag name for timeout jump: When the execution timed out, choose the line where the tag name is located.
WaitCondition (“1> 0”, 1000, 0, INT0,"Goto ggg")
5.1.8 Position operation commands
GetCurAPos
Get the position in the current joint coordinate system, and assign it to the Apos variables.
GetCurAPos (P1)
GetCurCPos
Get the Cartesian space position in the current coordinate system, and assign it to the Cpos variables.
GetCurCPos (P1)
APosToCPos
The command of robot position point conversion, through which APos points can be converted to CPos points.
Being given the APos point, as well as its user coordinates and tool paramete, the value of the target CPos point can then be derived.
APosToCPos (P1, P2, TOOL1, USERCOORD1)
CPosToAPos
The command of robot position point conversion, through which CPos points can be converted to APos points.
Being given the CPos point, as well as its reference coordinates and tool parameters , the value of the target APos point can then be derived.
APosToCPos (P1, TOOL1, USERCOORD1, P2)
CPosToCPos
The command of robot position point conversion, through which CPos points can be converted to CPos points.
Being given the CPos point, as well as the reference coordinates and tool parameters of the target CPos point to be converted, the value of the target CPos point can then be derived.
APosToCPos (P1, TOOL1, USERCOORD1, P2, TOOL2, USERCOORD2)
ToolOffset
The Robot Tool Coordinates Offset command, which rotates or offsets the reference tool coordinates to create the new tool coordinates.
Being given the reference tool coordinates TOOL and the offset to be shifted or rotated, the value of the target tool coordinates can be calculated.
ToolOffset (TOOL1, DCPOS1, TOOL2)
UserOffset
The Robot User Coordinates Offset command, which rotates or offsets the reference user coordinates to create the new user coordinates.
Being given the reference user coordinates USERCOORD and the offset to be shifted or rotated, the value of the target user coordinates can be calculated.
UserOffset (USERCOORD1, DCPOS1, USERCOORD2)
5.1.9 CLOCK commands
CLKStart
Start the specified clock (after starting, you can view from the variable list that the state of the specified CLOCK variable is TRUE). For example:
CLKStart (CLOCK0)
CLKStop
Stop the specified clock (its state is false, but will not be reset). For example:
CLKStop (CLOCK0)
CLKRead
Read the value of the specified clock, by checking the value corresponding to the variable in the list of variables. For example:
CLKRead (CLOCK0)
CLKReset
Reset the state value of the specified clock. For example:
CLKReset (CLOCK0)
5.1.10 I/O commands
For these commands, the digital and analog signals of the input and output modules will be used.
The digital and analog signals are often used in conjunction with trigger information.
SetDO
Set the digital output port to TRUE (1) or FALSE (0). For example:
SetDO (DO1, 1)
SetAO
Set the analog output port to a certain value. For example:
SetAO (AO2, 5.000000)
SetSimDO
Set the virtual digital output port to TRUE (1) or FALSE (0). For example:
SetSimDO (SimDO0, 0)
SetSimAO
Set the virtual analog output port to a certain value. For example:
SetSimAO (SimAO1, 5.000000)
WaitDI
Wait until the digital input port has been set or reset.
⚫ Port variable: The number of the input port to be waited for.
⚫ Port value: The digital input port level to be waited for.
0: Low level
1: High level
⚫ Duration (ms): The time to wait for signal change, either of type int constant or INT variable.
⚫ Interrupt enabling: Whether or not to continue timing after the program resumes during the waiting process.
0: Stop timing when the program stops, and continue timing before the program stopped when being resumed.
1: When the program stops, stop timing, and continue timing when being resumed.
⚫ Timeout judgment value: Return to the state after the command is executed
0: Signal is detected successfully
1: No signal is detected, and the command times out and returns.
⚫ Tag name for timeout jump: When the execution timed out, choose the line where the tag name is located.
WaitDI (DI0, 0, 1000, 0, INT0,"Goto ggg")
WaitDI8421
Wait for the state combination of a group of continuous digital input DI port within the specified time. If the condition for waiting is met within the set time, the program continues to execute downward; if not, the timeout judgment value is set to 1, and the program continues to execute downward.
⚫ Duration: The time spent in waiting for the DI signal of this group of digital inputs, either of type int constant or INT variable, in ms.
⚫ Interrupt enabling: The parameter is used to set whether or not to restart timing after restarting if the program is halted when waiting.
0: When the program is halted, timing is stopped but continued from the time before the program pause when resuming the operation.
1: When the program is halted, timing is stopped but restarted when resuming the operation
⚫ Start DI port: The start port number of the continuous DI port in this segment.
⚫ End DI port: The end port number of the continuous DI port in this segment.
⚫ Start port 8421 value: Convert the continuous DI port value of this segment into a decimal number. If it is equal to the VALUE, it will then be deemed to satisfy the condition.
⚫ Timeout judgment value: Return to the state after the command is executed.
0: Signal is detected successfully
1: No signal is detected, and the command times out and returns.
⚫ Tag name for timeout jump: When the execution timed out, choose the line where the tag name is located.
WaitDI8421(1000, 1, 9, 16, 255,INT1, "Gotoggg")
/*When the state of DI port 9-16 is 11111111 in 1,000 ms, the program will continue to execute downwards. If the condition is not met within 1000 ms, set INT1 to 1. If the program is paused while waiting, the timing will restart after program resumes. */
WaitAI
Wait until the analog input port value is equal to the given one. The parameter specifications are the same as that of WaitDI.
WaitAI (AI0, 0, 1000, 0, INT0,"Goto ggg")
WaitSimDI
Wait until the virtual digital input port is set or reset. The parameter specifications are the same as that of WaitDI.
WaitSimDI (SimDI0, 0, 1000, 0, INT0,"Goto ggg")
WaitSimDI8421
Wait for the state combination of a group of continuous virtual digital input SimDI ports within the specified time. The parameter specifications are the same as that of WaitDI8421.
WaitSimAI
Wait until the virtual analog input port value is equal to the given one. The parameter specifications are the same as that of WaitAI.
WaitSimAI (SimAI0, 0, 1000, 0, INT0,"Goto ggg")
PulseOut
Set the pulse time and conditions of IO variable output.
⚫ Port variable: The port number to be set.
⚫ Port value: Set the output pulse level.
0: Low level
1: High level
⚫ Duration: Set the time of pulse output.
⚫ Interrupt enabling: Whether the pulse output will continue to be output or not upon interruption.
0: When the program is stopped, the pulse output will continue for the set time and then stop. Its function will not be affected by the program stopping.
1: When both the program and output are stopped, the output will continue when the program continues to run, which means that it is synchronized with the program running state. The output acts based on the state of the program.
PulseOut (DO1, 1, 500, 1)
PulseSimOut
Set the pulse time and conditions of SimIO variable output.
⚫ Port variable: The port number to be set.
⚫ Port value: Set the output pulse level.
0: Low level
1: High level
⚫ Duration: Set the time of pulse output.
⚫ Interrupt enabling: Whether the pulse output will continue or not upon interruption.
0: When the program is stopped, the pulse output will continue for the set time and then stop. Its function will not be affected by the program stopping.
1: When both the program and output are stopped, the output will continue when the program continues to run, which means that it is synchronized with the program running state. The output acts based on the state of the program.
PulseSimOut (SimDO1, 1, 500, 1)
GetDI8421
Acquire a segment of continuous DI port status (regard it as a segment of binary data), and return it as a decimal number.
⚫ Start DI port: The start DI port number you want to acquire.
⚫ End DI port: The end DI port number you want to acquire.
⚫ End-The value of start port should not be greater than 32.
⚫ Return value: Store the acquired port state value into the int variable that has been fed.
GetDI8421 (9, 12, IN0)
GetSimDI8421
Acquire a segment continuous virtual digital input SimDI port status (regard it as a segment of binary data), and return it as a decimal number.
⚫ Start DI port: The start SimDI port number you desire to get.
⚫ End DI port: The end SimDI port number you want to acquire.
⚫ Return value: Store the acquired port state value into the int variable that has been transmitted.
GetSimDI8421 (9, 16, INT1)
/*Take the status of the virtual digital input ports from 9 to 16 as a binary number, convert it to a decimal number and return it to the variable INT1*/
SetDO8421
Set a segment of continuous DO port status (regard it as a segment of binary data); convert the decimal number transmitted in into a binary number, and set it to the designated DO port.
⚫ Start DO port: The start DO port number to be set.
⚫ End DO port: The end DO port number to be set.
⚫ End-The value of start port should not be greater than 32.
⚫ Set value: The decimal value that the port will outputs.
For example, 3 is 0011 when being converted into binary, then Ports 9 and 10 will output high level, respectively. 2 is for Port 9 low level. Set Port 10 to high level.
SetDO8421 (9, 10, 3)
SetSimDO8421
Set a segment of continuous SimDO port state (regard it as a segment of binary data); convert the decimal number transmitted in into a binary number, and set it to the designated SimDO port.
⚫ Start DO port: The start SimDO port number you want to acquire.
⚫ End DI port: The end SimDO port number you want to acquire.
⚫ Set value: The decimal set value that the port will output.
SetSimDO8421 (9, 16, 255)
/* Set the #9 to #16 virtual digital output ports to 1*/
GetSimDIToVar
Map the virtual digital input signal to a variable.
⚫ Port variable: The variable used to acquire the value of the virtual digital input signal. It is a virtual digital input variable.
⚫ Variable: The variable to which the acquired digital signal value is assigned. It is of type BOOL.
For example, the command that assigns the value of the virtual digital input variable SIMDI1 to BOOL0 can be as follows:
GetSimDIToVar(SimDI1,BOOL0)
SetSimDOByVar
Map the value of a Boolean variable to a digital output variable.
⚫ Port variable: The variable of digital output type, which receives the value of the variable and outputs it.
⚫ Variable: Boolean type, which outputs its value to port variable.
For example, the command that output the value of BOOL0 to the virtual digital output variable SimDO1 can be as follows:
SetSimDOByVar(SimDO1,BOOL0)
GetSimAIToVar
Map the virtual analog input signal to a variable.
⚫ Port variable: The variable used to acquire the value of the virtual analog input signal. It is a virtual analog input variable.
⚫ Variable: The variable assigned to the acquired analog signal value. It is REAL type.
For example, the command that assigns the value of the virtual analog input variable SIMAI1 to the real number variable REAL0 can be as follows:
GetSimAIToVar(SimAI1,REAL0)
SetSimAOByVar
Map the value of a REAL variable to a virtual analog output variable
⚫ Port variable: The variable of virtual analog output type, which receives the value of the variable and outputs it.
⚫ Variable: REAL type, which outputs its value to port variable.
For example, the command that outputs the value of the real number variable REAL0 to the virtual analog output variable SimAO0 can be as follows:
SetSimAOByVar(SimAO0,REAL0)
SetDIEdge
Set the edge signal state of a digital input port forcibly using commands.
⚫ Port variable: The variable of digital input type; it is used to set the rising or falling edge of the port.
⚫ Edge type: Choose the edge signal status of the port to be set.
riseEdge: Status of rising edge.
downEdge: Status of falling edge.
⚫ Edge value: The edge status value to be set.
For example: the command that sets the rising edge status of DI1 port to 0 can be as follows:
SetDIEdge(DI1 , "riseEdge" , 0)
SetSimDIEdge
Set the edge signal state of a virtual digital input port forcibly by using the commands.
⚫ Port variable: The variable of digital input type; it is used to set the rising or falling edge of the port.
⚫ Edge type: Choose the edge signal status of the port to be set.
riseEdge: Status of rising edge.
downEdge: Status of falling edge.
⚫ Edge value: The edge status value to be set.
For example: the command that sets the rising edge status of SimDI1 port to 0 can be as follows:
SetSimDIEdge(SimDI1 , "riseEdge" , 0)
5.1.11 Conveyor tracking commands
WaitWObj
This is the command of waiting for the visual information, to wait for the workpiece position information sent from the vision.
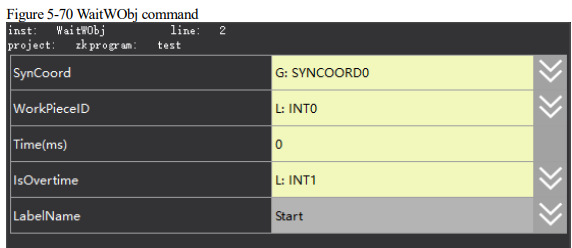
⚫ Moving coordinate system: SYNCOORD variable. The set moving coordinate system needs to be consistent with the moving coordinate system enabled on the conveyor configuration interface.
⚫ Workpiece id: Variable of type INT, which returns the id of the currently received workpiece.
⚫ Duration: Indicates the time required to execute waiting, in ms.
If the value of the parameter is 0, it will be forced to wait until it received the workpiece position information data from the vision before proceed to the next command.
If the value of the parameter is not 0, even if no data is received, the system will skip the command after waiting for a given period of time, and proceed the next command.
⚫ Timeout judgment value: Select a variable and assign a value to it in the following two cases.
When the command is executed within the waiting time, assign 0 to the variable;
When the command is executed due to timeout, assign 1 to the variable.
⚫ Tag name for timeout jump: When the execution timed out, choose the line where the tag name is located.
MovLSync
The command to initiate linear motion for conveyor synching, through which the TCP point of the robot can track the conveyor at the set speed, and reach the target position in a linear motion.
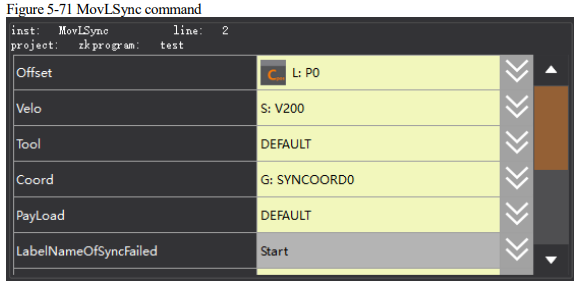
Before this command is executed, the robot control system will trigger the vision to shoot through IO and receive the target position from the vision system. When the command is executed, the robot will move from the current to the target position and keep in sync with the moving target object.
⚫Target position offset: The offset relative to the tracked target object, it can only be set as a CPOS position point.
Choose an existing point from the drop-down list.
⚫Target speed: The running speed of command.
−When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫Tool Parameters: The tool parameters used when the robot executes the path.
When setting it to “DEFAULT”, the tool parameters set last time will be continuously used.
⚫Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.Only the variable of SYNCOORD type can be set, but needs to be consistent with the moving coordinate system on the conveyor configuration interface.
⚫Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫Jump label when aborting during synchronization: It is used to follow the Aborting function. When the robot fails to synchronize with the target workpiece during synchronization, i.e. when the execution of the MovLSync command fails, the program pointer will go to the line where the Jump label is located to perform the Aborting operation. The user can add the corresponding command under this Label according to the working conditions on site.
⚫This value can be set by default. When set to default, it will jump to the Label used for the "Jump to label when aborting after synchronization".
⚫Lift height when aborting after sync: The distance lifted while following when aborting after sync, this is the offset relative to the positive direction of the Z axis of the moving coordinates.
⚫Jump label when aborting following sync: It is used to follow the Aborting function. When the robot cannot continue following during the following motion, i.e. the execution of the subsequent commands of the MovLSync command fails, the program pointer will go to the line where the jump label is located to perform the Aborting operation.
⚫This value cannot be defaulted and requires special attention in this case.
⚫AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO commands: Executing IO operation. The IO commands currently available are SetDo, SetAo, SetSimDo, SetSimAo, PulseOut, PulseSimOut, SetDO8421, SetSimDO8421, SetDIEdge, and SetSimDIEdge.
MovJSyncQuit
This is the command of conveyor syn tracking, through which the TCP point of the robot can quit the conveyor tracking status at the set speed and reach the target position in the fastest mode.
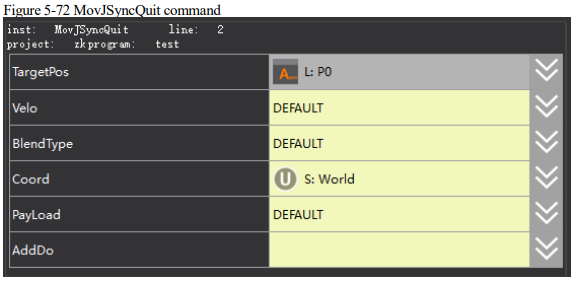
When executing this command, the robot transits smoothly from the previous motion command and quits the tracking status, and then resumes the motion in the normal user coordinates.
⚫Target position: The final position of the command (the position point of APOS or CPOS).
⚫Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
⚫Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
This parameter cannot be set to “DEFAULT” and must be forced to enter a coordinate system parameter.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO commands: Executing IO operation. The IO commands currently available are SetDo, SetAo, SetSimDo, SetSimAo, PulseOut, PulseSimOut, SetDO8421, SetSimDO8421, SetDIEdge, and SetSimDIEdge.
MovLSyncQuit
This is the command of conveyor syn tracking QUIT, through which the TCP point of the robot can quit the conveyor tracking status at the set speed and reach the target position by linear motion.
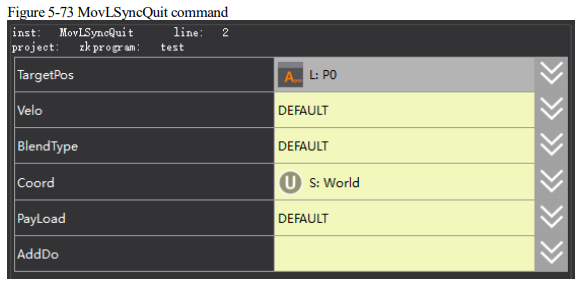
When executing this command, the robot transits smoothly from the previous motion command and quits the tracking status, and then resumes the motion in the normal user coordinates.
⚫Target position: The final position of the command (the position point of APOS or CPOS).
⚫Select an existing point in the drop-down list or create a new variable and teach it in the pop-up dialog box.
⚫Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫Coordinate System Parameters: The coordinate system parameters used by the robot when executing the path.
This parameter cannot be set to “DEFAULT” and must be forced to enter a coordinate system parameter.
When it is set to USERCOOR variable, you can selected the system pre-defined one, or create it by yourself.
When a coordinate system different from the current one is used, the system will switch the coordinate system to the set one.
⚫Workpiece load: The workpiece load parameter used by the robot when executing the path.
It is set to “DEFAULT”, which means to continue to use the workpiece load parameters set last time.
−When it is set to PAYLOAD variable, you can selected the system pre-defined one, or create it by yourself;
when a load parameter different from the current workpiece load parameter is used, the system will switch the workpiece load parameter to the set parameter. If the tool parameters of the path of current segment and the preceding/next segments change, the transition will not be supported.
⚫AddDo: The robot can perform IO operation after executing this command.
NULL: No operation.
IO commands: Executing IO operation. The IO commands currently available are SetDo, SetAo, SetSimDo, SetSimAo, PulseOut, PulseSimOut, SetDO8421, SetSimDO8421, SetDIEdge, and SetSimDIEdge.
SetTargetPos
This is the workpiece position information setting command. Use it to set the detected position information of the workpiece after entering the conveyor.
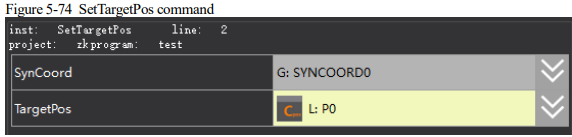
⚫Moving coordinate system: SYNCOORD variable. The set moving coordinate system needs to be consistent with the moving coordinate system enabled on the conveyor configuration interface.
⚫Target position: The CPOS type variable, and also the detected position information of the workpiece after entering the conveyor. Please note that only 2D visual data is currently supported, which means that only X, Y and
A are valid in this CPOS type variable.
SetSyncoord
The moving coordinate system set commands. It is used to set the current robot reference coordinates to moving coordinates. This command enables the current robot reference coordinates to be switched to a moving coordinate system, which can quickly teach the posture of the point position during the following process.
⚫Coordinate system parameters: The parameters of the coordinate system to which the robot is currently referenced, which can only be set to variables of SYNCOORD.
⚫Note that after switching to a moving coordinate system, only the JOG coordinates set before the switch can be toggled, e.g. if the JOG coordinate system set before the switch is a WORLD coordinate system, then only the WORLD coordinate system can be toggled after the command is executed and cannot be switched.
SynCToUserC
The teach reference coordinates conversion command. It is used to solve the coordinate system referenced when following the path point after synchronization.
⚫Moving coordinate system: The variable of type SYNCOORD. The moving coordinate system must be the same as the one enabled in the conveyor configuration interface.
⚫Target position: The variable of type DCPOS, indicating the offset of the position of the workpiece entering the conveyor relative to the origin of the moving coordinate system.
⚫Coordinate system parameter: The variable of type USERCOORD, indicating the coordinate system to be referred to when teaching the path point position after synchronization.
WaitConvDis
It is used to enable the robot to move in the positive direction of the conveyor in synchronization with the conveyor up to a certain increment before executing subsequent commands, thus allowing the robot to delay the movement for a specified increment. Unlike the Wait commands, this command requires a fixed increment while the Wait command requires a fixed time.
⚫Moving coordinate system: The variable of type SYNCOORD. The moving coordinate system must be the same as the one enabled in the conveyor configuration interface.
⚫WAIT increment: The value of the increment in which the robot is to be synchronized. In mm for straight conveyors and in deg for disc conveyors.
5.1.12 Bit operation commands
BitAnd
This is the command for bitwise AND operation. It performs bitwise AND operation on two operands, and assigns the result to the first operand.
⚫Operand 1: INT type variable; the operation result is also assigned to this operand.
⚫Operand 2: INT type variable.
BitAnd (INT1, INT2)
BitNeg
This is the command for bitwise negation operation. It performs bitwise negated operation for the operand, and assigns the result to the operand. Moreover, only the last 16 bits of the operand are negated.
⚫Operand: INT variable; the operation result is assigned to the operand.
BitNeg (INT1)
BitOr
This is the command for bitwise Or operation. It performs bitwise Or of two operands, and assigns the result to the first operand.
⚫Operand 1: INT type variable; the operation result is also assigned to this operand.
⚫Operand 2: INT type variable.
BitOr (INT1, INT2)
BitXOr
This is the command for bitwise XOr operation. It performs a bitwise XOr operation on two operands, and assigns the result to the first operand.
⚫Operand 1: INT type variable; the operation result is also assigned to this operand.
⚫Operand 2: INT type variable.
BitXOr (INT1, INT2)
BitLSH
This is the command for bitwise left shift. It performs bitwise left shift operation of the first operand as per the left shift number specified by the second operand, and assigns the result to the first.
⚫Operand 1: INT type variable; the operation result is also assigned to this operand.
⚫Operand 2: INT type variable, and the bit number of left shift.
BitLSH (INT1, INT2)
BitRSH
This is the command for bitwise right shift. It performs bitwise right shift operation of the first operand as per the right shift number specified by the second operand, and assigns the result to the first.
⚫Operand 1: INT type variable; the operation result is also assigned to this operand.
⚫Operand 2: INT type variable, and the bit number of right shift.
BitRSH (INT1, INT2)
5.1.13 AREA commands
AreaActivate
This is the command for activating standard AREA commands to validate the specified standard area.
AreaActivate (AREA0)
AreaDeactivate
This is the command for deactivating standard AREA commands to invalidate the specified standard area.
AreaDeactivate (AREA0)
PolyhedronAreaActivate
This is the command for activating polyhedron AREA to validate the specified polyhedron area.
PolyhedronAreaActivate (POLYHEDRON0)
PolyhedronAreaDeactivate
This is the command for deactivating polyhedron AREA to invalidate the specified polyhedron area.
PolyhedronAreaDeactivate (POLYHEDRON0)
5.1.14 Visual commands
TrigCam
This is the command to trigger the camera shooting.
TrigCam (“OK”,0)
WaitFinishCAM
This is the command for waiting for the camera to finish shooting
WaitFinishCAM (1000,0)
GetCamPos
This is the command for getting the camera position.
GetCamPos (P6, INT0, INI1,0)
SendMessage
Send a string message, which can be used for 3D visual commands. It sends the specified string to the camera, and enables the camera to shoot. For example:
SendMessage (“OK”,0)
Tracking
Tracking conveyor command. For detailed description of this command, please refer to the
Introduction to parameters in the Conveyor Tracking commands.
Tracking (10.0, 10.0, DO2, DO1, INT0,INT1)
5.1.15 Palletizing commands
PalletReset
This is the command for palletizing reset. When a pallet is forced to stop before the palletizing is completed, call this command to restore it.
⚫ Palletizing name: PALLET variable of the current palletizing.
⚫ Number of workpieces: The number of workpieces that have been placed on the current pallet. It must be set from 0 to the maximum number of workpieces of the pallet.
PalletReset (PALLET0,0)
For example, Pallet0 with a maximum number of workpieces of 60 will halt when 8 workpieces have been placed. Call "PalletReset (Pallet0, 8);" to restart the palletizing of subsequent workpieces.
PalletToPut
This is the command for putting workpieces.
⚫ Palletizing name: The PALLET variable of the current palletizing.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
PalletToPut (PALLET1,V2000)
The palletizing position is calculated based on the first taught workpiece position as well as the configured palletizing distance. Add the set palletizing distance to the position of the previous workpiece, so as to get the position of the next workpiece, as shown in figure below.
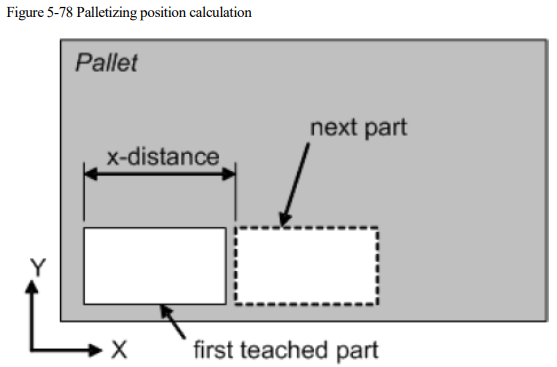
According to the figure, the defaulted palletizing sequence starts from X. Arrange all the parts in the x direction first, and then the next row. Arrange the workpiece in the x direction until the predetermined number of workpieces in the x direction is reached.
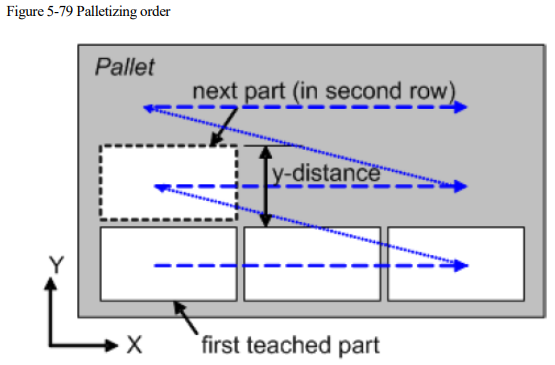
When starting placement for a new row, the position data of the workpiece in the new row will be produced by adding the offset in the y direction to the position of the workpiece in the first row.
The default palletizing sequence is x y z. First, put the workpiece in the x direction and then proceed to the second row. The placement of the first part of the new row starts at the position shown in the figure below. They will be put on the next row if the current row is full. After all the rows in this layer are filled, the xy layer repeats translation in the z direction until it is fully palletized.
When performing the placement, the recommended path is shown in the figure below.
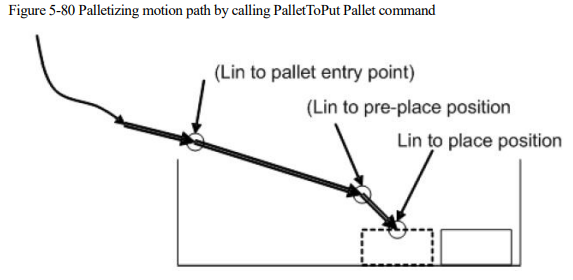
Following motion commands are executed when PalletToPut command is called:
⚫ The robot moves to the entry position of the pallet in a linear motion (optional)
⚫ The robot moves to the front position of the palletizing point in a linear motion (optional)
⚫ The robot moves to the arranged position of the workpiece in a linear motion (required)
PalletFromPut
This is the command used when the robot moves away from the putting position after the workpieces are placed.
⚫ Palletizing name: The PALLET variable of the current pallet.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
PalletFromPut (PALLET2,V2000)
This is the command for the opposite action of workpiece placement, making the robot leaves from the position of the workpiece that has been placed.
The recommended path when leaving is shown in figure below.
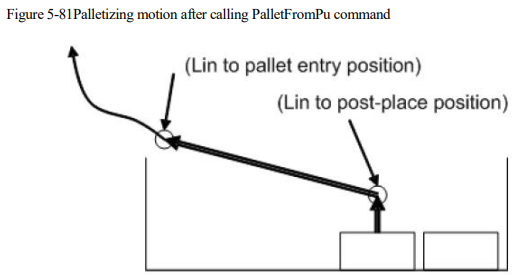
Following motion commands are executed when calling the PalletFromPut command:
⚫ The robot moves to the rear of palletizing point in a linear motion (optional)
⚫ The robot moves to the entry position of the pallet in a linear motion (optional)
If neither the post-pallet point nor the entry position has been set, the robot will maintain its current posture when the PalletFromPut command is executed.
PalletToGet
This is the command for picking the workpiece. When executing this command, the robot will move from the current point to the palletizing point of the target workpiece to pick such workpiece.
⚫ Palletizing name: The PALLET variable of the current pallet.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
PalletToGet (PALLET3,V2000)
The recommended path for picking is shown in figure below.
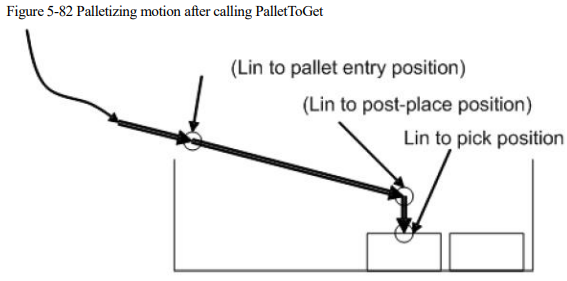
Following motion commands are executed when calling the PalletToGet command:
⚫ The robot moves to the entry position of palletizing point in a linear motion (optional)
⚫ The robot moves to the post position of the pallet in a linear motion (optional)
⚫ The robot moves to the picking position in a linear motion (required)
After making these motion sequences, the robot reaches the position where the workpiece is placed, then closes the fixture for picking workpieces.
PalletFromGet
This is the command indicating the process of leaving after workpiece pick. When executing this instruction, the robot will leave from the palletizing point where the workpiece is picked.
⚫ Palletizing name: The PALLET variable of the current pallet.
⚫ Target speed: The running speed of command.
When setting it to "DEFAULT", the default value V4000 will be used.
When it is set to SPEED variable, you can select the system pre-defined one, or create it by yourself.
⚫ Transition type: The way of transition when the robot approaches the endpoint.
DEFAULT: Use of the defaulted transition way FINE, i.e. use of no-transition.
FINE: No transition.
RELATIVE: Relative transition.
ABSOLUTE: Absolute transition.
⚫ Transition Value: The transition value when the robot approaches the endpoint.
When setting it to "DEFAULT", the default value C100 will be used.
When it is set to ZONE variable, you can selected the system pre-defined one, or create it by yourself; it means no transition when the variable value is 0; the greater the transition value, the larger the transition radius.
PalletFromGet (PALLET4,V2000)
The recommended path for picking is shown in figure below.
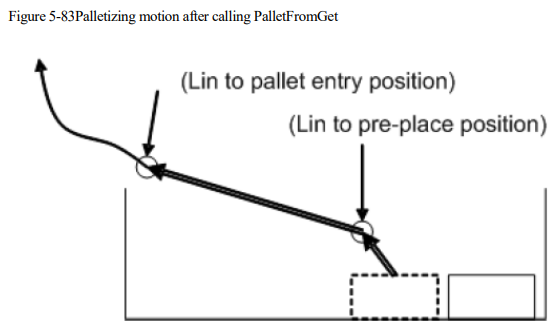
Following motion commands are executed when calling the PalletFromGet command:
⚫ The robot moves to the palletizing point in a linear motion (optional)
⚫ The robot moves to the entry position of the pallet in a linear motion (optional)
If neither the post-point nor the entry position of the pallet point has been set, the robot will maintain its current posture when executing the PalletFromGet command.
5.1.16 Socket commands
SocketCreate
Create a socket client for purpose of data exchange with the server. Create a client locally and connect it with the server-side according to the server-side parameters transmitted.
⚫ Socket name: The name of the socket to be created. The value transmits a socket variable.
⚫ IP address: The ip address of the server to be connected.
⚫ Port number: The port number of the server to be connected.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketCreate (Socket0, "192.168.1.1", 8888, INT0)
/*Create a Socket named Socket0, the connected server IP is "192.168.1.1", and the port is 8888*/
SocketClose
Close the socket client that has been created before.
Close the created client according to the socket name transmitted, and return the success or failure information of the operation.
⚫ Socket name: The name of the socket to be closed. The value transmits a socket variable.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketClose (Socket0, INT0)
/*Close the Socket0*/
SocketSendStr
Send a string to the server for the interaction of commands.
Send a string to the server that has established a connection, and return the result of whether it is successful or not.
⚫ Socket name: The name of the socket that needs to perform the sending operation. The value transmits a socket variable.
⚫ Sent strings: The string data that needs to be sent to the server-side.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketSendStr (Socket0, "test string", INT0)
/* Send the "test string" to the server */
SocketSendReal
Send a real array to the server for command interaction. Send a real array to the connected server and return the success or failure.
⚫ Socket name: The name of the socket that needs to perform the sending operation. The value transmits a socket variable.
⚫ Real-type array sent: The real-type array data that needs to be sent to the server-side.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketSendReal (Socket0, RealOneArray0, INT0)
/*Send RealOneArray one-dimensional array information to the server*/
SocketSendInt
Send an int array to the server for command interaction. Send an int array to the connected server and return the success or failure.
⚫ Socket name: The name of the socket that needs to perform the sending operation. The value transmits a socket variable.
⚫ int-type array sent: The real-type array data that needs to be sent to the server-side.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketSendInt (Socket0, IntOneReal, INT0)
/*Send IntOneArray one-dimensional array information to the server*
SocketReadReal
Read the string sent from the server-side, and store it in the form of a real array.
Wait for and receive the string sent by the server. Its format is [1.1,2.2,3.3,4.4] (that is, the beginning and the end of the data are'[]', and the figures are separated by ','). The robot system will split and parse the received string, and store it in the array in sequence.
⚫ Socket name: The name of the socket that needs to perform the read operation. The value transmits a socket variable.
⚫ Read count of data: The count of data to be read and stored in the array.
⚫ Data return value: Store the read and converted value into an array variable, and return such array variable.
⚫ Detection time: The time for waiting for the server-side to send data. It sends alarm when time is out.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketReadReal (Socket0, 5, RealOneArray0, 100, INT0)
/*Read 5 real numbers from the server within 100ms, and put them in the variable RealOneArray0 */
SocketReadInt
Read the string sent from the server and store it in the form of an int array.
Wait for and receive the string sent by the server-side. Its format is [1,2,3,4] (the beginning and the end of the data are'[]', and the figures are separated by ','). The robot system will split and parse the received string, and store it in the array in sequence.
⚫ Socket name: The name of the socket that needs to perform the read operation. The value transmits a socket variable.
⚫ Read count of data: The count of data to be read and stored in the array.
⚫ Data return value: Store the read and converted value into an array variable, and return such array variable.
⚫ Detection time: The time for waiting for the server-side to send data. It sends alarm when time is out.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketReadInt (Socket0, 5, IntOneArray0, 100, INT0)
/*Read 5 real numbers from the server within 100ms, and put them in the variable IntOneArray0 */
SocketReadStr
Read the string sent from the server-side, and store it in the form of a string variable.
Wait and receive the string sent by the server. Its format is [Hello world!] (The beginning and the end of the data are '[]'). The robot system will store the received string in the string variable.
⚫ Socket name: The name of the socket that needs to perform the read operation. The value transmits a socket variable.
⚫ Read string: The string data sent from the server. The value is returned in the form of a string variable.
⚫ Detection time: The time for waiting for the server-side to send data. It sends alarm when time is out.
⚫ Operation return value: Create the return value variable of the operation. It is success if the return value is 0, and failed if it is 1.
SocketReadStr (Socket0, STRING0, 100, INT0)
/*Read the strings from the server within 100ms, and put them in the variable STRING0 */
5.1.17 SoftFloat commands
SoftFloatStart
This is the command for SoftFloat start. Turn on the SoftFloat function and set the parameters.
⚫ Type of SoftFloat:
Linear SoftFloat. Only the linear SoftFloat is supported currently.
⚫ SoftFloat reference coordinate system:
WORLD: World Coordinates
USER: Tool Coordinates
TOOL: User Coordinates
⚫ Coordinate system number: When WORLD is selected as the reference coordinate system, the coordinate system number is empty by default and will not be displayed. When TOOL or USER is selected, select an existing coordinate system number from the drop-down list, or create a new coordinate system number in the pop-up dialog box for teaching.
⚫ SoftFloat direction:
X: The X direction of the selected reference coordinate system or its number
Y: The Y direction of the selected reference coordinate system or its number
Z: The Z direction of the selected reference coordinate system or its number
⚫ SoftFloat sensitivity: The SoftFloat compliance parameter.
HIGH: The highest level of compliance
MidHigh: The second highest level of compliance
MID: The medium compliance
MidLow: The second lowest level of compliance
LOW: the lowest level of compliance
For the setting of SoftFloat direction, please refer to the description of SoftFloat functions for details.
SoftFloatStart ("CART","TOOL",tool1,"Y","MID")
SoftFloatStop
This is the command for SoftFloat ending. Use this command to turn off the SoftFloat function.
After the SoftFloat function is done, call this command to turn off the SoftFloat function.
SoftFloatStop ()
5.1.18 Mathematical functions
The mathematical functions or string operating functions may be used in the "IF" and "...=..." commands. This section explains the "Mathematical Functions" that may be used.
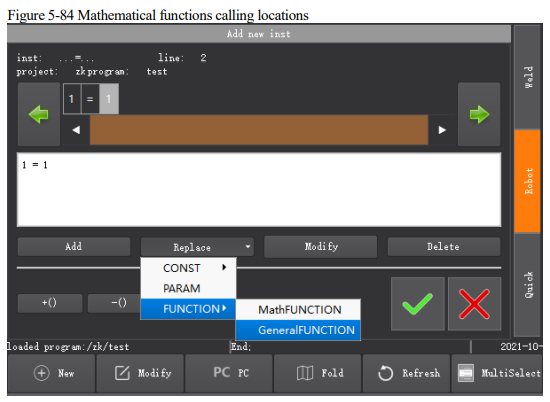
sin
The sine trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL
cos
The cosine trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
tan
The tangent trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
asin
The inverse sine trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
acos
The inverse cosine trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
atan
The inverse tangent trigonometric function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
atan2
X/Y inverse tangent value function, returning the value in radian from the X axis to the point (x, y).
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Parameter 2: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
sinh
The hyperbolic sine function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
cosh
The hyperbolic cosine function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
tanh
The hyperbolic tangent function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
log
The natural logarithmic function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
log10
The logarithmic function of base 10.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
sqrt
The square root function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
exp
The exponential function of base e.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
pow
The exponential function.
⚫ Parameter 1: int or real type variables or constants, base.
⚫ Parameter 2: int or real type variables or constants, exponent.
⚫ Function return value: A constant of type REAL.
deg
The radian to degree function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
rad
The degree to radian function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type REAL.
fmod
The remainder function.
⚫ Parameter 1: int or real type variables or constants, dividend.
⚫ Parameter 2: int or real type variables or constants, divisor.
⚫ Function return value: A constant of type REAL.
floor
The floor function.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type int.
random
Random integers selected from one of the 2 parameters.
⚫ Parameter 1: A variable or constant of type int or REAL.
⚫ Parameter 2: A variable or constant of type int or REAL.
⚫ Function return value: A constant of type int.
5.1.19 STRING commands
byte
Take the ASCCII code of the character in the nth position of the string.
⚫ Parameter 1: The variable or constant of string type.
⚫ Parameter 2: The variable or constant of type int.
⚫ Function return value: The int-type constant.
char
Return the character corresponding to the ASCCII code.
⚫ Parameter 1: The variable or constant of type int.
⚫ Function return value: The constant of string type.
find2
Return the position of the substring in the string.
⚫ Parameter 1: The variable or constant of string type.
⚫ Parameter 2: The variable or constant of type int.
⚫ Function return value: The int-type constant. (The return value is -1 when the corresponding character or string is not found)
findEnd
The string inversion lookup command, which locates the last occurrence of a specified string in a string and returns the index number.
⚫ Parameter 1: The source string to be looked up, a variable or constant of type string.
⚫ Parameter 2: The specified string to be looked up, a variable or constant of type string.
⚫ Return value: The index number of the search, a variable of type int.
format
The formatted STRING command, which transmits a reasonable formatting control in parameter 1, fills this formatting control with any number of subsequent parameters, and returns the filled data.
⚫ Parameter 1: The String format, a variable or constant of type string.
⚫ Parameter 2: The parameter of the formatting controller to be filled, a variable or constant of type string/real/int.
⚫ Parameter 3: The parameter of the formatting controller to be filled, a variable or constant of type string/real/int.
⚫ ... (no limit on the number of parameters, as long as the total length does not exceed the length of a single commanded string)
⚫ Function return value: The count of successfully split and saved to an array, a variable of type int
The formatted string starts with % and supports the following uses.
⚫ %c - accepts a number and converts it to the corresponding character in the ASCII table
⚫ %d, %i - accepts a number and converts it into signed integer format
⚫ %o - accepts a number and converts it to octal format
⚫ %u - accepts a number and converts it to unsigned integer format
⚫ %x - accepts a number and converts it to hexadecimal format, using the lowercase letter x
⚫ %X - accepts a number and converts it to hexadecimal format, using an uppercase X
⚫ %f - accepts a number and converts it to floating point format
⚫ %s - accepts a string and formats it according to the given parameters
Example:
⚫ format("%%c: %c", 83) Output S
⚫ format("%+d", 17.0) Output +17
⚫ format("%05d", 17) Output 00017
⚫ format("%o", 17) Output 21
⚫ format("%u", 3.14) Output 3
⚫ format("%x", 13) Output d
⚫ format("%X", 13) Output D
⚫ format("%6.3f", 13) Output 13.000
⚫ format("%s", "monkey") Output monkey
⚫ format("%10s", "monkey") Output monkey
getAt
The command to obtain a single string. It gets the string data of a certain bit and returns the obtained data.
⚫ Parameter 1: The string to be intercepted, a variable or constant of type string.
⚫ Parameter 2: The position to be intercepted, a variable or constant of type int.
⚫ Function return value: The acquired string, a variable of type string.
gsub
Search for a substring in the string s, and substitute a with the string b.
⚫ Parameter 1: string type variables or constants.
⚫ Parameter 2: string types variables or constants.
⚫ Parameter 3: string types variables or constants.
⚫ Function return value: string type constants.
len
Calculate the length of a string.
⚫ Parameter 1: The variable or constant of string type.
⚫ Function return value: The int-type constant.
left
The command to take the left of a string. It intercepts a specified number of strings starting from the left side of the string and returns the intercepted data.
⚫ Parameter 1: The string to be intercepted, a variable or constant of type string.
⚫ Parameter 2: The number to be intercepted, a variable or constant of type int.
⚫ Function return value: The intercepted string, a variable of type string.
lower
Return the string in lowercase format.
⚫ Parameter 1: The variable or constant of string type.
⚫ Function return value: The constant of string type.
right
The command to take the right of a string. It intercepts a specified number of strings starting from the right side of the string and returns the intercepted data.
⚫ Parameter 1: The string to be intercepted, a variable or constant of type string.
⚫ Parameter 2: The number to be intercepted, a variable or constant of type int.
⚫ Function return value: The intercepted string, a variable of type string.
reverse
The string inversion command, which inverts the string and returns it.
⚫ Parameter 1: The string to be inverted, a variable or constant of type string.
⚫ Function return value: The string to be inverted, a string variable.
strcmp
The String comparison command. Under this command, the return value is the ASCII difference between the first different characters.
⚫ Parameter 1: The string data to be compared, a variable or constant of type string.
⚫ Parameter 2: The string data to be compared, a variable or constant of type string.
⚫ Function return value: The returned ASCII value, a variable of type int.
trigLeft
The command to trim the string by left. This command removes the spaces to the left of the string and returns the modified string data.
⚫ Parameter 1: String to be trimmed, a variable or constant of type string.
⚫ Function return value: The trimmed string, a variable of type string.
trigRight
The command to trim the string by right. This command removes the spaces to the right of the string and returns the modified string data.
⚫ Parameter 1: String to be trimmed, a variable or constant of type string.
⚫ Function return value: The trimmed string, a variable of type string.
upper
Return the string in uppercase format.
⚫ Parameter 1: The variable or constant of string type.
⚫ Function return value: The constant of string type.
IToStr
Integer data to STRING command. The command allows to convert integer data to string type data and return the converted string.
⚫ Parameter 1: The integer data to be converted, a variable or constant of type int.
⚫ Function return value: The converted string data, a variable of type string.
RToStr
REAL parameter to STRING command. The command allows to convert the real data to string type data and return the converted string.
⚫ Parameter 1: The real data to be converted, a variable or constant of type REAL.
⚫ Function return value: The converted string data, a variable of type string.
StrToI
The String to Integer command. This command converts string data to integer type data and returns the converted integer data.
⚫ Parameter 1: The string data to be converted, a variable or constant of type string.
⚫ Function return value: The converted integer data, a variable of type int.
StrToR
The String to REAL data command. This command converts string data to REAL type data and returns the converted real number.
⚫ Parameter 1: The string data to be converted, a variable or constant of type string.
⚫ Function return value: The real data to be converted, a variable of type REAL.
APosToStr
The APOS point data to STRING command. This command converts apos points into strings in the specified format and returns the converted string data. The converted apos point is in the format "0;
1,2,3,4,5,6,0,0,0,0,0,0,0,0,0,0,0;", where the semicolon in front represents the apos point type and coordinate value, respectively.
⚫ Parameter 1: The APOS point data to be converted, a variable of type APOS.
⚫ Function return value: The converted string data, a variable of type string.
CPosToStr
The CPOS point data to STRING command. This command converts cpos points into strings in the specified format and returns the converted string data. The converted cpos point is in the format "1;0,0,0,0,0,0;1,2,3,4,5,6,0,0,0,0,0,0,0,0,0,0;", where the semicolon in front represents the cpos point type, cfg parameter and coordinate value, respectively.
⚫ Parameter 1: The CPOS point data to be converted, a variable of type CPOS.
⚫ Function return value: The converted string data, a variable of type string.
⚫ TranStrToInt
The command to get integer string array. This command splits the string according to the passed split character, converts the split value to an integer one-dimensional array and returns the number of valid splits.
⚫ Parameter 1: The string to be split, a variable or constant of type string.
⚫ Parameter 2: The separator, a variable or constant of type string.
⚫ Parameter 3: The split integer being stored as an array, a variable of type IntOneArray.
⚫ Function return value: The count of successfully split and saved to an array, a variable of type int
⚫ Example:
⚫ P:INT0.value = TranStrToInt("1_2_3er", "_", G:IntOneArray0) // The command passes in the character "1_2_3er", and after execution the system extracts the data by splitting it according to the incoming split character '_'. The split data is stored in the one-dimensional integer array variable IntOneArray0 in the order of 1, 2, 0, and the number of splits 3 is assigned to INT0.value.
TranStrToReal
A command to get an array of REAL strings. This command splits the strings according to the passed splitters and converts the split values into a REAL one-dimensional array and returns the number of valid splits.
⚫ Parameter 1: The string to be split, a variable or constant of type string.
⚫ Parameter 2: The separator, a variable or constant of type string.
⚫ Parameter 3: Store the split REAL type variable as an array, a variable of type RealOneArray.
⚫ Function return value: The count of successfully split and saved to an array, a variable of type int
⚫ Example:
⚫ P:INT0.value = TranStrToReal("1.1_2.2_3er", "_", G:IntOneArray0) // The command passes in the character "1.1_2.2_3er", after execution the system extracts the data by splitting it according to the incoming split character '_'. The split data is stored in the one-dimensional integer array variable RealOneArray0 in the order of 1.1, 2.2, 0 respectively, and the number of splits 3 is assigned to INT0.value.
TranStrToApos
The command to get an array of apos point data strings. This command splits the string according to the passed split character and converts the split value to an apos point variable, while returning a status of whether the conversion was successful or not. The string to be converted must be in the format "0; 1,2,3,4,5,6,0,0,0,0,0,0,0,0,0,0,0;", where the leading semicolon represents the apos point type, the coordinate value, and the last semicolon can be followed by any string.
⚫ Parameter 1: The string to be split, a variable or constant of type string.
⚫ Parameter 2: The separator, a variable or constant of type string.
⚫ Parameter 3: Store the split apos point data as an apos variable, a variable of type APOS.
⚫ Function return value: Return the status of the extraction success or failure, a variable of type int
⚫ Example:
⚫ P:INT0.value = TranStrToApos("0; 21,22,23,24,25,26,0,0,0,0,0,0,0,0,0,0;$qwqewe", "$", G: P0) // The command passes in the characters "0;21,22,23,24,25,26,0,0,0,0,0,0,0,0,0,0,0,0;$qwqewe". After execution, the system will split the extracted data according to the incoming separator '$', and the data after '$' will be discarded. The split data are stored in the order 21, 22, 23, 24, 25, 26... in the order of a1, a2, a3, a4, a5, a6... of P0. and the successful return value 0 is assigned to INT0.value.
TranStrToCpos
The command to get an array of cpos point data strings. This command splits the string according to the incoming separator and converts the split value to an apos point variable, while returning a status of whether the conversion was successful or not. The string to be converted must be in the format "1;0,0,0,0,0,0,0;1,2,3,4,5,6,0,0,0,0,0,0,0,0,0,0,0,0;", with the semicolon preceding the cpos point type, the cfg parameter, and the coordinate value respectively.
⚫ Parameter 1: The string to be split, a variable or constant of type string.
⚫ Parameter 2: The separator, a variable or constant of type string.
⚫ Parameter 3: Store the split apos point data as a cpos variable, a variable of type CPOS.
⚫ Function return value: Return the status of the extraction success or failure, a variable of type int
⚫ Example:
⚫ P:INT0.value = TranStrToCpos("1;0,0,0,0,0,0;21,22,23,24,25,26,0,0,0,0,0,0,0,0,0,0;$qwqewe", "$", G: P0) //
The command passes in the characters "0; 0,0,0,0,0,0,0;21,22,23,24,25,26,0,0,0,0,0,0,0,0,0,0,0,0,0,0;$qwqewe".
After execution, the system will split the extracted data according to the passed splitting character '$', the data after '$' will be discarded. The data after the first ";" will be stored in the cfg parameter in the order of "0,0,0,0,0,0" and the data after the second ";" will be stored in the order of 21, 22, 23, 24, 25, 26... in the order of x, y, z, a, b, c... of P0, and the successful return value 0 is assigned to INT0.value.
5.1.20 ARRAY commands
SetMatrix
Form a parallelogram in space with the specified three points and divide this parallelogram equally according to the set number of rows and columns to obtain a matrix point set.
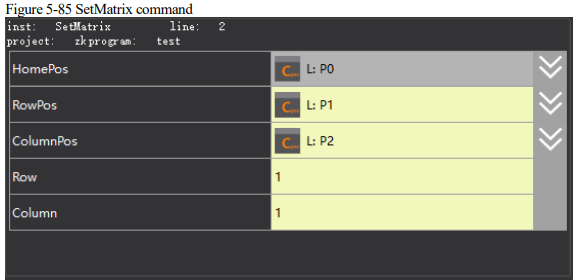
⚫ Origin: Specifies the first point of the parallelogram, of type CPOS.
⚫ Last point in row direction: Specifies the last point in the row direction of the parallelogram, of type CPOS.
⚫ Last point in column direction: Specifies the last point in the column direction of the parallelogram, of type CPOS.
⚫ Number of rows: The number of rows of the generated matrix, a constant, in the range [1,32767].
⚫ Number of columns: The number of columns of the generated matrix, a constant in the range [1,32767].
[Note]
The matrix points generated based on the three points are only operations in the displacement direction, so the posture and additional axis angle values of the generated matrix points are kept the same as the origin (as in P1_Home below):
⚫ If the number of rows is 1 and the number of columns > 1, the line is divided equally according to the number of columns by forming a line based on the origin (as in P1_Home below) and the last point in the row direction (as in P2_Row below), disregarding the last point in the column direction (as in P3_Column below);
⚫ If the number of columns is 1 and the number of rows > 1, the line is divided equally according to the number of rows on the basis of the origin (as in P1_Home below, and the last point in the column direction (as in P3_Column below), disregarding the last point in the row direction (as in P2_Row below);
⚫ If both the number of rows and the number of columns are 1, the origin is used directly (as in P1_Home above);
⚫ The range of rows is [1,32767], the range of columns is [1,32767] and the product needs to be less than 32767.
Example 1:
Divide the quadrilateral formed by P1, P2 and P3 equally in 4 rows and 5 columns.
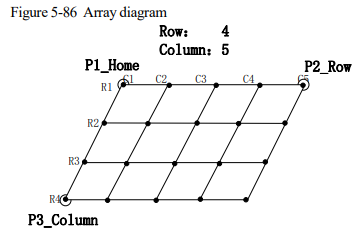
SetMatrix (P1, P2, P3,4,5)
GetMatrix
The value of this point in the corresponding row after executing the SetMatrix command and assigned to the target point. The posture and additional axis angle values of the point as described in SetMatrix remain the same as the origin.
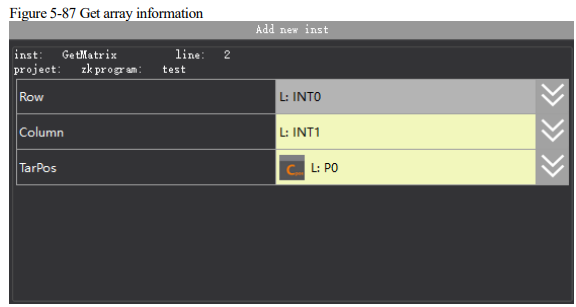
⚫ Number of rows: The row number of the matrix from which the point is to be taken, of type INT.
⚫ Number of columns: The column number of the matrix from which the point is to be taken, of type INT.
⚫ Target point: Used to store the value of the picked point, of type CPOS.
[Note]
The number of rows must be in the range [1,32767], the number of columns must be in the range [1,32767], and the number of rows and columns must be less than or equal to the corresponding values set in the SetMatrix command.
5.1.21 ModbusTCP commands
GetModConState
This command is used to get the status of the robot's connection to the external world using ModbusTCP communication.
⚫ Connection status: Return the current connection status, of type BOOL.
ReadModbusReg
This command is used to read the value of the specified Modbus register
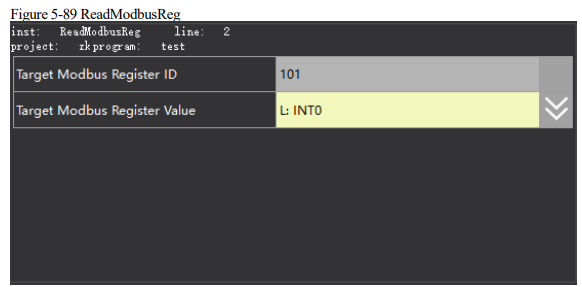
⚫ Target register ID number: The register ID number to be read, of type INT.
⚫ Target register value: Return the value of the register after reading, of type INT.
WriteModbusReg
This command is used to set the value of the specified Modbus register.
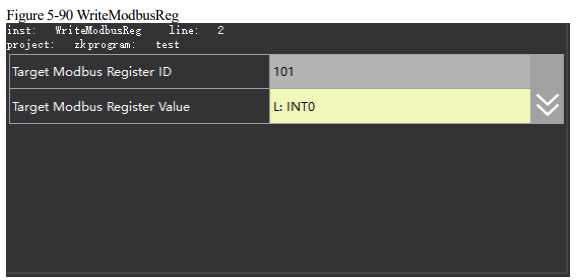
⚫ Target register ID number: The register ID number to be modified, of type INT.
⚫ Target register value: The register value to be modified, of type INT.
5.1.22 MA ELF commands
MA_ELF_START
This command initiates a process to record the effective operational time of the robot, and it does not require any parameters.
MA_ELF_STOP
This command concludes the process of recording the effective operational time of the robot, and it does not require any parameters.
5.2Types of Common Variables
Different types of variables are supported by different domains, which are detailed as follows:
⚫ System Domain: The system predefined variables, which cannot be edited.
⚫ Global Domain: IO data type, PLC data type, socket data type, position data types, area data type, basic data type, weave data type, clock data type, palletizing data type, and system data type.
⚫ Project Domain: IO data type, socket data type, position data types, basic data type, weave data type, pallet data type, and system data type.
⚫ Program Domain: IO data type, socket data type, position data type, basic data type, and system data type.
5.2.1 Basic data types
BOOL
This variable is used to store bool type data. It supports operations such as Create, Delete, and
Modify in the scope of the three major variables: Global, Project, and Program.
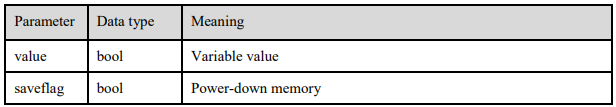
INT
This variable is used to store integers. It supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
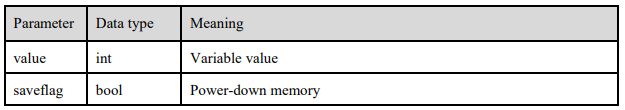
REAL
This variable is used to store real numbers. It supports operations such as Create, Delete, and
Modify in the scope of the three major variables: Global, Project, and Program.
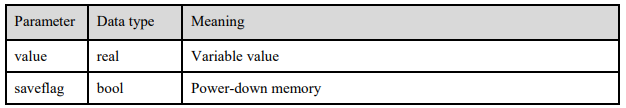
STRING
This variable is used to store character strings. It supports operations such as Create, Delete, and
Modify in the scope of the three major variables: Global, Project, and Program.
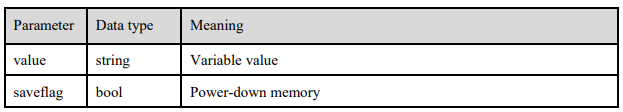
BoolOneArray
This variable is used to store bool type array data. It supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
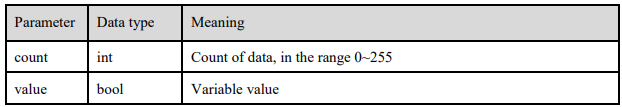
IntOneArray
This variable is used to store the integer array data. It supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
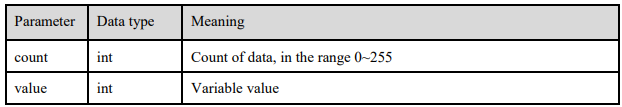
RealOneArray
This variable is used to store the real array data. It supports operations such as Create, Delete, and
Modify in the scope of the three major variables: Global, Project, and Program.
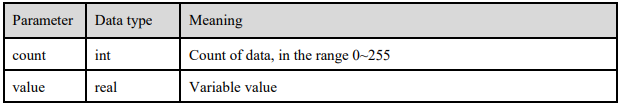
Please note:
⚫ If the last command of the program is an assignment to a power-down memory variable, it may not be saved successfully after execution and a wait period will be required afterwards. Similarly, there is a chance that a single-step pc run on this assignment command will not save successfully.
⚫ If the count of data in an array variable is too large (e.g. count is 200), do not create the variable in the same variable field as a variable with power-down memory enabled. For example, create an INT variable with the power-down memory property in the Global domain, and then create a one-dimensional array variable in the project field.
5.2.2 Position data types
APOS
This variable is used to store the coordinate values of axis in the joint space. It supports users to create and modify independently, and to perform assignment operations and other jobs in the teaching program. Also, it supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
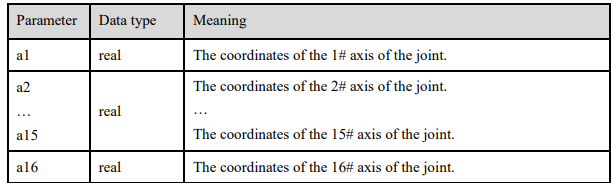
[Note] The number of parameters of axes will be displayed based on the number of axes. For example, the general six-axis robot displays aa1~a6, while the scara robot displays a1~a4.
POSCFG
Robot may have differed joint position combinations under the same Cartesian space position (corresponding to the multiple solutions of the robot inverse solution). This attribute is used to define the morphological configuration data corresponded to the spatial target point.
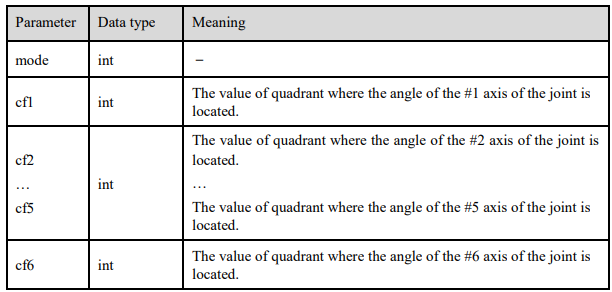
The values of these quadrants are divided as follows:
Non-negative numbers: 0: (-pi,pi], 1: (pi,3pi], 2: (3pi,5pi], ...; 2pi difference between each quadrant
Negative numbers: -1: (-3pi,-pi], -2: (-5pi,-3pi], ...; -2pi difference between each quadrant
① Definition of general-purpose six-joint dynamics mode
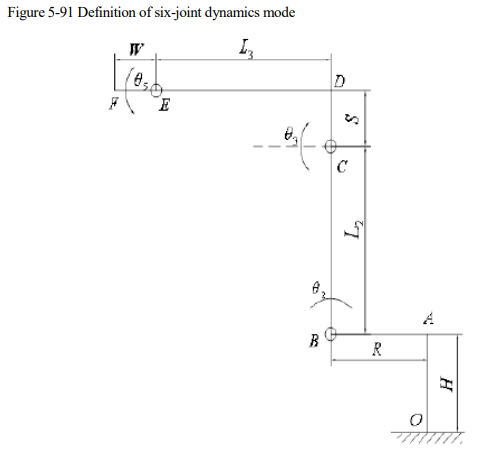
There are eight sets of solutions for the dynamics of the general-purpose six-joint. The mode value is defined as 0~7. The meanings are listed in table below:
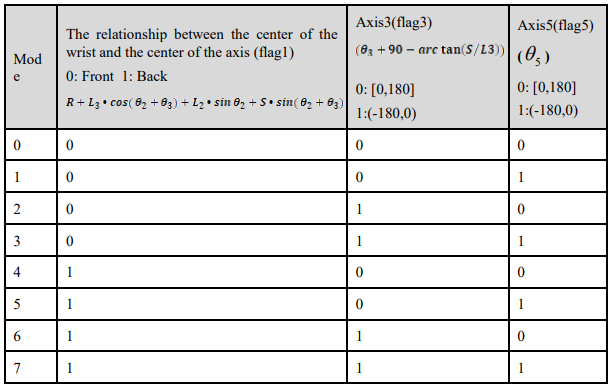
[Note]
⚫ mode = flag5 + 2*flag3 + 4*flag1
⚫ aa, the relationship between the wrist center and the center of the axis is shown in the figure below. Front: refers to the positive direction of x in the figure; Back: refers to the negative direction of x in the figure.
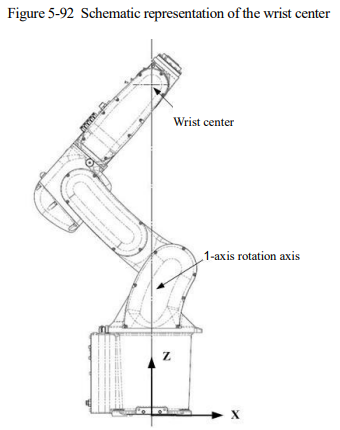
⚫ Meaning of bb, Axis3 (flag3): The second and third axis are on a straight line are taken as the boundary condition. 0 is for forward inclination, and 1 is for backward inclination.
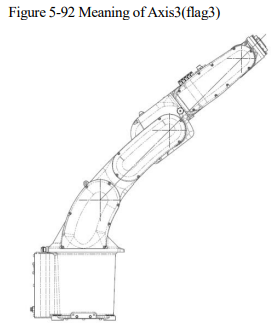
⚫ Meaning of cc, Axis5(flag5): The angle of 5 axes.
②Definition of SCARA dynamics mode
There are two sets of solutions for Scara dynamics. The mode values are defined as 0 and 1, with the meanings listed as follows:
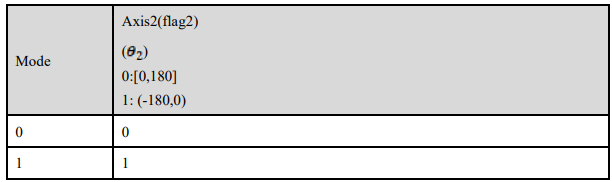
[Note]
mode = flag2
③Definition of 3-axis plane robot dynamics + "3+1" robot mode
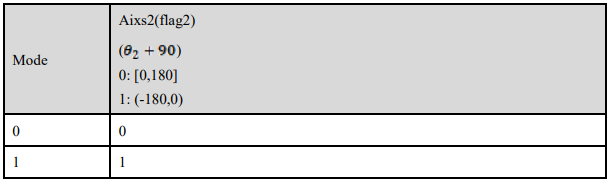
[Note]
mode = flag2
④Definition of SCARA hoisting dynamics mode
There’re two sets of solutions for Scara hoisting dynamics. The mode value is defined as 0 and 1, with the meanings listed below:
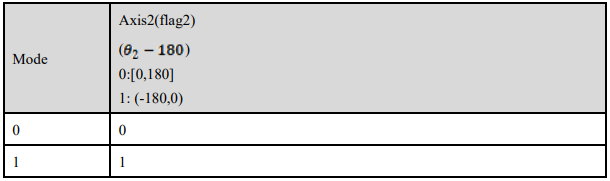
CPOS
This variable is used to store the position of the TCP point in the Cartesian coordinates. It supports users to create and modify independently, and to perform assignment operations and other jobs in the teaching program. It also supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
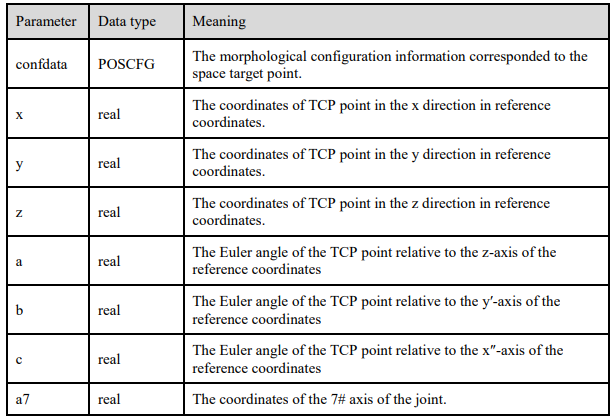
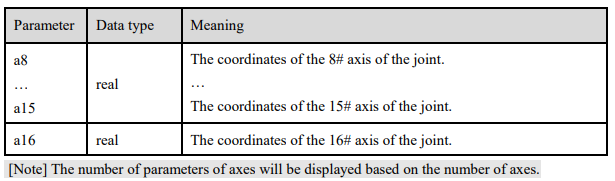
DAPOS
This variable is used to store the relative offset of each axis in the joint space. It supports users to create and modify independently, and to perform assignment operations and other jobs in the teaching program. It also supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
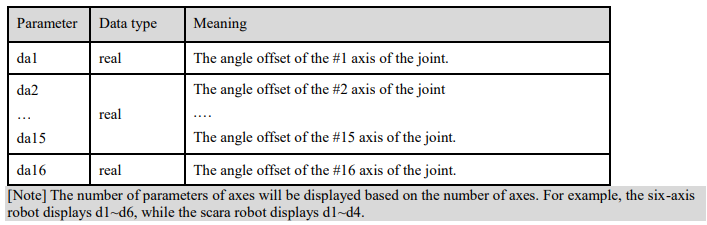
DCPOS
This variable is used to store the relative offset of the TCP point in the Cartesian coordinates. It supports users to create and modify independently, and to perform assignment operations and other jobs in the teaching program. It also supports operations such as Create, Delete, and Modify in the scope of the three major variables: Global, Project, and Program.
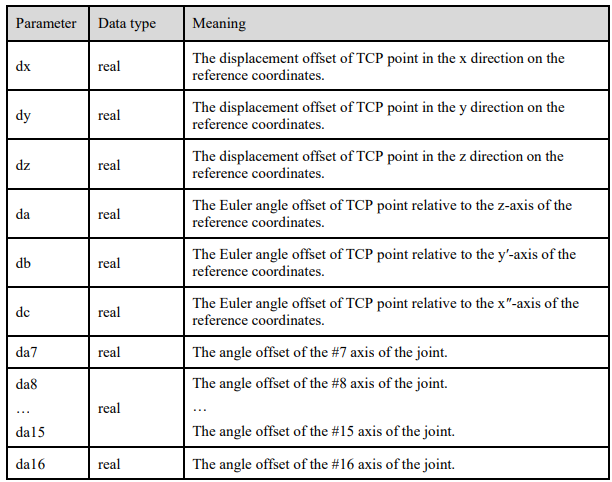
[Note] The number of parameters of axes will be displayed based on the number of axes.
5.2.3 System data types
CenterPos
The center of mass vector is set based on the position of the mounted tool or load on the coordinates OTool-XYZ, which his described below.
The direction of the tool & load mass information reference coordinates is shown in the figure below. Figure below shows the definition example of the tool & load mass information coordinates.
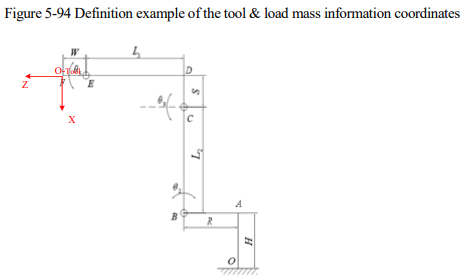
coordinate system OTool-XYZ is located at the end flange plane of the robot, and the Z axis of the coordinate system is coaxial with the axis of the J6 joint (taking 6-axis robot as an example).
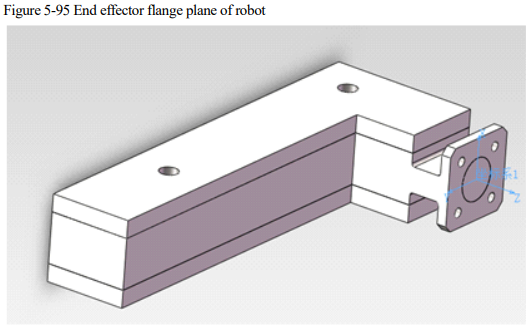
[Note] Please refer to the coordinates OTool-XYZ in Figure 5-1 for the mass information output coordinates of tools and loads.
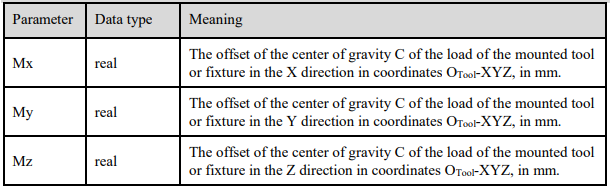
InertiaTensor
This parameter is the inertia tensor determined by the output coordinates Otool-XYZ of the mounted tool or load. For the output coordinate system, refer to the sample of the Figure.
Matrix representation of inertia tensor:
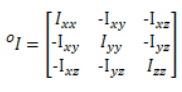
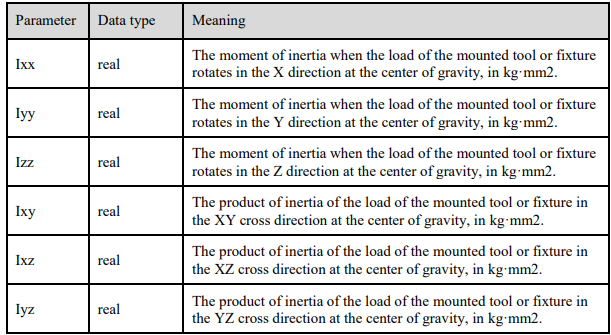
LoadDyn
It is used to store the end tool & load mass parameters of robot, and to calculate the full model of robot dynamics.
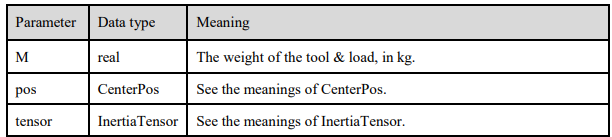
TOOL
The TOOL variable is used to record the tool parameters, and to define the displacement and rotation of the tool end in relation to the robot flange. The parameter can be calculated by the user based on the calibration of the variable interface or can be entered by the user. This variable can only be created and modified in the Global domain.
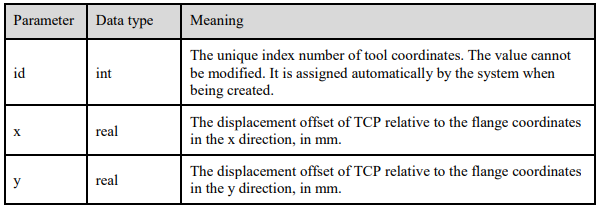
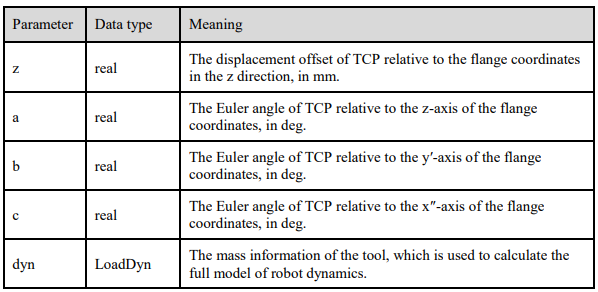
The system predefines the tool variable nullTool, in which the value of each offset is 0 by default.
User can define the tool coordinates to be used on the basis of site requirements.
USERCOOR
The USERCOOR variable is used to record user parameters, and to define the displacement and rotation of the user coordinates relative to the world coordinates. This parameter can be calculated based on the variable interface calibration, or be input by the user. The variable can only be created and modified in the Global domain.
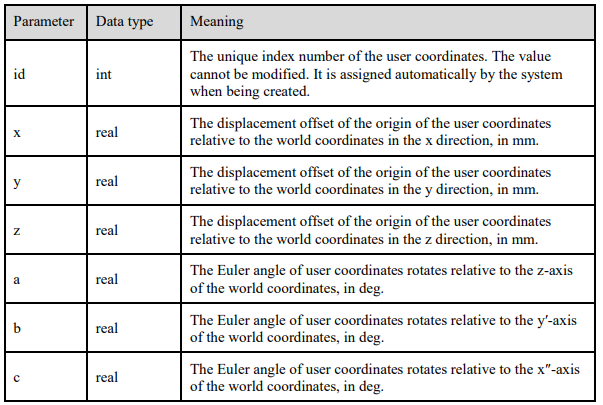
The system predefines the world coordinates World, in which the value of each offset is 0 by default. User can define the user coordinates to be used on the basis of site requirements.
EXTTCP
EXTTCP variable is used to record the parameters of external tool coordinates, and to define the displacement and rotation of the external tool coordinates relative to the world coordinates. The parameter can be calculated based on the variable interface calibration, or be input by the user. This variable can only be created and modified in the Global domain.
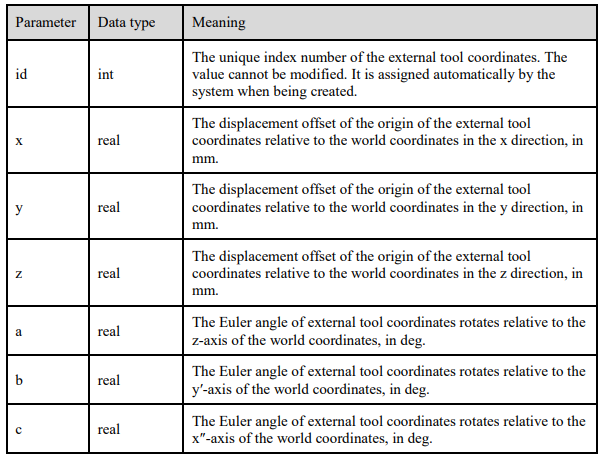
SYNCOORD
The SYNCOORD variable is used to record the parameters of the datum reference coordinates of a moving target object during following, and to define its displacement and rotation relative to the
World Coordinates. The parameters can be calculated by the user based on the calibration of the variable interface or entered by the user.
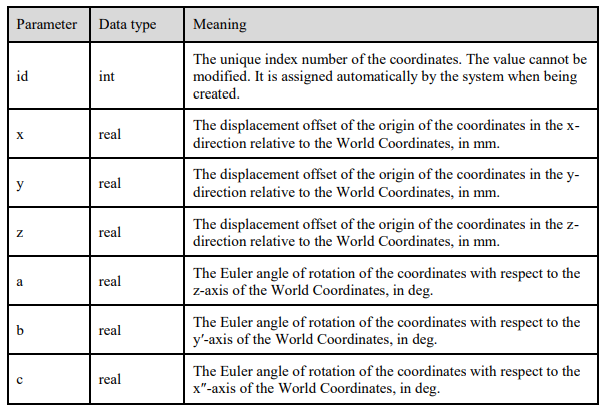
SPEED
It is used to define the motion speed of the robot and the external axis. For easy use, the system presets the common speed variables (system variables, not to be modified by users). It also supports operations such as Create, Delete, and Modify in the scope of the three major variables Global, Project, and Program.
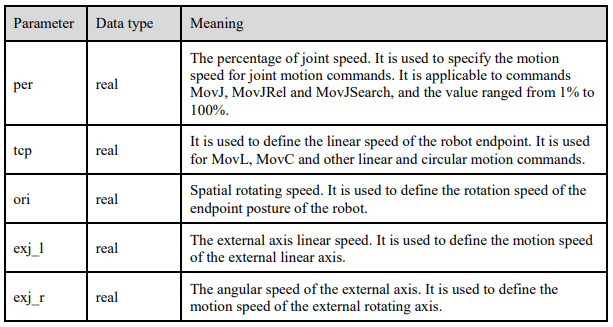
ZONE
It is used to define how a motion ends, or to define the size of the turning area between two motion trajectories. For easy use, the system presets the commonly used transition variables (system variables, not to be modified by the user). It also supports operations such as Create, Delete, and Modify in the scope of the three major variables Global, Project, and Program.
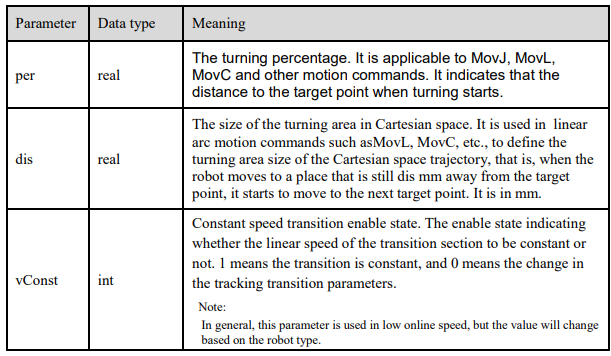
PAYLOAD
The PAYLOAD variable is used to record the workpiece load parameters, and to define the robot end-load parameters and mass information. The use of detailed mass information assists in the full model calculation of the robot dynamics in order to improve the motion tact even more. This parameter can currently only be entered by the user after calculating the value in advance, without a teach pendant calibration calculation. This variable can only be created and modified in the Global domain.
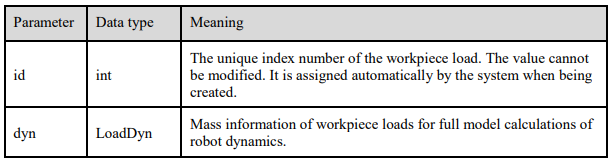
The system has a predefined workload of PAYLOAD0, where the default value for each offset is 0.
The user may define the workpiece parameters to be used according to the site requirements.
POSITIONER
The POSITIONER type variable selects the positioner (ID) by index.
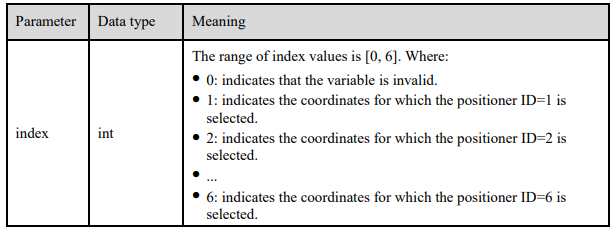
[Note]
See "Functions of positioner" for calibration of the indexing positioner coordinates.
LsScale
The LsScale variable is used to record the gain ratio threshold parameter for each joint axis to improve the low speed jitter in a certain speed range and is used in conjunction with the speed range threshold parameter. Setting range: [100,1000], in %. This variable can only be created and modified in the Global domain.
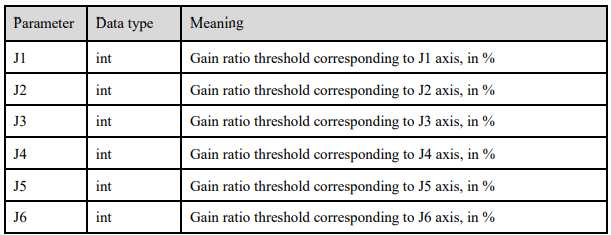
LsThresh
The LsThresh variable is used to record the speed interval threshold for each joint axis to improve low speed jitter in a certain speed interval and is used in conjunction with the gain ratio threshold parameter. The range is [10,1000], in r/min. This variable can only be created and modified in the Global domain.
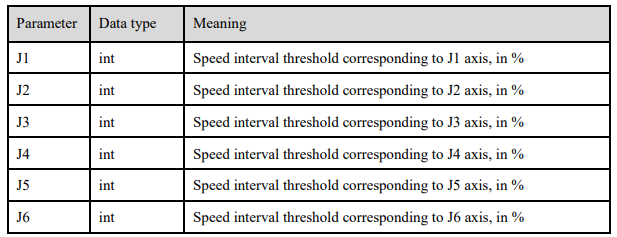
5.2.4 IO data types
DI
The digital input variable.
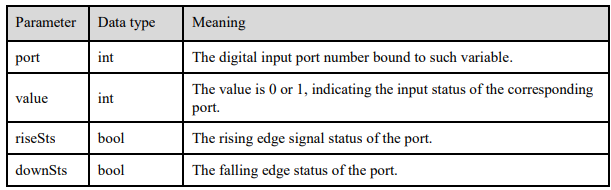
DO
The digital output variable.
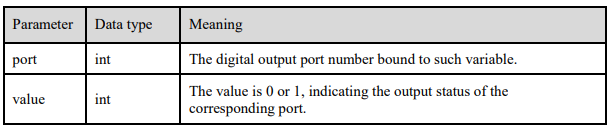
AI
The analog input variable.
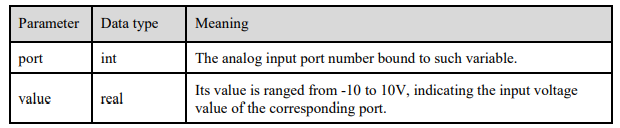
AO
The analog output variable.
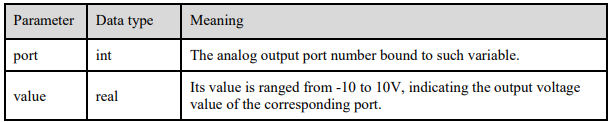
SimDI
The virtual analog input variable.
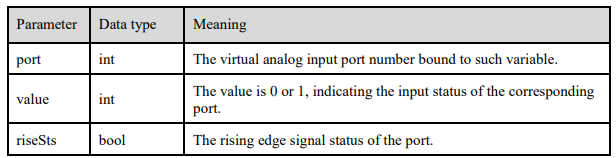
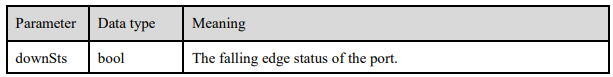
SimDO
The virtual analog output variable.
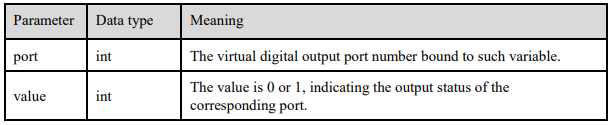
SimAI
The virtual analog input variable.
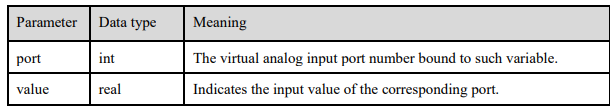
SimAO
The virtual analog output variable.
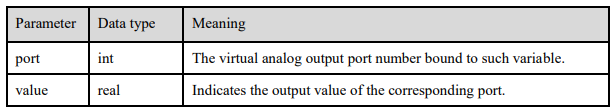
5.2.5 Weave data type
WEAVE
This variable is used to store some configuration parameters when the robot weaves on a straight line/arc trajectory. Also, it allows users to Create, Delete, Modify and other operations in the three variable scopes Global, Project, and Program.
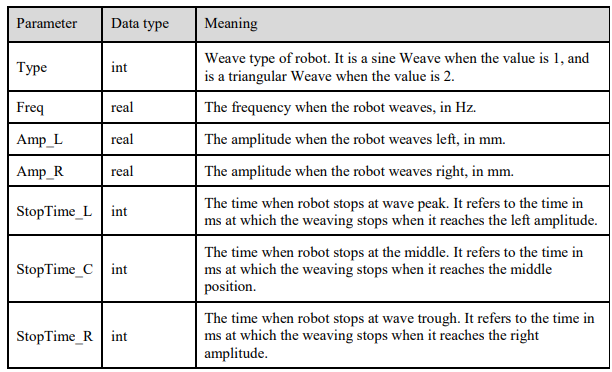
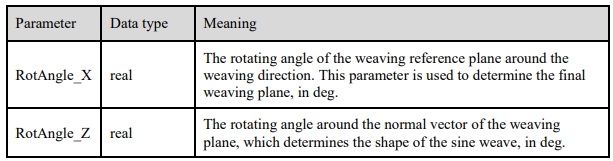
Caution:
⚫ The normal vector of the plane determined by the motion path and the Tz direction of tool coordinates, and the plane formed by the motion path is the reference plane for weaving.
⚫ The function of RotAngle_Z is in the figure below: it is indicated by a solid line if RotAngle_Z=0 is a solid line, and a dotted line if it is not 0.
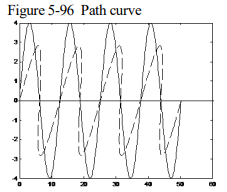
5.2.6 Clock data type
CLOCK
It is used to store the value of the clock information. It supports only the operations such as Create, Delete and Modify in the Global domain.
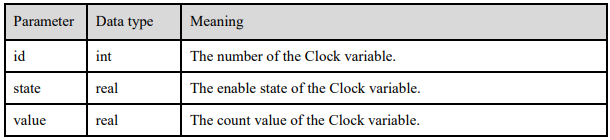
5.2.7 Area data type
AREA
It is used to store the value of Area information. It supports only the operations such as Create, Delete and Modify in the Global domain.
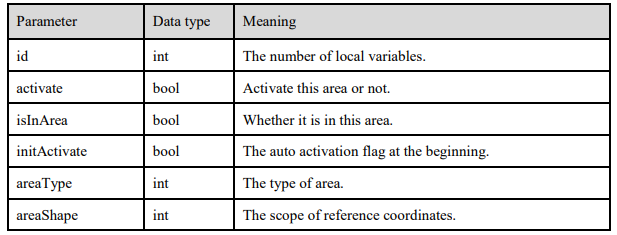
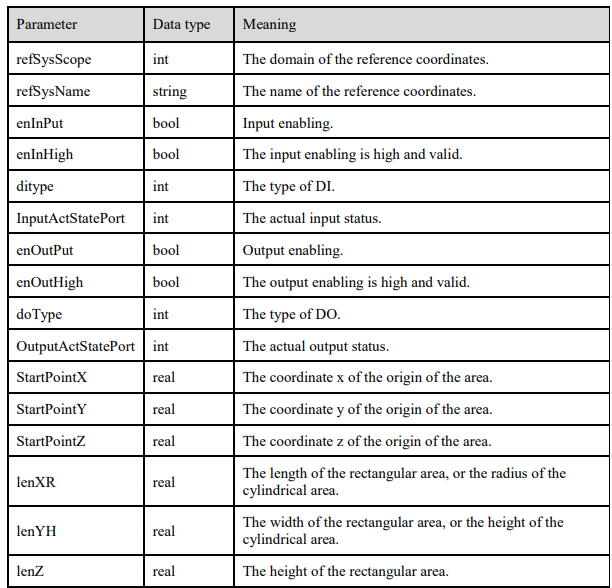
POLYHEDRON
The POLYHEDRON variable selects the polyhedron region (ID) by index. It supports only the operations such as Create, Delete and Modify in the Global domain.
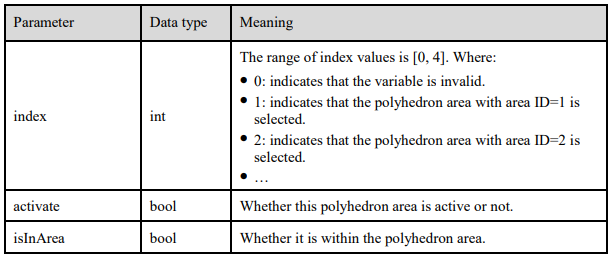
5.2.8 PLC data type
PLCREAL
It is used to store PLC real number, which correspond to real variables on the plc side according to the data number. It supports only the operations such as Create, Delete and Modify in the Global domain.
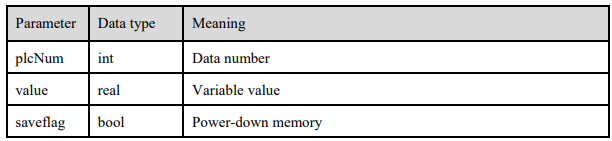
PLCBOOL
It is used to store PLC boolean values, which correspond to bool variables on the plc side according to the data number. It supports only the operations such as Create, Delete and Modify in the Global domain.
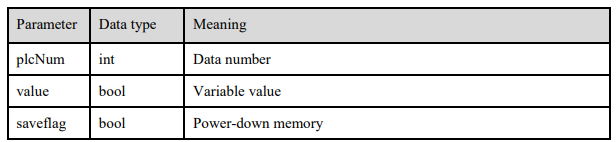
PLCINT
It is used to store PLC short integer data according to the data number corresponding to the int variable on the PLC side. This variable only supports operations such as Create, Delete, and Modify in the global variable scope.
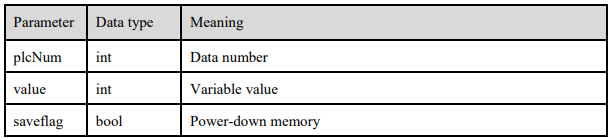
PLCDINT
It is used to store PLC short integral values, which correspond to dint variables on the plc side according to the data number. It supports only the operations such as Create, Delete and Modify in the Global domain.
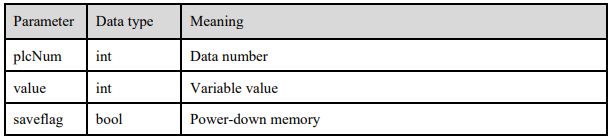
5.2.9 Pallet data type
PLACEOPTIONS
The information contained in the pre-place and the post-place points in the Pallet variable. This data type can only be used together in a way being nested in the Pallet data type.
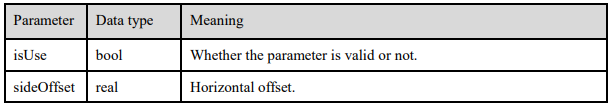
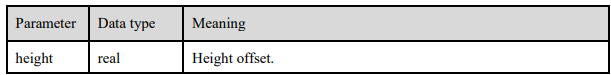
PALLET
It is used to store the Pallet information. This variable allows users to create and modify independently. It supports operations such as Create, Delete, and Modify in the scope of Global and Project variables.
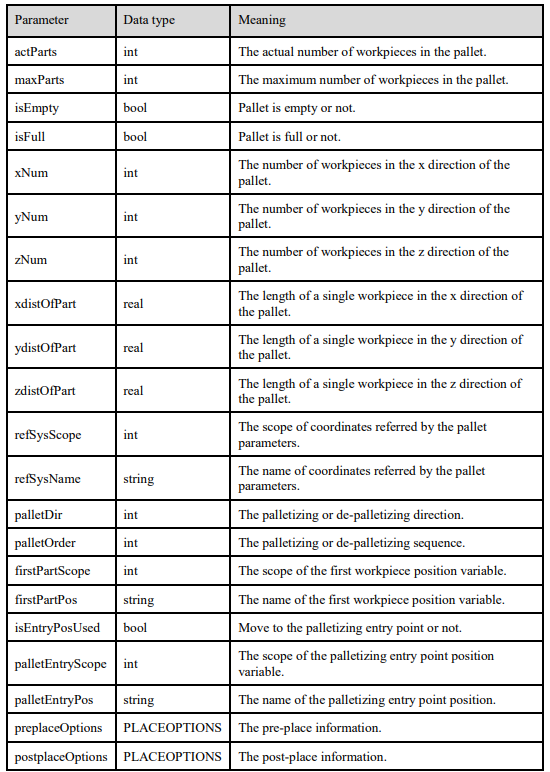
5.2.10 SOCKET data type
Socket
It is used to store Socket name information. This variable allows users to create and modify independently. It supports operations such as Create, Delete, and Modify in the scope of Global, Project and Program variables.
5.3 Quick Programming Function
5.3.1 Quick insertion commands
The teach pendant currently supports quick insertion functionality for the following commands:
MovJ, MovL, MovC, ARC_SET, ARC_Circ, ARC_Line, ARC_ON, ARC_OFF
Quick keys are deployed in the quick command area:
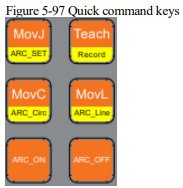
To use the quick insertion command feature, ensure that the cursor is positioned on the End line or any other command line (not on the Start line) in the program interface. Then, perform one of the following two actions:
⚫ Press the MovJ, MovC, MovL, ARC_ON, or ARC_OFF key directly to insert the corresponding MovJ, MovC, MovL, ARC_ON, or ARC_OFF command with the parameters from the last recorded data;
⚫ Press the combination key Fn + MovJ, MovL, or MovC to insert the ARC_SET, ARC_Circ, or ARC_Line command with parameters from the last recorded data.
5.3.2 Quick recording commands
When users are using quick commands for the first time or need to save the parameters set for the current quick command, they can use this command. The system will save the command data to the controller. The next time you use the quick insert command for this command, it will automatically populate the saved data, eliminating the need for parameter setup again and improving programming efficiency.
When users need to use the recording function, simply press the combination key Fn + "Teach/Record"  key on the teach pendant. If the recording is successful, the bottom status bar will display "Recording Successful - Write INI Success!" Otherwise, it will show "Recording Failed - Write INI Fail!"
Commands that can be used with the quick recording function include:
MovJ, MovC, MovL, ARC_ON, ARC_OFF, ARC_SET, ARC_Circ, ARC_Line
5.4Program point teaching
5.4.1 Confirmation of emergency stop
Before operating the robot, press the E-stop button on both the electrical cabinet and the programming pendant to confirm whether the servo power is cut off
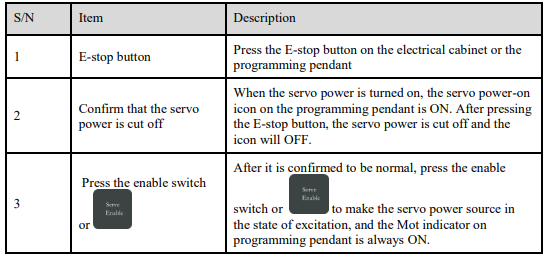
5.4.2 Teaching mode and safety assurance
For safety purposes, it is imperative to rotate the mode knob on the teach pendant to the manual mode when teaching. Once the mode knob is in the manual mode position, in the event of an accidental operation, the safety switch will be firmly gripped due to the human instinctive response.
The safety switch is a two-stage switch; when pressed to the second stage, the servo power will be disconnected.
5.4.3 Preparation for teaching
Perform the following tasks before starting to teach.
⚫ Check the electric control cabinet and the main unit, for example, if the power cord, servo port and controller port of the control cabinet are properly connected, and if there are foreign objects on the main unit.
⚫ Start the electric control cabinet and confirm that all parts are in proper working condition. (For details, please refer to the “Control Cabinet”)
⚫ Turn on the main power of the servo, and test the E-stop keys on the electric control cabinet and the programming pendant.
⚫ Turn the mode switch on the programming pendant to teaching mode.
⚫ Press the manual switch at this time to perform the axis operation using the axis operation keys (for the axis motion corresponded to the Axis Operation Key, refer to the Robot Coordinates).
5.4.4 Basic steps for teaching
Step 1: Start Position
Move the robot to a safe work position away from surrounding objects, and enter Step 1.
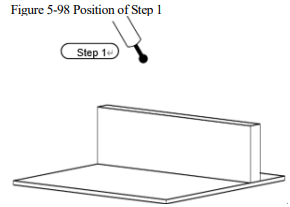
Step 1 Grip the enable switch, and move the robot to the start position using the Axis Operation Keys. Set the starting position at a safe position suitable for job preparation.
Step 2 Press the "Create" button in the job interface, and select "Motion Command→MovJ" from the list.
Step 3 Click "OK" to enter the command editing interface of MovJ, as shown in figure below.
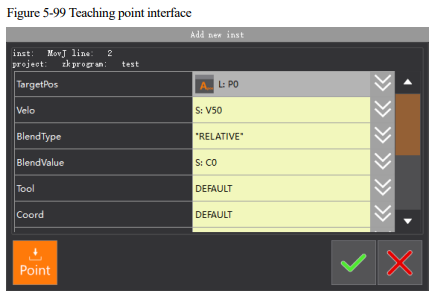
Step 4 After clicking "Teach", Point P1 records the robot sitting posture at Step 1 by this moment. Step 1 is taught after clicking "Insert", and the commands displayed in the program interface are as follows:
MovJ (P1, V50, “RELATIVE”, C0)
Step 2: Near the Work Start Position
Make the robot in the work posture using the Axis Operation Keys. Teach step 2 by utilizing the method of teaching step 1: starting position. The program commands are as follows upon teaching:
MovJ(P2, V50, “RELATIVE”, C0)
Step 3: Work Start Position
Move the robot to the work start position (Step 3) with the pose as shown in Step 2.
Step 1 Keep the posture of Step 2 the same. Set the robot coordinate system to a Cartesian Coordinates, and move the robot to the starting position of the job using the Axis Operation Keys.
Step 2 Press "Create" in the job interface, to enter the command interface and select the linear interpolation command.
Step 3 Click "Teach" or press the "Teach" button on the teach pendant to have the teaching of Step 3 done. The program commands are as follows.
MovL(P3, V50, “RELATIVE”, C0)
Step 4: Work End Position
Specify the work end position
Move the robot to the work end position with the Axis Operation Keys. While the robot is moving from starting position to the end position, keep a wide enough distance to ensure it will not strike the workpiece.
Use the method in the same way as the teaching Step 3 by adding a linear interpolation command. P4 is the sitting posture of the robot at Step 4. The program commands are detailed as follows.
MovL(P4, V50, “RELATIVE”, C0);
Step 5: Position Away from Workpiece and Fixture
Move the robot to a position where it will not strike the workpiece or fixture.
Move the robot with the Axis Operation Keys to a position where it will not strike the fixture. Use the method in the same way as the teaching Step 3 by adding a linear interpolation command. P5 is the sitting posture of the robot at Step 5. The program commands are detailed as follows:
MovL(P5, V50, “RELATIVE”, C0);
Step 6: Near the Start Position
Move the robot with the Axis Operation Keys to a position near the start position in the Joint Coordinates. Use the method in the same way as the teaching Step 2 by adding a linear interpolation command. P6 is the sitting posture of the robot at Step 6. The program commands are detailed as follows:
MovJ(P6, V50, “RELATIVE”, C0);
Ensuring the First and Last Step are Identical
The robot has stopped at Step 6, which should be very close to Step1. It is possible to move directly from the welding end position of Step 5 to Step1, so that the robot can begin the next welding job quickly and efficiently.
The following operation will make Step 6 (end position) and Step1 (start position) identical.
Step 2 Move the cursor to Step 1; click "Set Pointer" button, press "Step" to select the single-step mode. After setting the speed within 10%, press "Start" and the program starts to run, then move the robot to Step 1.
Step 3 Move the cursor to Step 6. After pressing "Modify", the modification interface appears.
Step 4 Press “Teach” or the "Teach" key on the teach pendant. This will change the position of Step 6 to be the same as Step1.
5.4.5 Path confirmation
The job is now complete. Please run the next job, and try to check each step separately to ensure there are no problems. When confirming the path, make sure that the programming pendant is in the teaching mode, and the enable switch is pressed at time of motion.
Step 1 Move the cursor to Step 1, and click “PC” or the "OK" key on the teach pendant.
Step 2 Choose the single-step mode.
Step 3 Press the speed increase and decrease keys to set the speed within 10%.
Step 4 Press the enable switch, and the robot servo enables.
Step 5 Press , and the program starts operation in single-step mode. The robot runs a command program each time you press.
Step 6 When you finish step confirmation, move the cursor to the beginning of the job.
Step 7 Finally, run all the steps continuously. After pressing , the robot plays back all the steps continuously and stops when one cycle is finished.
[Note]
When running a path in teaching mode, the trajectory speed is limited by the national standard speed, with a maximum linear speed of 250mm/s and a maximum posture speed of 180deg/s.
5.4.6 Modifying a step
If the actual robot trajectory differs from the expected one, the robot's trajectory can be adjusted by modifying the step position and speed in a program.
Before modification
Confirm the robot’s motion in each step. If any position modification or adding or deleting of steps is necessary, edit the job content by following the procedures below.
Step 1 Enter the Project Management interface.
Step 2 Select the job to be edited.
Step 3 Click "Load" or the "OK" key on the teach pendant to enter the job editing interface
Changing the Position Data of the Step
Change the position registered in Step 2
Step 1 Using the above method, set it to single-step mode set the speed within 10%, and press  to move the robot to Step 2 to be modified. The robot moves a step by pressing the
 once.
Step 2 Move the robot to the modified position with the Axis Operation Keys, as shown in the new Step 2 in figure above.
Step 3 Press “Modify” or the Modify command key on the teach pendant to enter the point correction interface.
Step 4 Press “Teach” or the “Teach” key on the teach pendant. The step’s position data is changed.
Adding a Step
Try to add a new step between Step 5 and Step 6.
Step 1 Move the robot to Step 6 by pressing  . Make sure that the robot can move to position 6 from the current position without collision before moving.
Step 2 Move the robot to the position at which you wish to add a step using the Axis Operation Keys.
Step 3 Move the robot near the start position, and add a joint interpolation command with reference to the “Adding Step 6”.
Deleting a Step
Try to delete the step you just added. Return to the state on the original right picture from the state on the right picture below.
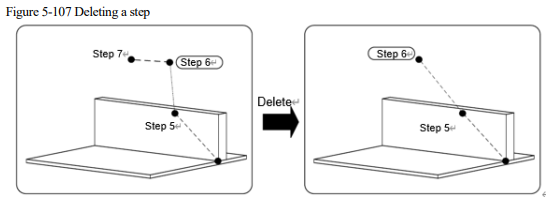
Enter the job editing interface; click the command to be deleted; then click "Delete" on the right or press the Fn+ Delete a Command key on the teach pendant, and "OK" in the "Delete a Command” prompt box.
5.5Program Status Settings
The status of a program includes both the program's operating mode and its execution sequence.
5.5.1 Program running mode settings
The program's operating modes include Single-Step Mode and Continuous Mode.
Step 1: In Single-Step Mode, each time the user presses and holds the "Start" button, the robot's program executes one step either downward or upward in the program sequence.
Step 2: In Continuous Mode, the teach pendant's control mode must be set to Playback (Auto). In this mode, when the user presses the "Start" button in the usual manner, the system will execute continuously from the current program pointer position, moving either downward or upward in the program sequence. It will continue until the program reaches a boundary line (such as the Start line or End line) or until the user presses the "Stop" button to halt the program's execution.
If the user wishes to switch between these program operating modes, they can simply press the "Single-Step/Continuous" button on the teach pendant. The status indicator for the operating mode on the teach pendant's interface will toggle between Single-step and loop modes
5.5.2 Program running sequence settings
The sequence of operation for the program can be set in either forward or reverse order:
⚫ Typically, the robot program runs in forward order using the teach pendant, starting from the "Start" line and progressing to the "End" line. During this mode, the run mode indicator on the display shows as .
⚫ When the control mode switches to teaching (manual) mode, and the current and target command are basic motion commands, the program will run in reverse order. In this case, it runs by decrementing line numbers. During this mode, the run mode indicator on the display shows as .
If the user wishes to change the program's order of operation, simply press the "Reverse/Forward" button on the teach pendant. This action toggles the run mode status indicator on the teach pendant interface between "Forward" and "Reverse".
5.6 Program execution and termination
To execute a section of a program without errors:
⚫ In Manual (Teach) mode, with the run mode set to single step and the execution sequence set to forward, press and hold the "Start" key. The program will execute one line from the current pointer position.
⚫ In Manual (Teach) mode, with the run mode set to continuous and the execution sequence set to forward, press and hold the "Start" key. The program will execute continuously from the current pointer position.
⚫ In Auto (Playback) mode, with the run mode set to single step and the execution sequence set to forward, press and hold the "Start" key. The program will execute one line from the current pointer position.
⚫ In Auto (Playback) mode, with the run mode set to continuous and the execution sequence set to forward, press the "Start" key. The program will execute continuously from the current pointer position.
⚫ In Auto (Playback) mode, with the run mode set to continuous and the execution sequence set to forward, press the "Stop" key to terminate program execution.
5.7Program playback
5.7.1 reparation before playback
The program after the teaching execution is called Playback. Before playback, make sure that the following is done:
Step 1 Make sure that the operator and other staff are outside the working envelope of robot prior to re-operation.
Step 2 Make sure that the E-stop keys on the electric control cabinet and the programming pendant are in an invalid state.
Step 3 Load the project file for playback.
Step 4 Select the program to be executed first, and then click "PC" to ensure that the program is executed from the first line.
Step 5 Press the speed increase or decrease key to set the speed to the desired.
5.7.2 Playback procedure
Step 1 Set the mode knob on the programming pendant to Auto mode, and move the cursor to the beginning of the program.
Step 2: Power on the main source, enable servo function, and connect servo power.
Step 3: Press the "Start" button. The robot will execute the playback program for one cycle and then stop.
5.7.3 Stop and restart
Causes for stopping the robot in motion or enabling the robot to stop automatically are detailed as follows:
⚫ Stop operation or emergency stop temporarily
⚫ Stop by alarm
⚫ Other stops
⚫ Stop by the operations
Pause
⚫ Stops using the programming pendant
Pause
Press  on the programming pendant, and the robot stops.
Release
Press  on the programming pendant. The robot restarts its operation from the position where
it was stopped.
⚫ Stops using an external input signal (system input)
Pause
Turn ON the PAUSE signal from an external input. The robot stops temporarily.
Release
Press the start signal on an external control device. The robot restarts its operation, beginning from the position where it was stopped.
 Caution
When the program is halted, it will automatically go to the stop state when the following operations are performed:
⚫ Program context changes, such as project loading/deregistration, command addition, deletion, etc.
⚫ Setting up the PC
⚫ Switch system mode
⚫ End
⚫ Jog operation
⚫ Homing operation
⚫ Operation of some other system settings
Emergency Stop
An emergency stop can be performed by using either of the following:
⚫ Programming pendant
⚫ Electric control cabinet
⚫ External input signal (system input)
[E-STOP] Power off the robot by pressing the E-stop button of the programming pendant or control cabinet, and the robot stops immediately.
[Release] Turn the E-stop button in the direction of the arrows. Then press the Servo Enable key and power on the servo.
Restart after Emergency Stop
 Warning
Prior to restarting after an emergency stop, confirm the position by clicking and make sure there is no interference with the workpiece or fixture.
The application of an emergency stop during high speed operations on continuous steps can result in the robot stopping two or three steps prior to the step that is being displayed. There is a risk of interference with the workpiece or fixture when the robot is restarted under such conditions.
Stop by Alarm
If an alarm occurs during operation, the robot stops immediately and the Alarm window appears on the programming pendant indicating users can enter the system log interface to view the detailed alarm.
⚫ Alarm Release
Alarms can be categorized into two main types: minor fault alarms and major fault alarms.
⚫ Minor Fault Alarms
Select "Clear Alarm" on the teaching programmer's alarm screen, to resolve and remove the alarm status.
⚫ Major Fault Alarms
Cut off the main power sourceand address the factors causing the alarm.
Others
⚫ Temporary stop by mode change
⚫ When the playback mode is switched to the teach mode during playback, the robot stops immediately. To restart the operation, return to the playback mode and perform a start operation.
⚫ Stop arising from the execution of PAUSE command
⚫ Execute the PAUSE command to pause the robot. When resuming the motion, perform the startup operation, and the robot will continue the motion from the next command.
5.7.4 Modifying playback speed
Users can modify the playback speed by means of the speed increase or decrease keys in the following way:
⚫ Speed can be modified during playback.
⚫ Speed can be changed experimentally, and modification can be performed when the actions are determined.
5.8Programming Considerations
When writing a program, it's important to keep the following considerations in mind:
⚫ When inserting the first line of instructions into a blank program file, make sure to move the program cursor to the "End" line first;
⚫ When using the MovH command, avoid having the intermediate program point too close to the target program point;
⚫ When teaching program points, take into account the maximum limits of each robot joint;
⚫ Using the MovJ or ARC_Line command between ARC_Circ and ARC_CW commands, whether before or after them, will result in an error. It is advisable to use MovL command in such cases;
⚫ No transition should be added between MovJ and MovL.