
2. CONNECTION WITH THE CONTROLLER
Connection cable between robot and control unit. Connect each cable to the connector on the back of the chassis.
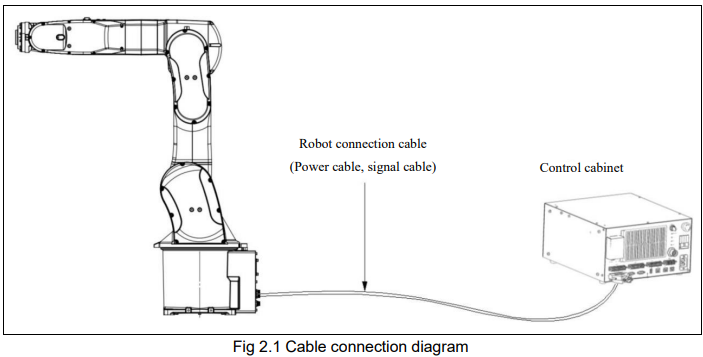
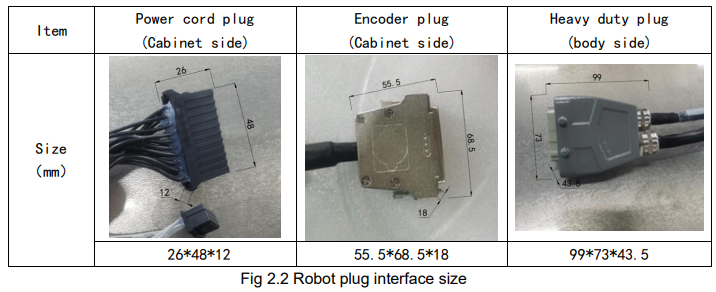
Connection cable between robot and control unit. Connect each cable to the connector on the back of the chassis.