3. Wiring and Connecting
3.1 Precautions for Wiring
3.1.1 General Precautions
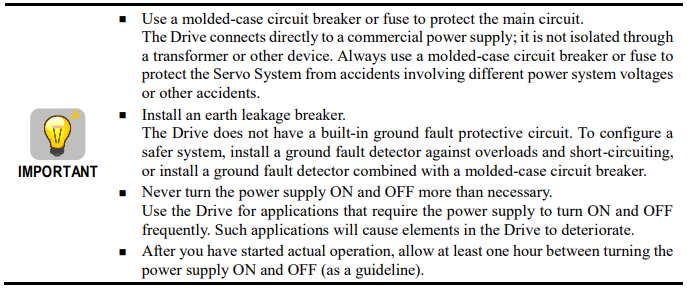
3.1.2 Countermeasures against Noise
Since the Drive uses microprocessors, it may be affected by switching noise from peripheral devices.
To prevent the noise from the Drive or the peripheral devices from causing malfunctions of any devices, take the following countermeasures against noise as required.
Install the input reference device and Noise Filter as close to the Drive as possible.
Always install a Surge Absorber for relays, solenoids, and Magnetic Contactor coils.
Never place the following cables in the same duct or bundle them together. Also, separate the cables from each other by at least 30 cm.
Never share the power supply with an electric welder or electrical discharge machine. If the Drive is placed near a high-frequency generator, install Noise Filters on the input side on the Main Circuit Power Supply Cable and Control Power Supply Cable even if the same power supply is not shared with the high-frequency generator. Refer to the section Noise Filters for information on connecting Noise Filters.
Implement suitable grounding measures. Refer to the section 错误!未找到引用源。Grounding for information on grounding measures.
Noise Filters
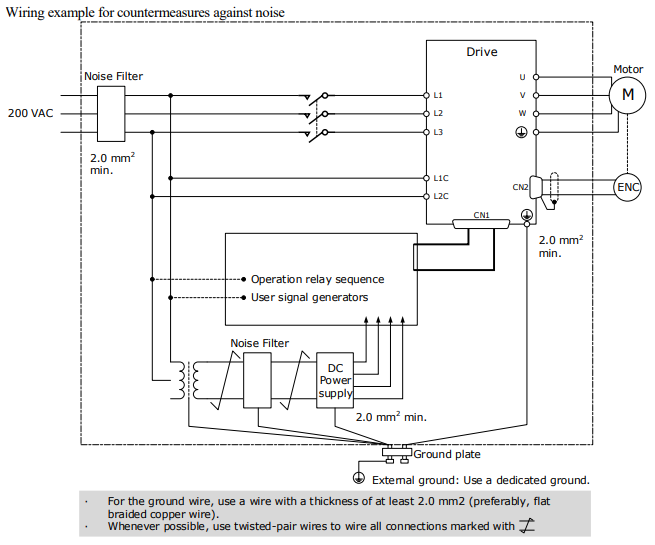
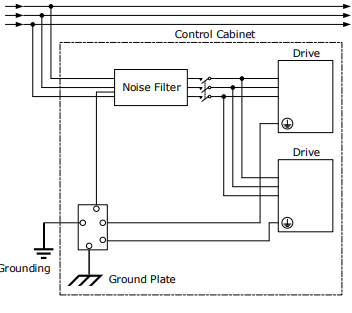
You must attach Noise Filters in appropriate places to protect the Drive from the adverse effects of noise. 0 is an example of wiring for countermeasures against noise.
Noise Filter Wiring and Connection Precautions
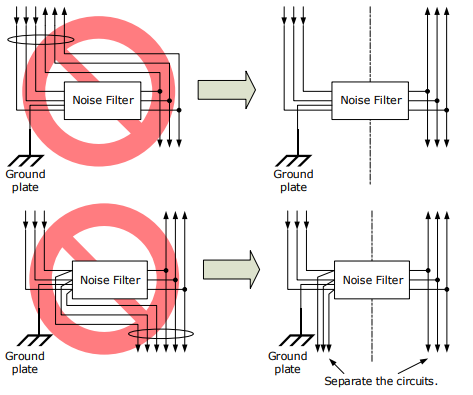
Always observe the following precautions when wiring or connecting Noise Filters.
Separate input lines from output lines. Do not place input lines and output lines in the same duct or bundle them together.
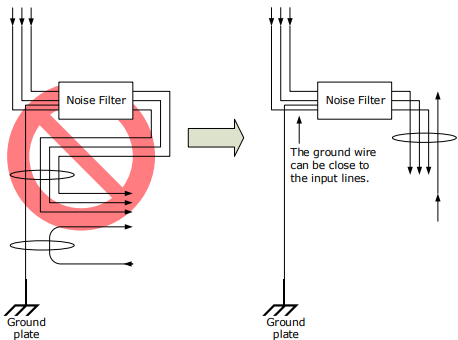
Separate the Noise Filter ground wire from the output lines. Do not place the Noise Filter ground wire, output lines, and other signal lines in the same duct or bundle them together.
Connect the Noise Filter ground wire directly to the grounding plate. Do not connect the Noise Filter ground wire to other ground wires.
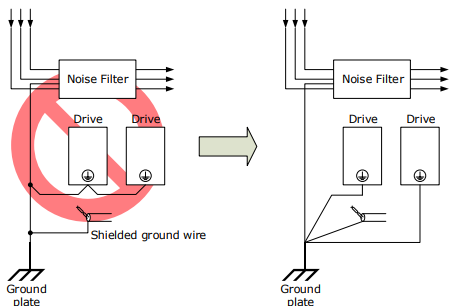
If a Noise Filter is located inside a control panel, first connect the Noise Filter ground wire and the ground wires from other devices inside the control panel to the grounding plate for the control panel, then ground the plate.
3.1.3 Recommended EMC Filters
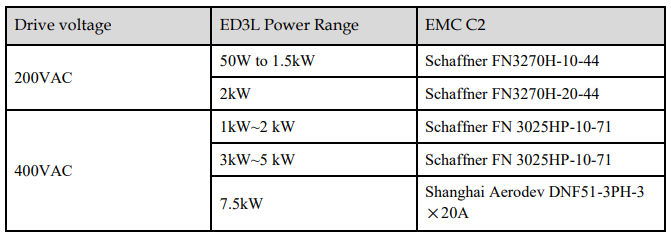
To comply with the limits based on IEC/EN 61800-3 second environment (C2) the Drive and Motor must be installed with an EMC/RFI filter. Recommended filters are:
NOTE
These filters have been tested with cable lengths of 3m and 20m.
3.1.4 Grounding
Implement grounding measures as described in this section. Implementing suitable grounding measures will also help prevent malfunctions, which can be caused by noise. Always use an unpainted backplane for electrical cabinets.
Ground the Drive to a resistance of 100 mΩ or less.
Be sure to ground at one point only.
Ground the Motor directly if the Motor is insulated from the machine.
Motor Frame Ground or Motor Ground
If the Motor is grounded thought the machine, the switching noise current can flow from the main circuit of the Drive through the stray capacitance of the Motor. To prevent this always connect the Motor frame terminal (FG) or ground terminal (FG) of the Motor to the ground terminal  on the Drive. Also, be sure to ground the ground terminal
 .
Noise on I/O Signal Cables
To prevent noise entering the I/O Signal Cable connect the shield of the I/O Signal Cable to the connector shell and ensure the shell is connected to ground. If placing cables in metal conduits, ensure the conduit is connected to ground. For all grounding, use a single grounding point.
Cable Fixing
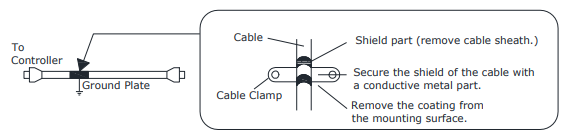
It is recommended that all cable shields are secured with a conductive metal clamp to the ground plate.
Ferrite Coils
While ferrite coils can be used to solve application specific EMC issues, they should not be necessary for applications.
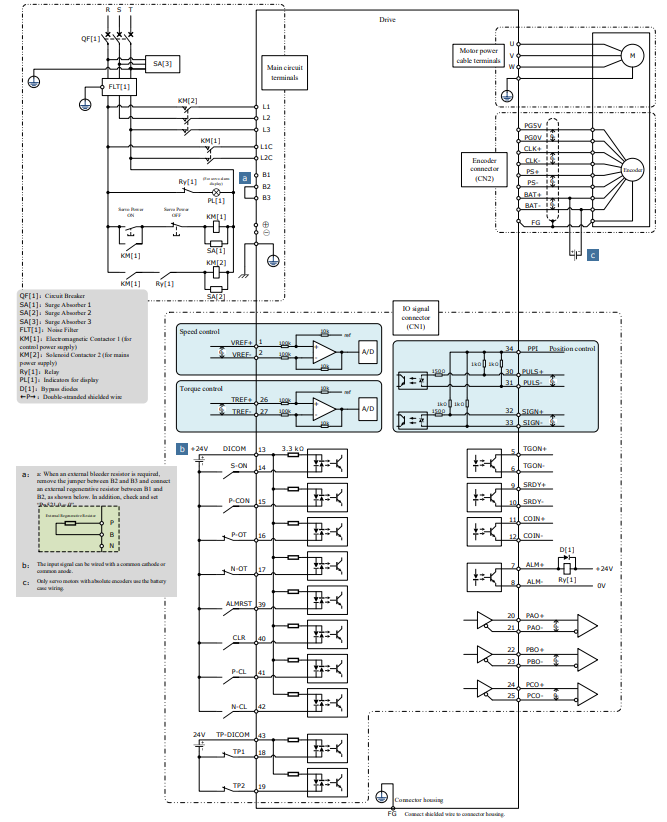
3.2 Basic Wiring Diagrams
Rated power from 50W to 400W
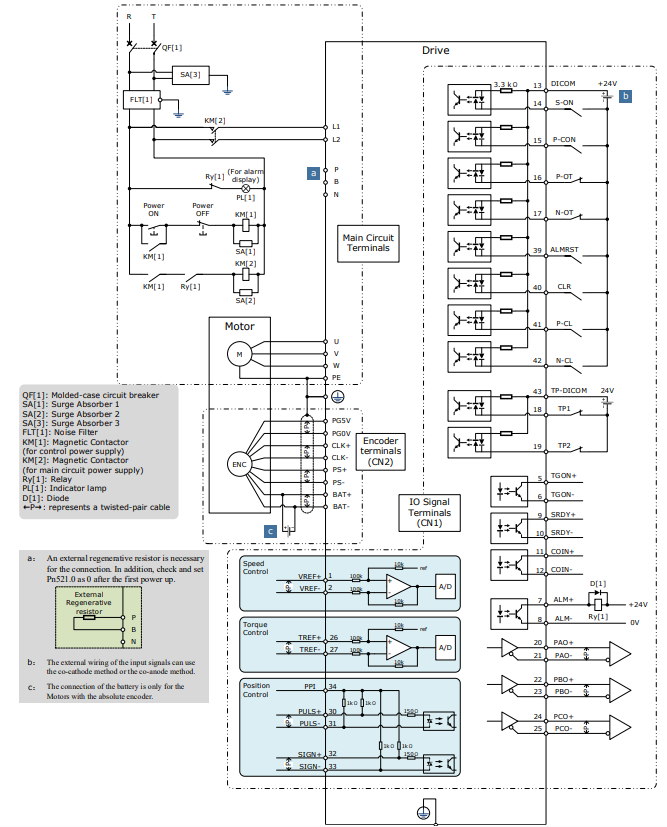
Rated power from 750W to 2kW
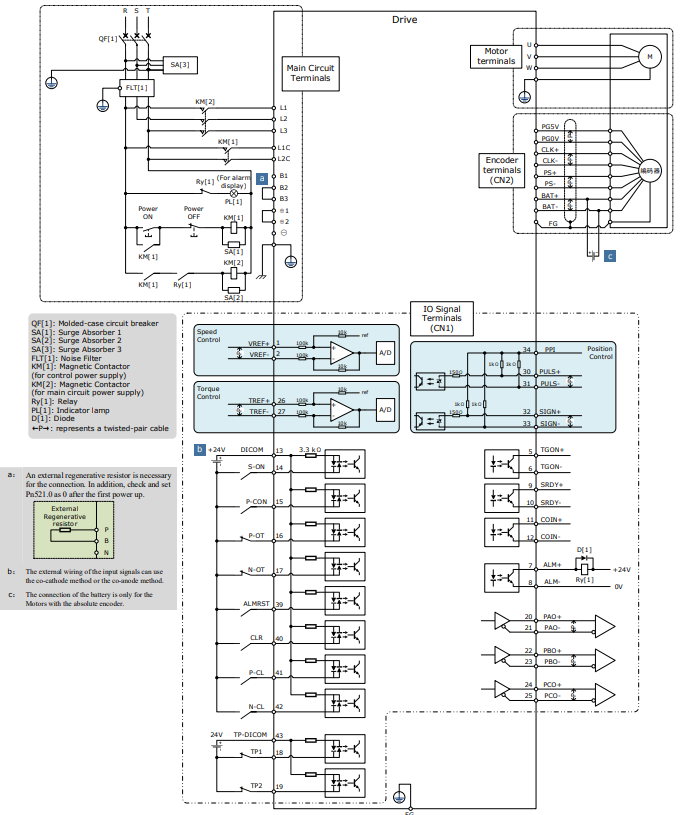
400VAC, rated power from 1kW to 7.5kW
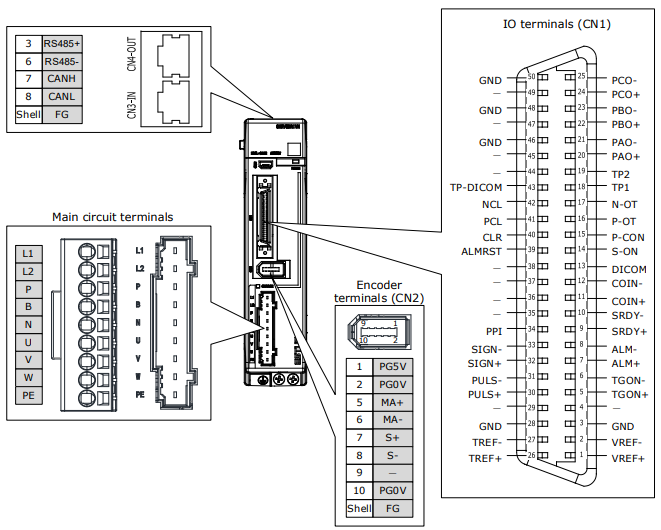
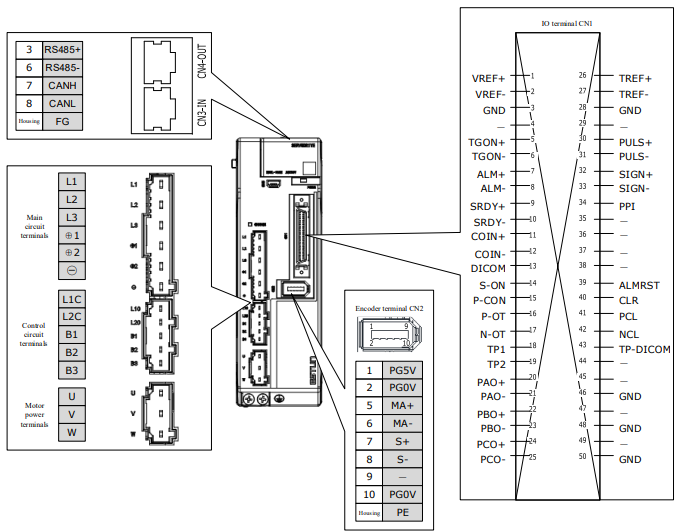
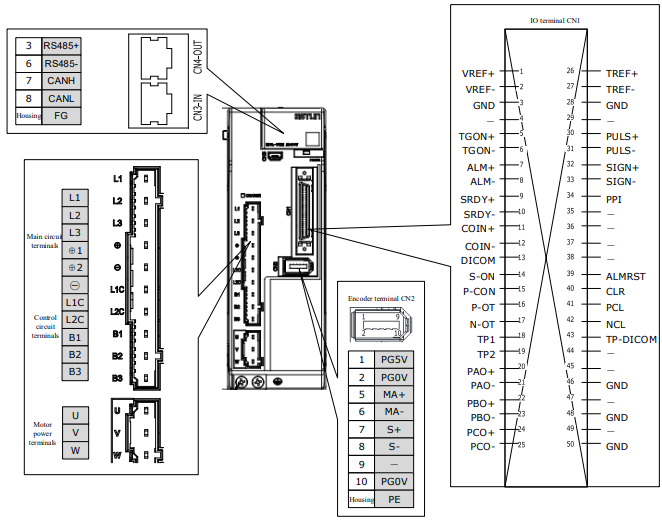
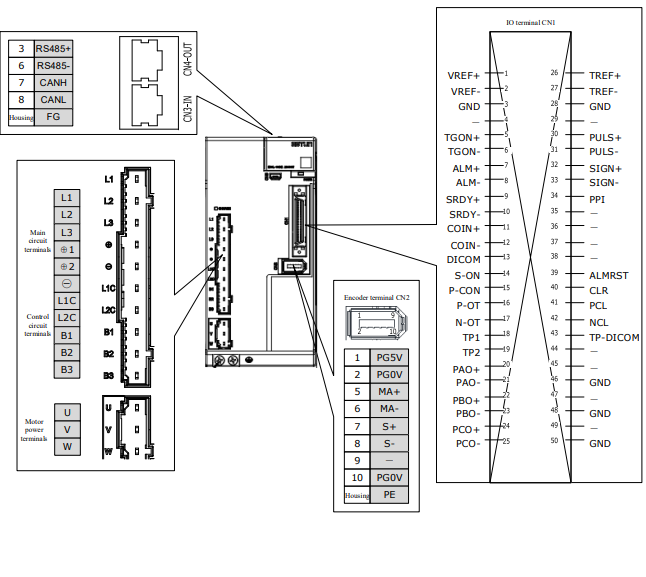
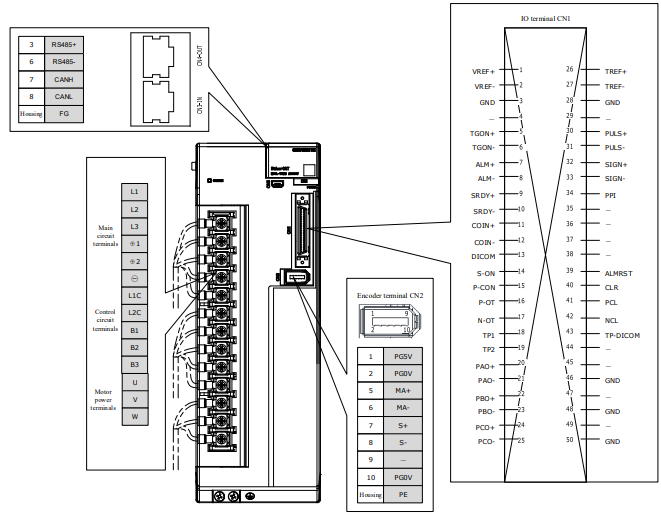
3.3 Terminals Arrangements
Rated power from 50W to 400W
200VAC, rated power from 750W to 2kW
400VAC, rated power from 1kW to 1.5kW
400VAC , rated power from 2kW to 3kW
400VAC, rated power from 5kW to 7.5kW
3.4 Wiring the Power Supply to Drive
3.4.1 Terminals Arrangement
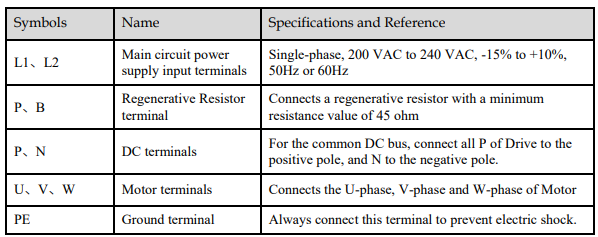
Rated power from 50W to 400W
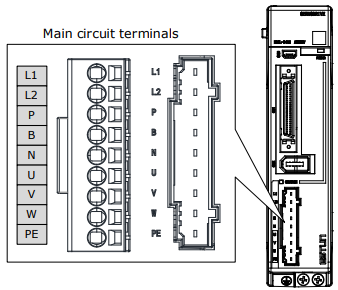
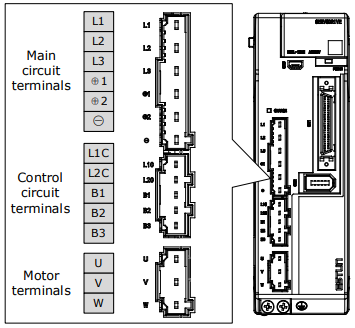
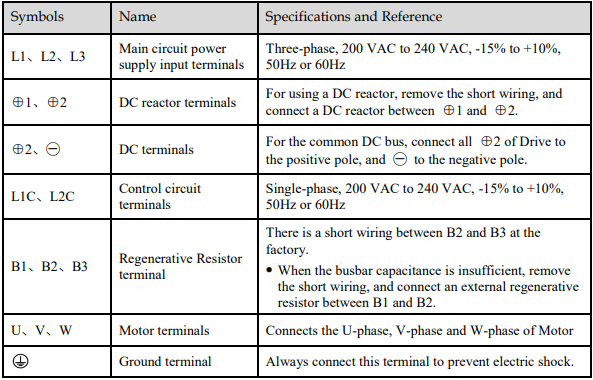
Rated power from 750W to 2kW
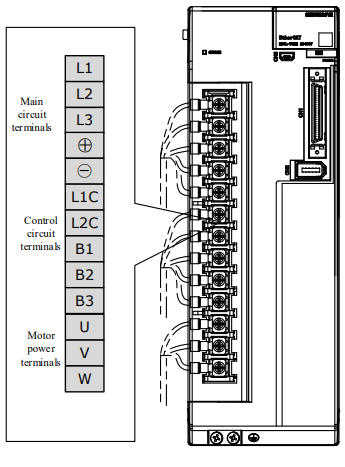
400VAC, rated power from 1kW to 3kW
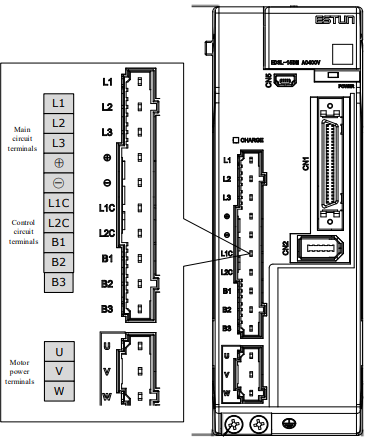
Take for example a product with a power rating of 1kW~1.5kW. Products with power rating from 1.5kW to 3kW are similar in appearance and have the same components
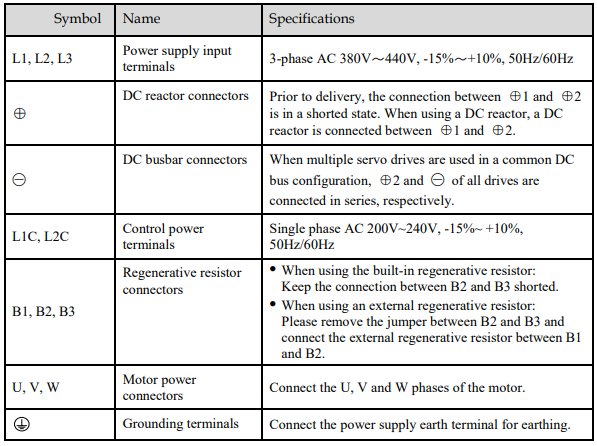
400VAC, rated power from 5kW to 7.5kW
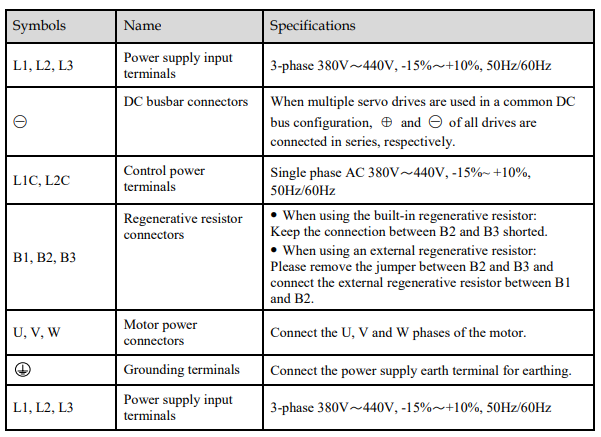
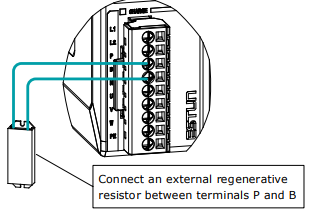
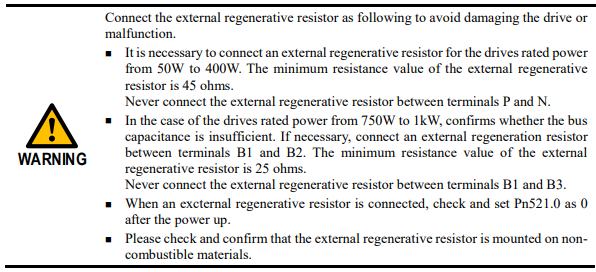
3.4.2 Wiring a Regenerative Resistor
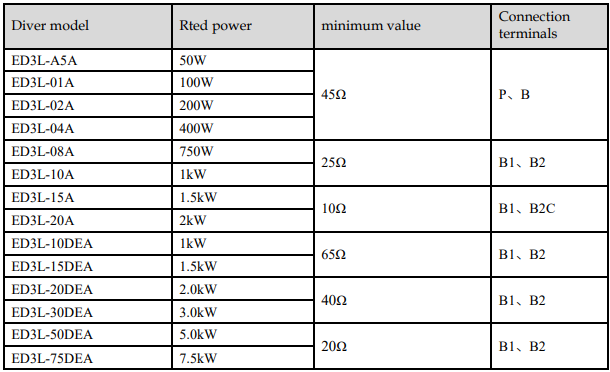
Figure 3-1 is an example of connecting an external regenerative resistor for the drives rated power from 50W to 400W.
Figure 3-1 Wires a regenerative resistor
3.4.3 Wiring Procedure
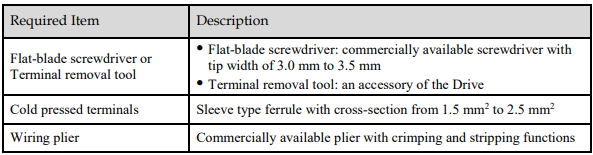
Prepare the following items before preparing the wiring for the Main Circuit Terminals and Control Circuit Terminals.
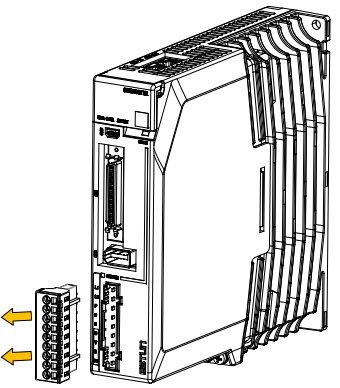
Follow the procedure below to wire the Main Circuit Terminals and Control Circuit Terminals. Step 1 Remove the Main Circuit Terminals and Control Circuit Terminals from the Drive.
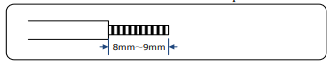
Step 2 Peel off the sheath so that the conductor portion of the cable will protrude from the tip of the ferrule.
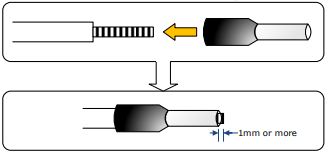
Step 3 Insert the cable into the ferrule (It should protrude 1 mm or more from the ferrule).
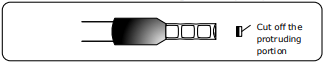
Step 4 Crimp the cable that has been inserted into the ferrule, and cut off the cable conductor portion protruding from the ferrule (The allowable protruding length after cutting should not be more than 0.5 mm).
Step 5 Use the flat-blade screwdriver or the terminal removal tool to press down the spring button corresponding to the terminal, and then insert the cable.
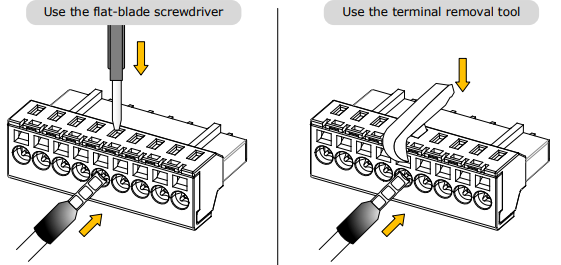
Step 6 Insert the crimped cable into the connection terminals, and then pull out the tool.
Step 7 Make all other connections in the same way.
Step 8 To change the wiring, pull the cable out of the connection terminals. Use the flat-blade screwdriver to press down the spring button corresponding to the terminal, and then gently pull out the cable.
Step 9 When you have completed wiring, attach connection terminals to the Drive.
NOTE
The above wiring procedure is also applicable to the Motor Terminals.
----End
3.4.4 Motor Connection Diagram
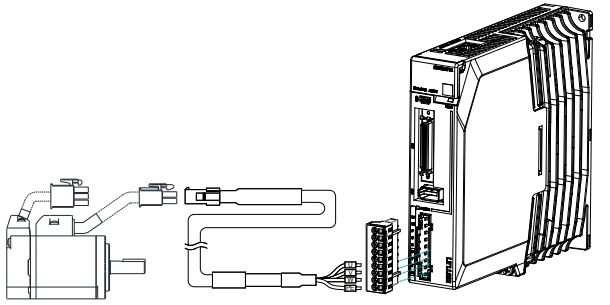
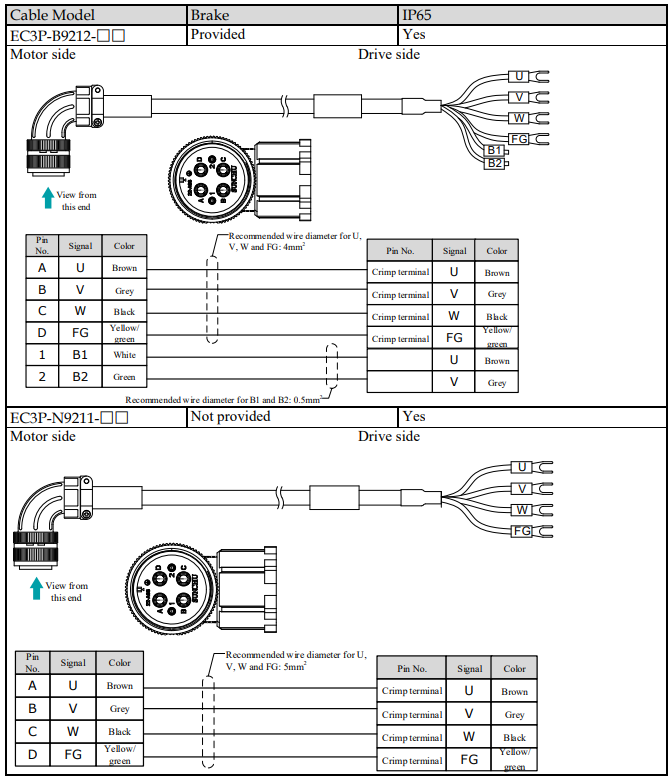
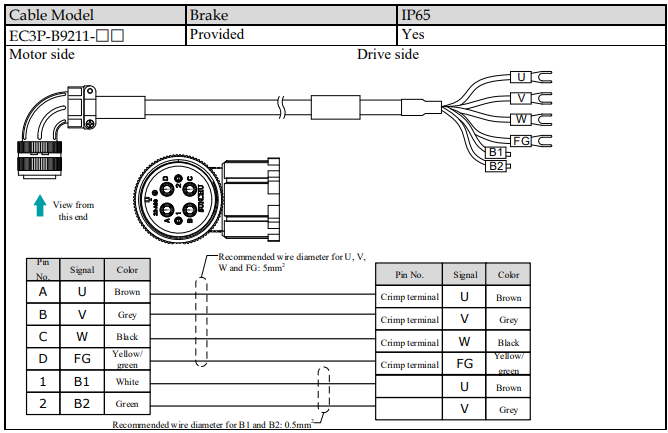
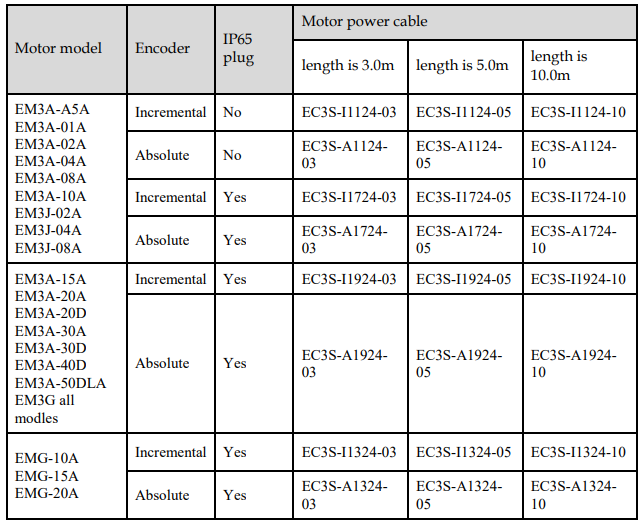
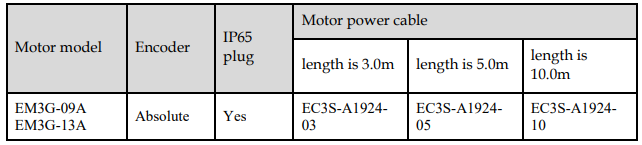
3.4.5 Motor Power Cable Description
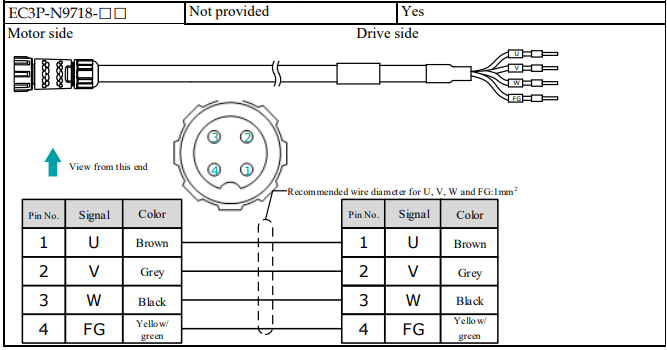
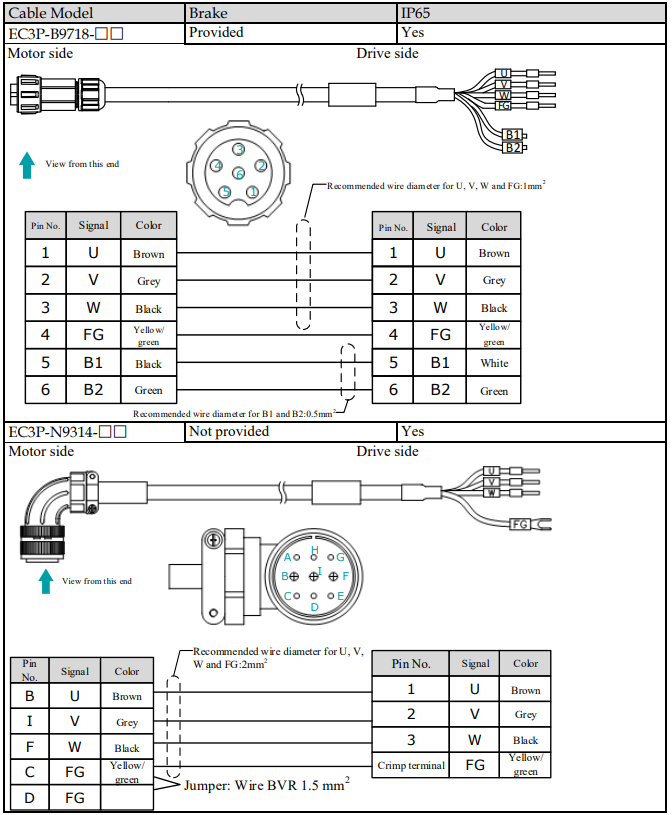
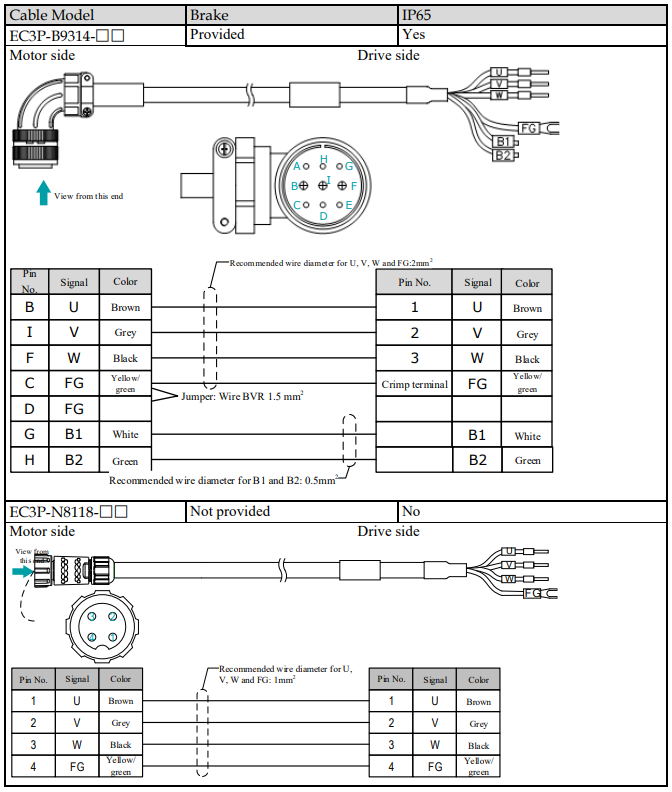
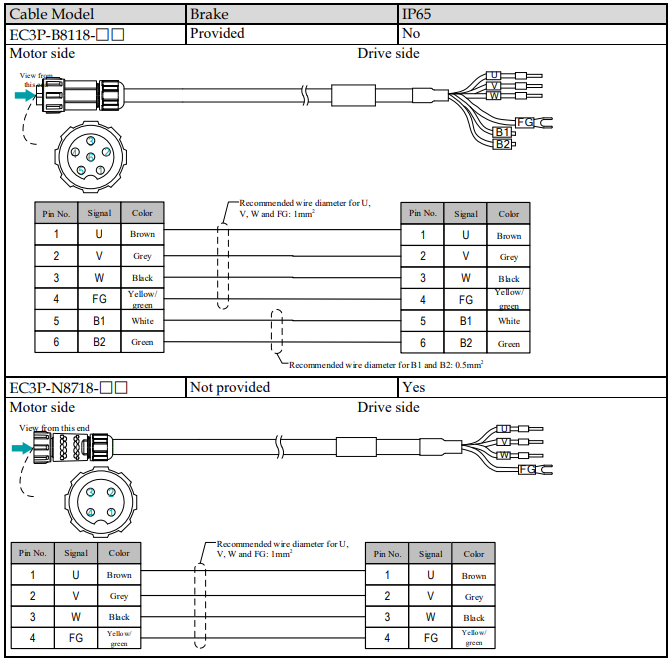
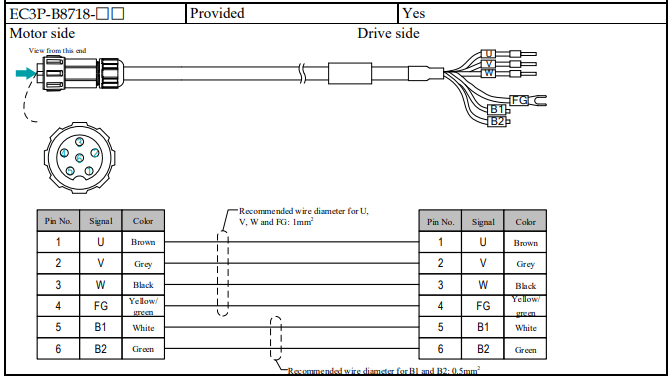
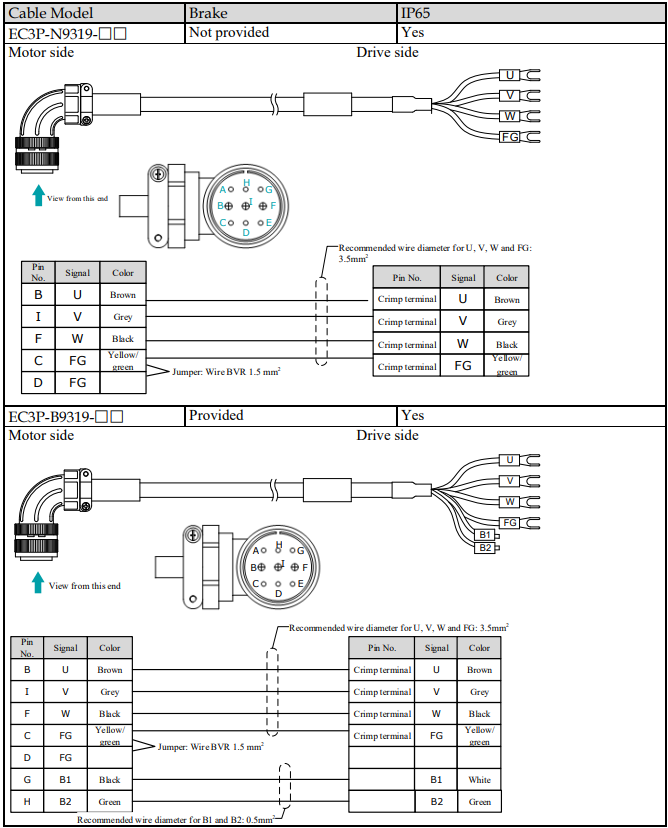
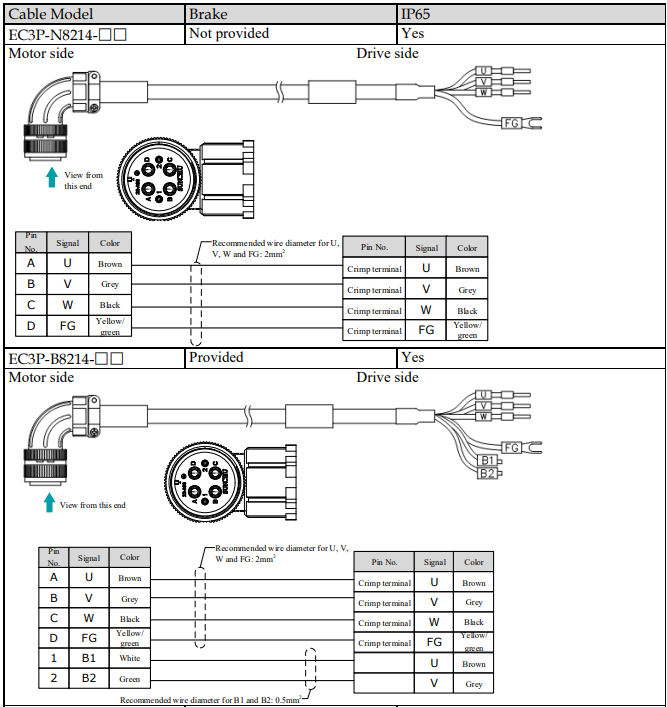
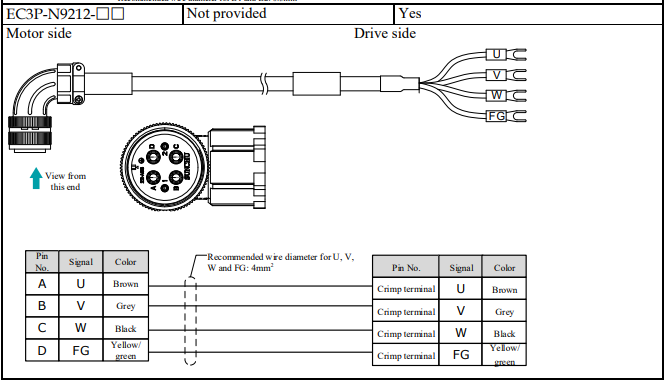
The Motor power cable depends on the Motor model. The common models are shown in the table below.
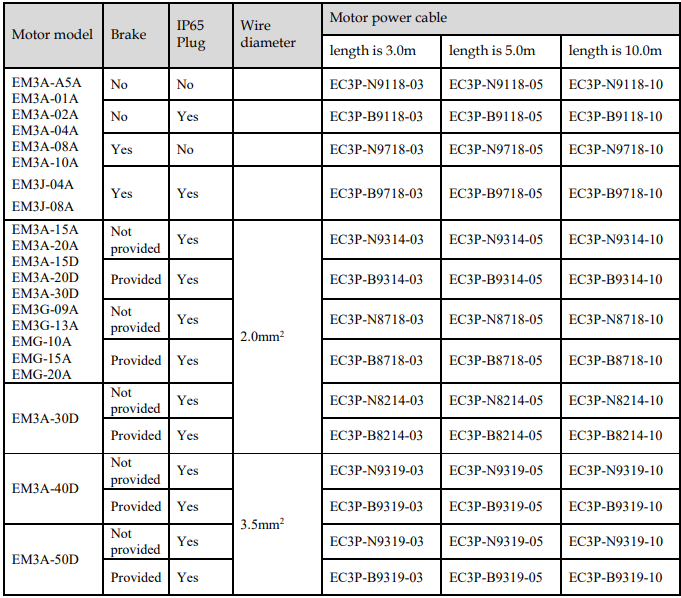
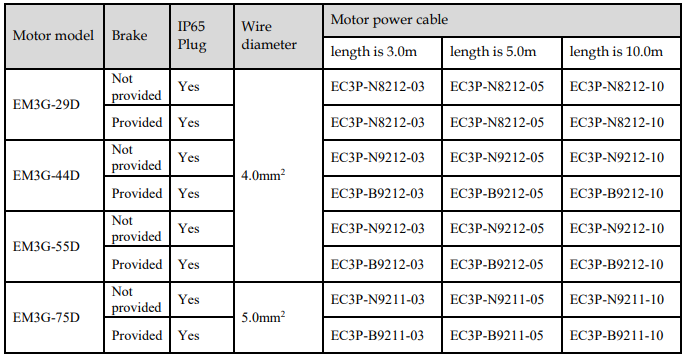
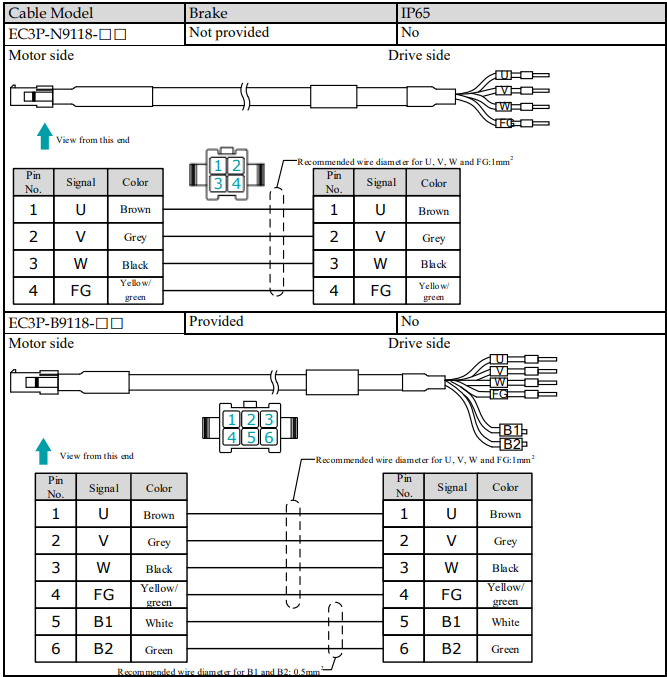
The following shows the diagram and wiring description of each Motor power cable.
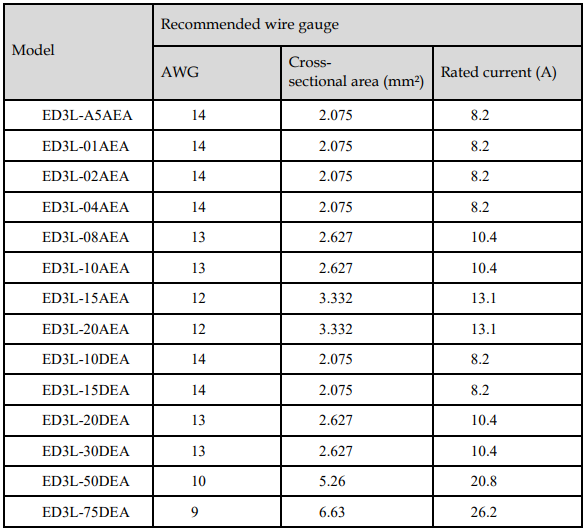
3.4.6 Power Input Wiring Specifications
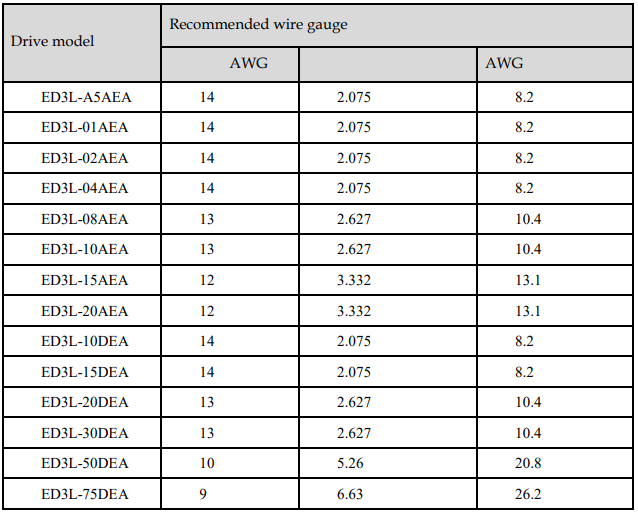
The power input wiring specification depends on the Motor model. The following table shows the recommended wire gauge for each Drive.
3.4.7 Power Input Wiring Example
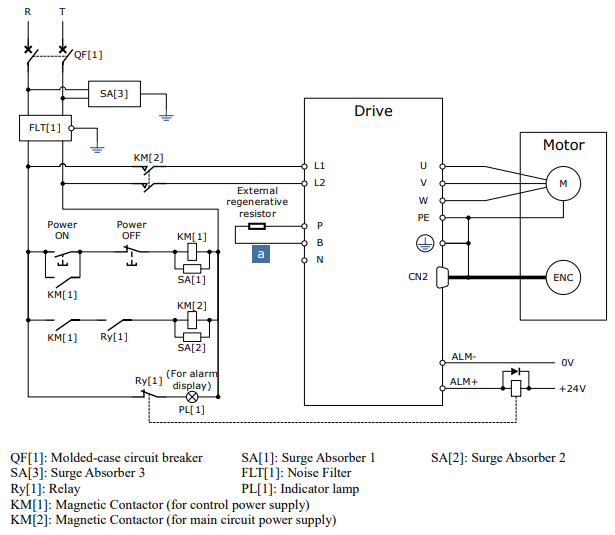
Rated power from 50W to 400W
Use single-phase 200 VAC to 240 VAC as the power input for the Drives rated power from 50W to 400W.
Rated power from 750W to 2kW
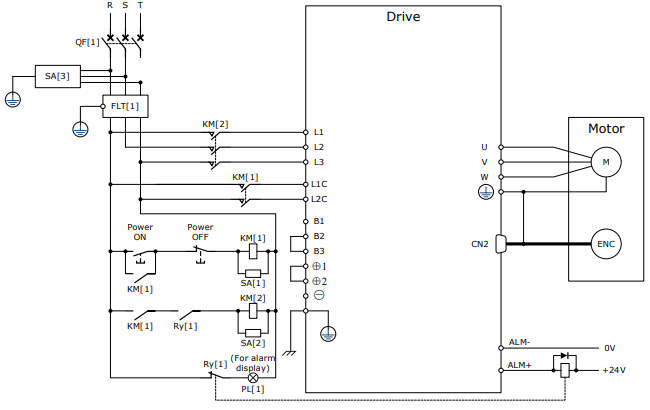
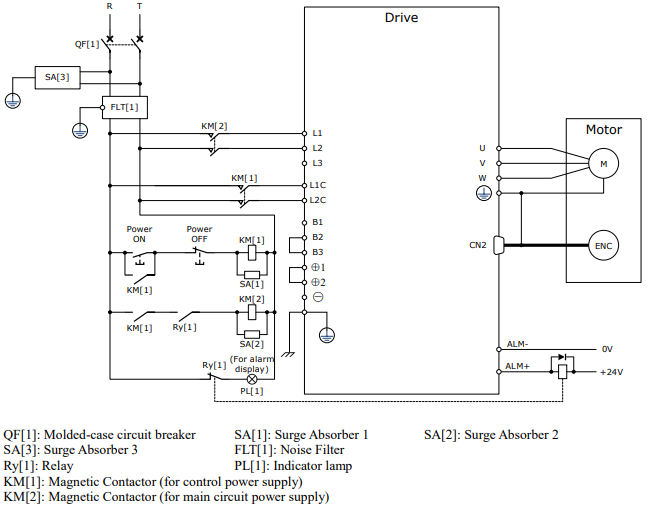
Use single-phase or three-phase 200 VAC to 240 VAC as the power input for the Drives rated power from 750W to 2kW.
The following figure shows the wiring example for using the three-phase AC input power.
The following figure shows the wiring example for using the single-phase AC input power.
400VAC, rated power from 1kW to 5kW
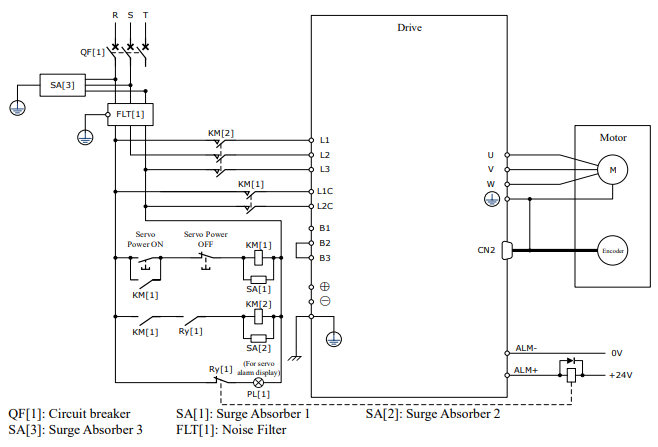
Use a three-phase AC 380V~440V as the power input for the drives.
[When using three-phase AC power supply]

3.5 Wiring the Encoder
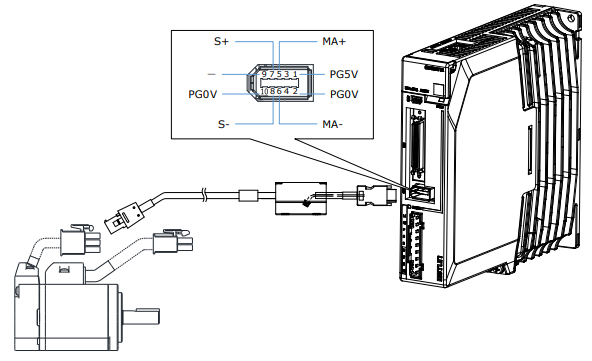
3.5.1 Connection Diagram
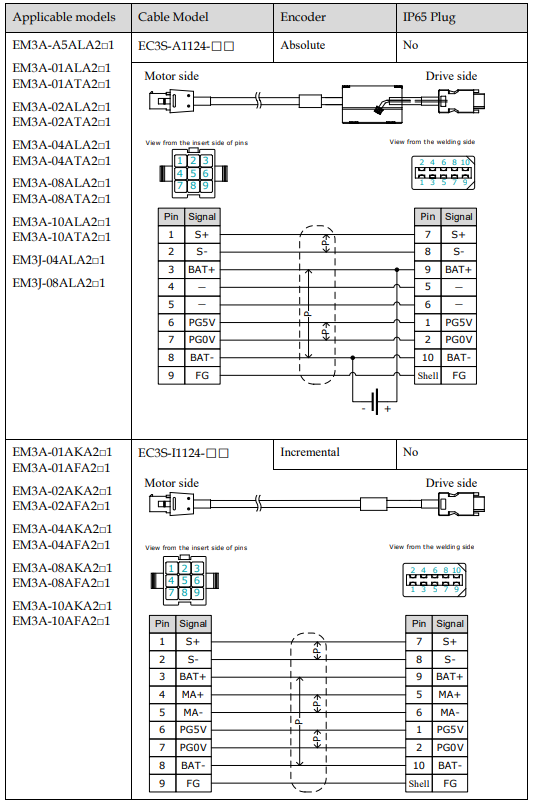
3.5.2 Encoder Cable Description
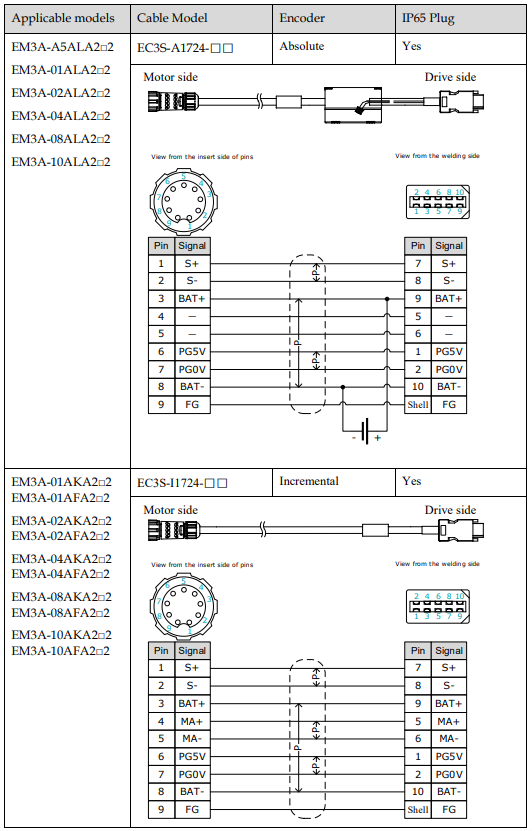
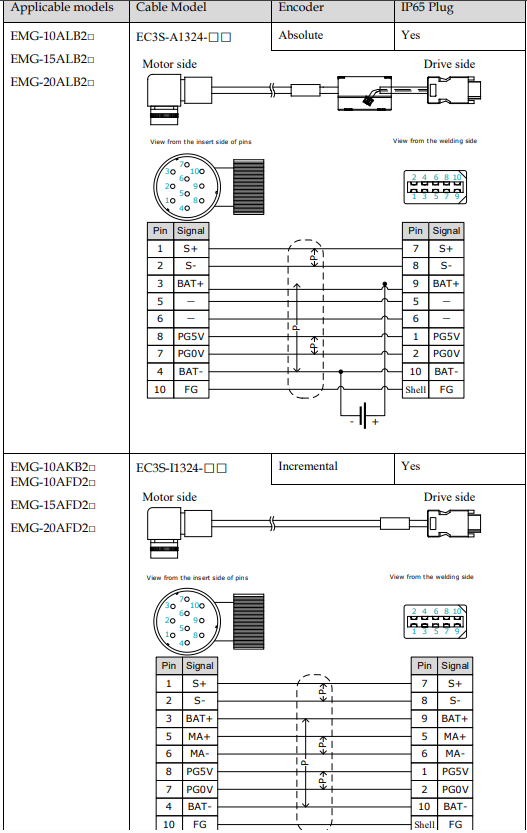
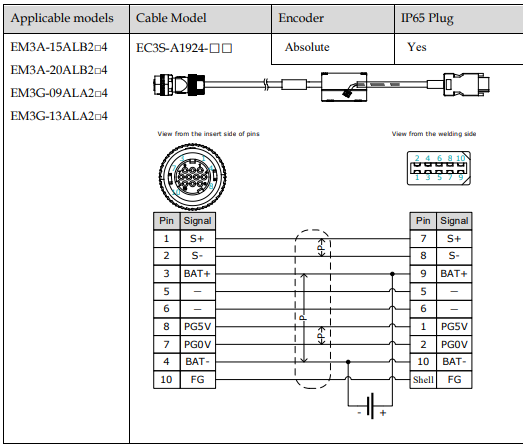
The encoder cable depends on the Motor model. The common models are shown in the table below.
3.5.3 Encoder Cable Wiring Specifications
Wiring specifications for encoders vary from model to model. The recommended wire gauge for each model are listed below.
The following shows the diagram and wiring description of each encoder cable.
3.5.4 Battery Case Connection
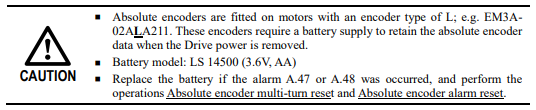
Follow the instructions below to install or replace the battery case.
Step 1 Turn ON only the control power supply to the Drive.
Step 2 Open the cover of the battery case.
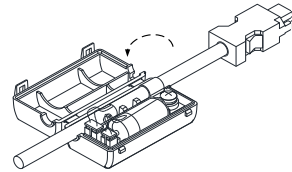
Step 3 Remove the old battery and mount a new battery.
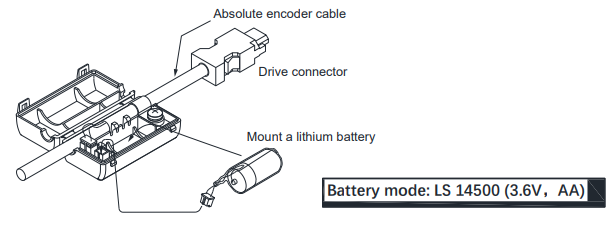
Step 4 Close the cover of the battery case.
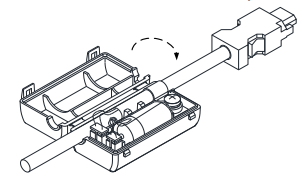
Step 5 Repower up the Drive.
Step 6 Resert the Alarms.
NOTE
Perform the Fn011 and Fn010 by Panel Operator to reset the alarms, for details, see the section Fn010 (Absolute encoder multi-turn reset) and Fn011 (Absolute encoder alarm reset) .
Also, you can reset the alarms by ESView V4, for details, see ESView Help Manual.
Step 7 Make sure the alarms have been cleared and the Drive operates normally.
----End
3.6 I/O Signal Connections
3.6.1 Signal Diagram
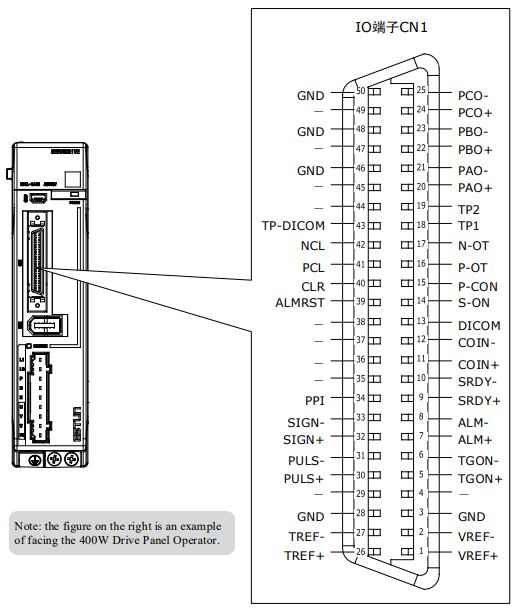
NOTE
The signal definitions for the IO signals of all drives are the same. The signal name in the diagram above is predefined at the factory. You can can assign the following signals by Pn509, Pn510, and Pn511, see the section 5.7 IO Signal Allocation in detail.
3.6.2 Pin Layout
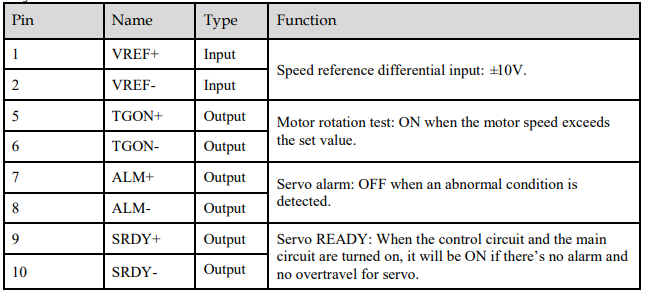
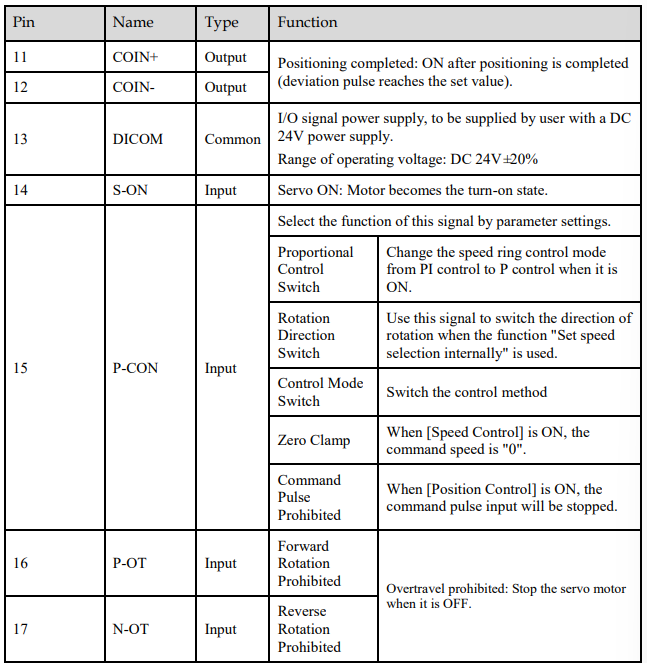
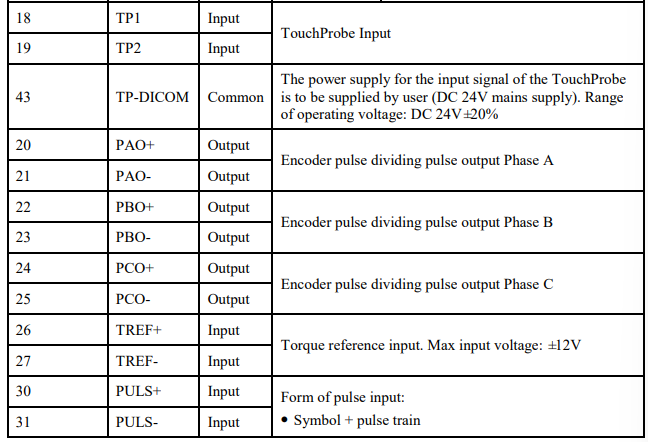
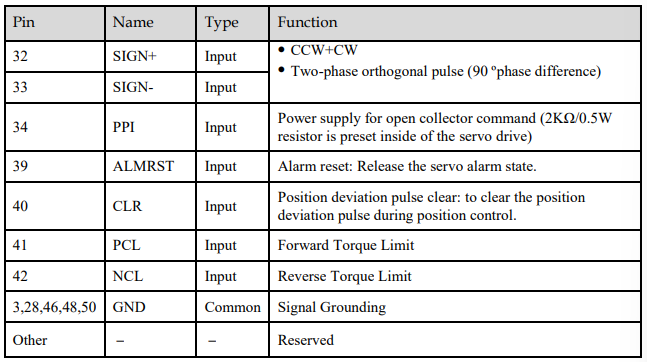
3.6.3 Wiring Description
Input Signals Wiring
The input signals of the Drive are divided into two groups, and the details are as following. Taking the input signal P-OT as an example, Figure 3-2 shows the connection diagram by using an external 24 VDC power supply, and the wiring of other input signals wiring is the same as it.
Figure 3-2 P-OT wiring diagram
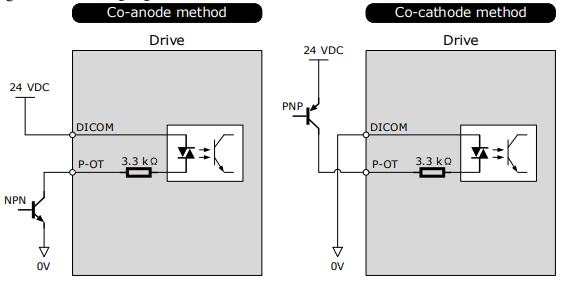
You can assign the input signals by Pn509 and Pn510. For the input signal allocation, see the section 5.7 IO Signal Allocation.
Output Signals Wiring
Taking the output signal TGON as an example, Figure 3-3 shows the connection diagram for using the optocoupler or relay, and the wiring of other output signals wiring is the same as it.
Figure 3-3 TGON wiring diagram
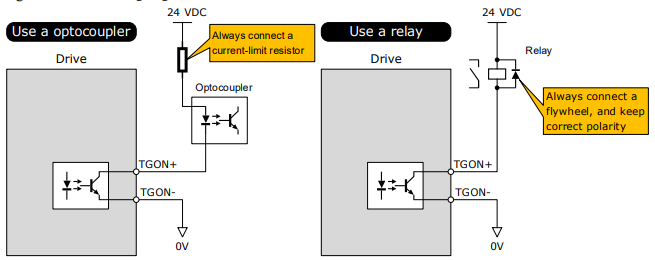
The maximum permissible voltage and current of the ptocoupler output circuit inside the servo drive are as follows:
Maximum voltage: 30 VDC
Maximum current: DC 50 mA
You can assign the output signals by Pn511. For the output signal allocation, see the section 5.7 Output Signal Allocations.
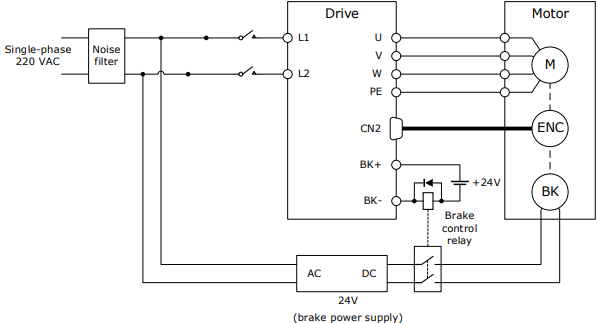
3.6.4 Holding Brake Wiring
A holding brake is used to hold the position of the moving part of the machine when the Drive is turned OFF so that moving part does not move due to gravity or an external force.
You can use the brake that is built into a Motor with a Brake, or you can provide one on the machine. The holding brake is used in the following cases.
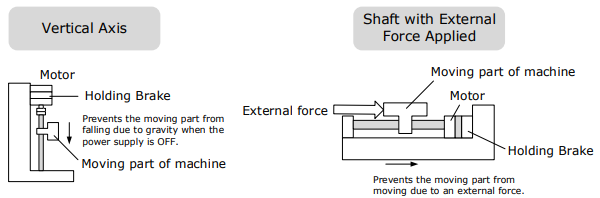
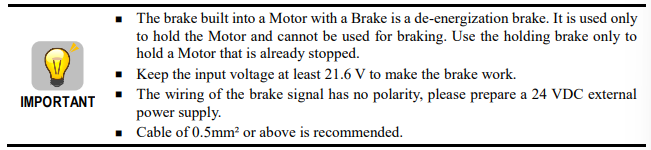
Taking the drives rated from 50W to 400W as an example,Figure 3-4 shows the connection diagram of the holding brake.
Figure 3-4 Holding brake wiring diagram
3.6.5 Touch Probe Wiring
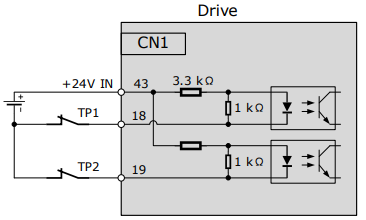
You shall only use the terminals CN1-18 (TP1) and CN1-19 (TP2) for Touch Probe input signal, which has been allocated at factory. The following figure shows the example diagram for the connection.
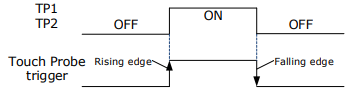
The timing sequence between input signals and trigger is as shown in below
3.7 USB Communication Cable
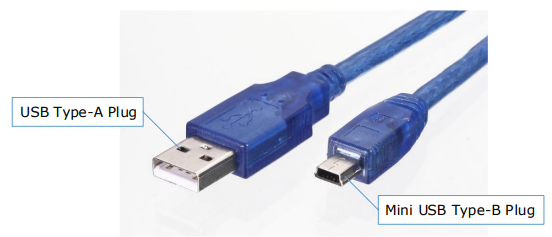
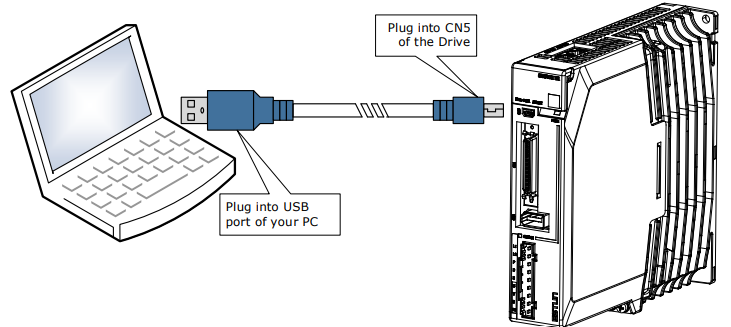
Connects your PC to a Drive with a USB Communication Cable, in order to make the online operation of ESView V4.
Connection Diagram
Cable Description
You can purchase the USB Communication Cable provided by ESTUN, or you can purchase the commercially available products yourself.
The plug connected to your PC is USB Type-A, and the plug connected to the Drive is Mini USB Type B.