7. Application Functions
7.1 Power Supply
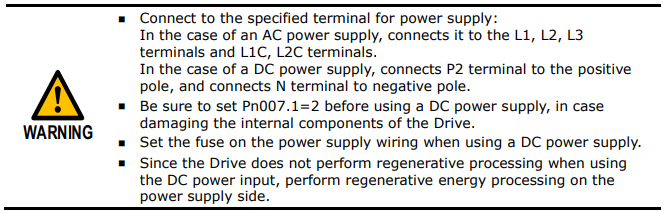
The main circuit and control circuit of the Drive can be operated with AC or DC power input. When AC power input is selected, single- phase or three phase power input can be used. You shall to set the parameter Pn007.1 and Pn007.3 (use AC power input) according to the applicable power supply.
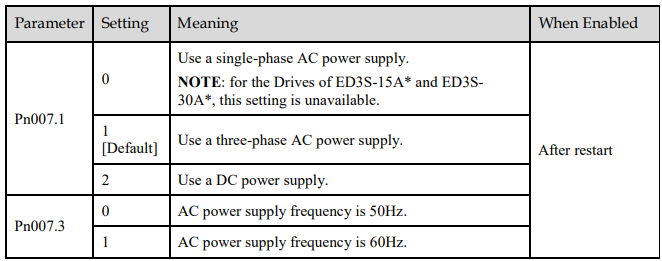
An alarm A.24 (Main Circuit Power Supply Wiring Error) may be occurred if the setting of Pn007.1 be consonant with not match the applicable power supply.
7.2 Motor Rotation Direction
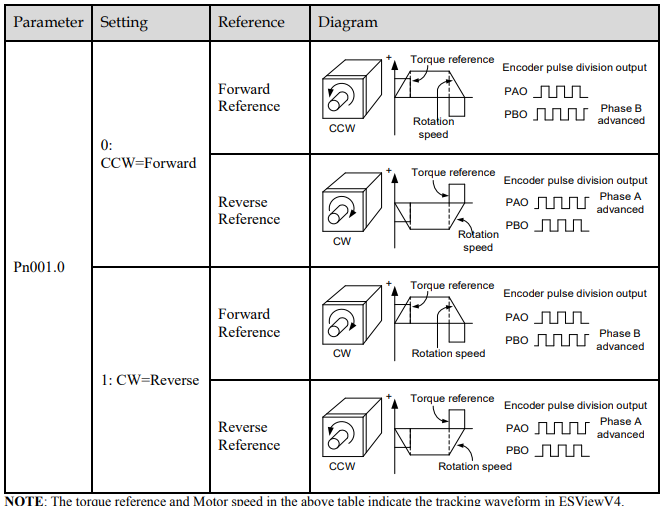
Only the rotation direction of the Motor can be switched without changing the reference pulse to the The standard setting for Forward Rotation is counterclockwise (CCW) as viewed from the Drive end.
7.3 Overtravel Limit
7.3.1 Function Description
Overtravel is a safety function of the Drive that forces the Motor to stop in response to a signal input from a limit switch that is activated when a moving part of the machine exceeds the safe range of movement.
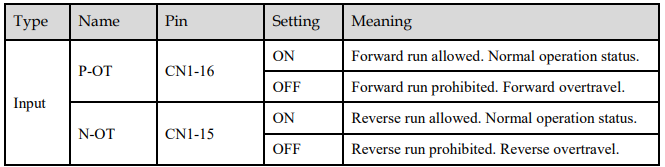
The overtravel signals include the P-OT (Forward Drive Prohibit) and the N-OT (Reverse Drive Prohibit) signals.
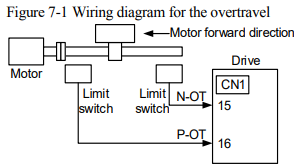
You use the P-OT and N-OT signals to stop the machine by installing limit switches at the positions where you want to stop the machine that is operated by the Motor.
An example of wiring for the P-OT signal and the N-OT signal is shown in Figure 7-1.
Using the overtravel function is not necessary for rotating applications such as rotary tables and conveyors. No wiring for overtravel input signals is required.
7.3.2 Connecting the Overtravel Signal
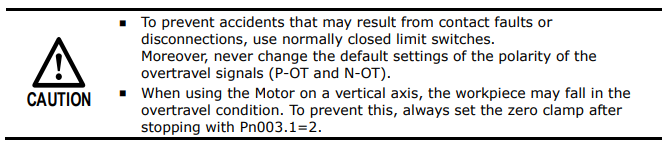
To use the overtravel function, connect the following overtravel limit switch input signal terminals.
7.3.3 Enabling/Disabling the Overtravel Signal
Parameters can be set to disable the overtravel signal. If the parameters are set, there is no need to wire the overtravel input signal
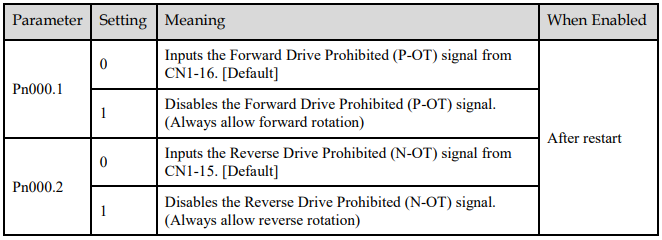
In addition, you can disable the overtravel limit function by not set the values 1 and 2 to parameter Pn509 (not allocate the P-OT signal and N-OT signal).
7.4 Motor Stop Methods
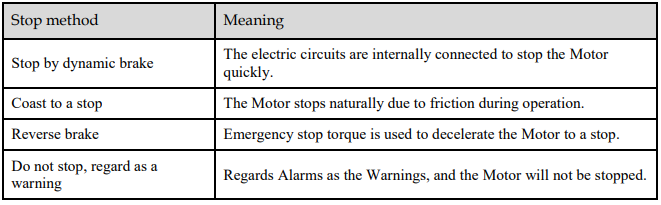
There are four methods to stop the Motor when an alarm (Gr.1 or Gr.2) occurs, in Safe state, or Servo OFF.
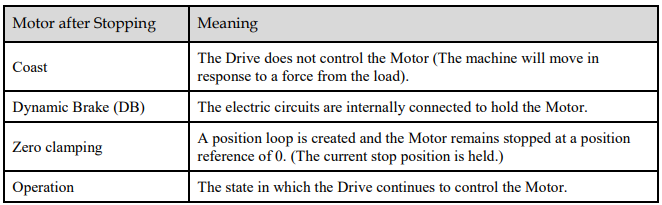
There are four ways of states after the Motor is stopped:
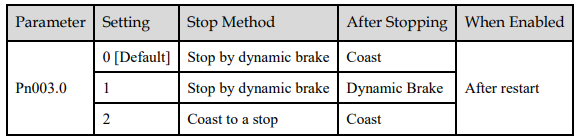
7.4.1 Motor Stop Methods for Gr.1 Alarms, Safety State and Servo OFF
You can select the Motor stopping methods for Gr.1 Alarms occur, in Safe state and Servo OFF by setting the parameter Pn003.0.
7.4.2 Motor Stop Methods for Overtravel
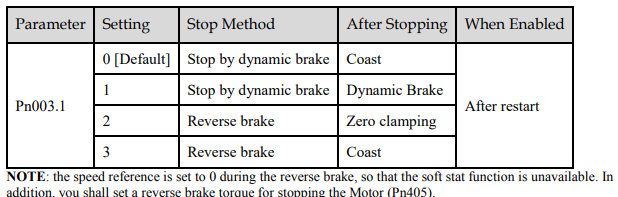
You can select the Motor stopping methods for an overtravel occurs by setting the parameter Pn003.1.
7.4.3 Motor Stop Methods for Gr.2 Alarms
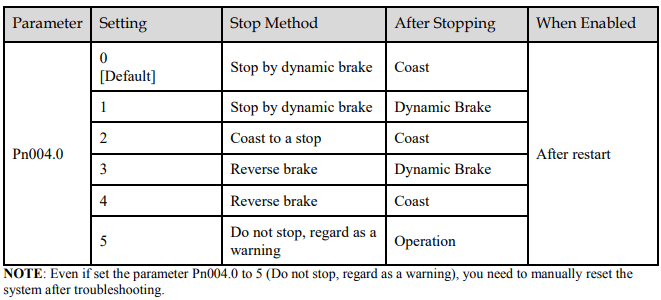
You can select the Motor stopping methods for Gr.2 Alarms occur by setting the parameter Pn004.0.
7.4.4 Reverse Brake Torque Limit Setting
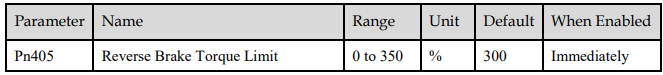
If Pn004.0 is set to 3 or 4, the Motor will be decelerated to a stop using the torque set in Pn405 as the
maximum torque.
7.5 Holding Brake
7.5.1 Function Description
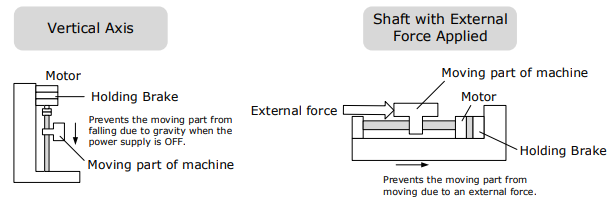
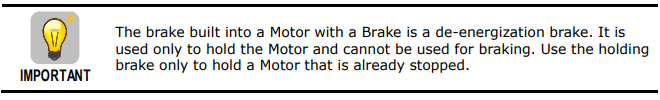
A holding brake is used to hold the position of the moving part of the machine when the Drive is turned OFF so that moving part does not move due to gravity or an external force.
You can use the brake that is built into a Motor with a Brake, or you can provide one on the machine.
The holding brake is used in the following cases.
7.5.2 Brake Operating Sequence
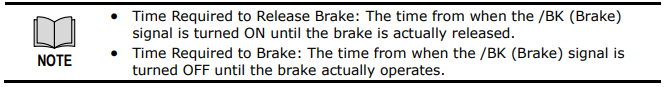
You must consider the time required to release the brake and the time required to brake to determine the brake operation timing, as described below.
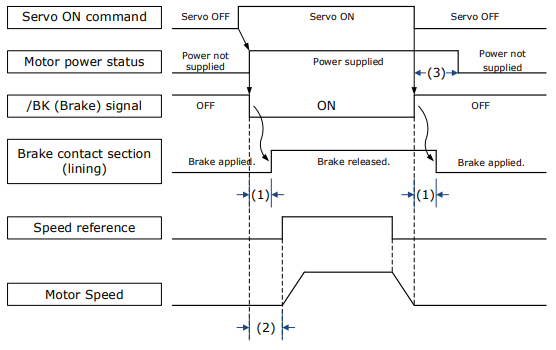
(1): The brake delay times for Motors with Holding Brakes.
(2): Before you output a reference from the host controller to the Drive, wait for at least 50 ms plus the time required to release the brake after you send the S-ON command.
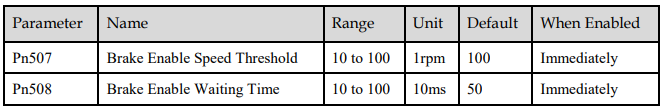
(3): Use Pn506 (Servo OFF Waiting Time), Pn507 (Brake Enable Speed Threshold), and Pn508 (Brake Enable Waiting Time) to set the timing of when the brake will operate and when the servo will be turned OFF.
7.5.3 /BK (Brake) Signal
The /BK signal is turned OFF (to operate the brake) when the Servo is turned OFF or when an alarm is detected. You can adjust the timing of brake operation (i.e., the timing of turning OFF the /BK signal) with the Servo OFF Waiting time (Pn506).
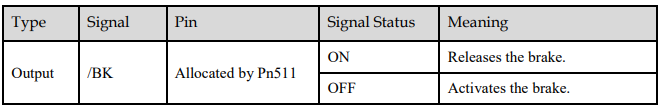
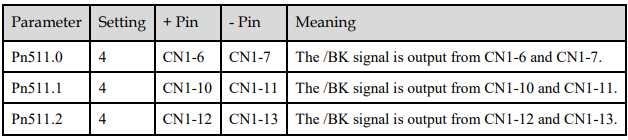
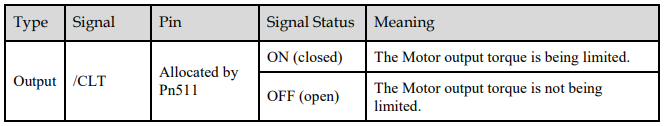
The /BK signal is not allocated in default setting, set its allocation in Pn511.
7.5.4 Output Timing of /BK Signal when Motor is Stopped
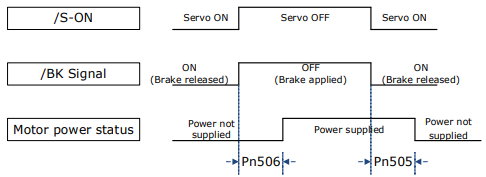
When the Motor is stopped, the /BK signal turns OFF as soon as the S-OFF (Servo OFF) command is received. Use the servo OFF delay time (Pn506) to change the timing to turn OFF power supply to the Motor after the S-OFF command is input.
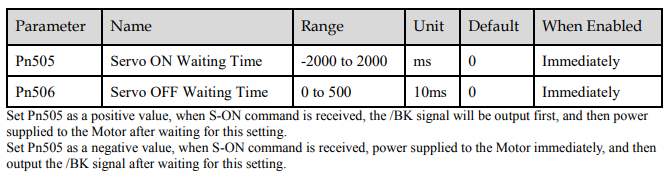
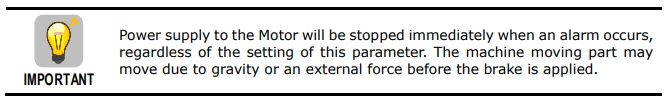
When the Motor is used to control a vertical axis, the machine moving part may move slightly due to gravity or an external force.
You can eliminate this slight motion by setting the servo OFF delay time (Pn506) so that power supply to the Motor is stopped after the brake is applied.
7.5.5 Output Timing of /BK Signal when Motor is operating
If an alarm occurs or S-OFF command is received while the Motor is operating, the Motor will start stopping and the /BK signal will be turned OFF. You can adjust the timing of /BK signal output by setting the Brake Enable Waiting Time (Pn508).
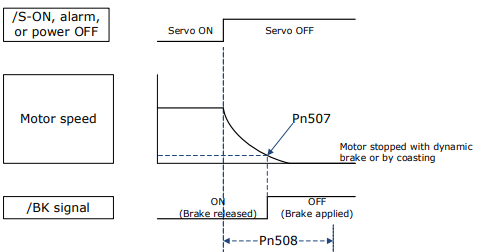
The /BK signal goes to H level (brake ON) when either of the following conditions is satisfied:
When the Motor speed falls below the level set in Pn507 after the power to the Motor is turned OFF.
When the time set in Pn508 is exceeded after the power to the Motor is turned OFF
7.6 Overload Enhancement
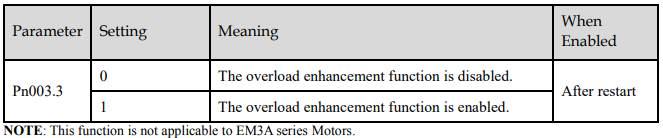
Overload Enhancement function can enhance the Motor load for instantaneous more than 2 times rated load, which can be used in the conditions that require frequent start and stop.
Set Pn003.3=1 for enabling this function, and it takes effect when the Motor speed is over 30 rpm.
7.7 Encoder Setting
7.7.1 Absolute Encoder Selection
The absolute encoder records the current position of the stop position even when the power supply is OFF.
With a system that uses an absolute encoder, the host controller can monitor the current position.
Therefore, it is not necessary to perform an origin return operation when the power supply to the system is turned ON.
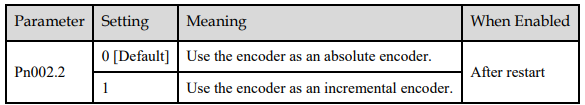
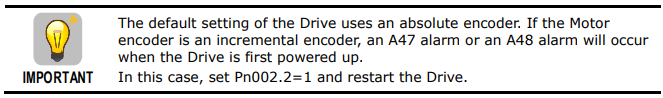
There are two types of encoders for the Motors. The usage of the encoder is specified in Pn002.2.
7.7.2 Encoder Alarm Resetting
It is necessary to connect a battery case for the absolute encoder, refers to the section Battery Case Connection in 3.5 Wiring the Encoder.
A48 Alarm Occurred
When the voltage of the encoder battery is lower than 3V, an alarm A48 will occur. In this case, follow the below methods to troubleshooting.
Turn ON only the control power supply to the Drive, and then, replace the battery case. Please contact ESTUN or the Authorized Distributor to purchase a new battery box if necessary.
Perform the Fn011 on Panel Operator, refers to the section Fn011 (Absolute encoder alarm reset).
Repower up the Drive, and the alarm A48 no longer occurs indicating the fault has been solved.
A47 Alarm Occurred
When the voltage of the encoder battery is lower than 2.45V, an alarm A47 will occur. In this case, the multi-turn data in the encoder has been lost, and you shall follow the below methods to troubleshooting.
Turn ON only the control power supply to the Drive, and then, replace the battery case. Please contact ESTUN or the Authorized Distributor to purchase a new battery box if necessary.
Perform the Fn011 on Panel Operator, refers to the section Fn011 (Absolute encoder alarm reset).
Perform the Fn010 on Panel Operator, refers to the section Fn010 (Absolute encoder multi-turn reset).
Repower up the Drive, and the alarm A48 or A47 no longer occurs indicating the fault has been solved.
7.7.3 Encoder Divided Pulse Output
Encoder Divided Pulse Output Signals
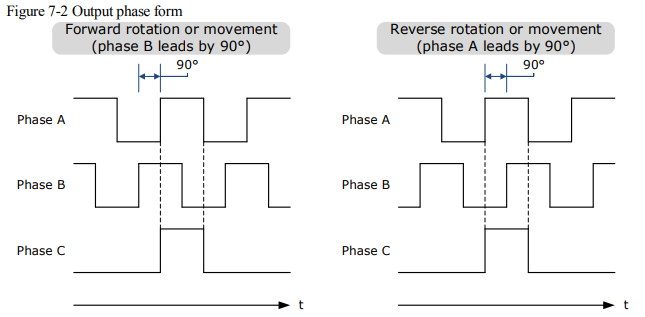
The encoder divided pulse output is a signal that is output from the encoder and processed inside the Drive. It is then output externally in the form of two phase pulse signals (phases A and B) with a 90° phase differential. At the host controller, it is used as the position feedback.
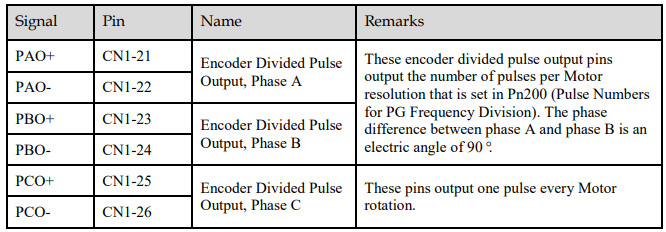
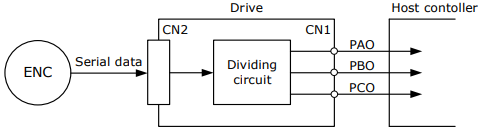
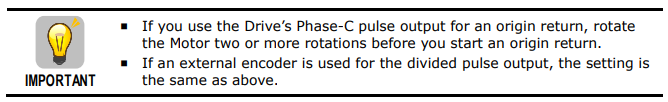
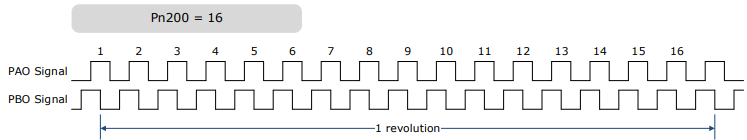
NOTE: Even for reverse operation (Pn001.0=1), the output phase form is the same as shown above. The output phase form is as shown in Figure 7-2.
Divide Pulse Setting
The pulse density set by the parameter Pn200 is converted and output based on the pulse data of the Motor encoder or an external encoder. The unit is "pulses per 1 revolution".
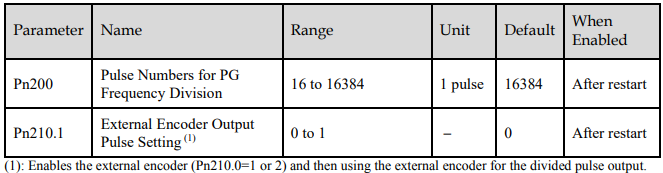
The number of pulses from the encoder per rotation are processed inside the Drive, divided by the setting of Pn200, and then output.
Set the number of encoder divided output pulses according to the system specifications of the machine or host controller.
The setting of the number of encoder output pulses is limited by the resolution of the encoder.
An output example is given below for the PAO (Encoder Pulse Output Phase A) signal and the PBO (Encoder Pulse Output Phase B) signal when Pn200 is set to 16 (16 pulses output per revolution)
7.8 I/O Signal Allocations
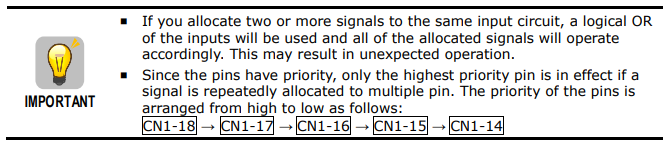
Functions are allocated to the pins on the I/O signal connector (CN1) in advance. You can change the allocations and the polarity for some of the connector pins. Function allocations and polarity settings are made with parameters.
7.8.1 Input Signal Allocations
Allocation Description
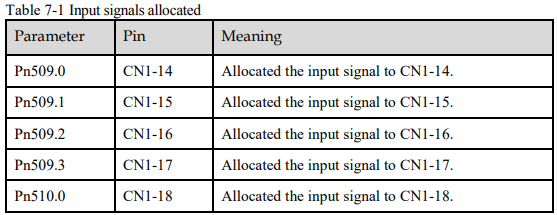
The I/O signal connector (CN1) on the Drive provides five pins (points) for allocating the input signals, corresponding to the sub-parameters of Pn509 and Pn510, as is shown in Table 7-1
Input Signals
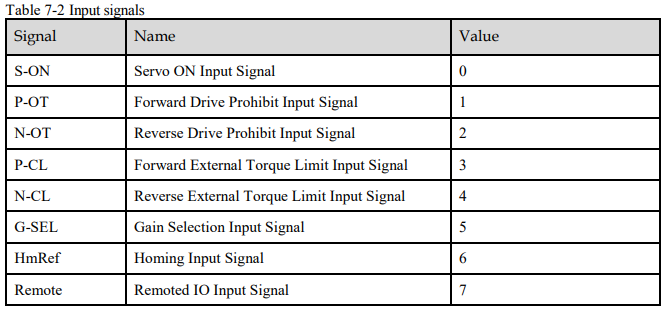
Table 7-2 lists the input signals that can be allocated and their corresponding values. Set the subparameters of Pn509 and Pn510 to use the following values, which means that they are allocated to the corresponding pins.
Allocation Example
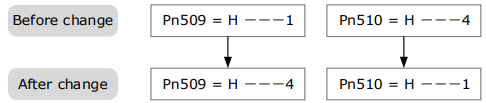
The following example shows reversing the P-OT (Forward Drive Prohibit) signal allocated to CN1-14
and the N-CL (Reverse External Torque Limit) signal allocated to CN1-18.
7.8.2 Output Signal Allocations
Allocation Description
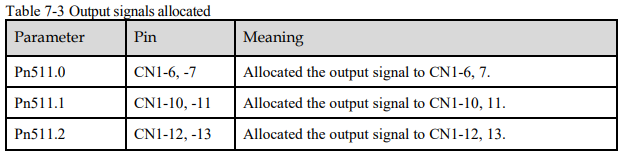
The I/O signal connector (CN1) on the Drive provides three pins (points) for allocating the output signals, corresponding to the parameter Pn511, as is shown in Table 7-3.
Output Signals
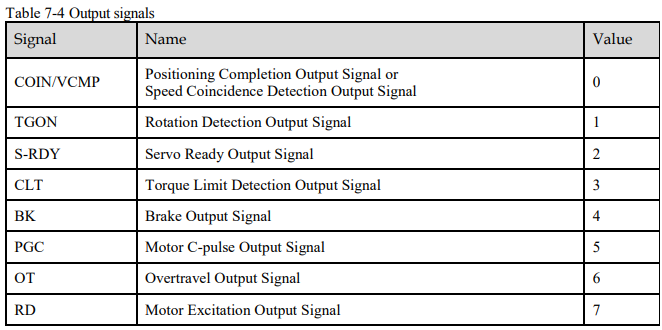
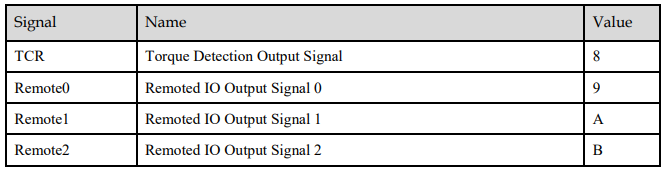
Table 7-4 lists the output signals that can be allocated and their corresponding values. Set the parameter Pn511 to use the following values, which means that they are allocated to the corresponding pins.
Allocation Example
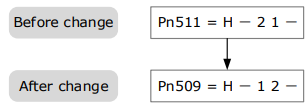
The following example shows reversing the S-RDY (Servo Ready) signal allocated to CN1-12, 13 and the TGON (Rotation Detection) signal allocated to CN1-10, 11.
7.9 Torque Limit
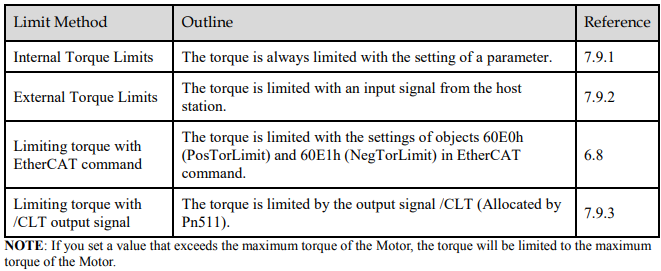
You can limit the torque that is output by the Motor.
There are four different ways to limit the torque. These are described in the following table.
7.9.1 Internal Torque Limits
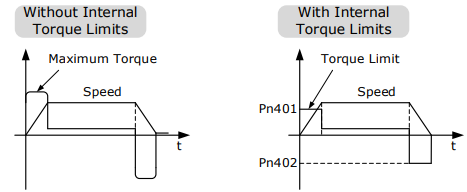
If you use internal torque limits, the maximum output torque will always be limited to the specified forward torque limit (Pn401) and reverse torque limit (Pn402).
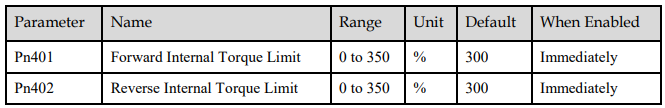
If the setting of Pn401 or Pn402 is too low, the torque may be insufficient for acceleration or deceleration of the Motor.
7.9.2 External Torque Limits
You can limit the torque only when required by the operating conditions of the machine by turning a signal ON and OFF.
You can use this for applications such as stopping on physical contact, or holding a workpiece with a robot.
External Torque Limit Reference Signals
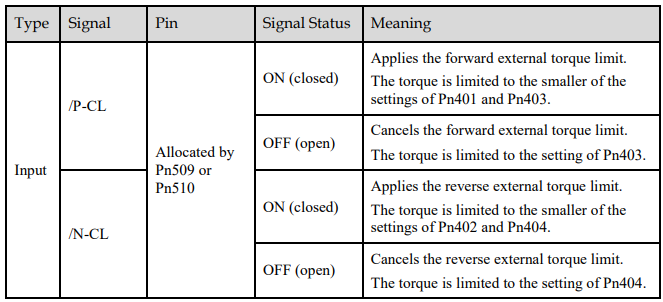
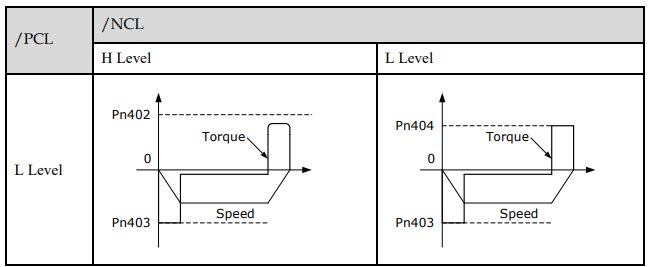
The /P-CL (Forward External Torque Limit) and /N-CL (Reverse External Torque Limit) signals are used as the external torque limit reference signals. The /P-CL signal is used for the forward torque limit and the /N-CL signal is used for the reverse torque limit.
Setting the Torque Limits
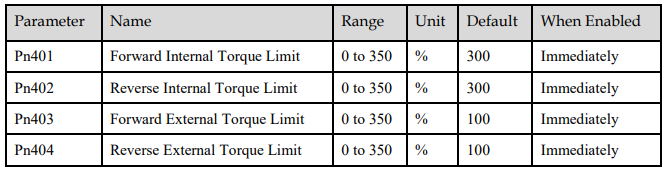
If the setting of Pn401 (Forward Torque Limit), Pn402 (Reverse Torque Limit), Pn403 (Forward External Torque Limit), or Pn404 (Reverse External Torque Limit) is too low, the torque may be insufficient for acceleration or deceleration of the Motor.
Changes in the Output Torque for External Torque Limits
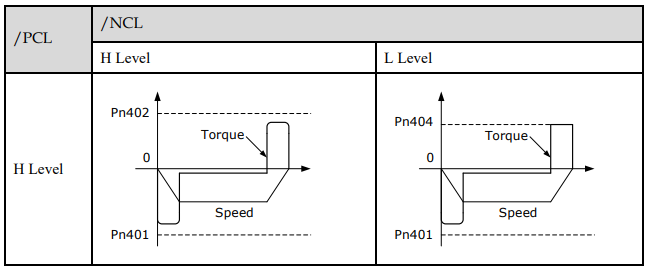
The following table shows the changes in the output torque when the internal torque limit is set to 300%. In this example, the Motor direction is set to Pn001.0=0 (Use CCW as the forward direction).
7.9.3 Limiting torque with /CLT output signal
This following describes the /CLT signal, which indicates the status of limiting the Motor output torque.
7.10 Soft Start
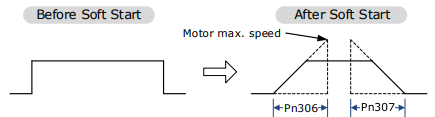
The soft start function converts the stepwise speed reference inside the Drive to a consistent rate of acceleration and deceleration.
The soft start form can be selected by parameter Pn310:
[0] Ramp; [1] S-Curve; [2] Primary filtering; [3] Secondary filtering
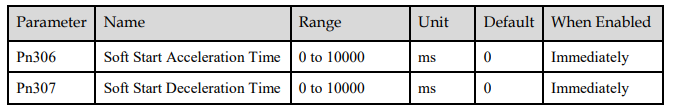
The soft start function enables smooth speed control when inputting a stepwise speed reference or when selecting internally set speeds. Set both Pn306 and Pn307 to “0” for normal speed control. Set these parameters as follows:
Pn305: The time interval from the time the Motor starts until the Motor maximum speed is reached.
Pn306: The time interval from the time the Motor is operating at the Motor maximum speed until it stops.
7.11 SEMI F47 Function
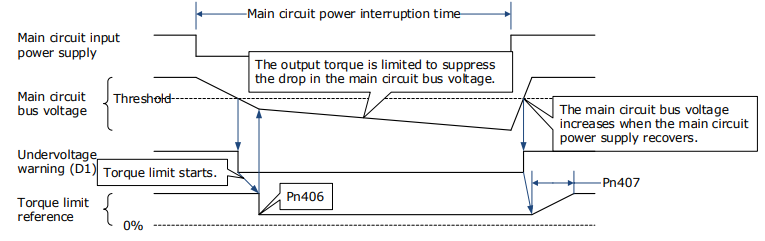
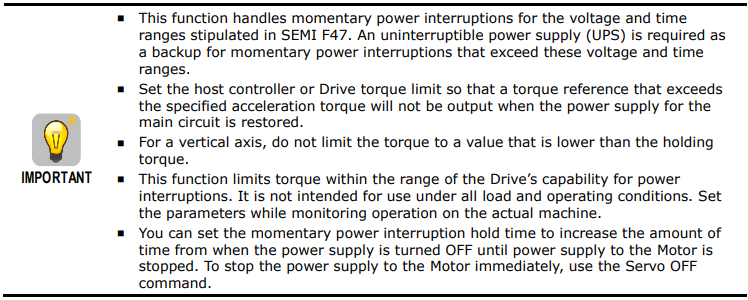
The SEMI F47 function detects an A.D1warning (Undervoltage Warning) and limits the output current if the DC main circuit power supply voltage to the Drive drops to a specified value or lower because the power was momentarily interrupted or the main circuit power supply voltage was temporarily reduced.
This function complies with the SEMI F47 standards for semiconductor manufacturing equipment.
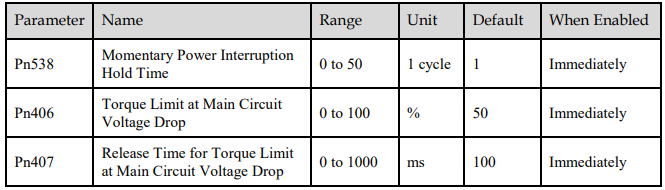
You can combine this function with the Momentary Power Interruption Hold Time (Pn538) to allow the Motor to continue operating without stopping for an alarm or without recovery work even if the power supply voltage drops.
You can set Pn007.2=1 for slow down the ramp rate of the bus voltage when an undervoltage occurs, allowing the system to run longer. In addition, you can set the Torque Limit at Main Circuit Voltage Drop (Pn407), which is a relative percentage of Pn401 (Forward Internal Torque Limit) or Pn402 (Reverse Internal Torque Limit).
The Drive controls the torque limit for the set time (Pn407) after the Undervoltage warning is cleared.