
5. Applications Functions
5.1 Power Supply
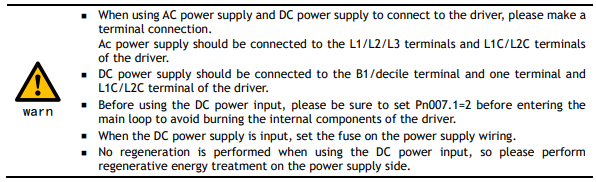
The main circuit and control circuit of the Drive can be operated with AC power input. When AC power input is selected, single- phase or three phase power input can be used. You should set the parameter Pn007.1 and Pn007.3 (use AC power input) according to the applicable power supply.
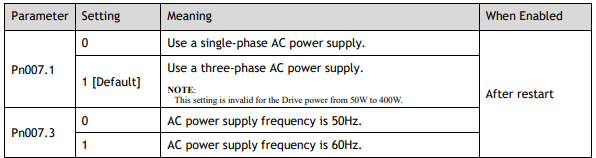
An alarm A.24 (Main Circuit Power Supply Wiring Error) may occur if the setting of Pn007.1 does not match the actual power supply.
5.2 Motor Rotation Direction
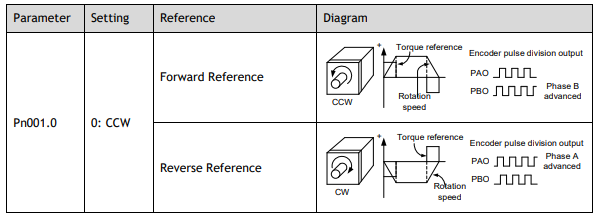
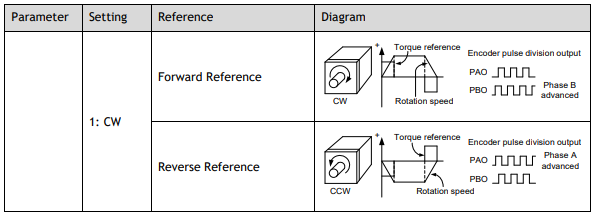
You can reverse the direction of Motor rotation by changing the setting of Pn001.0.
The default setting for Forward Rotation is counterclockwise (CCW) as viewed from the Drive end.
5.3 Overtravel Limit
5.3.1 Function Description
Overtravel is a safety function of the Drive that forces the Motor to stop in response to a signal input from a limit switch that is activated when a moving part of the machine exceeds the safe range of movement.
The overtravel signals include the P-OT (Forward Drive Prohibit) and the N-OT (Reverse Drive Prohibit) signals.
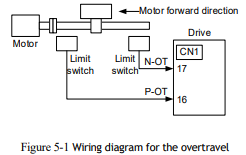
You use the P-OT and N-OT signals to stop the machine by installing limit switches at the positions where you want to stop the machine that is operated by the Motor.
An example of wiring for the P-OT signal and the N-OT signal is shown in Figure 5-1.
Using the overtravel function is not necessary for rotating applications such as rotary tables and conveyors. No wiring for overtravel input signals is required.
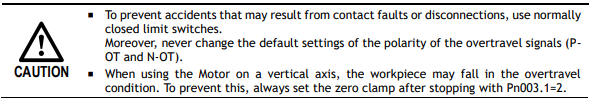
5.3.2 Connecting the Overtravel Signal
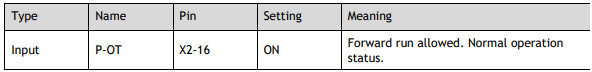
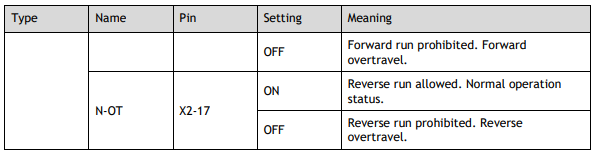
To use the overtravel function, connect the following overtravel limit switch input signal terminals
5.3.3 Enabling/Disabling the Overtravel Signal
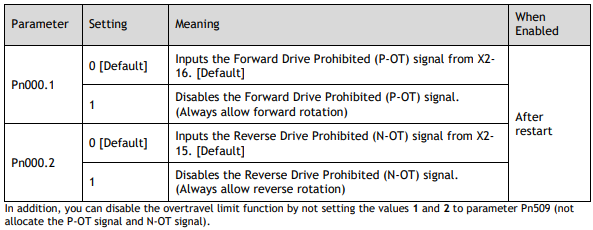
Parameters can be set to disable the overtravel signal. If the parameters are set, there is no need to wire the overtravel input signal.
5.4 Motor Stopping Methods
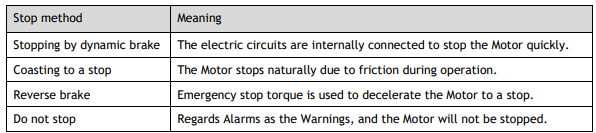
The following 4 ways are available to stop the drive alarming (Gr.1 or Gr.2), OT state, and servo OFF occurs:
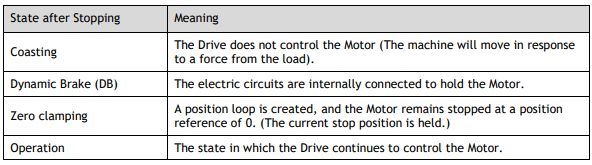
Also, you can let the Motor enter the following states after the Motor stops.
5.4.1 Motor Stop Methods for Gr.1 Alarms, Safety State and Servo OFF
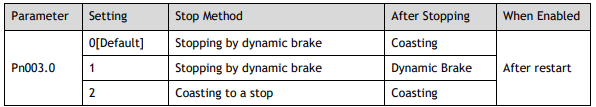
You can select the Motor stopping methods for Gr.1 Alarms occur, in Safe state or Servo OFF by setting the parameter Pn003.0.
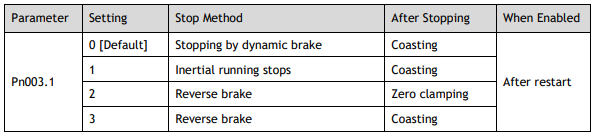
5.4.2 Motor Stop Methods for Overtravel
You can select the Motor stopping methods for overtravel occurrence by setting the parameter Pn003.1.
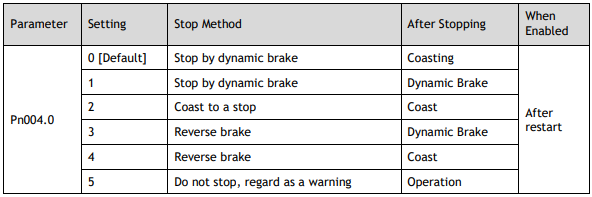
5.4.3 Motor Stop Methods for Gr.2 Alarms
You can select the Motor stopping methods for Gr.2 Alarms occur by setting the parameter Pn004.0
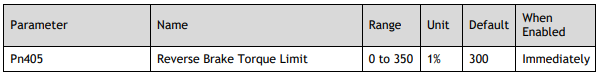
5.4.4 Reverse Brake Torque Limit Setting
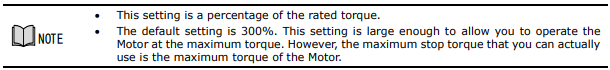
If Pn004.0 is set to 3 or 4, the Motor will be decelerated to a stop using the torque set in Pn405 as the
maximum torque.
5.5 Holding Brake
5.5.1 Function Description
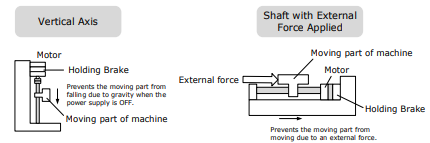
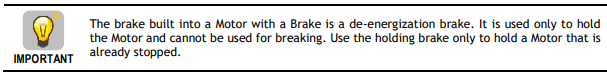
A holding brake is used to hold the position of the moving part of the machine when the Drive is turned OFF so that the moving part does not move due to gravity or an external force.
You can use the brake that is built into a Motor with a Brake, or you can provide one on the machine.
The holding brake is used in the following cases.
5.5.2 Brake Operating Sequence
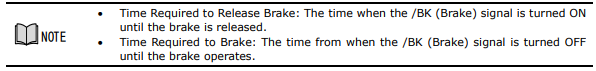
You must consider the time required to release the brake and the time required to brake to determine the brake operation timing, as described below.
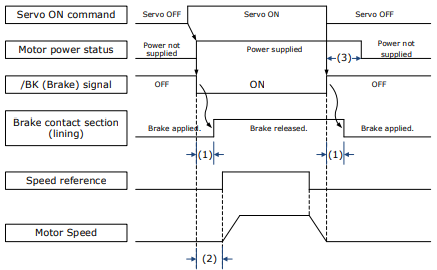
(1): The brake delay times for Motors with Holding Brakes.
(2): Before you output a reference from the host controller to the Drive, wait for at least 50 ms plus the time required to release the brake after you send the S-ON command.
(3): Use Pn506 (Servo OFF Waiting Time), Pn507 (Brake Enable Speed Threshold), and Pn508 (Brake Enable Waiting Time) to set the timing of when the brake will operate and when the servo will be turned OFF.
5.5.3 BK (Brake) Signal
The /BK signal is turned OFF (to operate the brake) when the Servo is turned OFF or when an alarm is detected. You can adjust the timing of brake operation (i.e., the timing of turning OFF the /BK signal) with the Servo OFF Waiting time (Pn506).
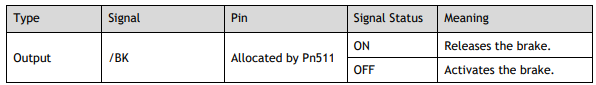
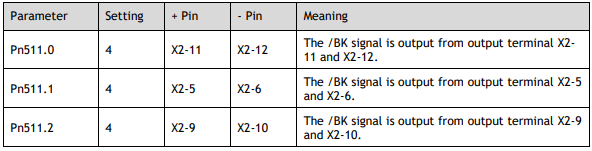
The /BK signal is not allocated in default setting, set its allocation in Pn511.
5.5.4 Output Timing of /BK Signal when Motor is Stopped
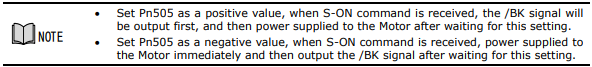
When the Motor is stopped, the /BK signal turns OFF as soon as the S-OFF (Servo OFF) command is
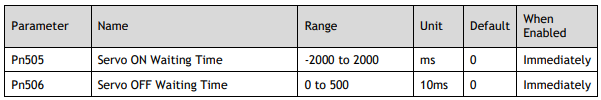
received. Use the servo OFF delay time (Pn506) to change the timing to turn OFF power supply to the
Motor after the S-OFF command is input.
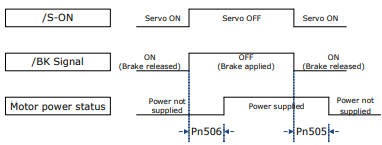
When the Motor is used to control a vertical axis, the machine moving part may move slightly due to gravity or an external force.
You can eliminate this slight motion by setting the servo OFF delay time (Pn506) so that power supply to the Motor is stopped after the brake is applied.
5.5.5 Output Timing of /BK Signal when Motor is operating
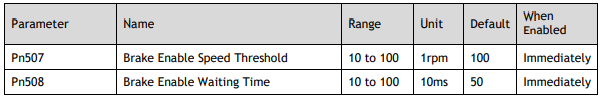
If an alarm occurs or S-OFF command is received while the Motor is operating, the Motor will start stopping and the /BK signal will be turned OFF. You can adjust the timing of /BK signal output by setting the Brake Enable Waiting Time (Pn508).
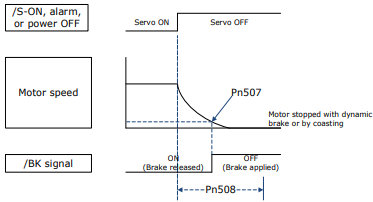
The /BK signal goes to H level (brake ON) when either of the following conditions is satisfied:
⚫ When the Motor speed falls below the level set in Pn507 after the power to the Motor is turned OFF.
⚫ When the time set in Pn508 is exceeded after the power to the Motor is turned OFF.
5.6 Encoder Settings
5.6.1 Absolute Encoder Selection
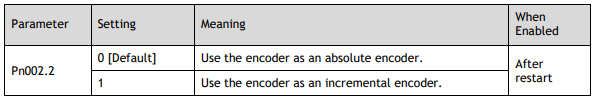
Absolute encoders are fitted on motors with an encoder type of L, e.g., MXL-02ALA211. These encoders require a battery supply to retain the absolute encoder data when the Drive power is removed.
With a system that uses an absolute encoder, the host controller can monitor the current position.
Therefore, it is not necessary to perform an origin return operation when the power supply to the system is turned ON.
There are two types of encoders for Motors. The usage of the encoder is specified in Pn002.2.
5.6.2 Encoder Alarm Resetting
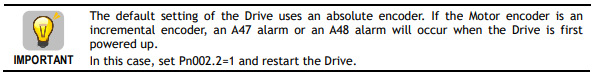
If alarm A.47 or A.48 occurs, replace the battery as soon as possible. After replacing the battery, perform the operation Absolute encoder alarm reset and Fn010 (Absolute encoder multi-turn reset.
For details about how to replace the battery and how to perform the replacement, see 3.5.4 Installing or Replacing a Battery.
5.6.3 Multiturn Limit Setting
The multiturn limit is used in position control for a turntable or other rotating body.
For example, consider a machine that moves the turntable shown in the following diagram in only one direction.
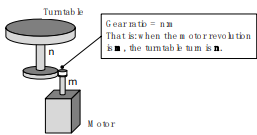
Because the turntable moves in only one direction, the upper limit to the number of revolutions that can be counted by an absolute encoder will eventually be exceeded.
The multiturn limit is used in cases like this to prevent fractions from being produced by the integral ratio of the number motor revolutions and the number of turntable revolutions.
For a machine with a gear ratio of n:m, as shown above, you can set Pn228 (OB 30A9h in EtherCAT) as m, and the value of m - 1 will be the setting for the multiturn limit setting.
The relationship between the number of turntable revolutions and the number of motor revolutions is shown in the following figure.
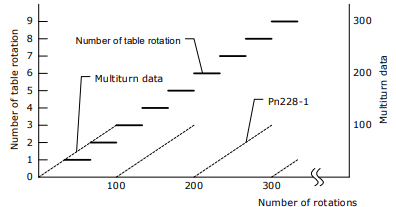


The data will change as shown below when this parameter is set to anything other than the default setting.
⚫ If the motor operates in the reverse direction when the multiturn data is 0, the multiturn data will change to the value set in (Pn228-1).
⚫ If the motor operates in the forward direction when the multiturn data is at the value set in (Pn228-1), the multiturn data will change to 0.

⚫ When you use a single-turn absolute encoder
⚫ When you set Pn002.2 = 1 (Use the encoder as an incremental encoder)
5.6.4 Encoder pulse dividing output
Pulse dividing signals.
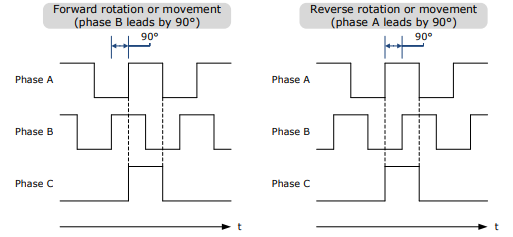
Encoder pulse dividing pulse output processes the signals sent from the encoder inside the driver, and outputs such signals to the outside in the form of two-phase pulses (Phase A, and Phase B) with 90° phase differential. It can be used as position feedback in the host controller.
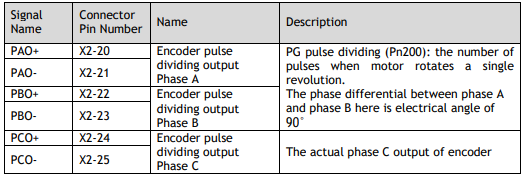
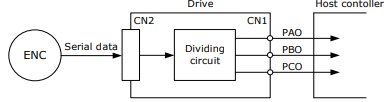
Note: Even in reverse mode (Pn001.0=1), the pulse dividing output phase form is the same as the standard setting (Pn001.0=0).
Output Phase Form
Pulse Dividing Ratio Setting
Encoder pulse dividing means that the divider converts data into the pulse density (Pn200) set by the user parameter based on the pulse data of the motor encoder, and outputs it. The setting unit is the number of pulses/revolutions.

⚫ Set the number of pulses for PG output signals (PAO,/PAO,PBO,/PBO) externally from the servo drive through Pn200.
⚫ Feedback pulses from the encoder per revolution are divided inside the servo drive by the number set in Pn200 before being output.
⚫ Set the encoder pulse dividing ratio according to the system specifications of the machine or host controller.
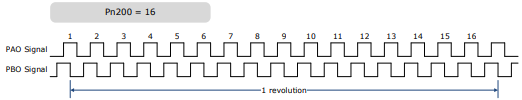
⚫ The setting of the encoder pulse dividing number is restricted by the encoder's resolution. [Output Example] Pn200=16 (when 16 pulses are output per revolution), the output examples of signals of encoder pulse dividing output phase A (PAO) signal and encoder pulse dividing output phase B (PBO) are shown below.
5.7 IO Signal Allocation
Functions are allocated to the pins on the I/O signal connector (X2) in advance. You can change the allocations and the polarity for some of the connector pins. Function allocations and polarity settings are made with parameters.
Operation panel can only display 5 digits. When distributing IO signals, it is necessary to display or set all the signals by page turning. The display instructions are detailed as follows (take Pn509 as an example).
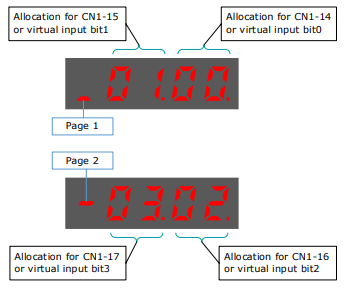
5.7.1 Input Signal Allocations
Allocation Description
X2 provides a total of 8 pin numbers available for allocation of input signals, corresponding to the subparameters of Pn509 and Pn510. Moreover, there are 8 virtual input bits controlled by Modbus communication, corresponding to the sub-parameters of Pn709 and Pn710.
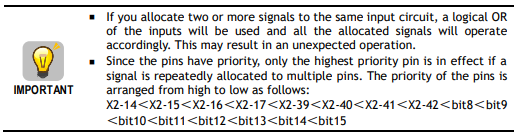
Default Input Signals
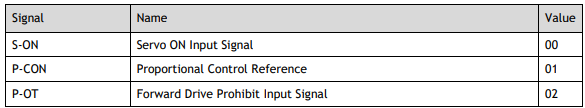
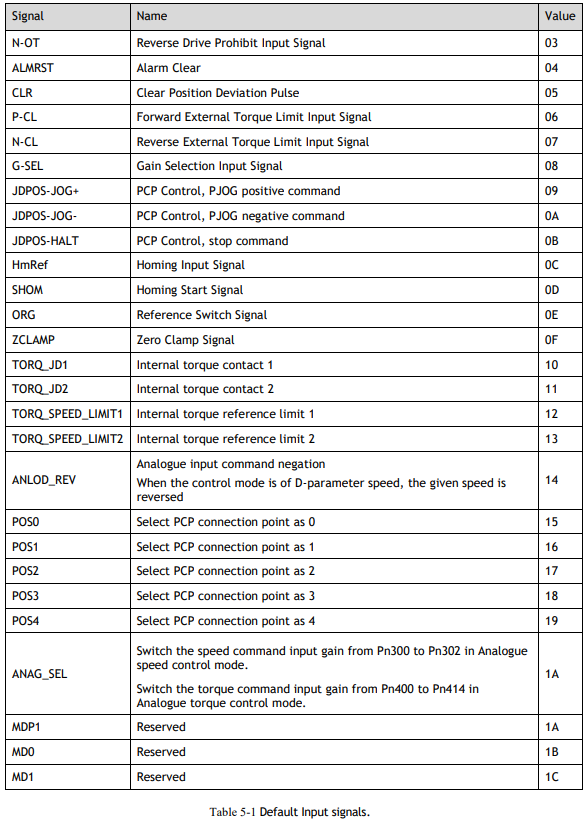
Table 5-1 lists the input signals that can be allocated and their corresponding values. Set the sub-parameters of Pn509, Pn510, Pn709 and Pn710 to use the following values, which means that they are allocated to the corresponding pins.
5.7.2 Output Signal Allocations
Allocation Description
The I/O signal connector (X2) on the Drive provides three groups of pins (points) for allocating the output signals, corresponding to the parameter Pn511, as is shown in Figure 5-2.
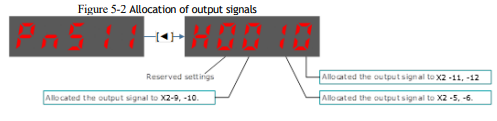
Default Output Signals
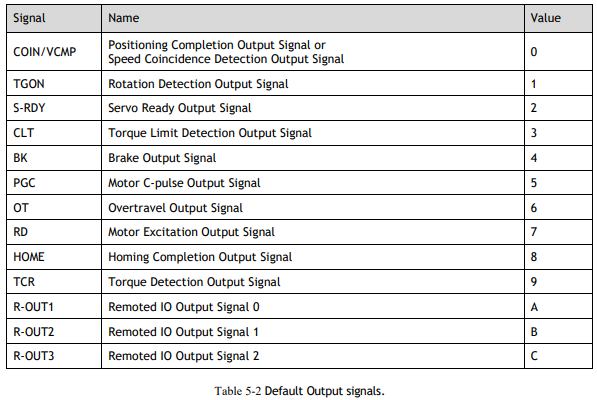
Table 5-2 lists the output signals that can be allocated and their corresponding values. Set the parameter Pn511 to use the following values, which means that they are allocated to the corresponding pins.
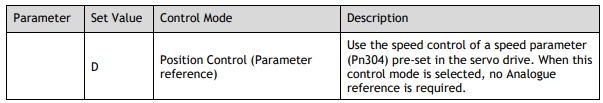
5.8 Control Mode Selection
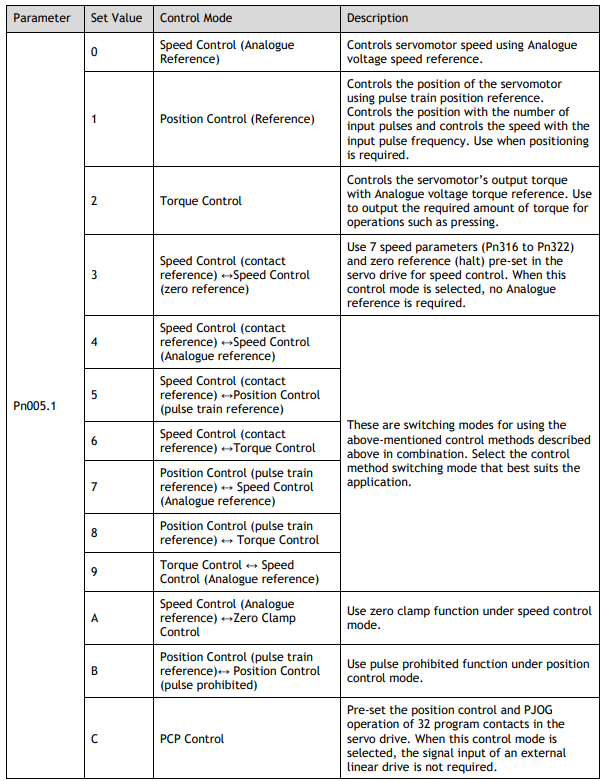
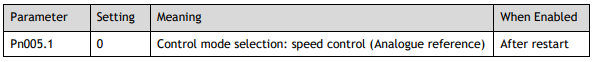
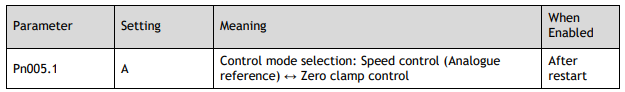
Speed control, position control and torque control are available to servo drive. Set through the control mode selection (Pn005.1).
5.9 Speed Control
Speed control is selected by Pn005.1:
5.9.1 Setting speed control
Speed reference input signal.
To control the speed of the servo motor at a speed proportional to the input voltage, it is necessary to set the speed reference input signal.
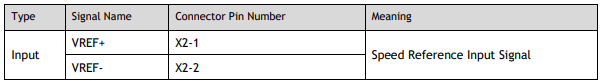
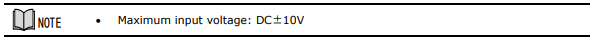
When performing position control by a host controller such as a programmable controller, connect it to the speed reference output terminal of the host controller.
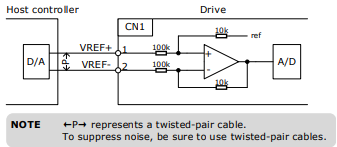
Setting speed reference input gain
Sets the Analogue voltage level for the speed reference (V-REF) necessary to operate the servomotor at the rated speed through Pn300.

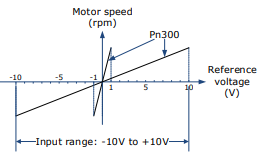
Speed Reference Input Example
Pn300=150 [factory setting]:
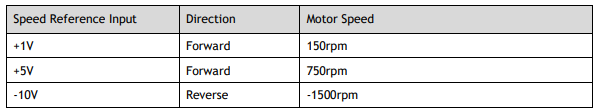
5.9.2 Adjustment of Speed Reference Offset:
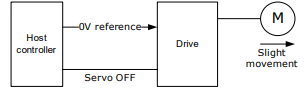
When speed control is used, even if the command is 0V (the command speed is 0 or haled), the servo motor may rotate at a slight speed. This is because there is a slight deviation in the reference inside the servo unit. This slight deviation is called "offset". When the servo motor is moving at a slight speed, it is necessary to use the offset adjustment function to eliminate the offset.
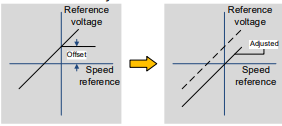
Auto Adjustment of Speed Reference Offset:
The auto adjustment of the Speed Reference Offset is a method for the servo drive to automatically adjust the voltage of the speed command after offset measurement.

The following provides the steps for auto adjustment of the Speed Reference Offset.
Step 1 Confirm that the servo drive is in the servo OFF state.
Step 2 Input 0V command voltage from the host controller or external circuit.
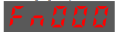
Step 3 Press [M] key several times to select the Utility Function Mode.
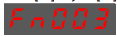
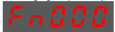
Step 4 Press [▲] key or [▼] key to select the function number Fn003.
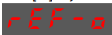
Step 5 Press [◄] key and the operating panel are displayed as follows.
Step 6 Press key to execute automatic offset adjustment.
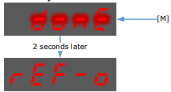
Step 7 Press the [◄] key to return to the display of the Fn003.
----End
Manual Adjustment of Speed Reference Offset
The manual adjustment of the speed reference offset is a method that inputs the speed command offset directly for adjustment. Use the manual adjustment in the following situations.
⚫ If a loop is formed with the host controller and the position error pulse is set to be zero when servo lock is stopped.
⚫ To deliberately set the offset to some value.
⚫ To check the offset data set in the speed reference offset auto adjustment mode.
⚫ The following provides the steps for manual adjustment of the Speed Reference Offset.
Step 1 Input 0V command voltage from the host controller or external circuit.
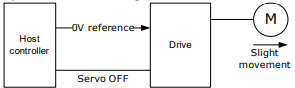
Step 2 Press [M] key on operating panel several times to select the Utility Function Mode.
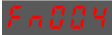
Step 3 Press [▲] key or [▼] key to select the function number Fn004.
Step 4 Press [◄] key and the operating panel are displayed as follows.
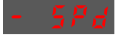
Step 5 Turn ON the servo S-ON signal, so that the servo drive enters the servo ON state.
Step 6 Press the [M] key for one second to display the current speed reference offset.
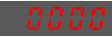
Step 7 Press [▲] key or [▼] key to adjust the offset manually.
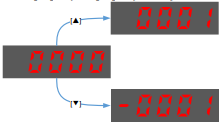
[Note] The adjustment range of the offset is -1024 to 1024.
Step 8 Press and hold the [◄] key for 1 second to return to the manual adjustment display.
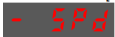
Step 9 Press the [M] key to return to the display of the Fn004.
----End
5.9.3 Soft Start
The soft start function converts the stepwise speed reference inside the drive to a consistent rate of acceleration and deceleration.
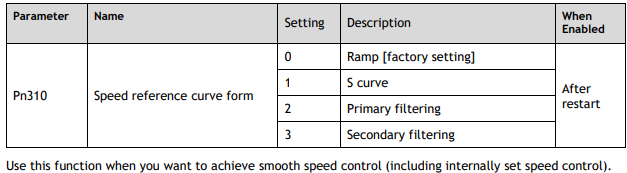
First, the user needs to select the running curve of the speed reference via Pn310 (speed reference curve form).
When speed reference uses ramp form (Pn310=0)
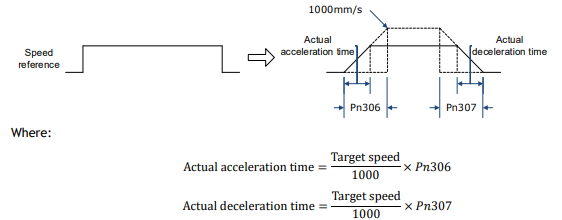
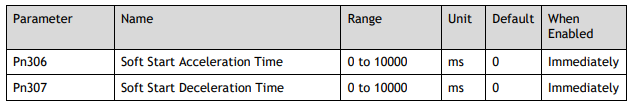
The figure below shows the timing diagram of the speed reference in the ramp form (Pn310=0). Among them, Pn306 is the time interval for the motor to accelerate from the stop state to speed of 1000rpm, and Pn307 is the time interval for the motor from 1000rpm to the stop state.
When speed reference uses S-curve (Pn310=1)
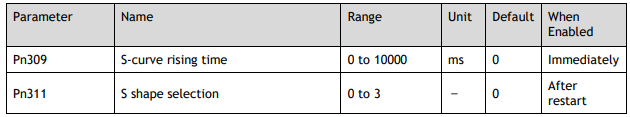
The figure below shows the timing diagram of the speed reference in the S-curve (Pn310=1). Among them, Pn309 is the time interval for the motor to accelerate from the stop state to the target speed, or the time interval for the motor to decelerate from the target speed to the stop state.
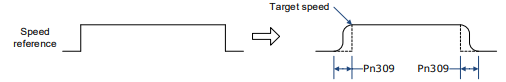
Moreover, transition form of the S-curve via Pn311 can also be selected. Users can try and choose the appropriate setting.
When speed reference uses filtering (Pn310=2 or 3)
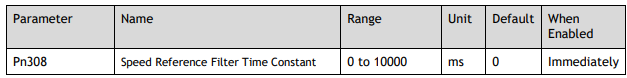
Pn308 (speed filter time constant) smooths the speed reference by applying a 1st-order delay filter that can be applied to the Analogue speed reference (VREF) input.
This parameter is generally not set. If the set value is too large, the responsiveness may be reduced. It is recommended to set while confirming responsiveness.
5.9.4 Zero Clamp Function
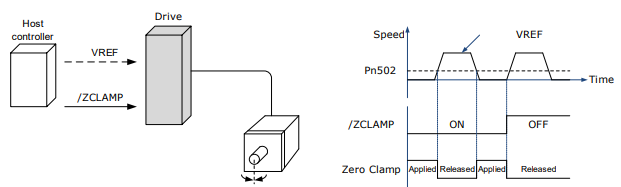
When the zero clamp function is used for speed control, the upper controller is a system that forms a loop.
The zero clamp function locks the servo when the input voltage of the speed reference (VREF) drops below the set speed in the zero clamp level parameter (Pn502) while the zero clamp signal (/ZCLAMP) is ON (low level). At this moment, a loop is formed inside the servo drive, ignoring the speed reference.
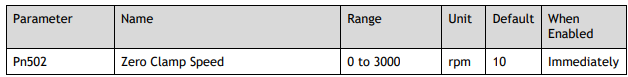
The servo motor is fixed within ±1 pulse of the zero clamp effective position. Even if it moves due to external force, it returns to the zero-clamp position.
Adjust the position loop gain in Pn104 (position loop gain) if the servomotor oscillates in the zero clamp state. If the gain switching function is used, adjusting Pn109 (2nd position loop gain) is also required.
Zero-Clamp Signal Allocations
The /ZCLAMP signal is not allocated in the factory setting, and the user needs to set it through Pn509 or Pn510.
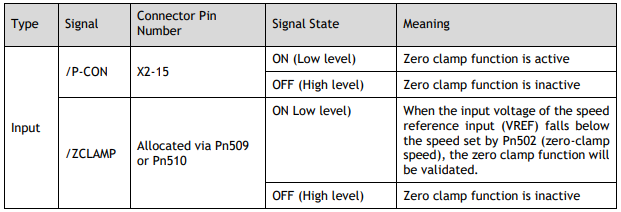
Setting Zero Clamp Function
When the control mode (Pn005.1) is set to A, the zero clamp function is active when the following two conditions are satisfied.
⚫ Low level when /P-CON is ON
⚫ The speed reference (VREF) drops below the set value of Pn502.
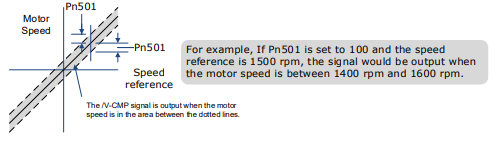
5.9.5 Speed Coincidence Detection (/VCMP) Signal
The Speed Coincidence Detection (/VCMP) Signal is the signal output when the speed of the servomotor coincides with the reference speed. It is used on occasions such as interlocking with the upper controller.
This output signal can only be used during speed control.
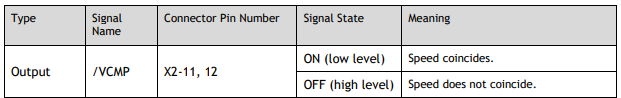

This output signal can be distributed to other output terminals via Pn511. For details, please refer to "5.7.2 Output Signal Allocation".
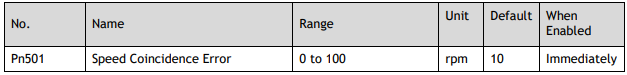
The VCMP signal is output when the difference between the motor speed and the reference speed drops below the set speed of Pn501.
5.10 Position Control