4. Motion Range
4.1. Motion Range Setting by Mechanical Stops
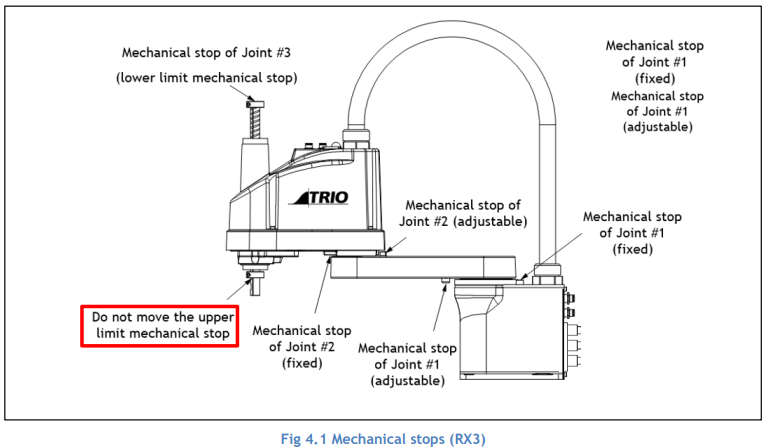
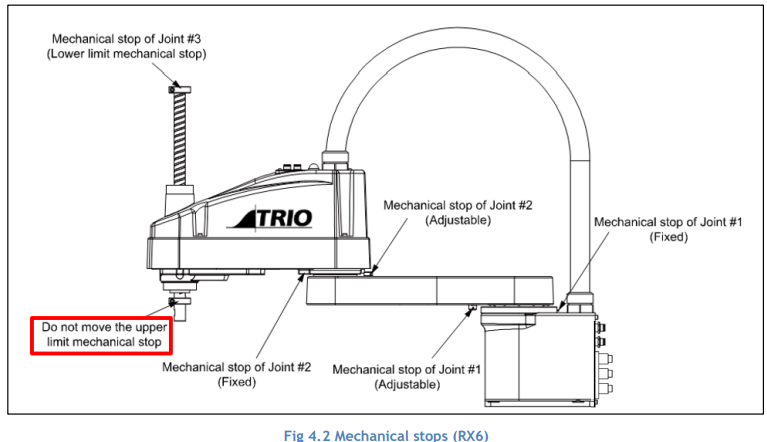
Mechanical stops physically limit the absolute area that the Robot can move.
4.1.1. Setting the Mechanical Stops of Joints #1 and #2
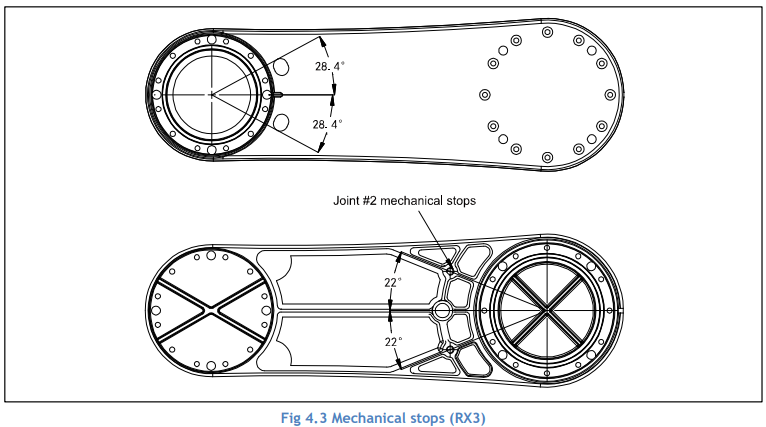
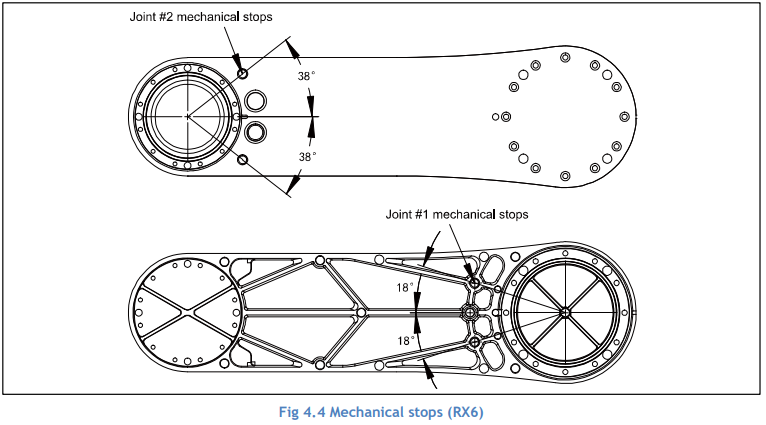
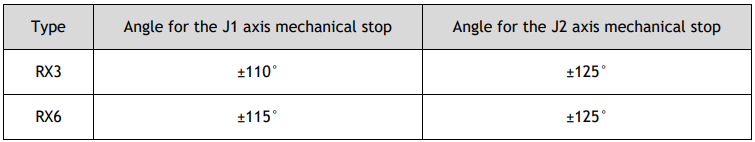
Both Joints #1 and #2 have threaded holes in the positions corresponding to the angle for the mechanical stop settings. Install the bolts in the holes corresponding to the angle that you want to set. The angle for Joint #3 can be set in any value within the maximum range.
Install the bolts for the mechanical stop to the following position.