
2. Basic Functions
2.1User Login
Click "User Login" on the Home screen, or press Fn+Arc Welding Application/Login on the teach
pendant to access the user login interface, as shown in the diagram below.
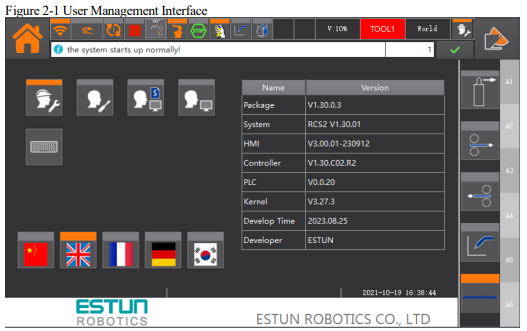
User Switching
The default user is "Guest", with three additional user types: "User", "Administrator" and "Debugging". These user types correspond to varying levels of operational permissions. To switch to another user type, click the drop-down list and select the desired user type, then enter the password to log in.
To modify the password of the currently logged-in user, click "Change Password" and input the desired new password twice in the pop-up dialog box. This action will update the password for the current user.
Language Selection
The default display language is "Simplified Chinese", and you can click on it to access the dropdown list and select "English" for the interface language.
2.2Log Information Management
Viewing System Logs
To view system logs, press "Log" on the teach pendant or click "Log Management" on the Home screen to access the system log interface, as shown in the diagram below.
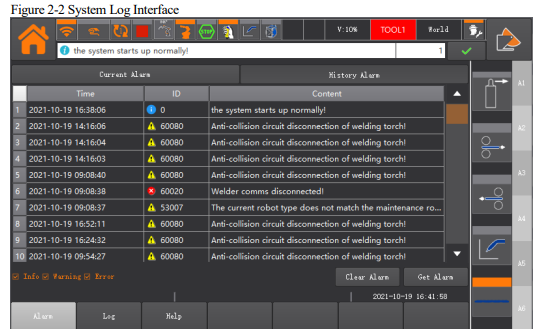
⚫ Clicking "Current Alarms" will display currently active alarms.
⚫ Clicking "Historical Alarms" will display alarm information that has occurred since the system was powered on.
⚫ Clicking "Clear Historical Alarms" will remove all historical alarm information.
⚫ Clicking "Retrieve Historical Alarms" will synchronize and update the historical alarm information from the controller.
⚫ If there are "Current Alarms", clicking "Clear Alarms" will remove the current alarms to resume normal operation.
⚫ Users can also click the clear alarm icon  on the right side of the alarm information column to perform alarm clearance.
Viewing and Exporting System Logs
There are two methods to view and export system logs:
⚫ Home → General Settings → System Diagnostics
⚫ Home → Advanced Settings → Local Settings → Disable Teach Pendant → ESTool
System Diagnostics
Clicking "System Diagnostics" in the General Settings interface will allow you to access the System Diagnostics page, as shown in the diagram below.
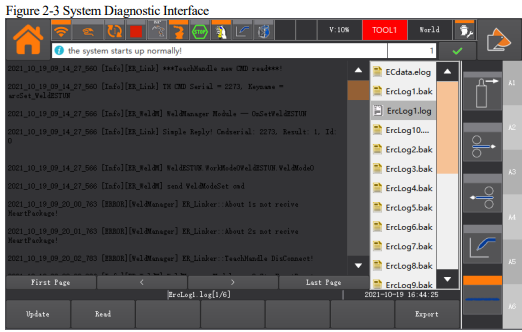
⚫ Clicking "Generate Report" will put the system into diagnostic mode and generate a report after a moment.
⚫ Clicking "ViewLog", the report of the most recent system diagnosis will appear. The log files of the diagnosis report include ERC.log (controller running log), ErrLog.txt (controller running fault log), RTstart.elog (controller startup log), etc.
⚫ To export the diagnosis log file, user needs to prepare a USB flash drive, insert it into the USB port of the programming pendant, then click "Export Log".
All log files will be exported to the root directory of the USB flash drive.
Start ESTool
When the programming pendant is connected and the user type has been switched to "Administrator", click the local settings in the System Home/Advanced Settings, and click "Turn off the teach pendant" in the local settings power management, as shown in figure below. Then, start ESTool to enter the maintenance mode of the teach pendant, and start ESTool by clicking keys in order.
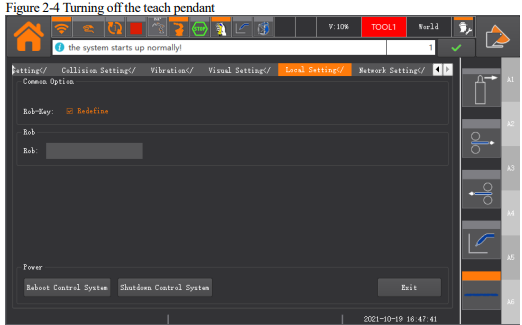
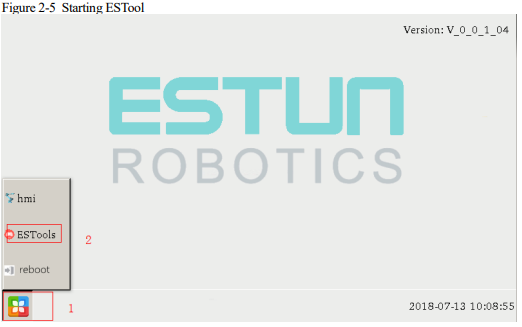
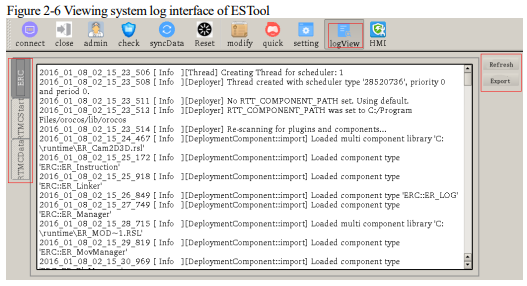
The system log files currently are available for viewing and exporting include ERC.log (controller running log), RTstart.log (controller startup log), and RTdata.elog (controller running data log).
After the ESTool is started, click logView; select the desired system log on the left side of the interface, and click “Refresh” to view the log information.
To export the system log file, insert the USB flash drive into the USB interface of the programming pendant, select the log file to be exported on the left side of the interface, click “Refresh” and “Export”.
2.3Project Management
Create a New Project or Program
Create a new project or a program by following the procedure below.
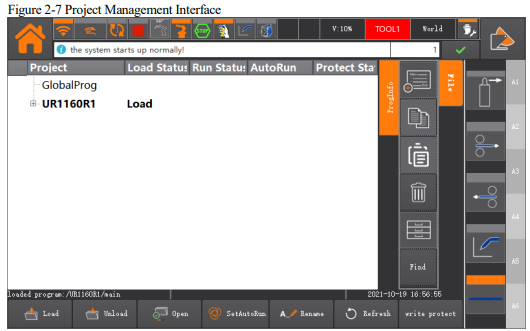
Step 1 Click the Project key, or the “Project Management” on the main interface to enter Project Management interface, as shown in figure below.
In the Project Management interface, click "Refresh" below to update the list of project.
Step 2 Select "File→New" on the right, and the "New Program" dialog box will pop up, as shown in Figure 4-2.
Tip
In other interfaces, select "File→New" on the right to perform the operation of creating a new project.
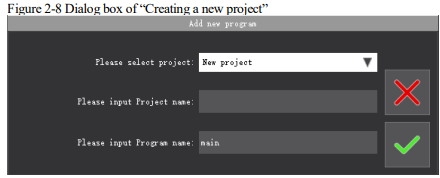
Step 3 To create a new project, select " New Project" from the drop-down list on the right of "Select a Project".
If you want to create a new job in a project, select the desired project name in the drop-down list and skip to Step 5.
Or, select a desired project in the project list in advance, and then click "Create".
If there is no program in the project list, the option "Create a Project” is in default.
Step 4 Click the input box of "Please enter the project name", and enter the name of the project to be created in the soft keyboard popped up, for example: project0.
Step 5 Click the input box of "Please enter the program name", and enter the name of the program to be created in the soft keyboard popped up, for example; program0.
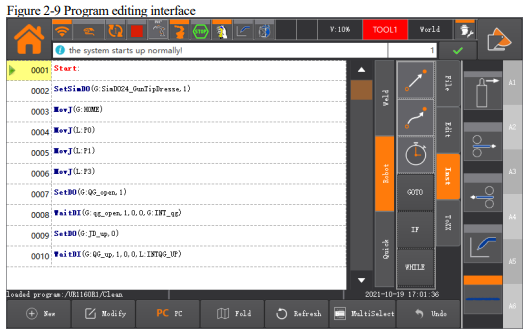
Step 6 Click "OK", a new project or program is then created. The interface jumps directly to the program editing interface, as shown in figure below.
---END
Delete a Project or Program
Delete a project or a program by following the procedure below.
Step 1 Click the project or program to be deleted in the Project Management interface, for example: project0.
Note
To delete a project that has been "loaded", you need to click "Cancel" below before performing the normal delete operation. To delete a program, you must ensure that the project in which the program is located is logged out before deleting.
Step 2 Click "Delete" on the right, and a prompt box will pop up, as shown in figure below.
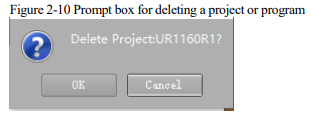
Step 3 Click "OK" to delete the project.
----END
Rename a Project or Program
Rename a project or a program by following the procedure below.
Step 1 Click the project or program to be renamed in the Project Management interface, for example:project0.
To rename a project that has been "loaded", you need to click "Cancel" below before performing the renaming operation.
Step 2 Click the "Rename" below.
Step 3 Click "Enter a new project name", and enter the new name in the pop-up soft keyboard.
Step 4 Click "OK", and the rename operation is done.
----END
Copy/paste a project or program
Copy and paste a project or a program by following the procedure below.
Step 1 Click a project or program to be copied in the Project Management interface, for example: project0.
Step 2 Click "Paste".
When a program is to be copied, if the pasted path is under another project, the prompt message "Unable to copy the program to another project!" will pop up. Please click and select the correct project before proceeding.
Step 3 Click "Please enter a new project name", and enter the new project name in the soft keyboard.
Step 4 Click "OK" to finish the copy/paste operation.
----END
Load/Cancel a Project or Program
In the project list, the "Loading Status" column already shows the project or program being loaded.
Only one project or program can be loaded. When another project or program is loaded, the previously loaded project or program will be automatically canceled.
To load or log off a project or program, click the project or program you want, and then click "Load" or "Cancel".
Self-triggered Program
In the project list, click the program that you want to enable for Auto Load. Then, click the "Selftriggered" option located below. In the dialog box that appears, click "OK" to complete the selftriggered setup for that program. When the user enables remote mode, the program will be automatically loaded.
Project Import/Export
Before performing the project import/export operation, the user needs to prepare a readable and writable USB flash drive, and then perform the following procedures.
⚫ Project Import: To import the project or program file in the USB flash drive to the controller.
⚫ Project Export: To export the project or program file in the controller to the USB flash drive.
The following operations are the procedures for project import, which is similar to project export.
Step 1 Insert the USB flash drive into the USB interface of the teach pendant.
Step 2 Click the Project Management, and enter the Project Management interface.
Step 3 Click "Manage" in the right menu to enter the interface, as shown in figure below.
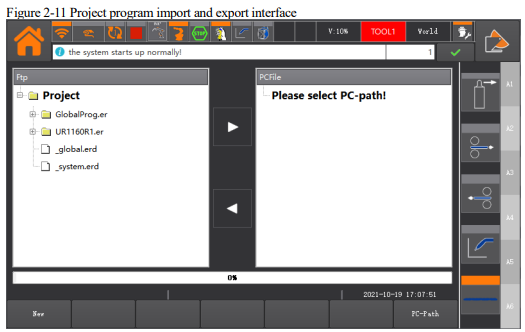
On the left side is the project file list within the teach pendant, and on the right side is the project file list within the USB flash drive.
Project Export
1. Select the program file to be exported from the list of "Project File" on the left.
2. Click ">>" in the middle of the interface to export the program file selected to the USB flash drive.
Project Import
1. Click the bottom.
2. Click on "<<" in the middle of the interface to import the selected program file to the controller.
Create
1. Click "Create" below, and the project create dialog box as shown in figure below will appear.
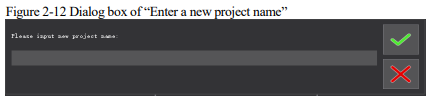
2. Click the input box of "Enter a new project name", and enter the name of the project to be created in the soft keyboard, for example, project0.
3. Click "OK" to produce a new project, prompting "Please reload the project". You can view the new project in the project file list in the teaching box on the left.
----END
2.4Program Management
Click "Program" on the teach pendant or click "Program Edit" on the Home screen to access the program editing interface.
Note
⚫ You need to load the project where the program is located before editing commands.
⚫ Program editing interface entered by clicking the menu key or through the Home interface is the program being loaded. Refer to “Load/cancel a project or program” for operation if there’s no program currently loaded.
⚫ Users may also click on the program being loaded in the Project Management interface, and then click "Open" at the bottom to enter the Program Editing interface. You can edit programs that have not been loaded under the project being loaded using this manner.
Add a New Command
Create a new command by following the procedure below.
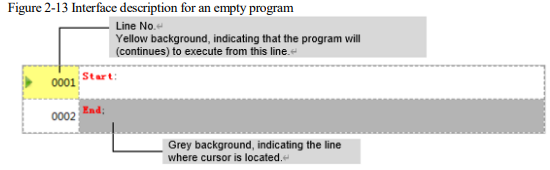
Step 1 Enter the program editing interface, as shown in 错误!未找到引用源。, which is an interface description for an empty program.
Move the cursor to the line where "End" is located when inserting the first command in the new program.
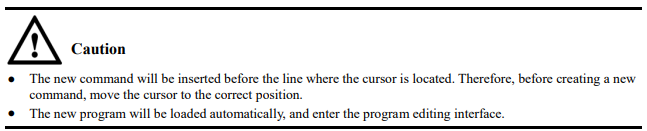
Step 2 Click "Create" at the interface bottom to enter the command selection interface, as shown in 错 误!未找到引用源。.
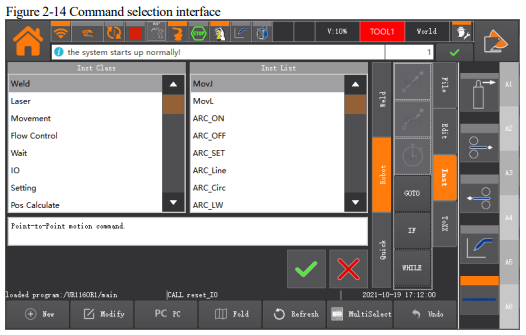
Step 3 Select "Command Class", and then select the command to be used on the right.
For example: if you need to create a new motion command MovJ, select "Motion Command→ MovJ".
Step 4 Click "OK" and enter the "Create Command" dialog box, where you can edit the command parameters you want to insert. Figure below shows the parameter editing dialog box of MovJ.
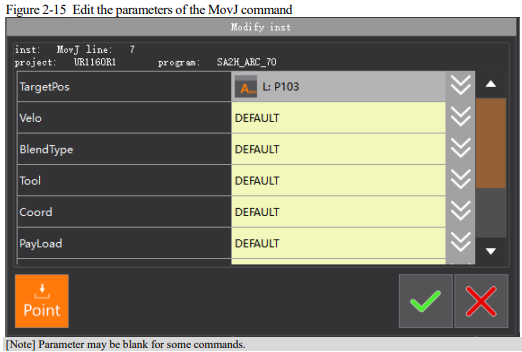
Step 5 Edit the parameters of the command based on actual requirements.
Following methods may be used for edition of different parameters:
⚫ Click the input box of the parameter, and enter the correct value in the soft keyboard.
⚫ Click the drop-down arrow behind the input box, and select the desired parameter from the drop-down list.
⚫ For the parameter denoting the position, click "Teach" if you want to select the current position as the parameter value.
Certain parameters may trigger the appearance of a variable list. Refer to the instructions in section 5.2 for guidance on editing variables.
Step 6 Click "Insert" after the parameter is edited.
A MovJ command is successfully inserted if the interface returns to the command editing interface, as shown in figure below.
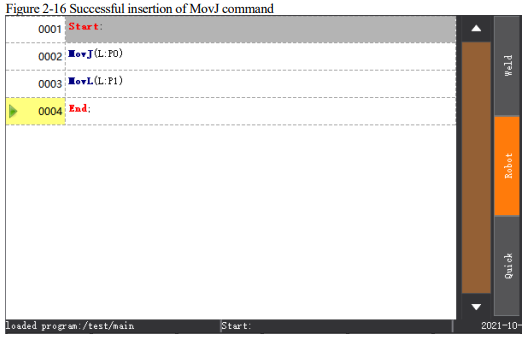
Step 7 Continue to add commands using the method described above.
Step 8 After checking and confirming that all program, you can return to the home interface for other operations.
----END
Cancel a Command
In case of an incorrect operation while editing the program, and you want to cancel the new or modified command, click "Cancel" in the command editing interface to withdraw and return to the previous step, as shown in figure below.
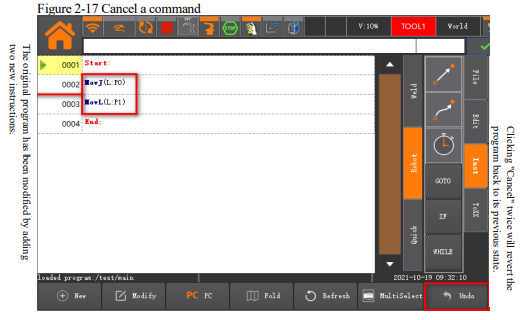
Note
Up to 64 steps of commands can be canceled.
If the program is canceled, loaded or reopened, this operation cannot be performed.
Other operations
Modifying Command Rapidly
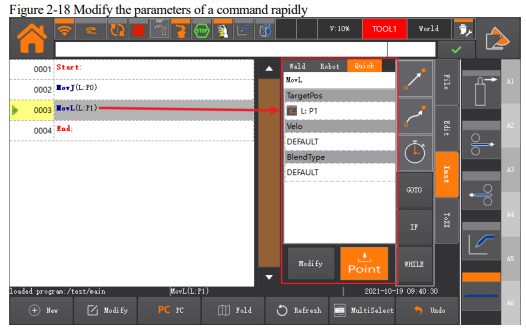
To modify a specific command, click on the command to be modified. This will open the "Quick Teach" panel on the right, where you can select the parameter you want to modify and proceed with the editing process, as shown in figure below.
After completing the modifications, click "Edit" to successfully update the parameters of that command.
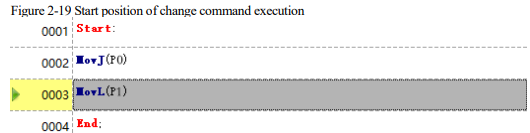
To specify the program to start execution from a command, click the command to be executed directly, and then click "PC" below, the pointer will change to the command, as shown in figure below. The, the command executing position has been changed to Line 0003.
Tips
Users can click on the "Command" on the right to create a frequently used command.
In addition, users can also click "Edit" on the right to perform the following operations on this interface:
⚫ Copy: Click to select the command to be copied, and then click "Copy". Cross-program "Copy" is supported.
⚫ Cut: Click to select the command to be cut, and then click "Cut". Cross-program "Cut" is supported.
⚫ Paste: Click to select the position of the command to be pasted, and then click "Paste". Cross-program "Paste" is supported.
⚫ Reverse Paste: Click to select the location of the command to be pasted, then click on "Reverse Paste" to paste the selected multiple lines of commands into the location in the reverse order. Cross-program "Reverse Paste" is supported.
⚫ Delete: Click to select the command to be deleted, and then click "Delete".
⚫ //: Click to select the command to be annotated, and then click "//".
⚫ ToPC: Click "ToPC" to return the program editing interface to the line where the pointer is located.
⚫ For a detailed description of each command, please refer to section 5.1.
One Point Reach by Command Point
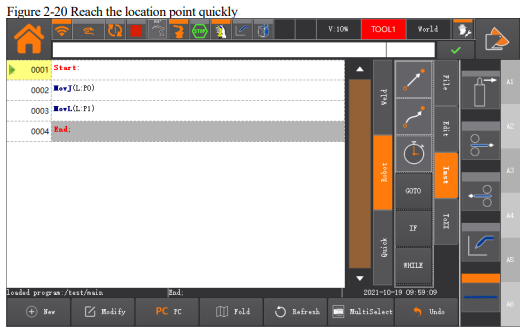
In manual mode, the user can locate the target point manually by clicking "Quick Reach" → "Location Point" on the right side of the program page, as shown in figure below
Select the target "point" and the running command "MovJ" or "MovL" in the floating options, and then press "Go", the TCP will continue to run to the target point; release "Go" to stop the movement of the TCP, as shown in figure below.
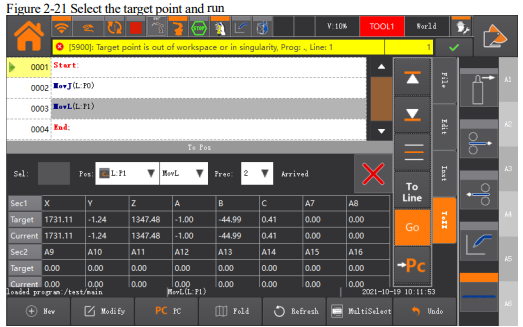
⚫ Please select the command line that specifies the target point, the "point" in the floating option will automatically show the variable of the target point.
When multiple points appear in the command line, you can select the desired target "point" in the drop-down list.
⚫ Only "MovJ" and "MovL" are optional for the command operation when running to the target point.
⚫ If the coordinate system parameters such as tool and usercoord are included in the command, switch the coordinate system to these set coordinates and perform point motion to avoid problems related to collision arising from execution errors
⚫ Select display precision, and adjust the decimal places for the data displayed in the table below.
Searching Program Line Rapidly
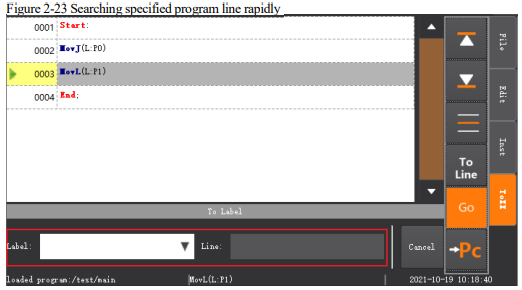
User can click "Quick Reach" on the right side in the program page, and select the position to be quickly located, such as "Top", "Bottom", "Select Line" or "Specify Line", as shown in figure below.
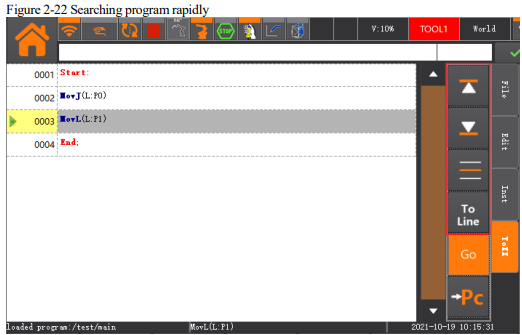
⚫ Click "Top", and the display of the program line will be located to the "Start" line.
⚫ Click "Bottom", and the display of the program line will be located to the "End" line.
⚫ Click "Select Line", and the display of the program line will be located to the position of the currently selected line.
⚫ Click "specified line"; select the "label" or "line number" to be located in the options appeared, and the display of the program line will be located to the designated one.
2.5 Location Management
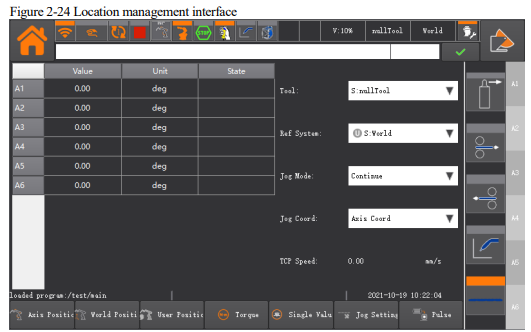
Click the "Location" key, or the "Location Management" in the "Jog Management" plugin group in
Home interface to enter the location management interface, as shown in figure below.
Joint Coordinates
Click "Joint Coordinates", and the current joint position information of the robot (A1, A2, A3, A4, A5, A6) will appear.
World Coordinates
Click "World Coordinates", the position information (X, Y, Z, A, B, C) of the robot TCP in the World Coordinates will appear.
User Coordinates
If the “Reference Coordinates” is set to “G: USERCOOR”, clicking “User Coordinates”, the position information of the robot TCP in the User Coordinates (RX, RY, RZ, RA, RB, RC) will appear.
External Tool Coordinates
If the “Reference Coordinates” is set to “G: EXTTCP”, clicking “External Tool Coordinates”, the position information of the robot TCP in the External Tool Coordinates (EX, EY, EZ, EA, EB, EC) will appear.
Positioner Coordinates
If the “Reference Coordinates” is set to “G: POSITIONER””, clicking “Positioner Coordinates”, the position information of the robot TCP in the Positioner Coordinates (PX, PY, PZ, PA, PB, PC) will appear.
Torque
Clicking "Torque", the rated torque value (percentage) of each joint motor of the robot will appear.
Single-turn Value
Clicking "Single-turn Value", the left side of the interface displays the set single-turn value of each axis (set by clicking the right position), and the right side displays the actual single-turn value of each axis.
Inching Setting
If "Jog Mode" is set to "Inching", click "Inching Setting", the inching parameters of each axis of the robot will appear. To modify the jogging parameters, just click the parameter value input box and enter the value to be modified in the pop-up soft keyboard. Alternatively, you can press the "Jog/Continuous" key on the teach pendant or use the "Jog/Continuous" button on the right side of the interface to switch between Inching and Continuous modes.
Users can modify the "Jog Coordinates" to the coordinate system requiring jog operation, or press the "Coordinates" key on the programming pendant to switch the coordinates requiring jog operation.
Homing
When the robot is in servo excitation state, click "Home" and enter the correct administrator password in the pop-up dialog box. After that, a prompt message will pop up on the interface, as shown in figure below.
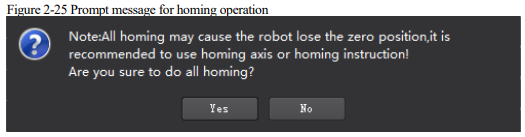
Click "OK" to initiate the homing operation.
2.6Program Data
Press the "Variable" key or click "Program Data" on the Home interface to enter the Program Data interface.
Click "Refresh" below to update the variable list in this interface.
Program data (variables) is of four ranges: System, Global, Project and Program.
⚫ System (S): The variables as initially defined by the system.
⚫ Global (G): The variables that can be used by all projects or programs.
⚫ Project (P): The variables that can be used by programs in the same project.
⚫ Program (L): The variables that can only be used in the current program.
Different domains support different types of variable. For details, please refer to "5.2 Type of Common Variables".
Create Variable
Create a new variable by following the commands below.
Step 1 Enter the program data interface, as shown in figure below.
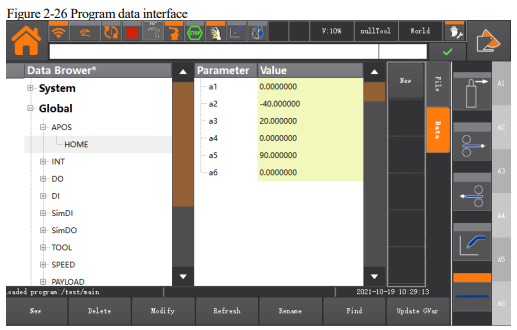
Step 2 Click on the range to be created, such as "Global".
Step 3 Click "Create" and set the relevant parameters in the pop-up dialog box, as shown in figure below.
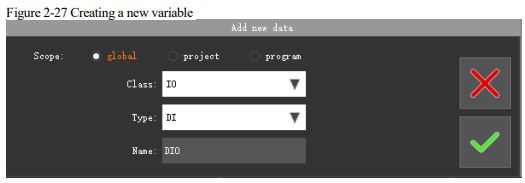
Step 4 Confirm or select the "Domain" (range) to which the variable to be created belongs.
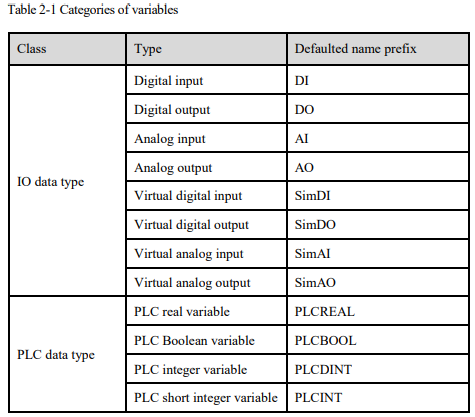
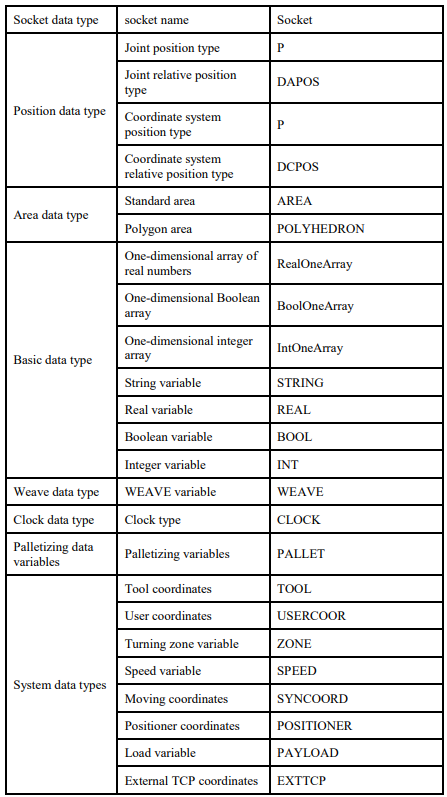
Step 5 Set the category of the variable to be created. Table below lists all the categories and types.
Step 6 Click the "Name" input box, and enter the name you want to define in the pop-up soft keyboard.
Note
The following "names" are reserved by the system. Users may not create variables with the same name;
abs, acos, and, asin, assert, atan, break, ceil, collectgarbage, coroutine, cos, debug, deg, do, dofile, else, elseif, end, error, exp, false, findEnd, floor, fmod, for, format, function, getAt, getmetatable, goto, huge, if, in, io, ipairs, left, load, loadfile, local, log, math, max, min, modf, next, nil, not, or, os, package, pairs, pcall, pi, print, rad, random, randomseed, rawequal, rawget, rawset, real, repeat, require, return, reverse, right, select, strcmp, setmetatable, sin, sqrt, string, table, tan, then, tonumber, tostring, true, type, until, while, xpcall, AI, AO, APOS, APosToCPos, APosToStr, AREA, AreaActivate, AreaDeactivate, ARRAYS, BitAnd, BitNeg, BitOr, BitXOr, BitLSH, BitRSH, BOOL, CalcTool, CalcCoord, CALL, CenterPos, CLKRead, CLKReset, CLKStart, CLKStop, CLOCK, CompareAI, CompareSimAI, CPOS, CPosToAPos, CPosToCPos, CPosToStr, DAPOS, DCPOS, DI, DO, ELSE, ELSIF, ENDIF, ENDWHILE, EXTTCP, GetCamPos, GetCurAPos, GetCurCPos, GetCurOverRide, GetDI8421, GetMatrix, GetSimAIToVar, GetSimDI8421, GetSimDIToVar, GetTrackId, GOTO, Hand, IF, InertiaTensor, INT, IToStr, LABEL, LoadDyn, MovArch, MovC, MovCW, MovCircle, MovCircleW, MovE, MovH, MovJ, MovJRel, MovJSearch, MovL, MovLRel, MovLSearch, MovLSync, MovJSyncQuit, MovLSyncQuit, MovLW, OnDistance, OnParameter, PalletFromGet, PalletFromPut, PalletReset, PalletToGet, PalletToPut, PAYLOAD, PLCBOOL, PLCDINT, PLCINT, PLCREAL, POLYHEDRON, PolyhedronAreaActivate, PolyhedronAreaDeactivate, POSCFG, POSITIONER, PulseOut, PulseSimOut, ReadModbusReg, REAL, RefRobotAxis, RET, RETURN, RToStr, RUN, SendMessage, SetAxisVibraBLevel, SetAO, SetCartDyn, SetCoord, SetDIEdge, SetDO, SetDO8421, SetExternalTCP, SetJointDyn, SetMotionMode, SetOverRide, SetPayload, SetPositioner, SetRestorePC, SetRtInfo, SetRtToErr, SetRtWarning, SetMatrix, SetSimAO, SetSimAOByVar, SetSimDIEdge, SetSimDO, SetSimDO8421, SetSimDOByVar, SetTargetPos, SetTool, SetSyncoord, SimAI, SimAO, SimDI, SimDO, SocketClose, SocketCreate, SocketReadInt, SocketReadReal, SocketReadStr, SocketSendStr, SoftFloatStart, SoftFloatStop, SPEED, Stop, STRING, StrToI, StrToR, SYNCOORD, SynCToUserC, TOOL, Tracking, TranStrToApos, TranStrToCpos, TranStrToInt, TranStrToReal, TrigCam, trimLeft, trimRight, USERCOOR, Wait, WaitAI, WaitCondition, WaitConvDis, WaitDI, WaitDI8421, Waitfinish, WaitFinishCAM, WaitSimAI, WaitSimDI, WaitSimDI8421, WaitWObj, WEAVE, WHILE, WriteModbusReg, ZONE, ToolOffset, UserOffset, ARC_ON, ARC_OFF, ARC_SET, ARC_WireFeed, ARC_WireFeedBack, ARC_WireSpeed, ARC_GasFeed, ARC_Line, ARC_Circ, SetWeaveCFG, ARC_StichL, ARC_SegmentL, ARC_StichC, ARC_LW, ARC_CW, ARC_Fast, WaitArcOn, SetwelderMode, SetBlendParam, SetBurnTime, ARC_Count, SetCloosJOB, ConnectLaser, DisconnectLaser, OpenLaser, CoseLaser, MuteLaser, SetLaserTaskNum, GetLaserPos, Laser_Search, MovLTrack, SetwelderThoughGap, LoadMatrix, Calibrate_ON, Calibrate_OFF, Search_ON, Search_OFF, Calibrate_Search, Sensor_Search, TouchOffset_ON, TouchOffset_OFF.
Step 7 Click “OK” after confirming that the variable to be created is set correctly.
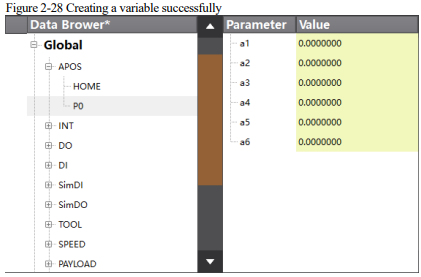
The interface will return to the list of variables and display the created variable data. Figure below shows that a global position variable P0 has been added.
----END
Standard Area Variables
Create a new standard area variable by following the steps below.
Step 1 Enter the program data interface and click "Create".
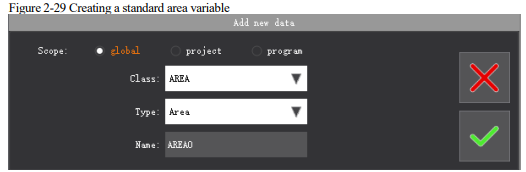
Step 2 Select "Class" as "Area Data Type" and "Type" as "Standard Area" from the pop-up dialog box, and enter the "Name", for example, AREA1, as shown in figure below.
Step 3 Click “OK” after settings of the area variables to be created are confirmed to be correct.
Step 4 The interface will return to the list of variables and display the created variable data. Figure below shows that a global area variable AREA1 has been created successfully.
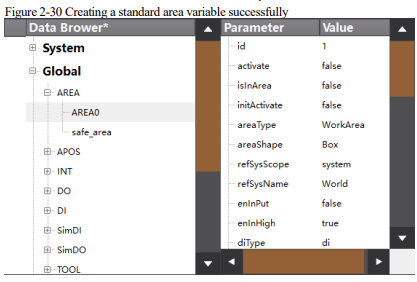
----END
Polygon Area Variables
Create a new polyhedron area variable by following the steps below.
Step 1 Enter the program data interface and click "Create".
Step 2 Select "Class" as "Area Data Type" and "Type" as "Polyhedron" from the pop-up dialog box, and enter the "Name", for example, POLYHEDRON1, as shown in figure below.
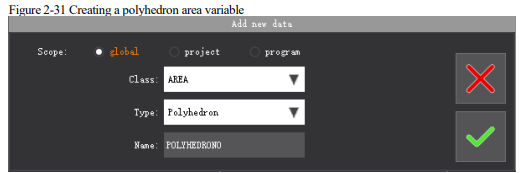
Step 3 Click “OK” after settings of the polyhedron area variables to be created are confirmed to be correct.
Step 4 The interface will return to the list of variables and display the created variable data. Figure below shows that a global polyhedron area variable POLYHEDRON1 has been created successfully
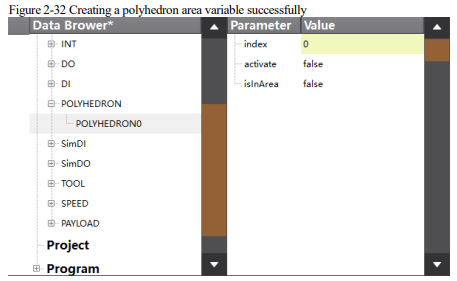
----END
Tool Coordinates Variables
Create a tool coordinates variable by following the procedure below.
Step 1 Enter the program data interface and click "Create".
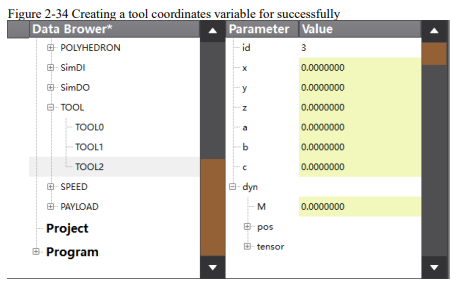
Step 2 Select "Class" as "System Data Type", and "Type" as "Tool Coordinates" in the pop-up dialog box, and enter the "Name" (TOOL0), as shown in figure below.
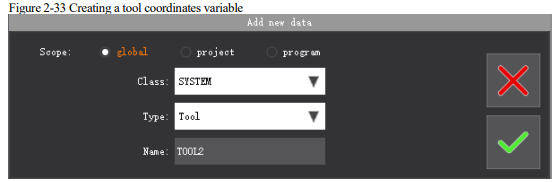
Step 3 Click “OK” after settings of the tool coordinates variable to be created are confirmed to be correct.
Step 4 The interface will return to the list of variables and display the created variable data. Figure below shows that a global variable TOOL0 for tool coordinates has been created successfully
----END
User Coordinates Variables
Create a user coordinates variable by following the procedure below.
Step 1 Enter the program data interface and click "Create".
Step 2 Select "Class" as "System Data Type", and "Type" as "User Coordinates" in the pop-up dialog box, and enter the "Name" (USERCOOR1), as shown in figure below.
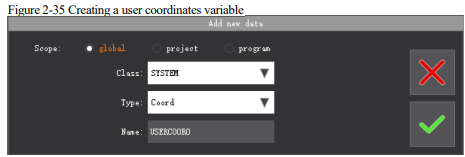
Step 3 Click “OK” after settings of the user coordinates variable to be created are confirmed to be correct.
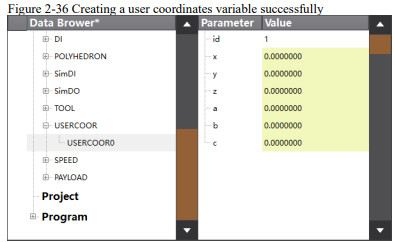
Step 4 The interface will return to the list of variables and display the created variable data. Figure below shows that a global user coordinates variable USERCOOR1 has been created successfully.
----END
External Tool Coordinates Variables
Create an external Tool Coordinates variable by following the procedure below.
Step 1 Enter the program data interface and click "Create".
Step 2 Select "Class" as "System Data Type", and "Type" as "External TCP Coordinates" in the pop-up dialog box, and enter the "Name" (e.g. EXTTCP1), as shown in figure below.
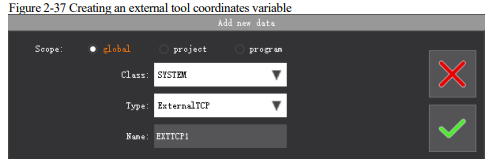
Step 3 Click “OK” after settings of the external tool coordinates variable to be created are confirmed to be correct.
Step 4 The interface will return to the list of variables and display the created variable data. Figure below shows that a global external tool coordinates variable EXTTCP1 has been created successfully.
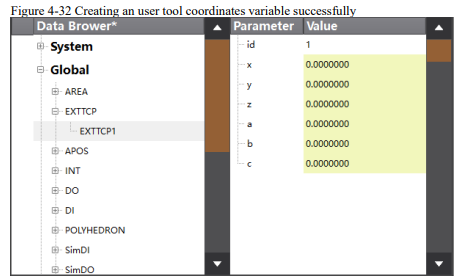
----END
Other Operations
Modifying Variable Value
Modify the value of a variable by following the procedure below:
Step 1 Select the variable to be modified, and “Parameters” and “value” of the variable will appear on the right side of the interface.
Step 2 Click the parameter value to be modified and re-enter the correct value in the pop-up soft keyboard.
For some special variables, click "Modify", and the interface will display the modification interface to assist operation.
----END
Deleting a Variable
Select the variable to be deleted, click "Delete", then the prompt box shown in figure below will pop up.
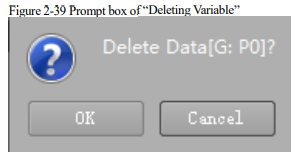
Click "OK" to delete the variable.
Renaming a Variable
Select the variable to be renamed, the "Change Variable Name" interface will pop up by clicking
"Rename", as shown in figure below.
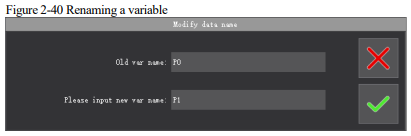
Click the input box of "New variable name", and type the desired name in the pop-up soft keyboard. Then click "OK". The variable renaming is done.
Searching Variable
Click "Search" in the "List of Variable" page, and enter the "Name" of the variable you want to search in the floated option, as shown in figure below.
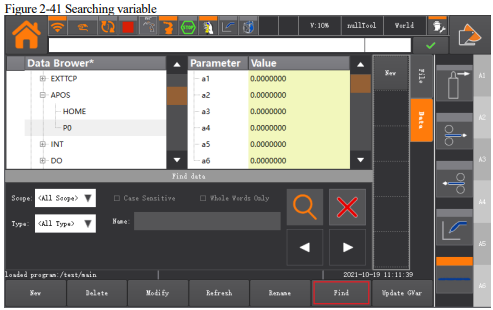
⚫ You can find the desired variable precisely by selecting the "Domain" or "Type" you want to search.
⚫ When a matching name is searched, multiple results appear. You can select by clicking "Previous" or "Next".
2.7IO Detection
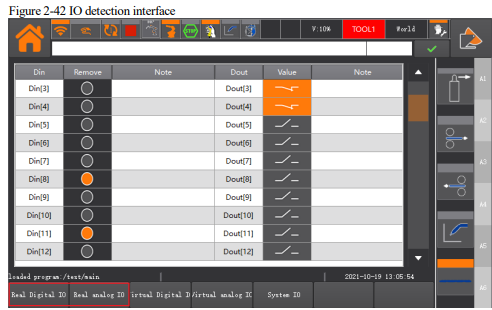
Press the "I/O" key or click "IO Detection" on the Home screen to access the I/O detection interface, as shown in the figure below.
Physical IO
Upon entering the I/O detection interface, the default view displays the "Physical IO" list, allowing you to observe the operational status of the physical I/Os.
Users can view the IO status on the control module through this interface: 0 means low level; 1 means high level.
Din is for digital input port; Dout is for digital output port; Ain is for analog input port, and Aout is for analog output port.
⚫ To detect a digital input port, user needs to change the signal state of a port (change the status of corresponding relay), and then check if the port value in the interface has changed.
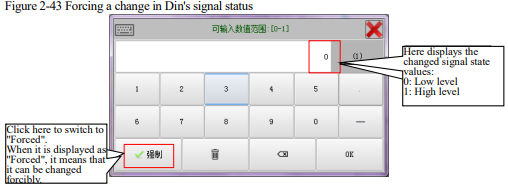
To facilitate the detection, you can click the "Value" of the input port to be changed in the interface, and enter the changed value in the pop-up soft keyboard, and then click the button on the lower left side of the soft keyboard to switch to "Force", as shown in the diagram below, to change the status of the port forcibly.
Note
The change in the "Forced" signal only affects the way the program judges the input port's state; it does not alter the actual relay state, nor does it update the rising or falling edge status of the input port.
⚫ To detect a digital output port, click the "Value" of an output port, and enter the value (0 or 1) to be modified in the pop-up soft keyboard, and then check if the level of the corresponding port has changed with a multimeter.
⚫ To detect the analog input port, user needs to specify the level (e.g. 5V) for the corresponding input port, and then the interface will display the voltage value of the port.
⚫ To detect the analog output port, click the "value" of an output port, and enter the voltage value to be modified in the pop-up soft keyboard (5V will appear on the interface), and check if the voltage value of the corresponding port is 5V using a multimeter.
Virtual IO
Click "Virtual IO" below to view the working status of virtual IO, as shown in figure below
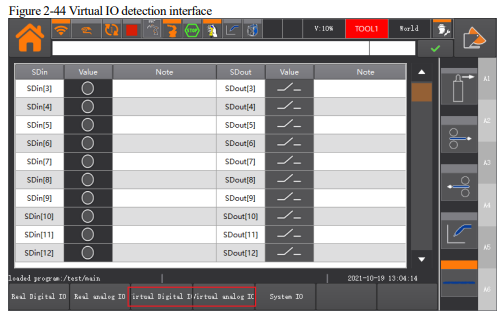
In this interface, users can view the status of virtual IO.
SDin is for virtual digital input port; SDout is for virtual digital output port; SAinis for virtual analog input port, and SAout is for virtual analog output port.
System IO
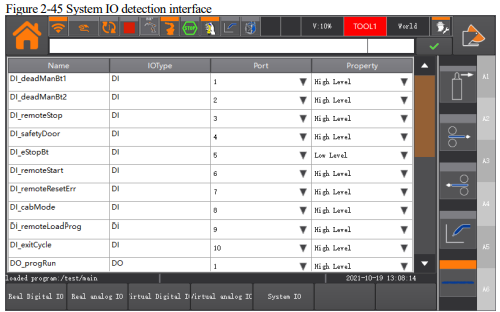
Clicking the [System IO] key and entering the password in the pop-up dialog box, then you can enter the system IO configuration interface. In this interface, you can configure all the IO ports corresponded to the system IOs and effective levels. Figure below shows the system IO configuration interface.
No comments to display
No comments to display