
6. CiA402 Drive Profile
6.1 Conversion Factor Setting
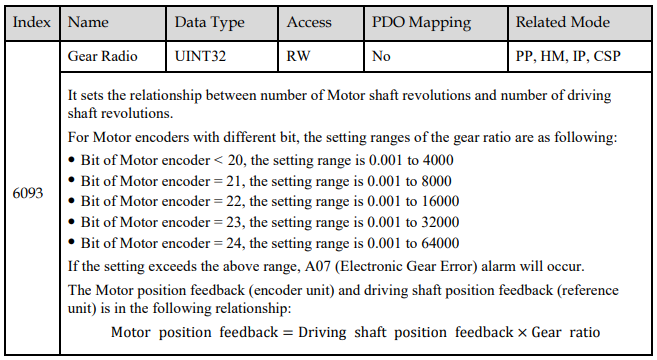
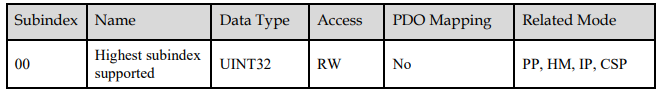
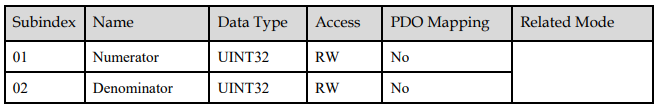
Gear Ratio (6093h)
The gear ratio indicates the Motor displacement (in encoder unit) corresponding to the driving shaft displacement of one reference unit.
The gear ratio is defined by the numerator (6091-01h) and denominator (6091-02h). It determines the relationship between the driving shaft displacement (in reference unit) and the Motor displacement (in encoder unit):
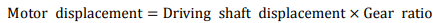
The Motor is connected with the load through the reduction wheel and other mechanical transmission mechanism. The gear ratio is calculated based on parameters such as the mechanical reduction ratio, mechanical size and Motor resolutions:
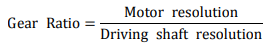
The resolutions of the Motor encoder with different bit are as follows:
The general incremental encoder outputs 10,000 pulses per 1 revolution
The resolver outputs 65536 pulses per 1 revolution
The 17-bit encoder outputs 131072 pulses per 1 revolution
The 20-bit encoder outputs 1048576 pulses per 1 revolution
The 23-bit encoder outputs 8388608 pulses per 1 revolution
Setting Example
Take the load ball screw as an example: Minimum reference unit fc=1 mm, Lead pB=10 mm/r, Reduction ratio n=5:1, 20-bit incremental encoder resolution P=1048576;
The gear ratio is calculated as follows:
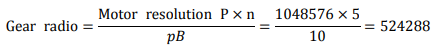
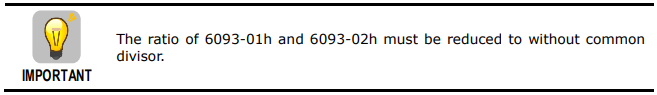
Therefore, 6093-01h=524288, 6093-01h=1, which means that when the driving shaft displacement is 1, the Motor displacement is 524288.
6.2 Device Control
6.2.1 CiA402 State Machine
The Drive runs in the specified status only when it is instructed according to the flowchart defined in CiA402.
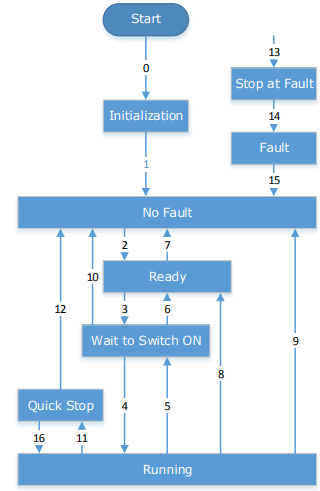
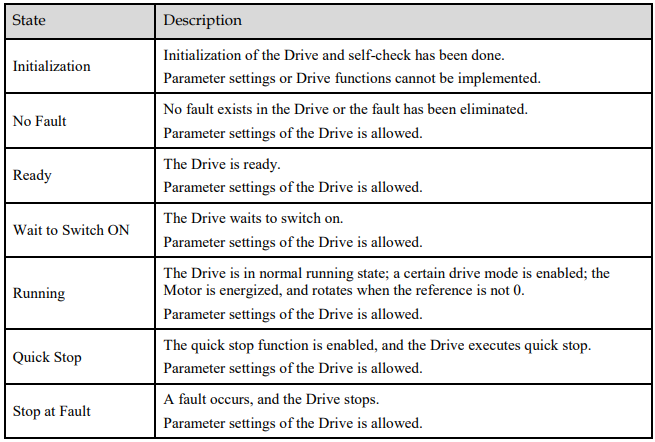
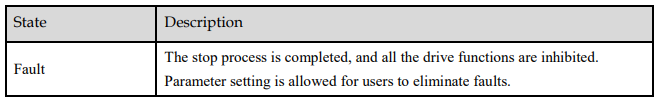
The states are described in the following table.
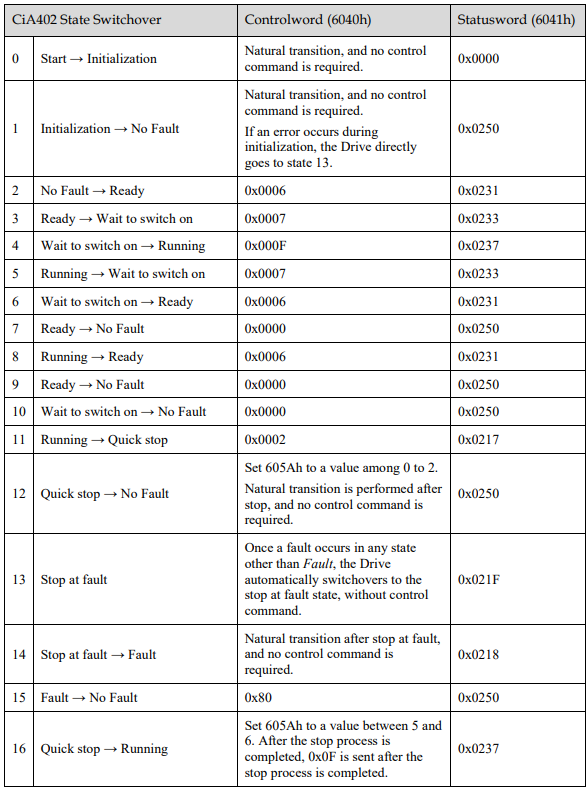
The control commands and state switchover are described as follows:
6.2.2 Stop Modes
The Drive supports 5 stop modes described as below sections.
Quick Stop Option Code (605Ah)
This object determines what operation will be performed if a Quick Stop is executed
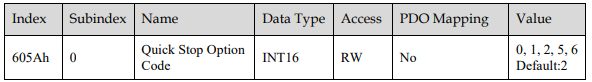
The meanings of Value are as follows:
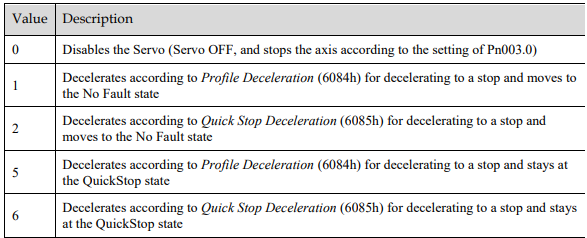
605Bh (Shutdown Option Code)
This object defines the operation that is performed if there is a move from Operation Enable state to Ready state.
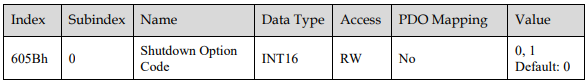
605Ch: Disable Operation Option Code
This object defines the operation that is performed if there is a move from Operation Enable state to Switched ON state.
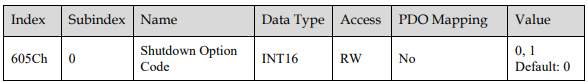
The meanings of Value are as follows:
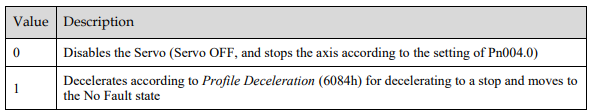
605Dh: Halt Option Code
This object defines the operation that is performed if bit 8 (Halt) in Controlword is active.
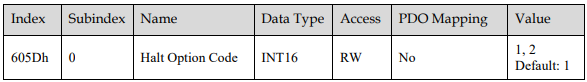
The meanings of Value are as follows:
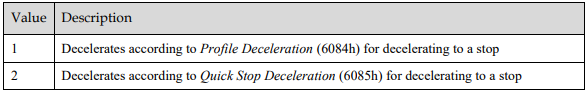
605Eh: Fault Reaction Option Code
This object defines the operation that is performed when an alarm is detected in the Servo System.
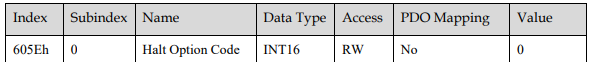
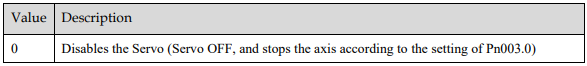
The meaning of Value is as follows:
6.3 Control Modes
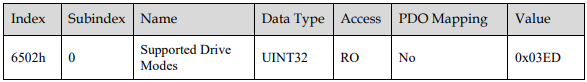
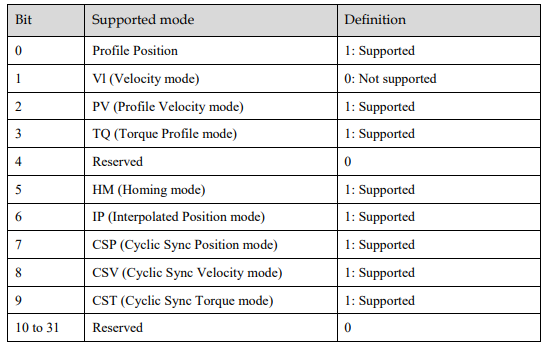
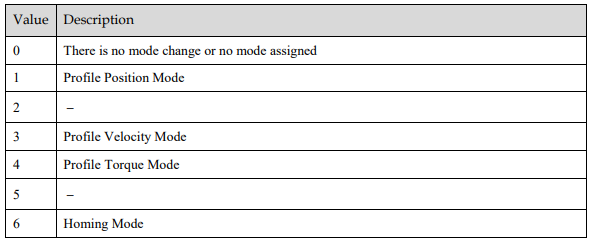
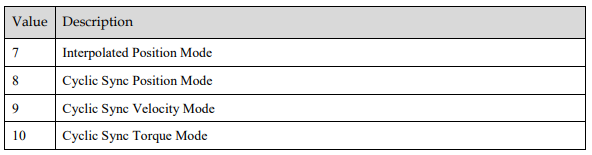
The Drive supports 8 control modes as defined in 6502h.
6.3.1 Modes of Operation
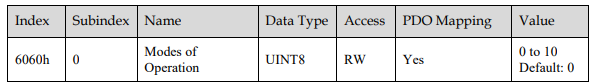
This object is used to select the operation mode. The Servo System gives the actual operation mode in the Modes of Operation Display object.
6.3.2 Modes of Operation Display
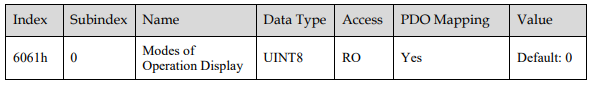
This object gives the current mode of operation.
6.3.3 Mode Change
Note the following when changing the control mode.
After changing from Position Control Mode (PP mode or CSP mode) to other modes, the unexecuted position command will be discarded.
A ramp stop command is executed when changing from Speed Control Mode (PV mode or CSV mode) or Torque Control Mode (PT mode or CST mode) to other modes. And then, changes to other modes after the stop has been completed.
It cannot be changed to other modes when the Servo is operating in the Homing Mode, except that the homing operation has been completed or interrupted (Fault or disabled).
Servo running status, after changing from other modes to CSP mode, CSV mode or CST mode, please send the command at least 1ms interval to avoid loss of instruction or error.
After changing the modes to Cyclic Sync Mode (CSP mode, CSV mode or CST mode), please wait 1 ms or more before sending the commands, in case losing command loss or error occurred.
6.3.4 Communication Cycle
The communication Cycle Time of all Control Modes (PP, PV, PT, HM, IP, CSP, CSV, and CST) supports an integer multiple of 125μs (e.g. 125μs, 250μs, 500μs, 1ms, and so on).
6.4 Position Control
6.4.1 Profile Position (PP) Mode
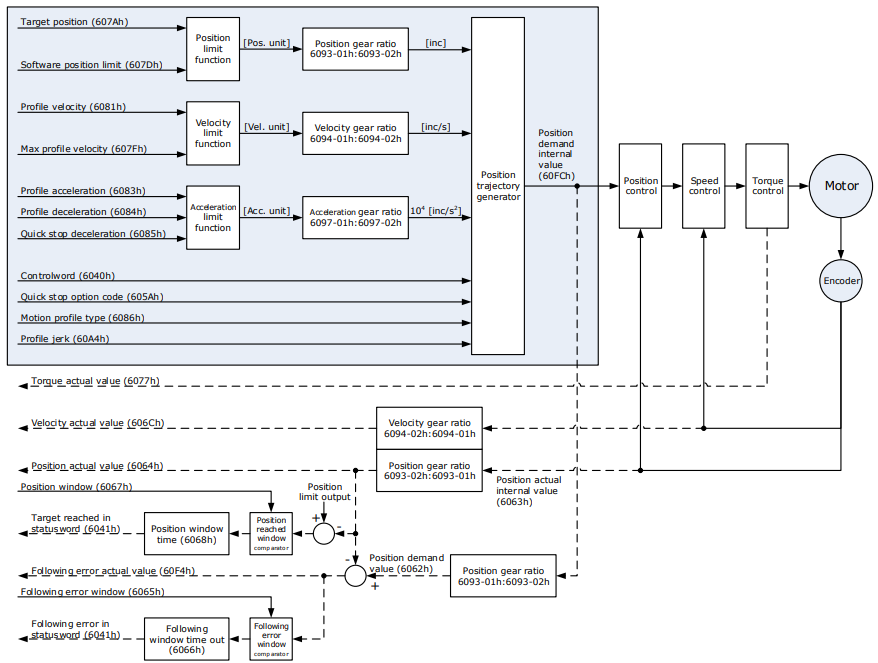
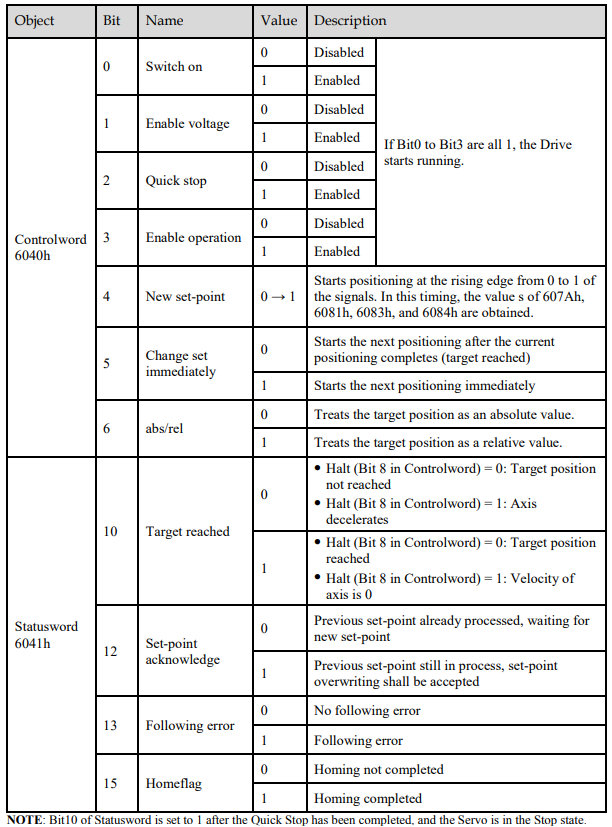
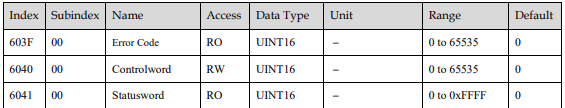
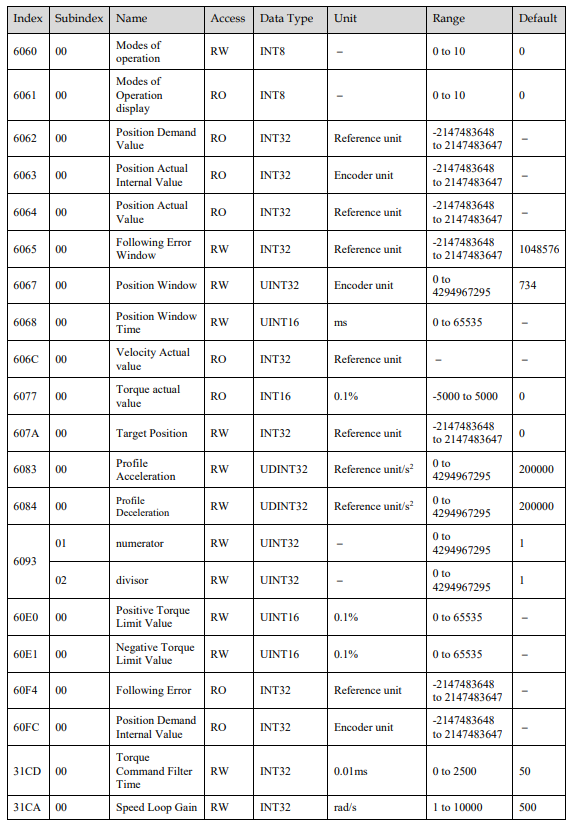
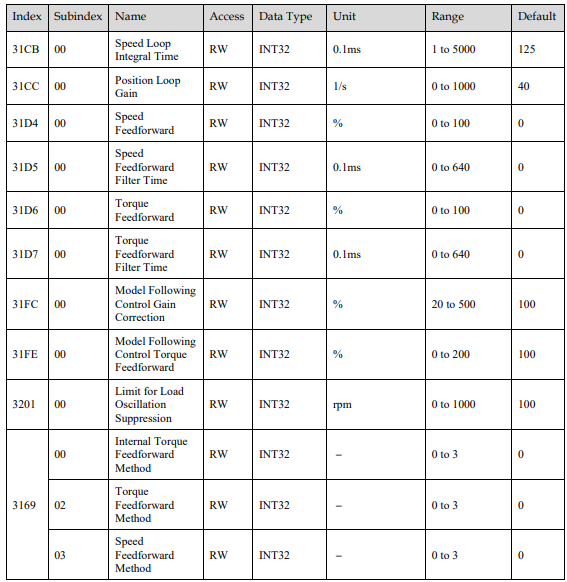
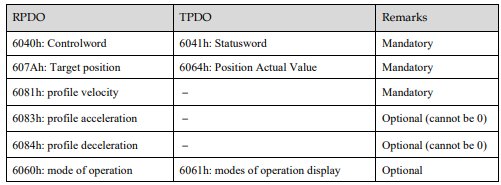
In this mode of operation, the host control uses the trajectory generator (an operation profile calculation function) inside the Drive to perform PTP positioning operation. It executes trajectory generator, position control, speed control, and torque control based on the target position, profile velocity, profile acceleration, profile deceleration, and other information.
Block Diagram
Speed Limit
The speed limit is determined by the smaller of 6080h value and 607F value
Relevant Objects
Recommended Configuration
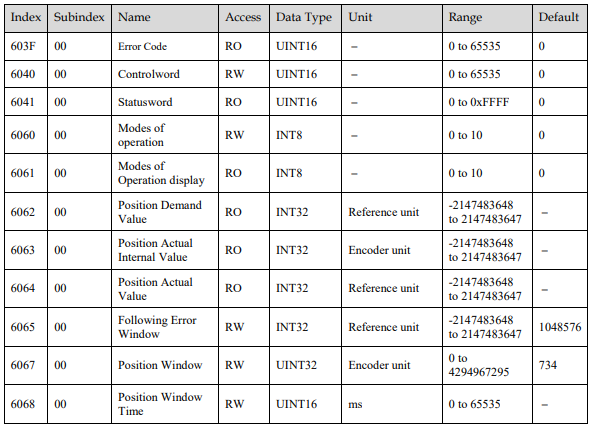
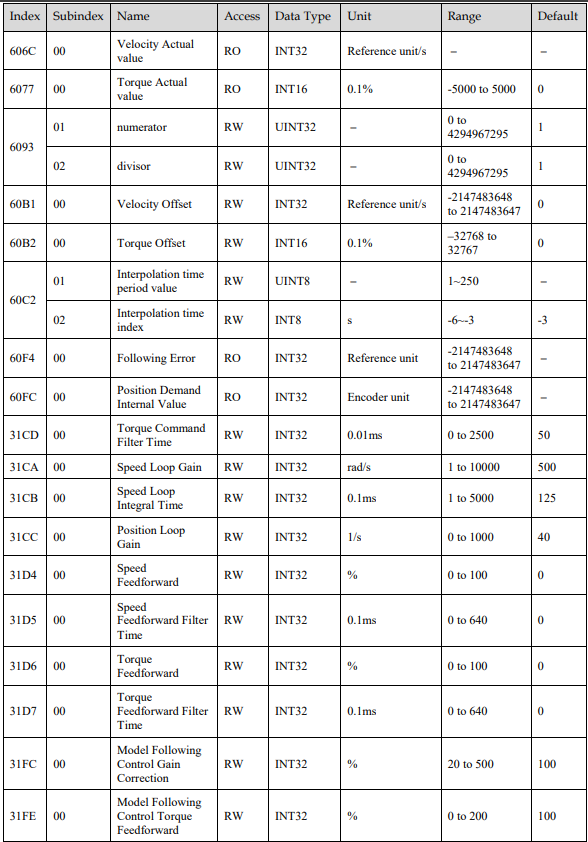
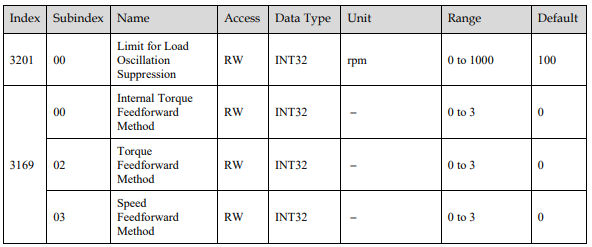
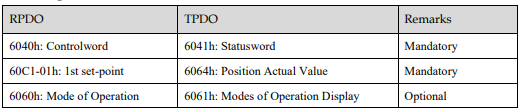
6.4.2 Interpolated Position (IP) Mode
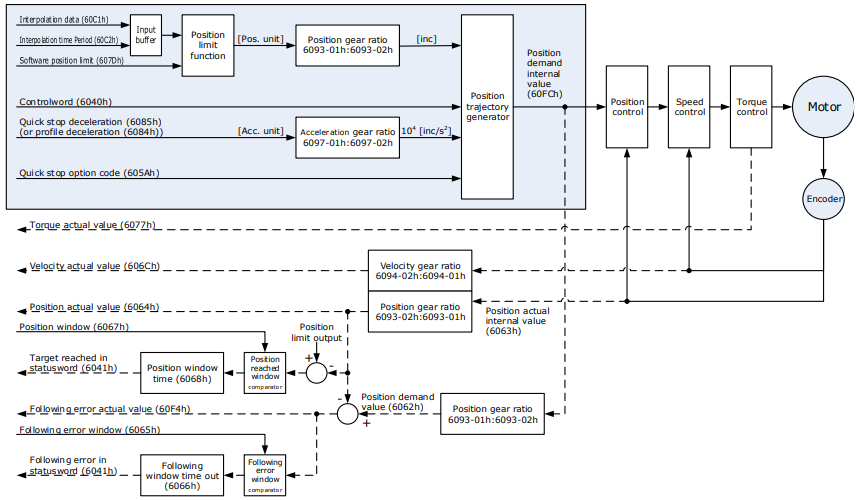
The Interpolated Position Mode is used to control multiple coordinated axes or to control a single axis that requires time interpolation of the set point data.
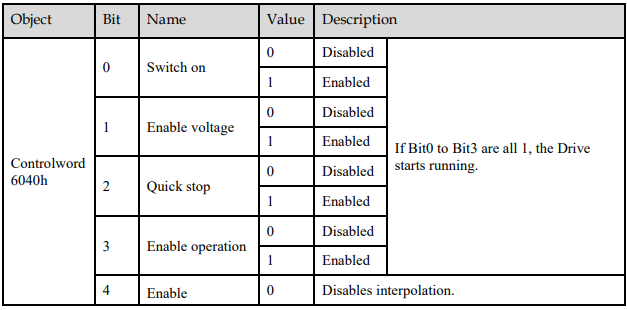
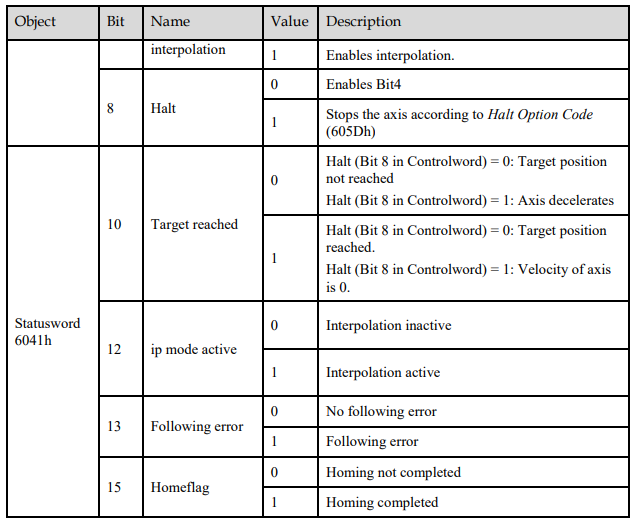
This mode normally uses a time (communications) synchronization mechanism to synchronize the Servo Drives. The Interpolation Time Period defines the update cycle of the Interpolation Data (i.e., the interpolation position). The interpolation processing in the Drive is based on this setting. The Interpolation Data is interpreted as an absolute value.
Block Diagram
Speed Limit
The speed limit is determined by the smaller of 6080h value and 607F value.
Relevant Objects
Recommended Configuration
6.4.3 Cyclic Synchronous Position (CSP) Mode
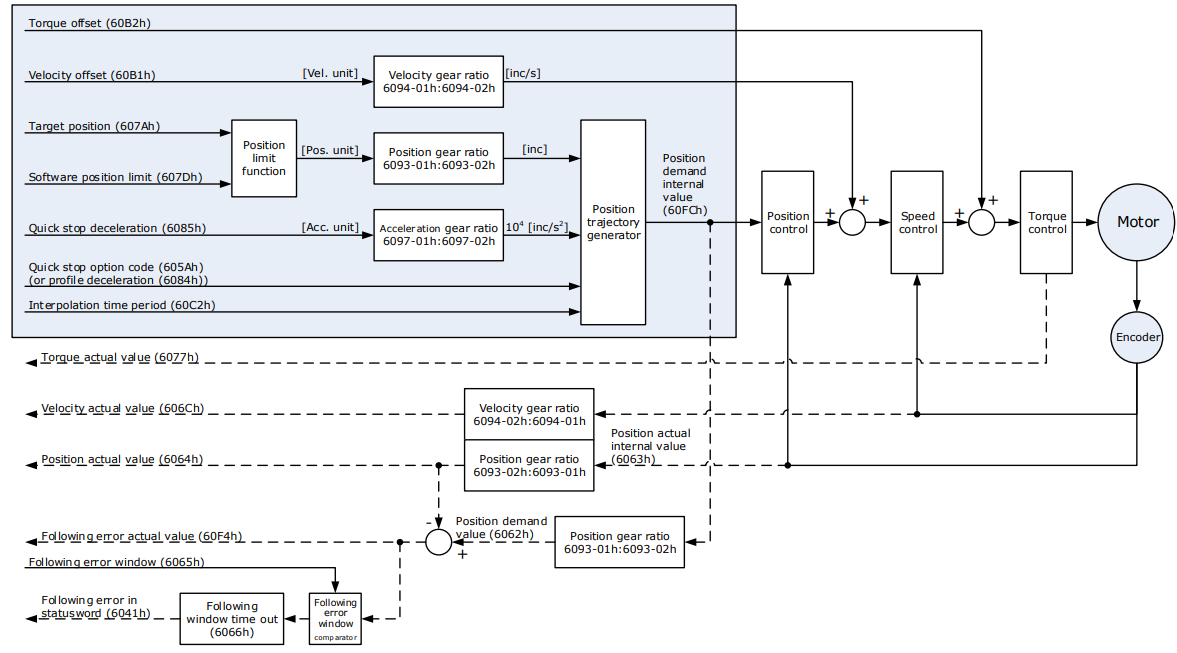
In this mode of operation, the host controller generates the position references and gives the target position in 607Ah to the Drive using cyclic synchronization. Position control, speed control, and torque control are performed by the Drive.
Block Diagram
Speed Limit
The speed limit is determined by the smaller of 6080h value and 607F value.
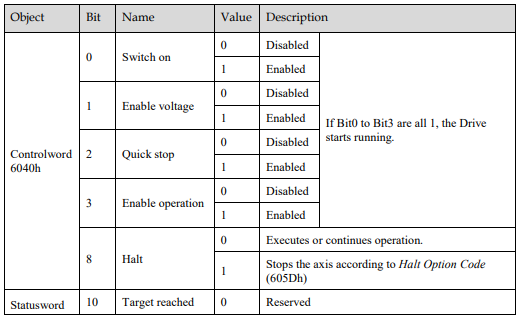
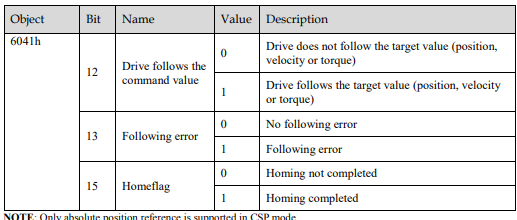
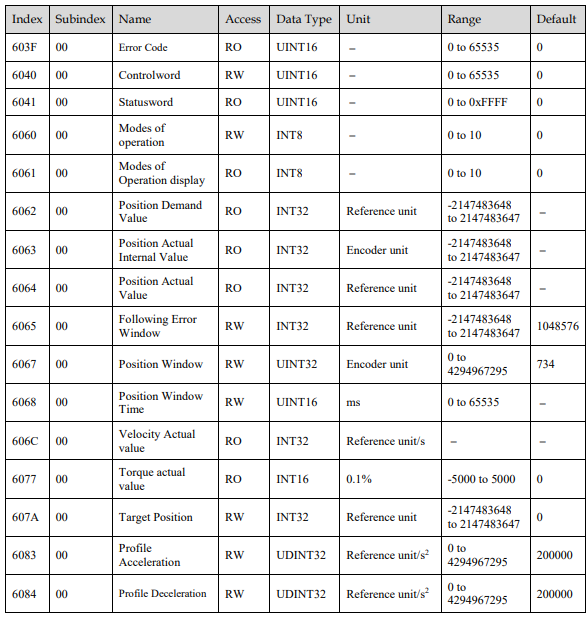
Relevant Objects
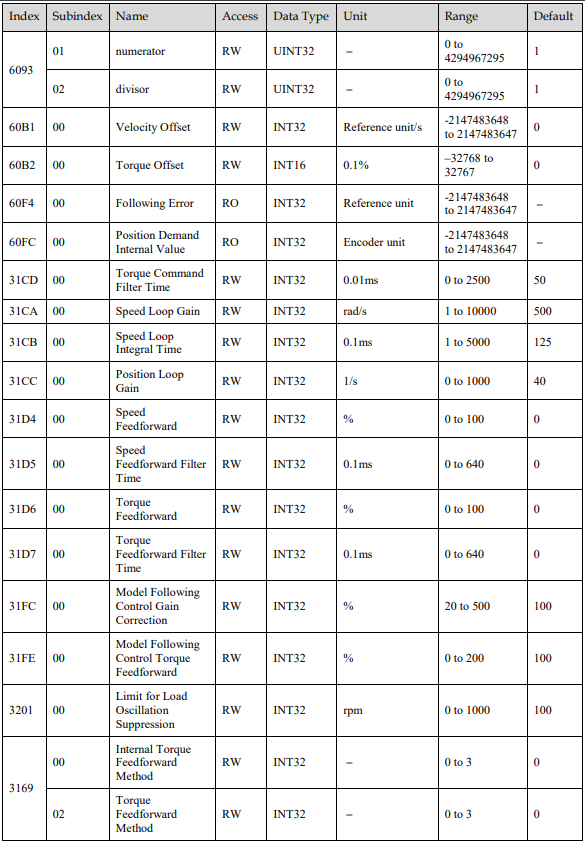
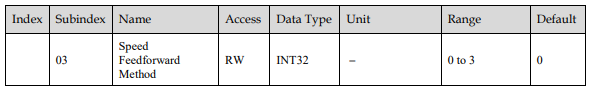
Recommended Configuration
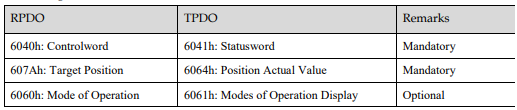
6.5 Homing
6.5.1 Homing (HM) Mode
This mode searches for the home and determines the position relationship between home and zero.
Home: mechanical home reference point, that is, the encoder C-pulse.
Zero: absolute zero point in the machine.
After homing is completed, the Motor stops at the home. The relationship between home and zero is set in 607Ch.
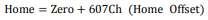
When 607Ch=0, the zero is the same as the home.
Block Diagram
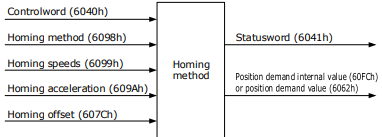
Speed Limit
The speed limit is determined by the smaller of 6080h value and 607F value.
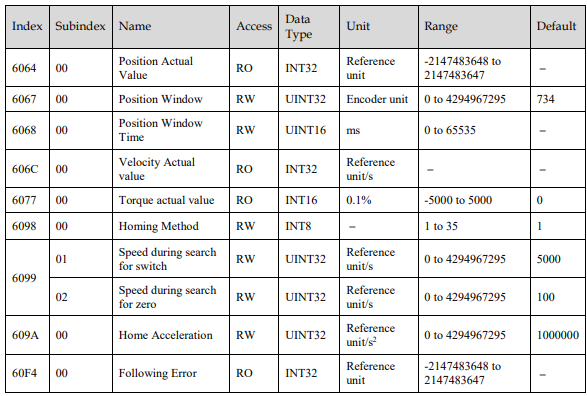
Relevant Objects
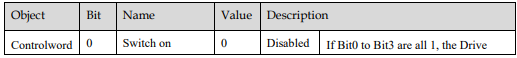
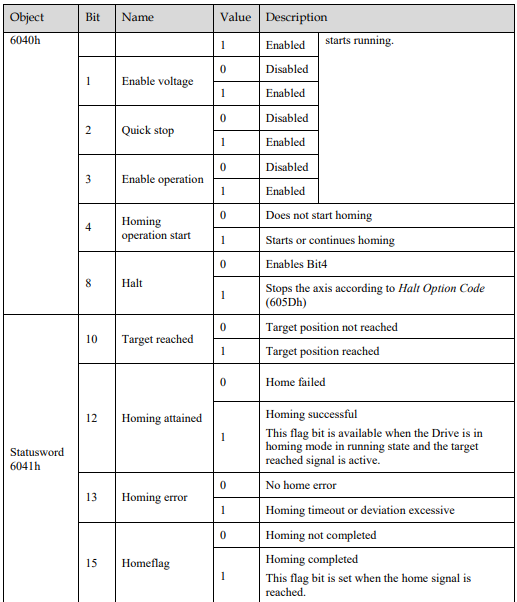
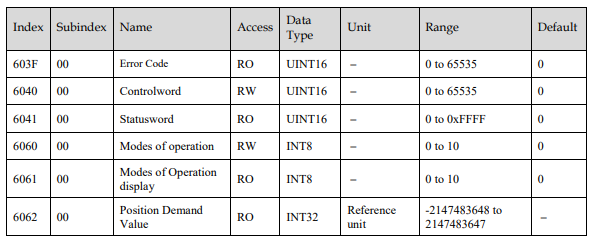
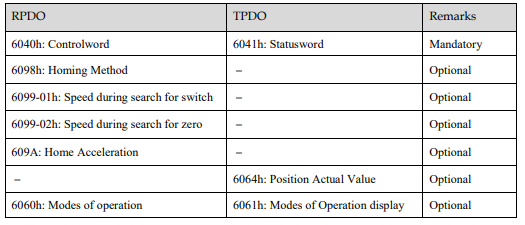
Recommended Configuration
6.5.2 Homing Methods
6098h = 1
Home: the Motor C-pulse signal
Deceleration point: negative limit switch (N-OT)
Deceleration point signal inactive at homing start:
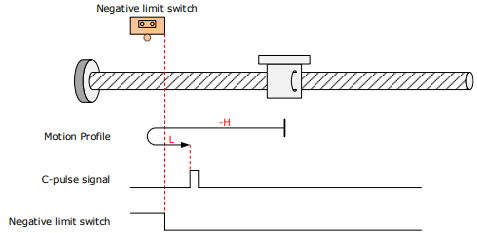
The N-OT signal is inactive initially, and the Motor starts homing in negative direction at high speed. After reaching the rising edge of the N-OT signal, the Motor decelerates and changes to run in positive direction at low speed.
After reaching the falling edge of the N-OT signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start
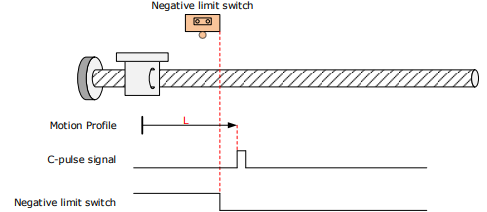
The N-OT signal is active initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the falling edge of the N-OT signal, the Motor stops at the first Motor C-pulse signal.
6098h = 2
Home: the Motor C-pulse signal
Deceleration point: positive limit switch (P-OT)
Deceleration point signal inactive at homing start
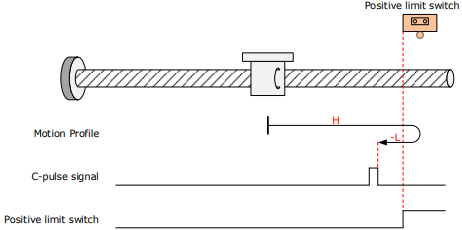
The P-OT signal is inactive initially, and the Motor starts homing in positive direction at high speed. After reaching the rising edge of the P-OT signal, the Motor decelerates and changes to run in negative direction at low speed.
After reaching the falling edge of the P-OT signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start
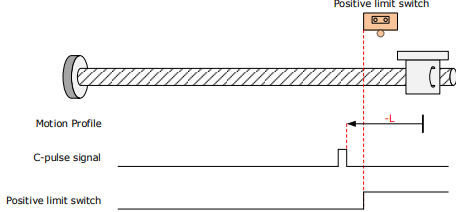
The P-OT signal is active initially, and the Motor directly starts homing in negative direction at low speed.
After reaching the falling edge of the P-OT signal, the Motor stops at the first Motor C-pulse signal.
6098h = 3
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start:
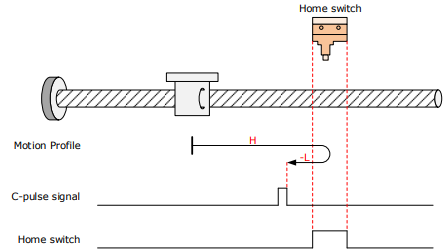
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. After reaching the rising edge of the HmRef signal, the Motor decelerates and changes to run in negative direction at low speed.
After reaching the falling edge of the Hmref signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
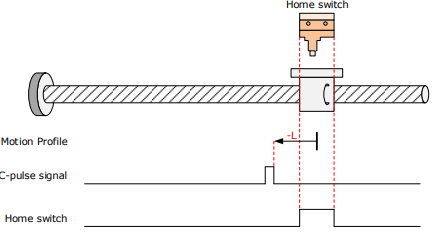
The HmRef signal is active initially, and the Motor directly starts homing in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 4
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start:
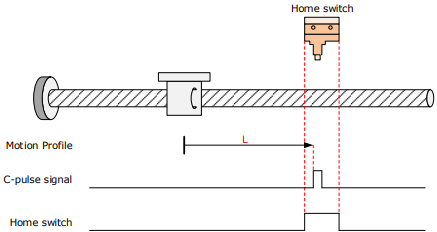
The HmRef signal is inactive initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
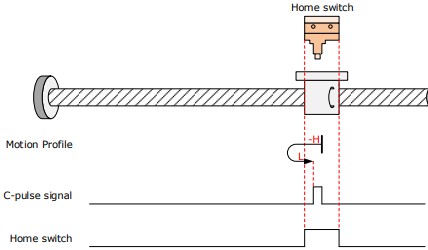
The HmRef signal is active initially, and the Motor starts homing in negative direction at high speed. After reaching the falling edge of the HmRef signal, the Motor decelerates and changes to run in negative direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 5
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start:
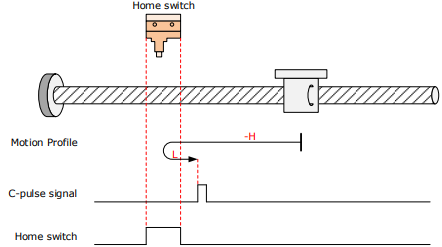
The HmRef signal is inactive initially. The Motor starts homing in negative direction at high speed. After reaching the rising edge of the HmRef signal, the Motor decelerates and changes to run in positive direction at low speed.
Deceleration point signal active at homing start:
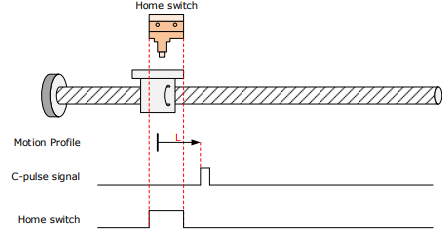
The HmRef signal is active initially, and the Motor directly starts homing in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 6
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start:
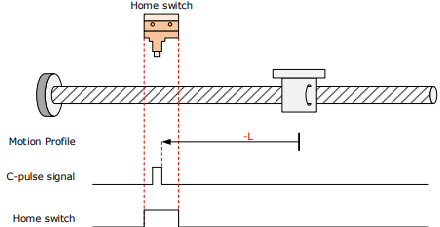
The HmRef signal is inactive initially, and the Motor directly starts homing in negative direction at low speed. After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
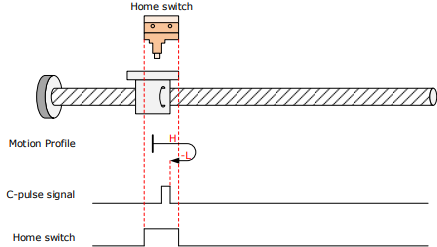
The HmRef signal is active initially, and the Motor starts homing in positive direction at high speed. After reaching the falling edge of the HmRef signal, the Motor decelerates and changes to run in negative direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 7
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching positive limit switch:
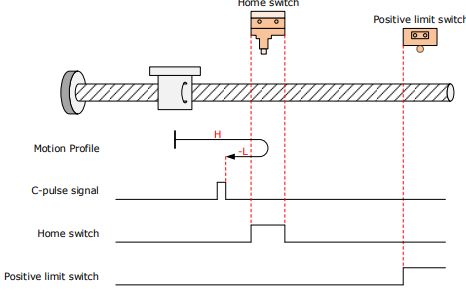
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor does not reach the limit switch, it decelerates and changes to run in negative direction at low speed after reaching the rising edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching positive limit switch:
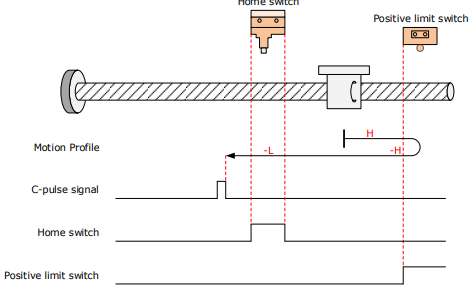
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor reaches the limit switch, it automatically changes to run in negative direction at high speed.
After reaching the rising edge of the HmRef signal, the Motor decelerates and continues to run in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
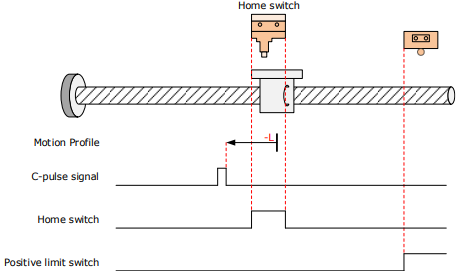
The HmRef signal is active initially, and the Motor directly starts homing in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 8
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching positive limit switch:
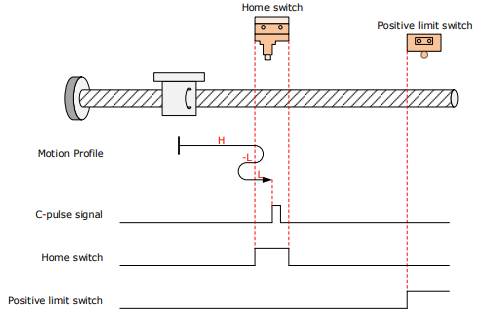
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor does not reach the limit switch, it decelerates and changes to run in negative direction at low speed after reaching the rising edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor changes to run in positive direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching positive limit switch:
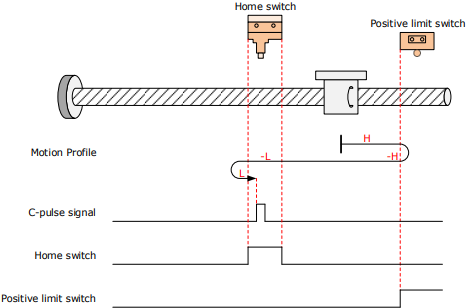
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor reaches the limit switch, it automatically changes to run in negative direction at high speed.
After reaching the rising edge of the HmRef signal, the Motor decelerates and continues to run in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in positive direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
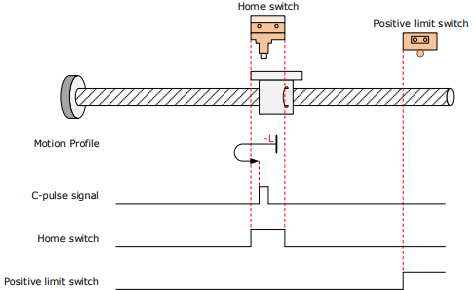
The HmRef signal is active initially, and the Motor directly starts homing in negative direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in positive direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 9
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching positive limit switch:
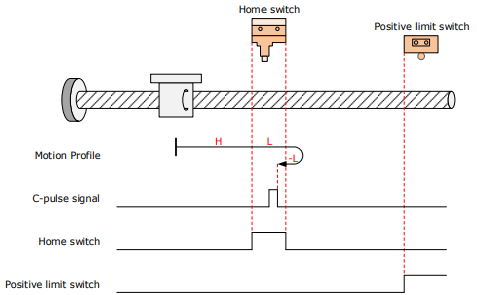
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor does not reach the limit switch, it decelerates and continues to run in positive direction at low speed after reaching the rising edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching positive limit switch:
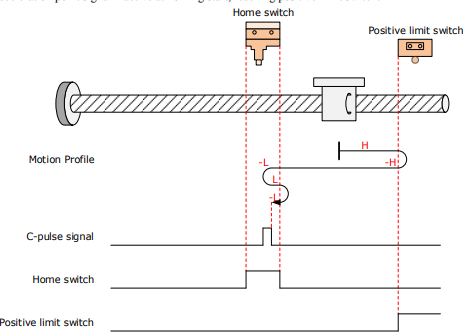
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor reaches the limit switch, it automatically changes to run in negative direction at high speed.
After reaching the rising edge of the HmRef signal, the Motor decelerates and resumes to run in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
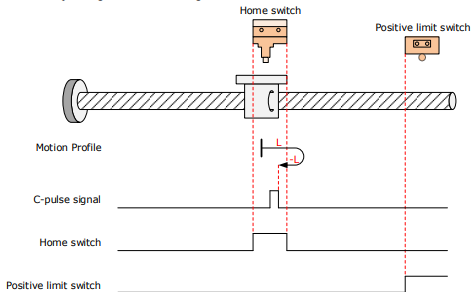
The HmRef signal is active initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal
6098h = 10
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching positive limit switch:
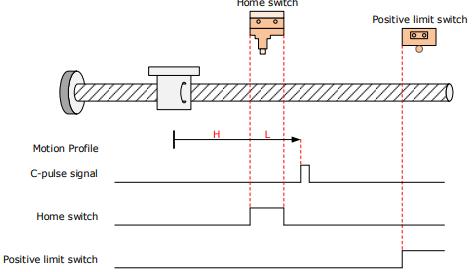
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor does not reach the limit switch, it decelerates and continues to run in positive direction at low speed after reaching the rising edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor continues to run in positive direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching positive limit switch:
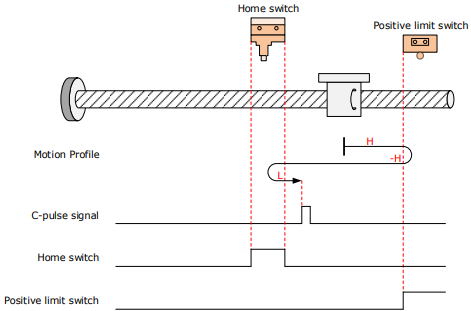
The HmRef signal is inactive initially, and the Motor starts homing in positive direction at high speed. If the Motor reaches the limit switch, it automatically changes to run in negative direction at high speed.
After reaching the falling edge of the HmRef signal, the Motor decelerates and resumes to run in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
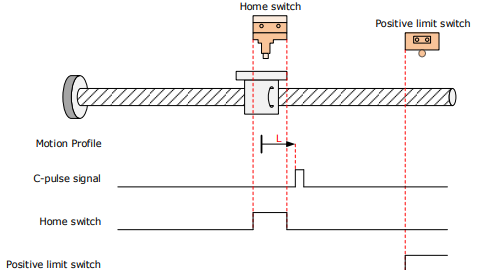
The HmRef signal is active initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 11
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching negative limit switch:
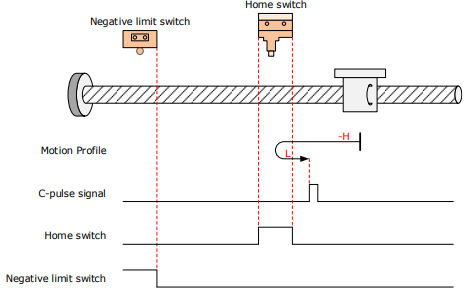
The HmRef signal is inactive initially, and the Motor starts homing in negative direction at high speed. If the Motor does not reach the limit switch, it decelerates and changes to run in positive direction at low speed after reaching edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching negative limit switch:
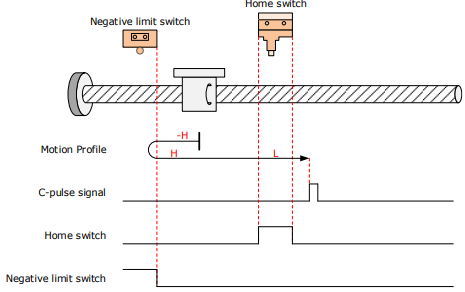
The HmRef signal is inactive initially, and the Motor starts homing in negative direction at high speed. If the Motor reaches the limit switch, it automatically changes to run in positive direction at high speed.
After reaching the rising edge of the HmRef signal, the Motor decelerates and continues to run in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
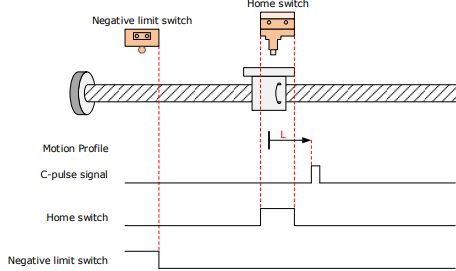
The HmRef signal is active initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.
6098h = 12
Home: the Motor C-pulse signal
Deceleration point: home switch (HmRef)
Deceleration point signal inactive at homing start, not reaching negative limit switch:
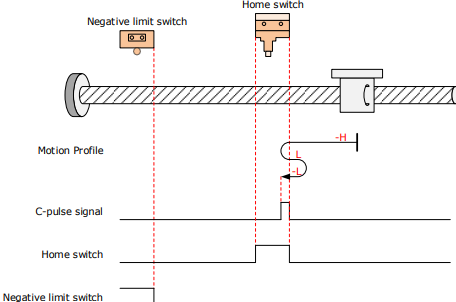
The HmRef signal is inactive initially, and the Motor starts homing in negative direction at high speed. If the Motor does not reach the limit switch, it decelerates and changes to run in positive direction at low speed after reaching the rising edge of the HmRef signal.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal inactive at homing start, reaching negative limit switch:
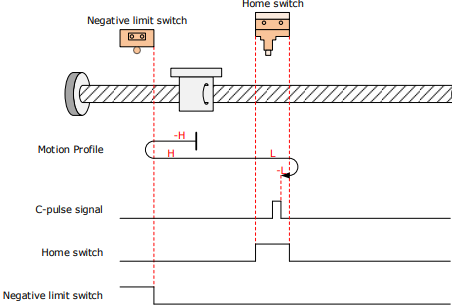
If the Motor reaches the limit switch, it automatically changes to run in positive direction at high speed.
After reaching the rising edge of the HmRef signal, the Motor decelerates and continues to run in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed, and stops at the first Motor C-pulse signal.
Deceleration point signal active at homing start:
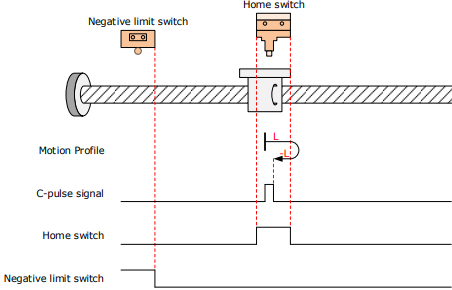
The HmRef signal is active initially, and the Motor directly starts homing in positive direction at low speed.
After reaching the falling edge of the HmRef signal, the Motor changes to run in negative direction at low speed.
After reaching the rising edge of the HmRef signal, the Motor stops at the first Motor C-pulse signal.