2. HARDWARE OVERVIEW
Motion Coordinator MC464
OVERVIEW
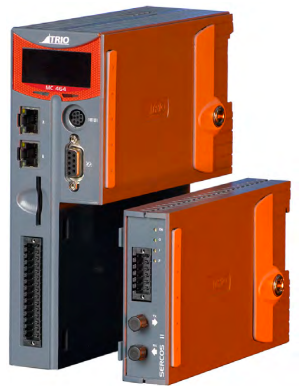
The Motion Coordinator MC464 is Trio’s new generation modular servo control positioner with the ability to control servo or stepper motors by means of Digital Drive links (e.g. EtherCAT, Sercos, etc) or via traditional analogue and encoder or pulse and direction. A maximum of 7 expansion modules can be fitted to control up to 64 axes which gives the flexibility required in modern system design. The MC464 is housed in a rugged plastic case with integrated earth chassis and incorporates all the isolation circuitry necessary for direct connection to external equipment in an industrial environment. Filtered power supplies are included so that it can be powered from the 24V d.c. logic supply present in most industrial cabinets.
It is designed to be configured and programmed for the application using a PC running the Motion Perfect application software, and then may be set to run “standalone” if an external computer is not required for the final system.
The Multi-tasking version of TrioBASIC for the MC464 allows up to 22 TrioBASIC programs to be run simultaneously on the controller using pre-emptive multi-tasking. In addition, the operating system software includes the IEC 61131-3 standard run-time environment (licence key required).
PROGRAMMING
The Multi-tasking ability of the MC464 allows parts of a complex application to be developed, tested and run independently, although the tasks can share data and motion control hardware. IEC 61131-3 programs can be run at the same time as TrioBASIC allowing the programmer to select the best features of each.
I/O CAPABILITY
The MC464 has 8 built in 24V inputs and 8 bi-directional I/O channels. These may be used for system interaction or may be defined to be used by the controller for end of travel limits, registration, datuming and feedhold functions if required. Each of the Input/Output channels has a status indicator to make it easy to check them at a glance. The MC464 can have up 512 external Input/Output channels connected using DIN rail mounted CAN I/O modules. These units connect to the built-in CAN channel.
COMMUNICATIONS
A 10/100 base-T Ethernet port is fitted as standard and this is the primary communications connection to the MC464. Many protocols are supported including Telnet, Modbus TCP, Ethernet IP and TrioPCMotion. Check the Trio website (www.triomotion.com) for a complete list.
The MC464 has one built in RS232 port and one built in duplex RS485 channel for simple factory communication systems. Either the RS232 port or the RS485 port may be configured to run the Modbus or Hostlink protocol for PLC or HMI interfacing.
If the built-in CAN channel is not used for connecting I/O modules, it may optionally be used for CAN communications. E.g. DeviceNet slave or CANopen master.
The Anybus CompactCom Carrier Module (P875) can be used to add other fieldbus communications options
REMOVABLE STORAGE
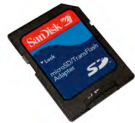
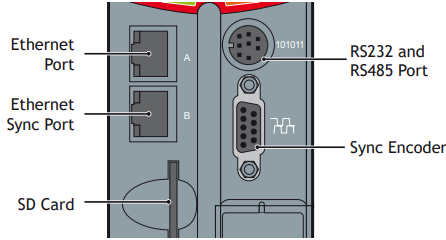
The MC464 has a SD Card slot which allows a simple means of transferring programs, firmware and data without a PC connection. Offering the OEM easy machine replication and servicing.
The memory slot is compatable with a wide range of SD cards up to 2Gbytes using the FAT32 compatible file system.
AXIS POSITIONING FUNCTIONS
The motion control generation software receives instructions to move an axis or axes from the TrioBASIC or IEC 61131-3 language which is running concurrently on the same processor. The motion generation software provides control during operation to ensure smooth, coordinated movements with the velocity profiled as specified by the controlling program. Linear interpolation may be performed on groups of axes, and circular, helical or spherical interpolation in any two/three orthogonal axes. Each axis may run independently or they may be linked in any combination using interpolation, CAM profile or the electronic gearbox facilities.
Consecutive movements may be merged to produce continuous path motion and the user may program the motion using programmable units of measurement (e.g. mm, inches, revs etc.). The module may also be programmed to control only the axis speed. The positioner checks the status of end of travel limit switches which can be used to cancel moves in progress and alter program execution.
CONNECTIONS TO THE MC464
ETHERNET PORT CONNECTION
Physical layer: 10/100 base_T
Connector: RJ45
The Ethernet port is the default connection between the Motion Coordinator and the host PC running Motion Perfect programming.

ETHERNET SYNC PORT
Not used.
MC464 SERIAL CONNECTIONS
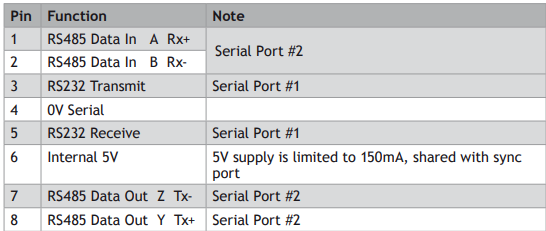
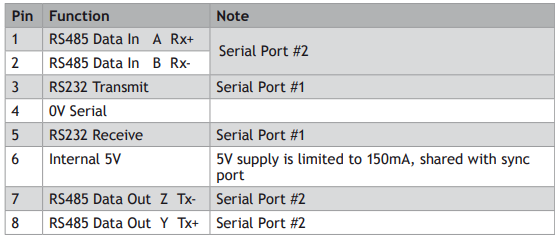
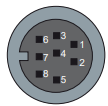
The MC464 features two serial ports. Both ports are accessed through a single 8 pin connector.
SERIAL CONNECTOR
SYNC ENCODER
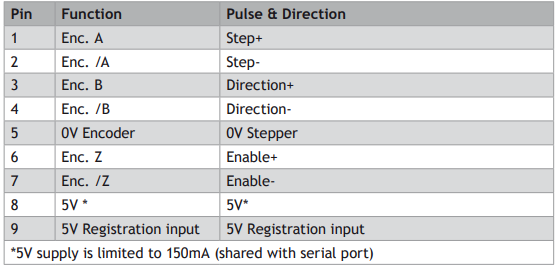
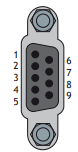
The sync encoder port is bidirectional. It can be used as a reference encoder input or as an encoder simulation output to act as a master reference for other parts of the system
REGISTRATION
The MC464 built in port has 2 available registration events. These can be used with the Z mark, the registration input on the sync port, input 0 or input 1.
24V POWER SUPPLY INPUT
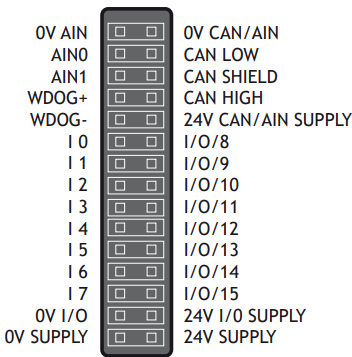
The MC464 is powered entirely via the 24V d.c.supply connections. The unit uses internal DC-DC converters to generate independent 5V logic supply, the encoder/serial 5V supply and other internal power supplies. I/O, analogue and CANbus circuits are isolated from the main 24V power input and must be powered separately. For example; it is often necessary to power the CANbus network remotely via the CANbus cable.
24V d.c., Class 2 transformer or power source required for UL compliance. The MC464 is grounded via the metal chassis. It MUST be installed on an unpainted metal plate or DIN rail which is connected to earth.
AMPLIFIER ENABLE (WATCHDOG) RELAY OUTPUTS
One internal relay contact is available to enable external amplifiers when the controller has powered up correctly and the system and application software is ready. The amplifier enable is a solid-state relay with an ON resistance of 25 ohms at 100mA. The enable relay will be open circuit if there is no power on the controller OR a motion error exists on a servo axis OR the user program sets it open with the WDOG=OFF command.
The amplifier enable relay may, for example, be incorporated within a hold-up circuit or chain that must be intact before a 3-phase power input is made live.
ALL STEPPER AND SERVO AMPLIFIERS MUST BE INHIBITED WHEN THE AMPLIFIER ENABLE OUTPUT IS OPEN CIRCUIT
CANBUS
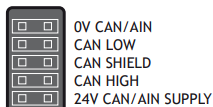
The MC464 features a built-in CAN channel. This is primarily intended for Input/Output expansion via Trio’s range of CAN digital and analogue I/O modules. It may be used for other purposes when I/O expansion is not required.
The CANbus port is electrically equivalent to a DeviceNet node.
ANALOGUE INPUTS
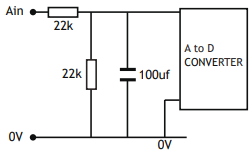
Two built-in 12 bit analogue inputs are provided which are set up with a scale of 0 to 10V. External connection to these inputs is via the 2-part terminal strip on the lower front panel.
A 24V d.c. supply must be applied to the CANbus port to provide power for the analogue input circuit.
24V INPUT CHANNELS
The Motion Coordinator has 16 24V Input channels built into the master unit. These may be expanded to 256 Inputs by the addition of CAN-16 I/O modules.
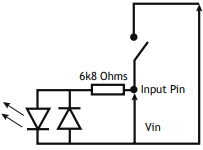
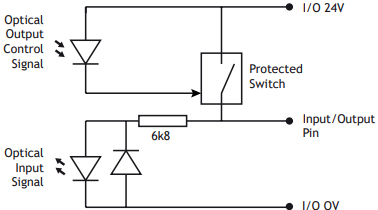
All of the 24V Input channels have the same circuit although 8 on the master unit have 24V Output channels connected to the same pin. These bidirectional channels may be used for Input or Output to suit the application. If the channel is to be used as an Input then the Output should not be switched on in the program.
24V I/O CHANNELS
Input/output channels 8..15 are bi-directional and may be used for Input or Output to suit the application. The inputs have a protected 24V sourcing output connected to the same pin. If the channel is to be used as an Input then the Output should not be switched on in the program. The input circuitry is the same as on the dedicated inputs. The output circuit has electronic over-current protection and thermal protection which shuts the output down when the current exceeds 250mA.
Care should be taken to ensure that the 250mA limit for the output circuit is not exceeded, and that the total load for the group of 8 outputs does not exceed 1A
BATTERY
The MC464 incorporates a user replaceable battery for the battery back-up RAM. For replacement, use battery model CR2450 or equivalent.
To replace the battery, insert screwdriver under the frontmost ventilation slot (A) and prize off the battery cover (B) and pull the battery ribbon to lift the battery (C) from the MC464. Replacing is the reverse of the procedure.
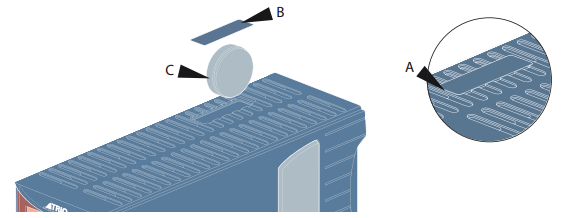
TO AVOID LOSING THE MEMORY CONTENTS, THE NEW BATTERY SHOULD BE INSERTED WITHIN 30 SECONDS OF THE OLD ONE BEING REMOVED.
BACKLIT DISPLAY
The information display area shows the IP address and subnet mask during power-up and whenever an Ethernet cable is first connected to the MC464. During operation, this display shows run, Off or Err to indicate the MC464 status. Below the main status display are the ERROR, ENABLE and BATTERY LOW indicators.
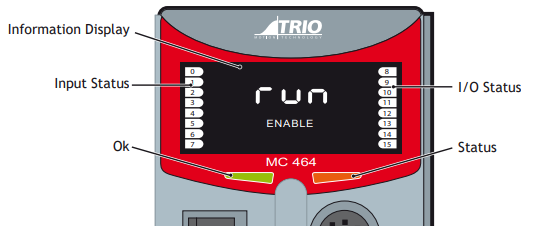
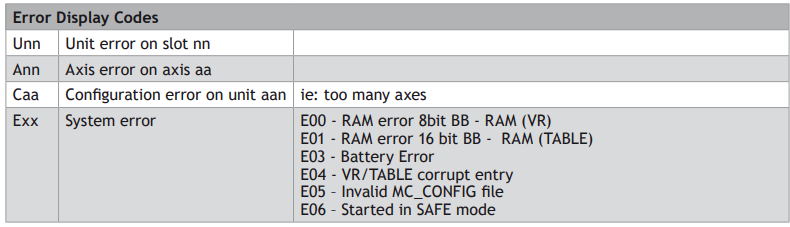
ERROR An error has occurred (see Error Display Codes table below for details).
ENABLE When illuminated, WDOG is ON.
BATTERY LOW When illuminated the battery needs replacing.
A bank of 8 indicators at the left side shows the Digital Input States and a similar bank on the right shows the state of I/O8 to I/O15. The I/O displayed can be altered using the DISPLAY command.
Two LED’s are provided to show the processor (OK) and system status.
MC464 FEATURE SUMMARY
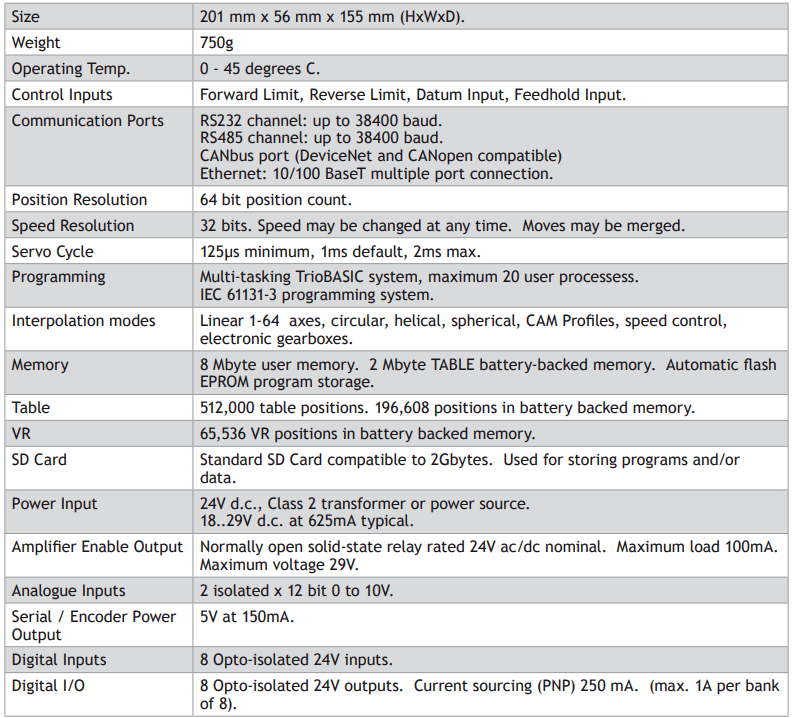
Motion Coordinator MC4N-Mini EtherCAT Maste
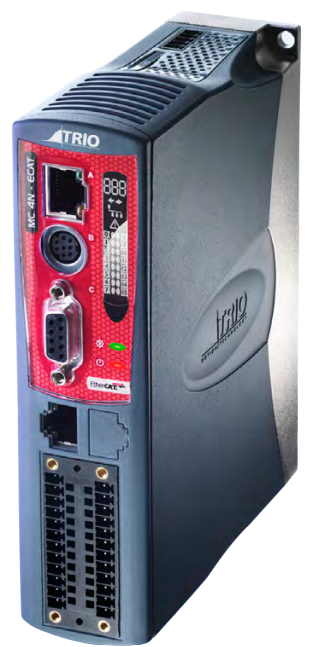
OVERVIEW
The MC4N is a new concept in high performance Motion Coordinators which is dedicated to running remote servo and stepper drives via the EtherCAT real time automation bus. It is based on an up-rated version of the 532MHz ARM 11 processor which makes it ideal for high axis count machines or robotic
applications.
It is designed to be configured and programmed for the application using a PC running the Motion Perfect application software, and then may be set to run “standalone” if an external computer is not required for the final system.
The Multi-tasking version of TrioBASIC for the MC4N allows up to 22 TrioBASIC programs to be run simultaneously on the controller using pre-emptive multi-tasking. In addition, the operating system software includes the IEC 61131-3 standard run-time environment (licence key required).
Versions of the MC4N are available for 2, 4, 8, 16 and 32 motor axes. All versions feature 32 software axes any of which may be used as virtual axes if not assigned to EtherCAT hardware.
PROGRAMMING
The Multi-tasking ability of the MC4N allows parts of a complex application to be developed, tested and run independently, although the tasks can share data and motion control hardware. IEC 61131-3 programs can be run at the same time as TrioBASIC allowing the programmer to select the best features of each.
I/O CAPABILITY
The MC4N has 8 built in 24V inputs and 8 bi-directional I/O channels. These may be used for system interaction or may be defined to be used by the controller for end of travel limits, registration, datuming and feedhold functions if required. Each of the Input/Output channels has a status indicator to make it easy to check them at a glance. The MC4N can have up 512 external Input/Output channels connected using DIN rail mounted CAN I/O modules. These units connect to the built-in CAN channel.
COMMUNICATIONS
A 10/100 base-T Ethernet port is fitted as standard and this is the primary communications connection to the MC4N. Many protocols are supported including Telnet, Modbus TCP, Ethernet IP and TrioPCMotion. Check the Trio website (www.triomotion.com) for a complete list.
The MC4N has one built in RS232 port and one built in duplex RS485 channel for simple factory communication systems. Either the RS232 port or the RS485 port may be configured to run the Modbus or Hostlink protocol for PLC or HMI interfacing.
If the built-in CAN channel is not used for connecting I/O modules, it may optionally be used for CAN communications. E.g. DeviceNet slave or CanOpen master.
REMOVABLE STORAGE
The SD Card maybe used for storing or transfering programs, reciepes and data to and from the MC4N. The card must be FAT32 format and a maximum 16Gb size.
SD CARDS MAY BE FAT16 FORMATTED WHEN PURCHASED. RE-FORMAT IN A PC TO FAT32
PRIOR TO USE.
AXIS POSITIONING FUNCTIONS
The motion control generation software receives instructions to move an axis or axes from the TrioBASIC or IEC 61131-3 language which is running concurrently on the same processor. The motion generation software provides control during operation to ensure smooth, coordinated movements with the velocity profiled as specified by the controlling program. Linear interpolation may be performed on groups of axes, and circular, helical or spherical interpolation in any two/three orthogonal axes. Each axis may run independently or they may be linked in any combination using interpolation, CAM profiles or the electronic gearbox facilities.
Consecutive movements may be merged to produce continuous path motion and the user may program the motion using programmable units of measurement (e.g. mm, inches, revs etc.). The module may also be programmed to control only the axis speed. The positioner checks the status of end of travel limit switches which can be used to cancel moves in progress and alter program execution.
CONNECTIONS TO THE MC4N
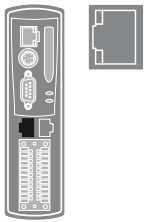
ETHERNET PORT CONNECTION
Physical layer: 10/100 base_T
Connector: RJ45
A standard Ethernet connector is provided for use as the primary programming interface.
The Trio programming software, Motion Perfect, must be installed on a Windows based PC that is fitted with an Ethernet connection. The IP address is displayed on the MC4N display for a few seconds after power-up or when an Ethernet cable is plugged in.
Ethernet cable must be CAT 5 or better.
The Standard Ethernet connection may also be used for Ethernet-IP, Modbus and other factory communications.
SERIAL CONNECTIONS
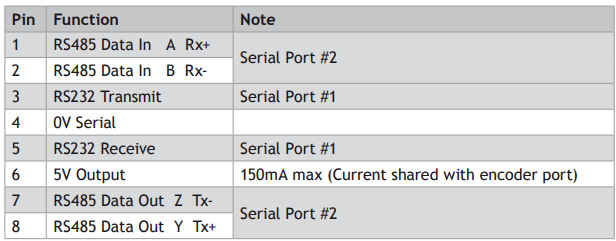
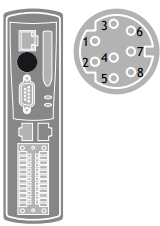
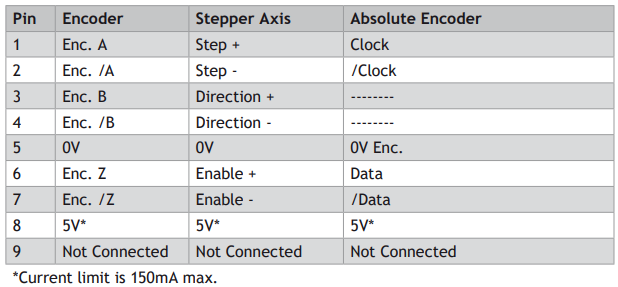
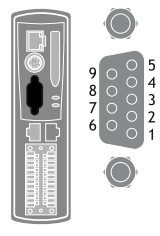
FLEXIBLE AXIS PORT
ETHERCAT PORT
The MC4N acts as an EtherCAT master. EtherCAT drives and I/O devices are normally connected in a chain. Other topologies are possible when specialised EtherCAT routers are used in the network.
Up to 32 EtherCAT axes and 1024 digital I/O points may be connected via the EtherCAT bus.
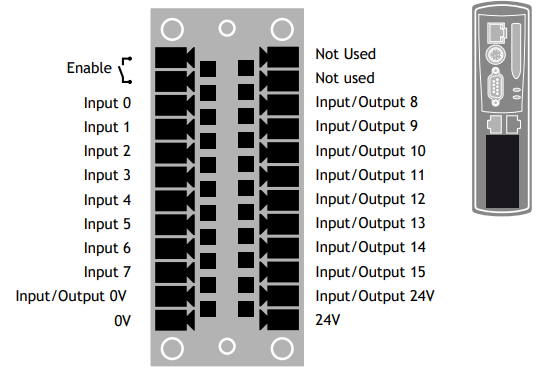
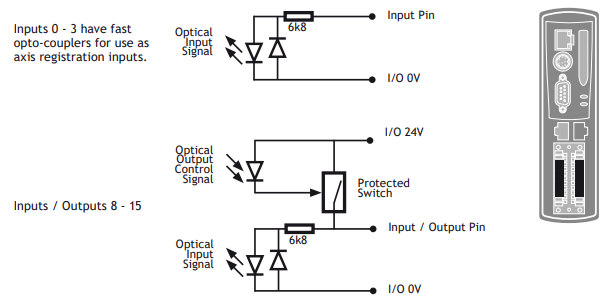
I/O CONNECTOR
THE MC4N IS GROUNDED VIA THE METAL CHASSIS. FIT A SHORT SHIELD CONNECTION BETWEEN THE CHASSIS EARTH SCREW AND THE EARTHED METAL MOUNTING PANEL / PLATE.
AMPLIFIER ENABLE (WATCHDOG) RELAY OUTPUT
An internal relay may be used to enable external amplifiers when the controller has powered up correctly and the system and application software are ready. The amplifier enable is a single pole solid state relay with a normally open “contact”. The enable relay contact will be open circuit if there is no power on the controller OR an axis error exists OR the user program sets it open with the WDOG=OFF command.
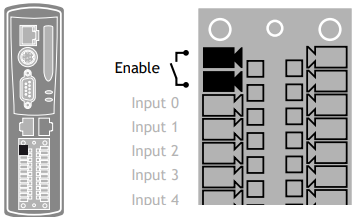
ETHERCAT DRIVES WILL BE ENABLED VIA THE ETHERCAT NETWORK SO THE “AMPLIFIER ENABLE” CONNECTION IS NOT NORMALLY REQUIRED.
ALL NON ETHERCAT STEPPER AND SERVO AMPLIFIERS MUST BE INHIBITED WHEN THE AMPLIFIER ENABLE OUTPUT IS OPEN CIRCUIT
AN ADDITIONAL SAFETY RELAY MAY BE REQUIRED SO AS TO MEET MACHINE SAFETY APPROVALS.
5 WAY CAN CONNECTOR
This is a 5 way 3.5mm pitch connector. The connector is used both to provide the 24 Volt power to the MC4N CAN circuit and provide connections for I/O expansion via Trio’s CAN I/O expanders. A 24V dc, Class 2 transformer or power source should be used.
This 24 Volt input is internally isolated from the I/O 24 Volts and main 24V power.
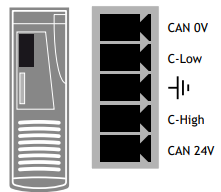
The CAN connector may be left unused.
DISPLAY
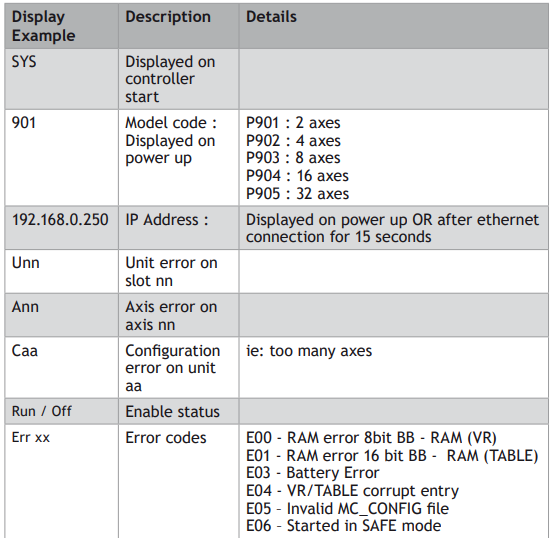
The IP address and subnet mask of the MC4N is shown on the LCD display for a few seconds after power-up. The factory default IP address is 192.168.0.250. This can be changed using the IP _ ADDRESS commands via the Motion Perfect software tool.
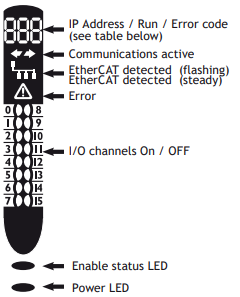
COMMUNICATIONS ACTIVE
This symbol appears when the firmware has detected one or more valid EtherCAT nodes on the network.
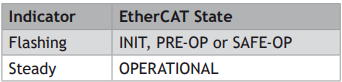
ETHERCAT DETECTION
This symbol shows the EtherCAT connection status.
ERROR
This symbol shows when an error condition has occurred. See the numerical display for more information.
NETWORK SET-UP
NETWORK CONNECTION
Set IP _ ADDRESS in MC4N to an available unused address. It MUST match the subnet in use. Set the PC to use DHCP server.
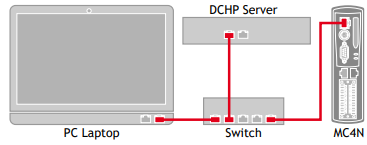
The MC4N always has a fixed IP _ ADDRESS.
POINT-TO-POINT OR CLOSED NETWORK
(No DHCP server)
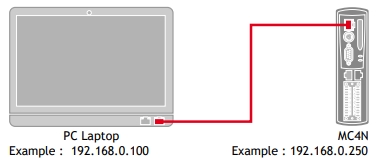
THE PC MUST BE SET TO A FIXED IP _ ADDRESS.
The first 3 “octets” MUST be the same as the MC4N and the last MUST be different, but not 000, 254 or 255.
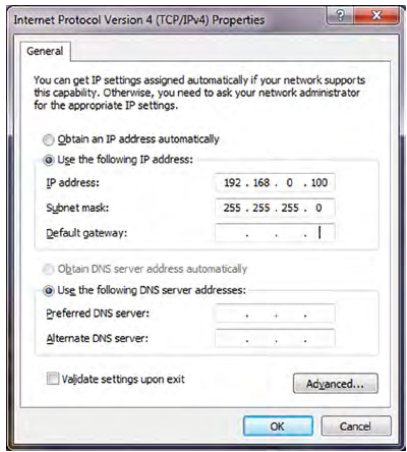
SETTING A FIXED IP ADDRESS
In Windows 7. Open “Network and Sharing Centre” then change “Adapter Settings”. Select the properties of the Local Area Network and the IPv4 properties. The IP Address is set to 192.168.0.100 with subnet mask set to 255.255.255.0. Assuming that the MC4N has IP _ ADDRESS=192.168.0.250 or similar.
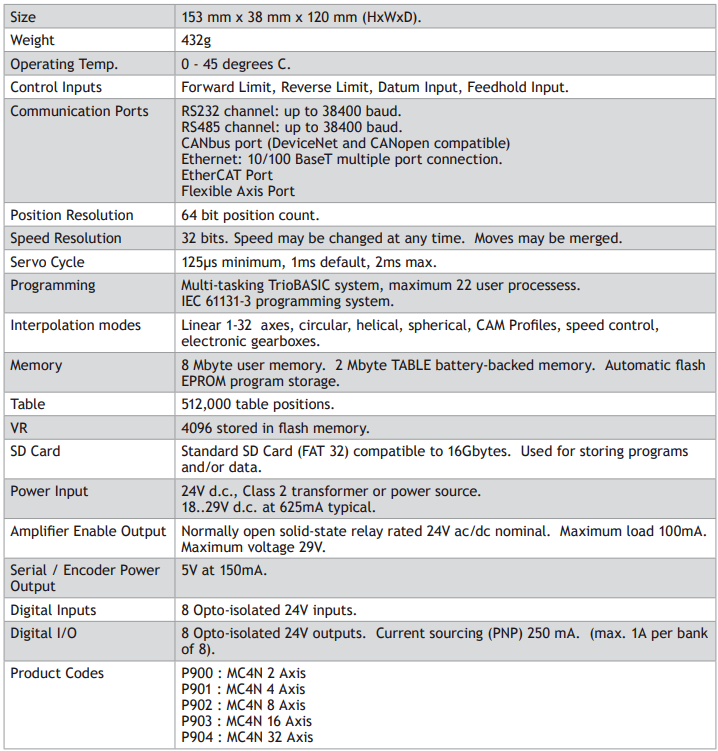
MC4N FEATURE SUMMARY
Motion Coordinator MC403
OVERVIEW
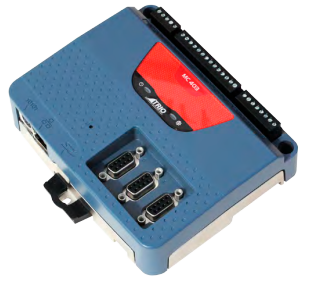
The Motion Coordinator MC403 is based on Trio’s highperformance ARM11 double-precision technology and provides 2 axes of servo plus a master encoder axis, or 3 axes of pulse+direction control for stepper drives or pulseinput servo drives. Trio uses advanced FPGA techniques to
reduce the size and fit the pulse output and servo circuitry in a compact DIN-rail mounted package. The MC403 is housed in a rugged plastic case with integrated earth chassis and incorporates all the isolation circuitry necessary for direct connection to external equipment in an industrial environment. Filtered power supplies are included so that it can be powered from the 24V d.c. logic supply present in most industrial cabinets.
It is designed to be configured and programmed for the application using a PC running Trio’s Motion Perfect application software, and then may be set to run “standalone” if an external computer is not required for the final system. Programs and data are stored directly to Flash memory, thus eliminating the need for battery backed storage.
The Multi-tasking version of TrioBASIC for the MC403 allows up to 6 TrioBASIC programs to be run simultaneously on the controller using pre-emptive multi-tasking. In addition, the operating system software includes a the IEC 61131-3 standard run-time environment (licence key required).
A reduced functionality version, the MC403-Z has all the fesatures of the full MC403 except that there are no analogue outputs and the encoder function of axes 0 and 1 is incremental encoder only.
PROGRAMMING
The Multi-tasking ability of the MC403 allows parts of a complex application to be developed, tested and run independently, although the tasks can share data and motion control hardware. The 6 available tasks can be used for TrioBASIC or IEC 61131-3 programs, or a combination of both can be run at the same time, thus allowing the programmer to select the best features of each.
I/O CAPABILITY
The MC403 has 8 built in 24V inputs and 4 bi-directional I/O channels. These may be used for system interaction or may be defined to be used by the controller for end of travel limits, registration, datuming and feedhold functions if required. The MC403 can have up 512 external Input and Output channels connected using DIN rail mounted CAN I/O modules. These units connect to the built-in CANbus port.
COMMUNICATIONS
A 10/100 base-T Ethernet port is fitted as standard and this is the primary communications connection to the MC403. Many protocols are supported including Telnet, Modbus TCP, Ethernet IP and TrioPCMotion. Check the Trio website (www.triomotion.com) for a complete list.
The MC403 has one built in RS232 port and one built in duplex RS485 channel for simple factory communication systems. Either the RS232 port or the RS485 port may be configured to run the Modbus or Hostlink protocol for PLC or HMI interfacing.
If the built-in CAN channel is not used for connecting I/O modules, it may optionally be used for CAN communications. E.g. DeviceNet, CANopen etc.
REMOVABLE STORAGE
The MC403 has a micro-SD Card slot which allows a simple means of transferring programs, firmware and data without a PC connection. Offering the OEM easy machine replication and servicing.
The memory slot is compatible with a wide range of micro-SD cards up to 16Gbytes using the FAT32 compatible file system.
AXIS POSITIONING FUNCTIONS
The motion control software receives instructions to move an axis or axes from the TrioBASIC or IEC 61131-3 language which is running concurrently on the same processor. The motion generation software provides control during operation to ensure smooth, coordinated movements with the velocity profiled as specified by the controlling program. Linear interpolation may be performed on groups of axes, and circular, helical or spherical interpolation in any two/three orthogonal axes. Each axis may run independently or they may be linked in any combination using interpolation, CAM profile or the electronic gearbox facilities.
Consecutive movements may be merged to produce continuous path motion and the user may program the motion using programmable units of measurement (e.g. mm, inches, revs etc.). The module may also be programmed to control only the axis speed. The positioner checks the status of end of travel limit switches which can be used to cancel moves in progress and alter program execution.
CONNECTIONS TO THE MC403
ETHERNET PORT CONNECTION
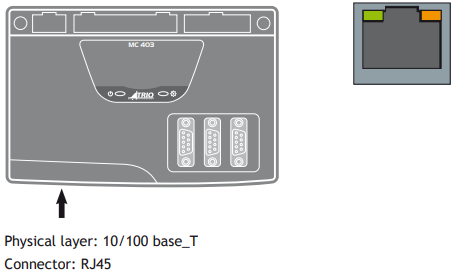
The Ethernet port is the default connection between the Motion Coordinator and the host PC running the Motion Perfect development application.
To reset the IP _ ADDRESS, IP _ GATEWAY and IP _ NETMASK to their default values press the IP reset button and power cycle the controller while keeping the button pressed.
MC403 SERIAL CONNECTIONS
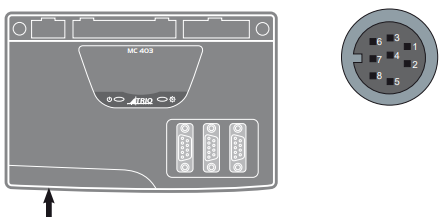
The MC403 features two serial ports. Both ports are accessed through a single 8 pin connector.
SERIAL CONNECTOR