
3. SPECIFICATIONS
3.1. ROBOT CONFIGURATION
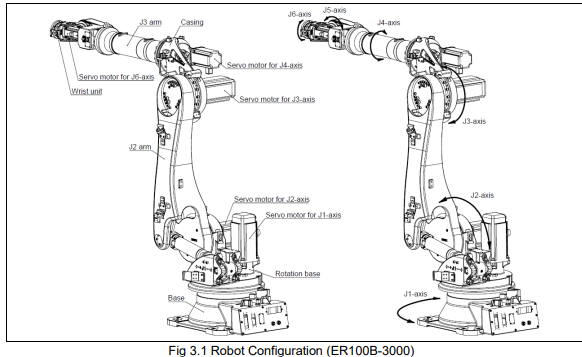
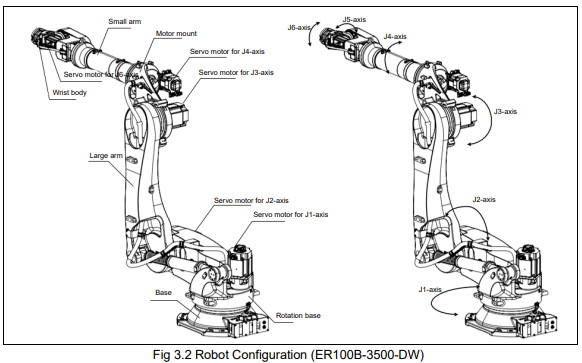
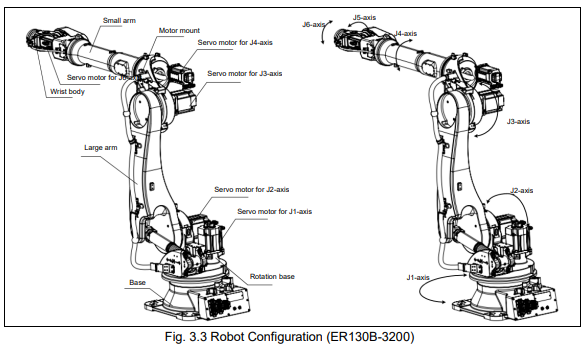
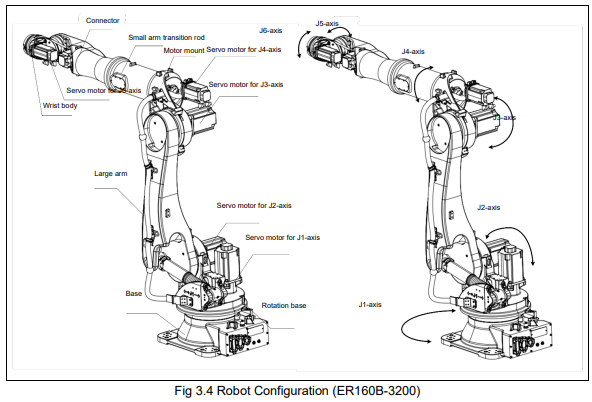
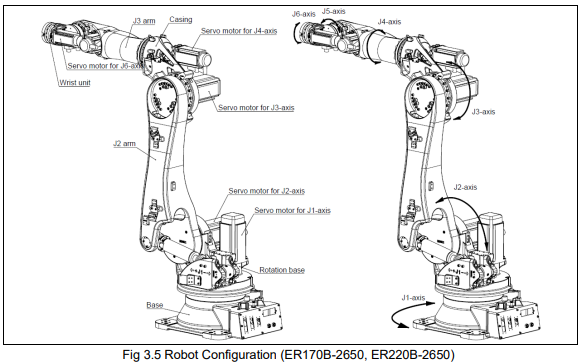
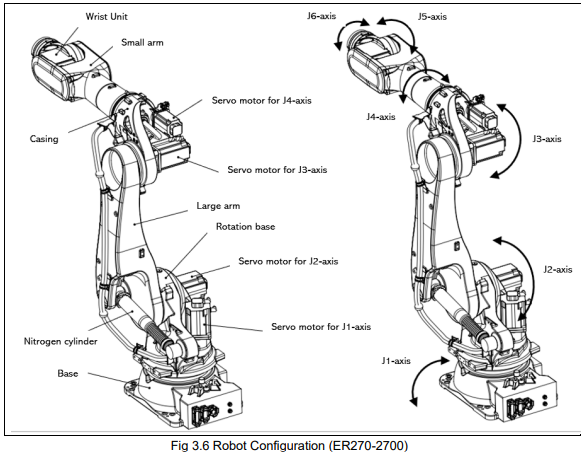
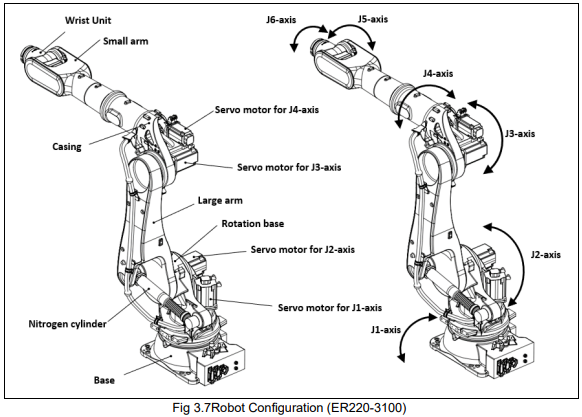
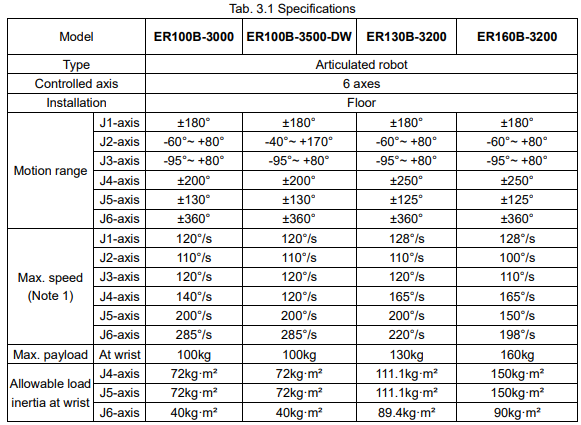
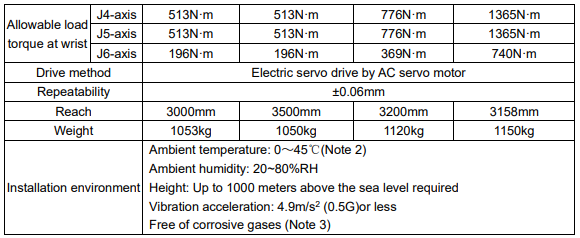
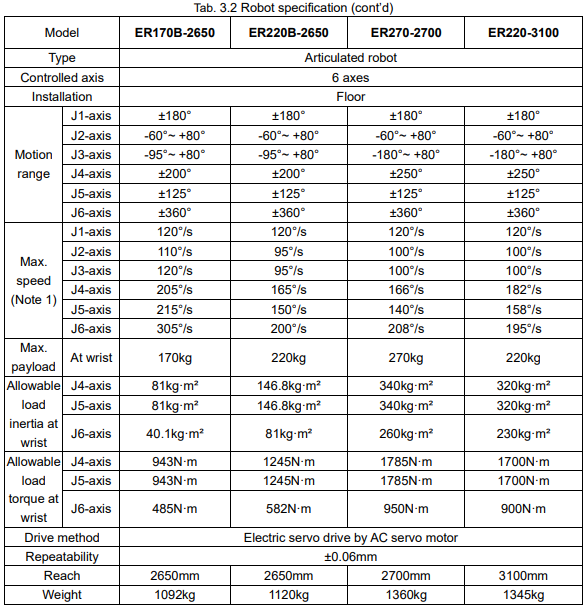
(Note 1) During short distance motions, the axis speed may not reach the maximum value stated. The maximum speed is measured at zero position of the robot, and will be limited by the position of other axes.
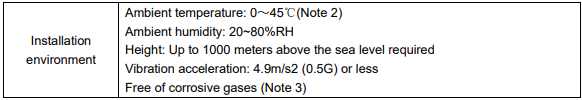
(Note 2) When the robot is used in low temperature environment that is near 0℃ or not operated for a long time in the environment that is less than 0℃ in a holiday or the night, collision detection alarm may occur since the resistance of the drive mechanism could be high immediately after starting the operation. In this case, we recommend performing the warm up operation for several minutes.
(Note 3) Contact the service representative, if the robot is to be used in an environment or a place subjected to hot/cold temperatures, severe vibrations, heavy dust, cutting oil splash and or other foreign substances.
3.2. EXTERNAL DIMENSIONS AND OPERATING SPACE
The following figures show the robot operating space, for the reference of robot installation. When install peripheral devices, be careful not to interfere with the robot and its motion range.
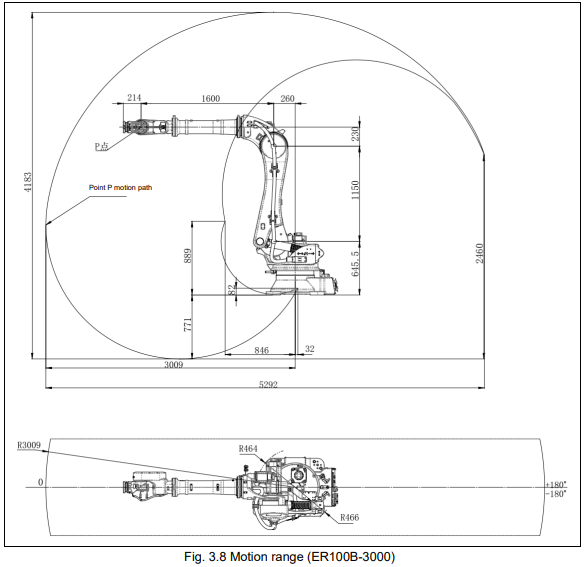
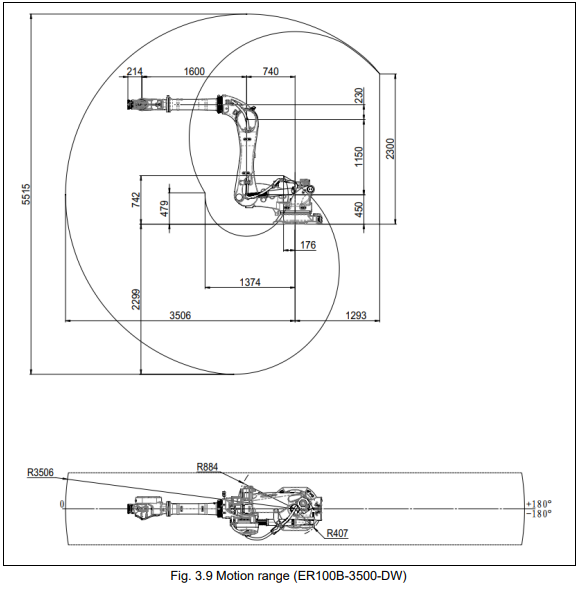
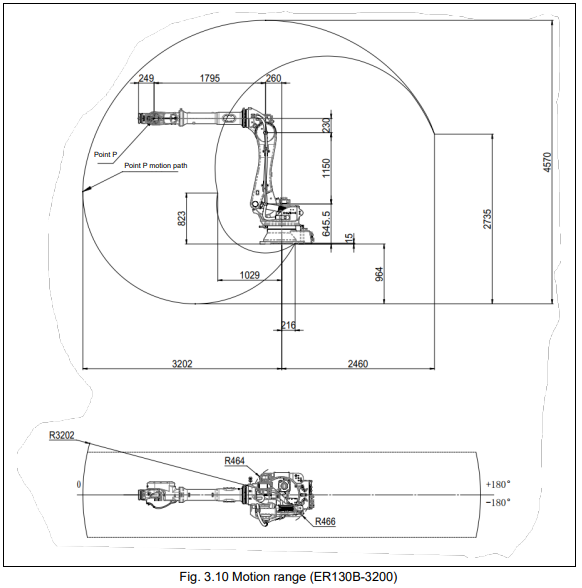
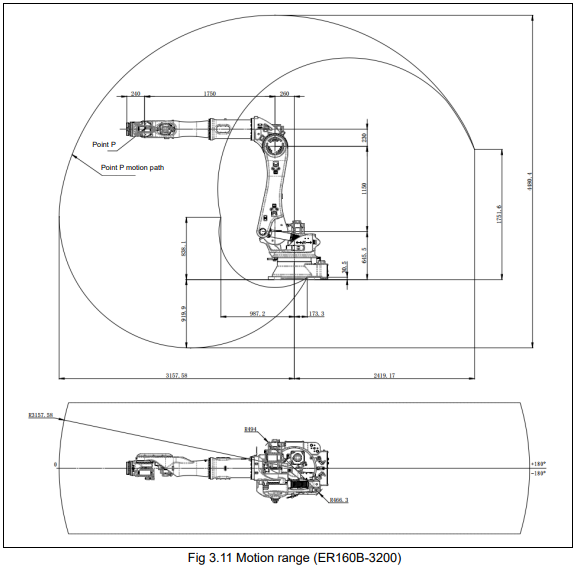
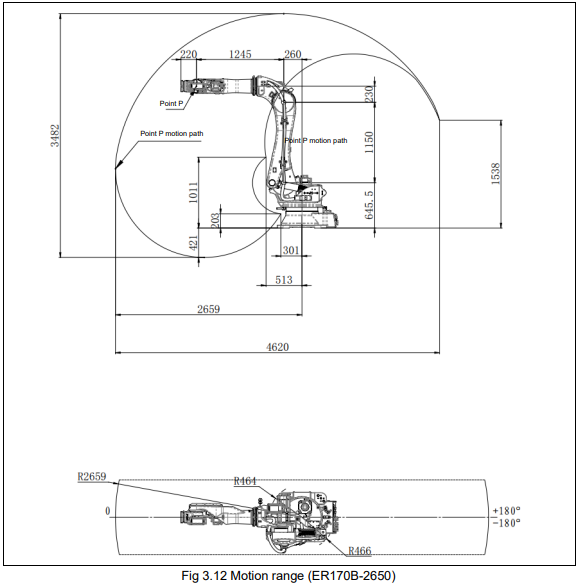
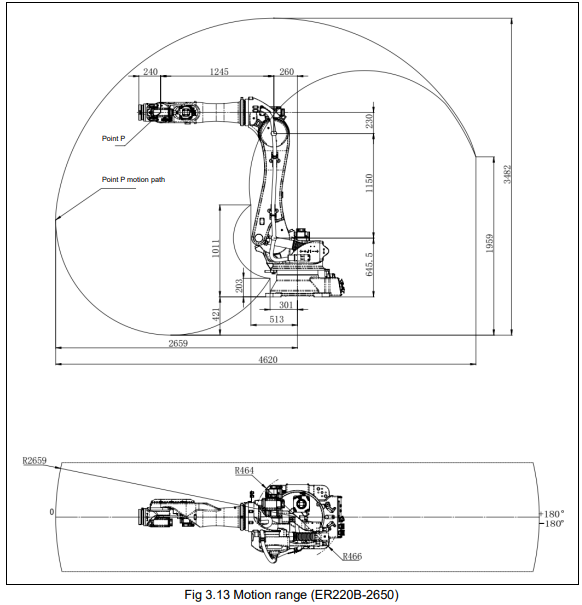
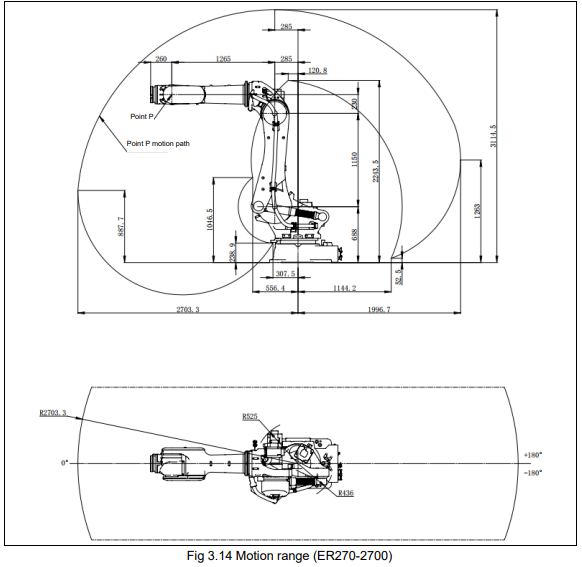
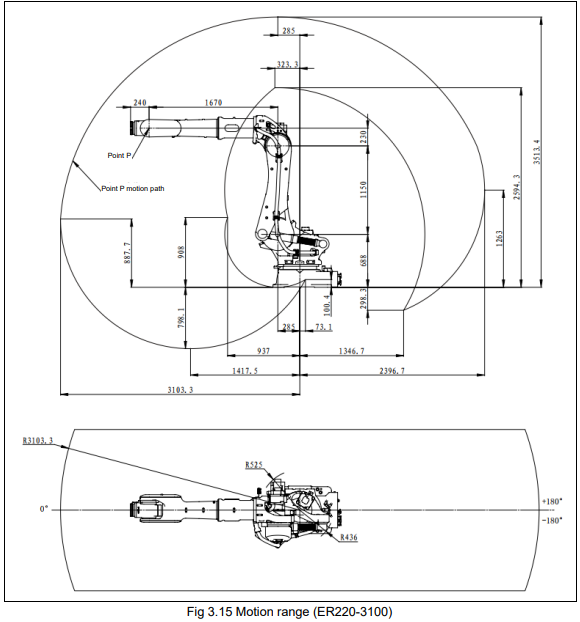
3.3. ZERO POINT POSITION AND MOTION LIMIT
Zero point and motion range are provided for each controlled axis. Exceeding the software motion limit of a controlled axis is called overtravel (OT). Overtravel is detected at both ends of the motion limit for each axis. The robot cannot exceed the motion range unless there is a loss of zero point position due to abnormalities in servo system or system error.
In addition, the motion range limit by a fixed mechanical stopper is also prepared to improve safety.

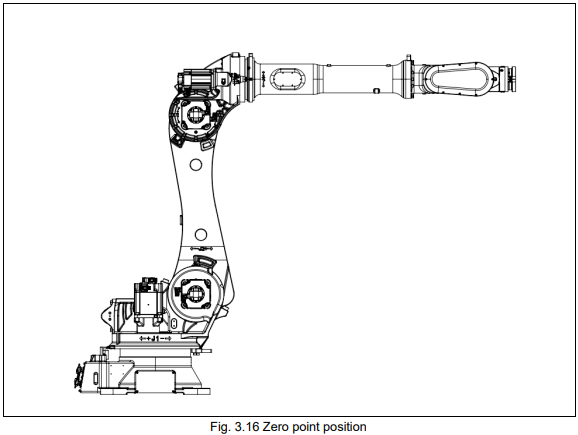
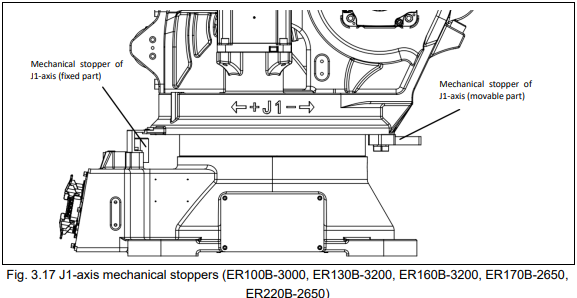
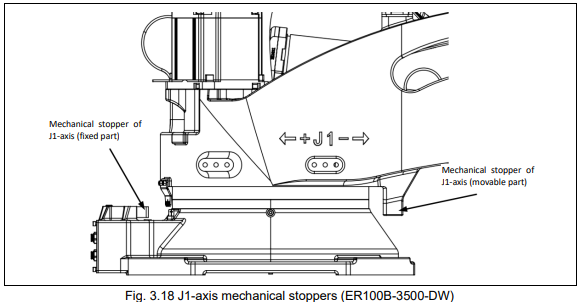
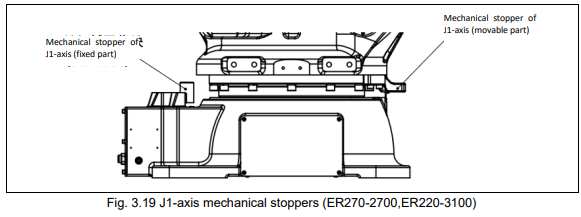
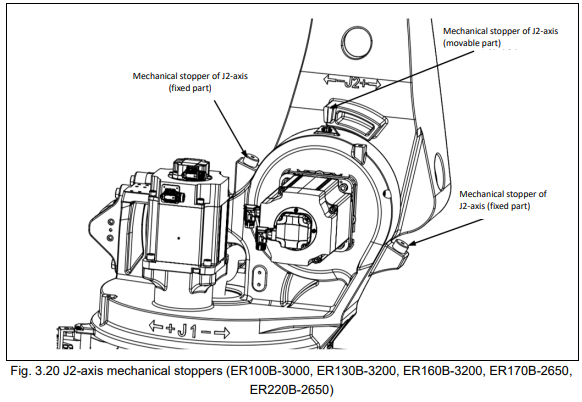
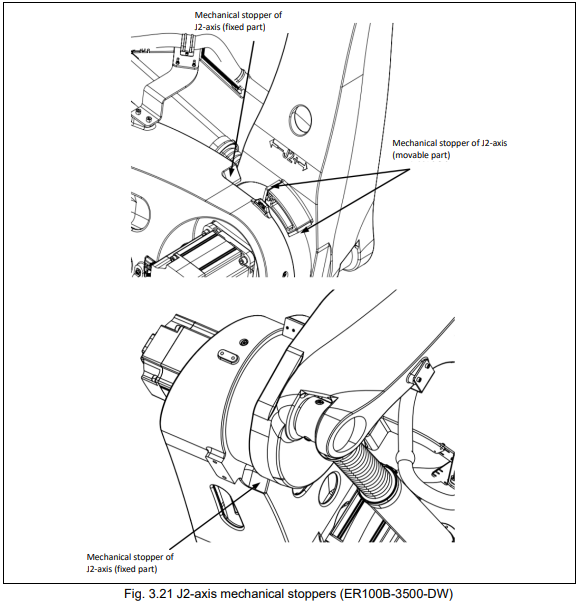
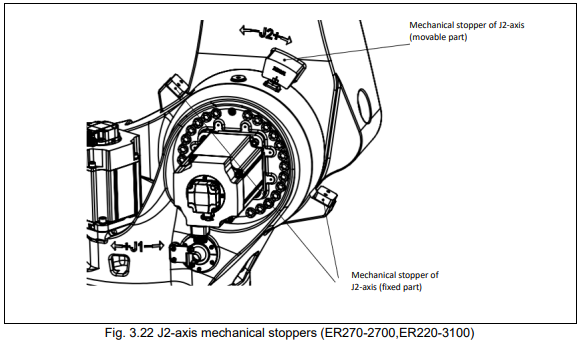
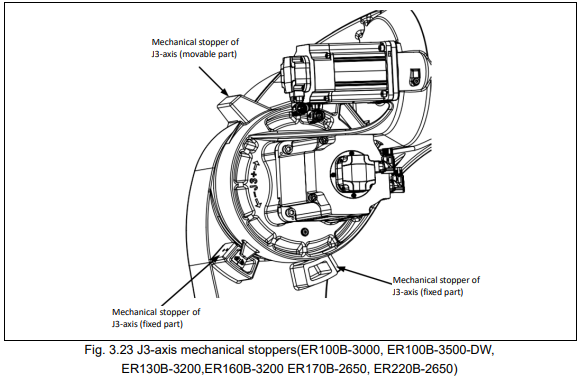
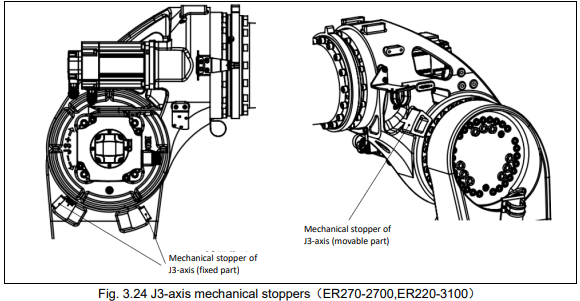
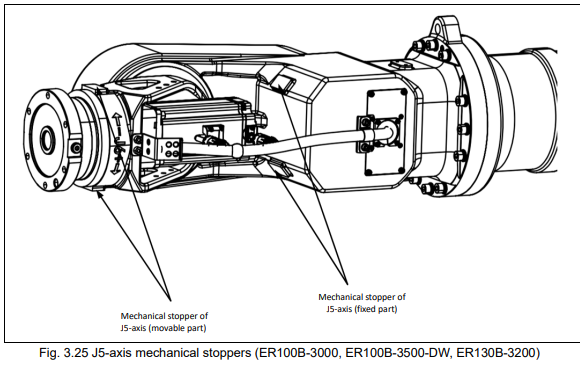
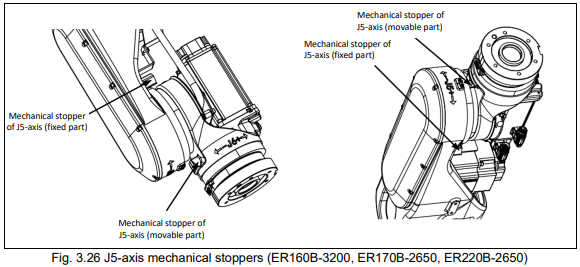
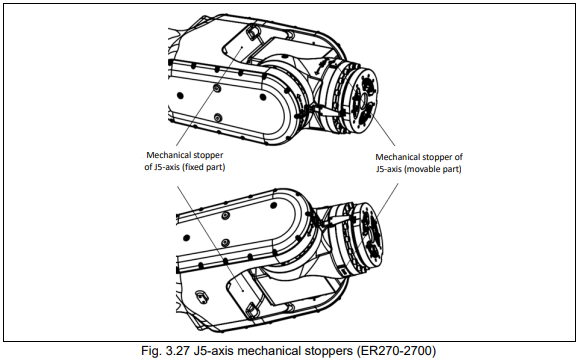
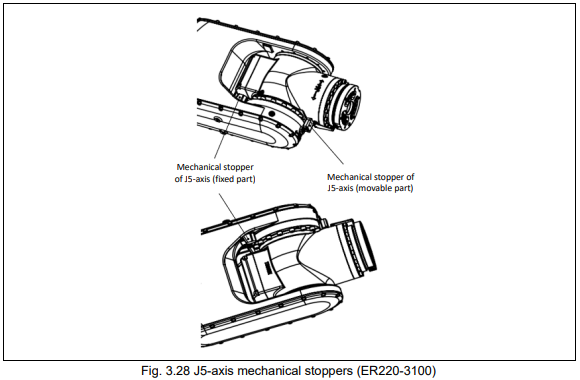
Refer to system operation manual for more information about setting motion range.
3.4. WRIST LOAD CONDITION
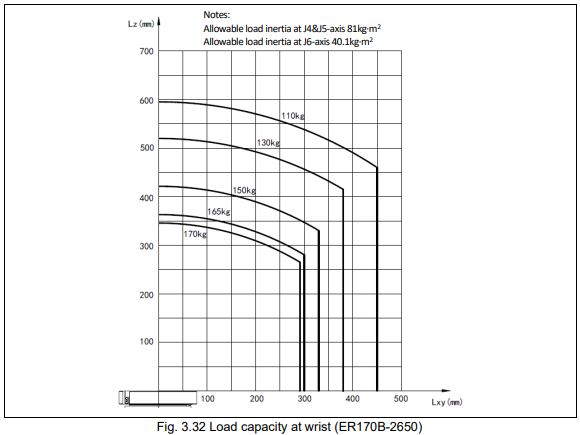
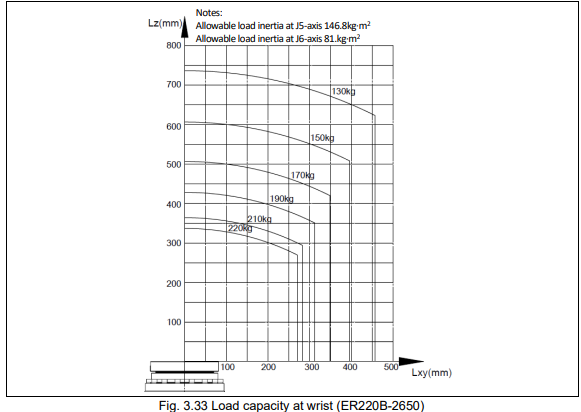
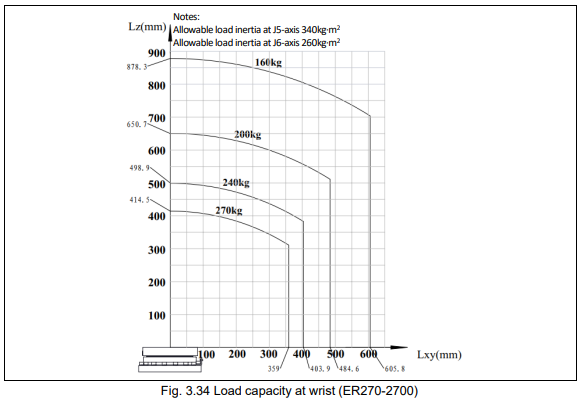
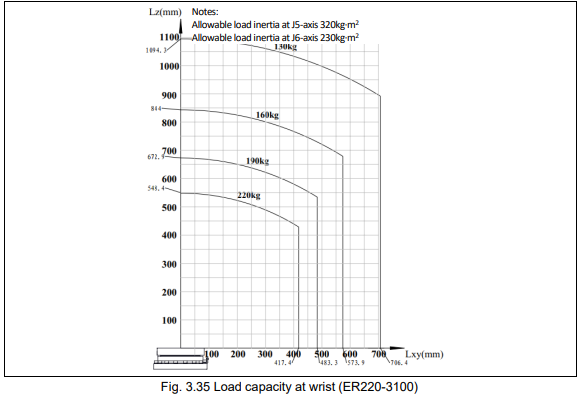
Robot load capacity (including weight of gripper or welding gun) coincides with robot model. Observe restrict of load torque and load inertia strictly.
Refer to ESTUN robot bearing capacity calculation table when calculate load torque and load inertia. Contact ESTUN sales representatives for more detail.
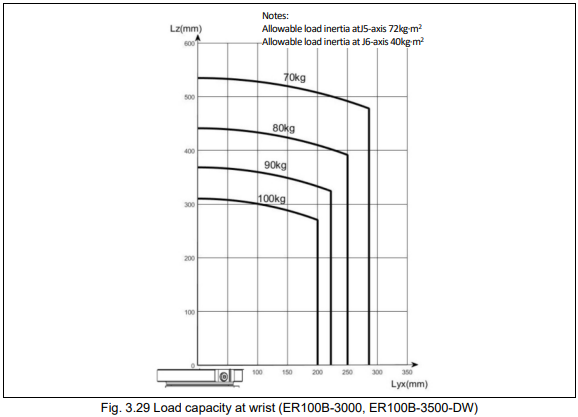
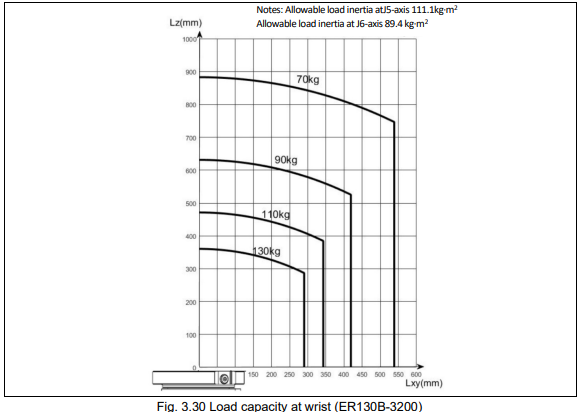
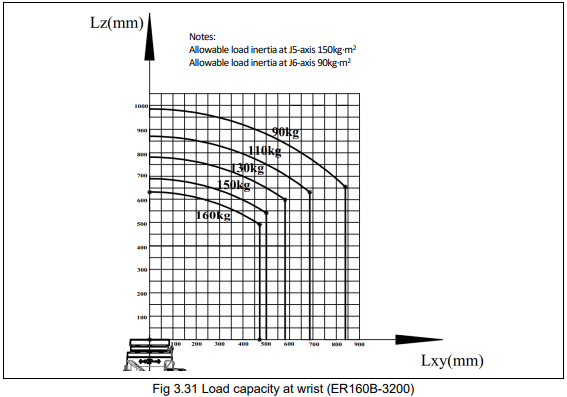
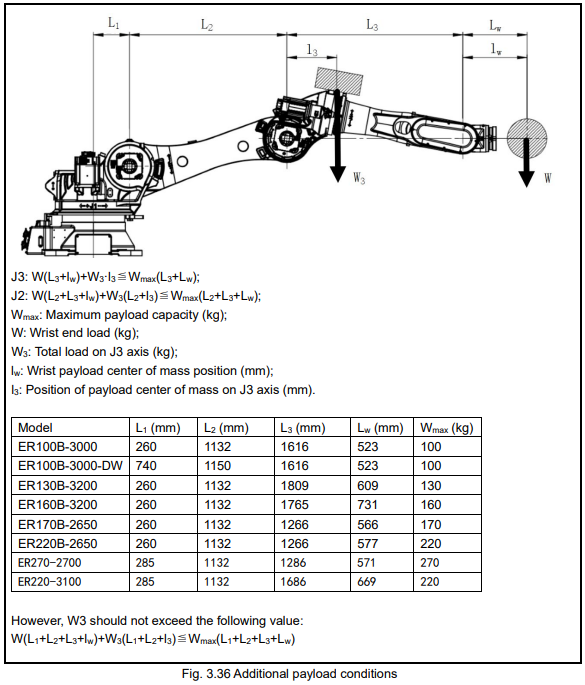
3.5 Additional payload conditions
Additional loads can be added to each robot of this series. The payload conditions are detailed as follows.
No comments to display
No comments to display