
5. Robot System Structure and Connection
5.1 Introduction to this chapter
ROKAE has several series of robots. This chapter mainly introduces the system structure and connection mode of different series of robots to deepen users' understanding of robot systems. Users can optionally read the contents of this chapter based on the model they use.
5.2 Control system structure
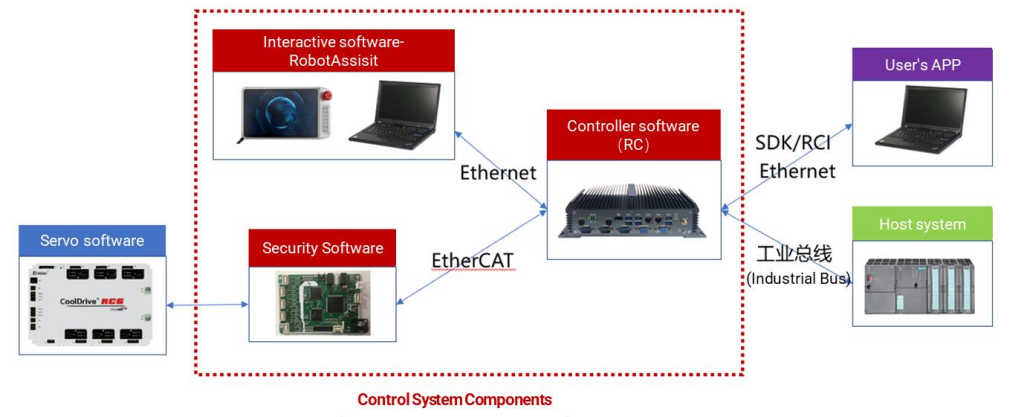
xCore control system is based on CS architecture, including HMI software (RobotAssist) and controller software RC.
5.2.1 xPad2 Teach Pendant introduction
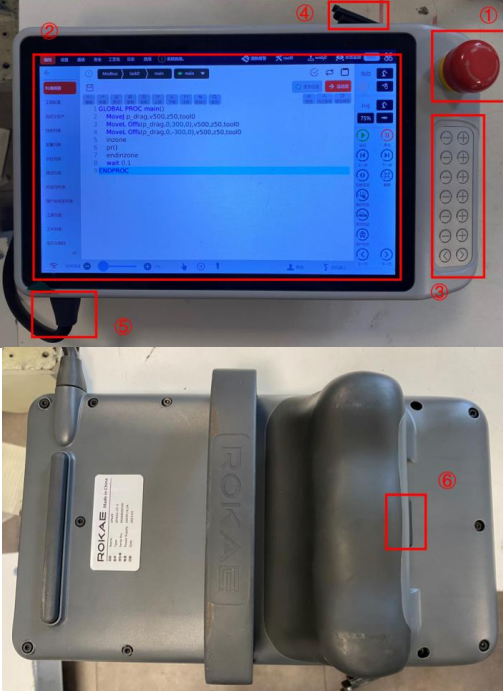
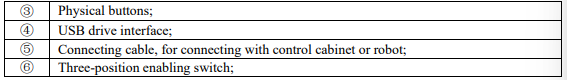
The buttons and their functions of xPad2 Teach Pendant are described below

5.3 Industrial robot system composition
This chapter mainly introduces the structure, wiring, and power-on start-up methods of industrial robots. There may be certain differences in the robot body and control cabinet depending on the robot's specific model. For more information, please refer to the XBC5 Series Controller (xCore System) Product Manual.
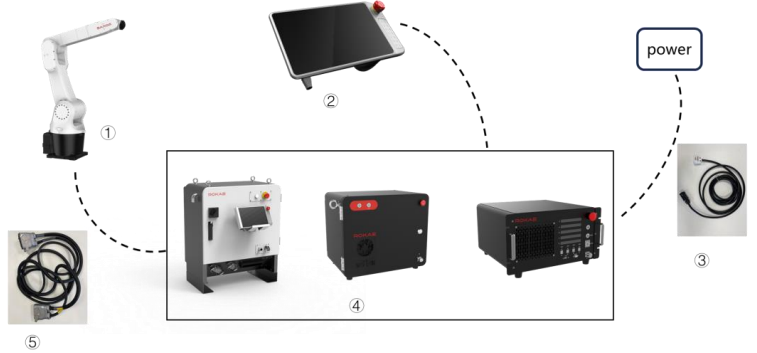
The main structure and wiring relations of an industrial robot system are shown in the figure below, mainly including: robot body, Teach Pendant, control cabinet, relay cable, and power cord.
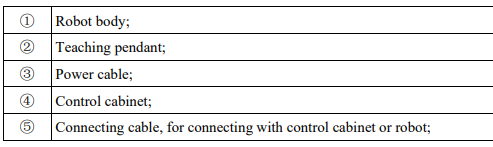
5.3.1 XBC5 series controller introduction
XBC5 series control cabinets include three models: XBC5, XBC5-E, XBC5-M. Taking XBC5-M as an example, the main components and functions of the cabinet are briefly introduced, to which other models are similar in components and functions.
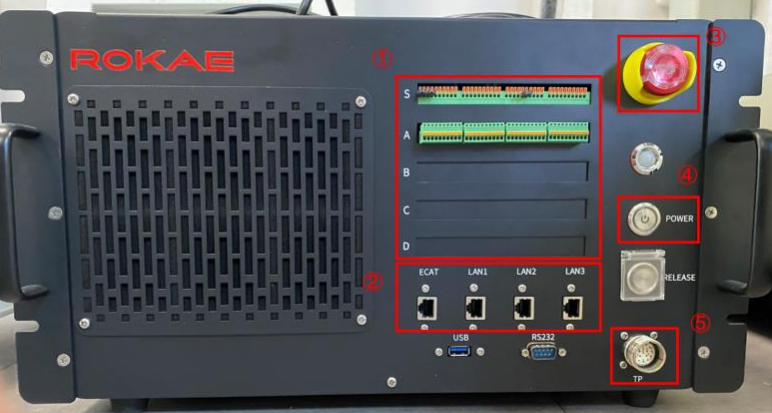
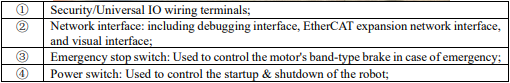

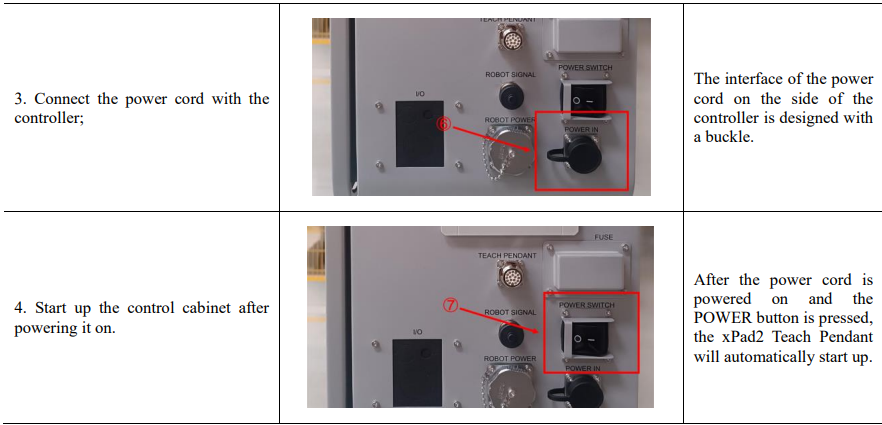
5.3.2 XBC5-M controller wiring, power-on, and start-up
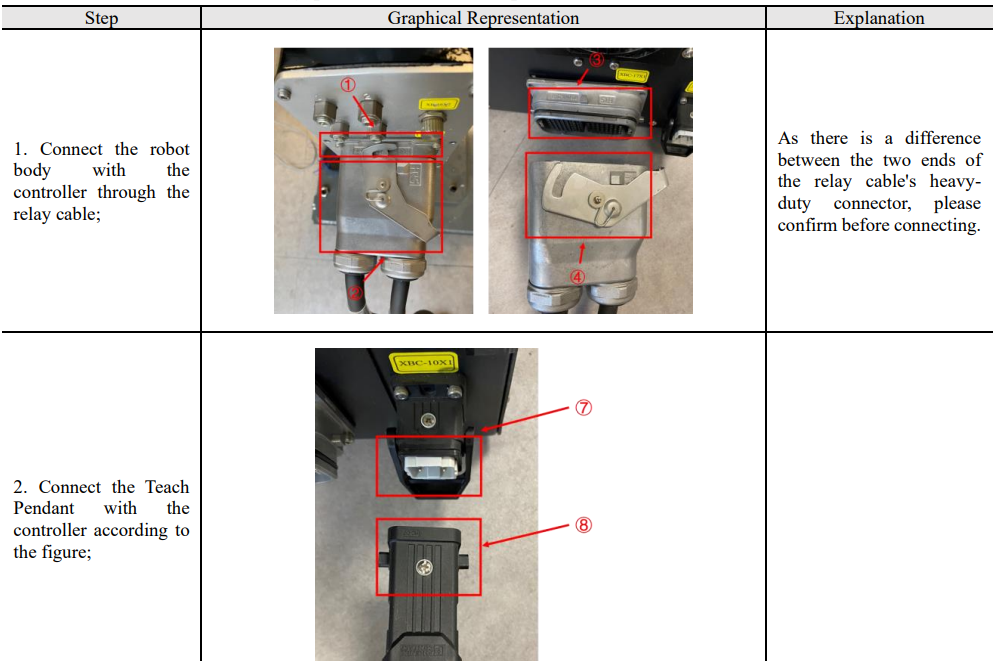
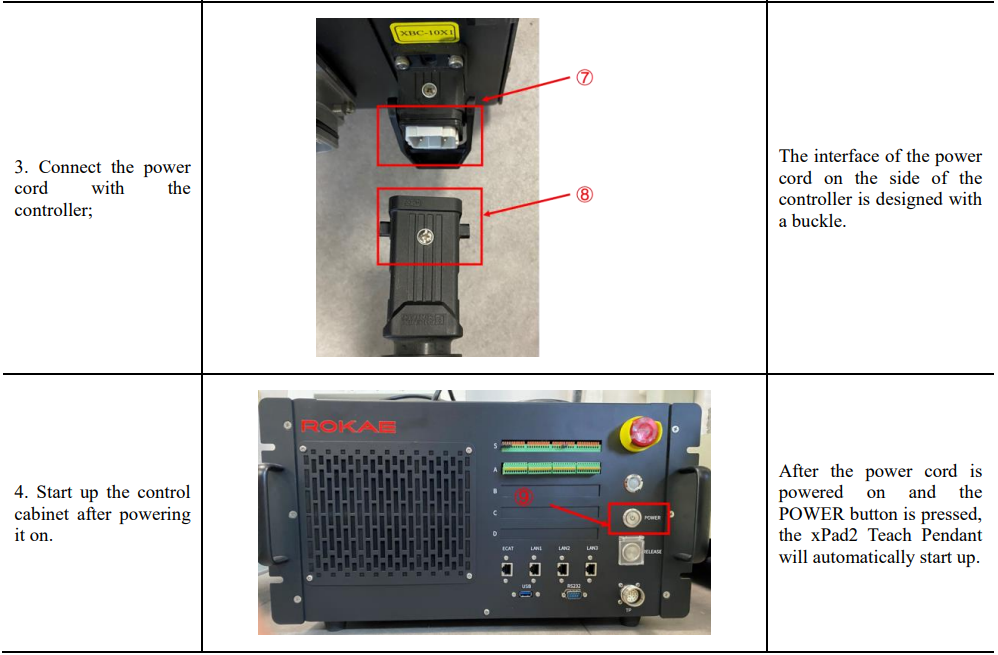
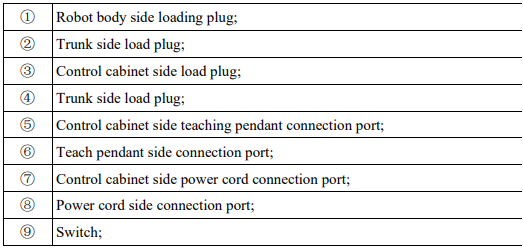
5.3.3 XBC5 controller wiring, power-on, and start-up
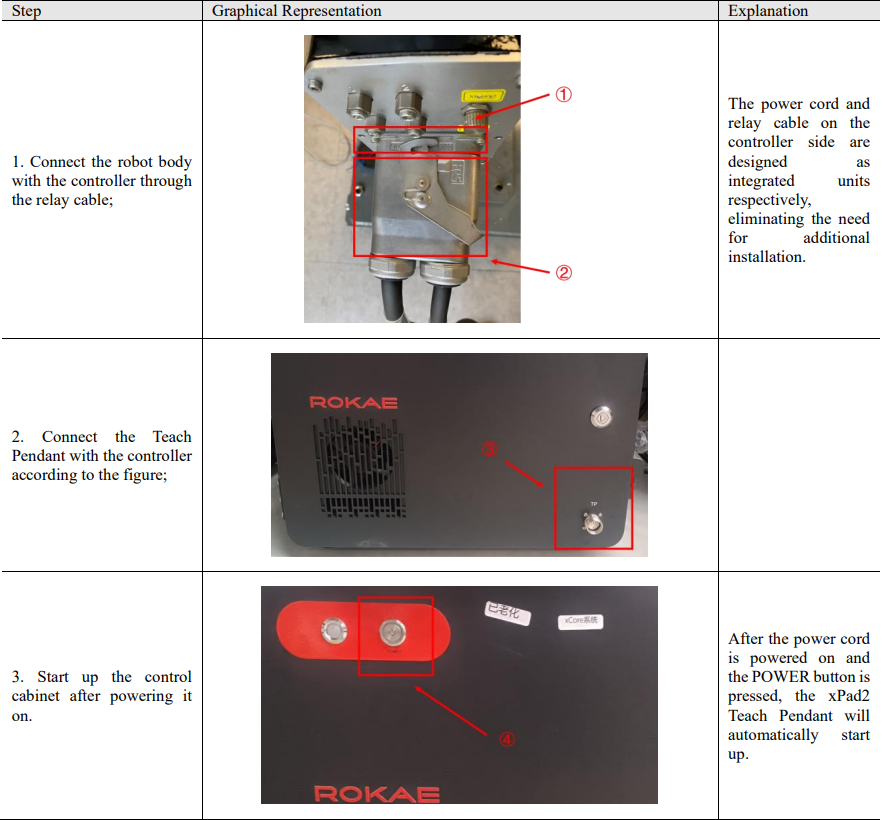
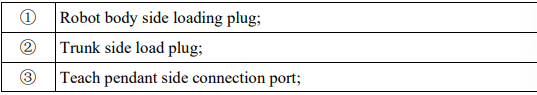

5.3.4 XBC5-E controller wiring, power-on, and start-up
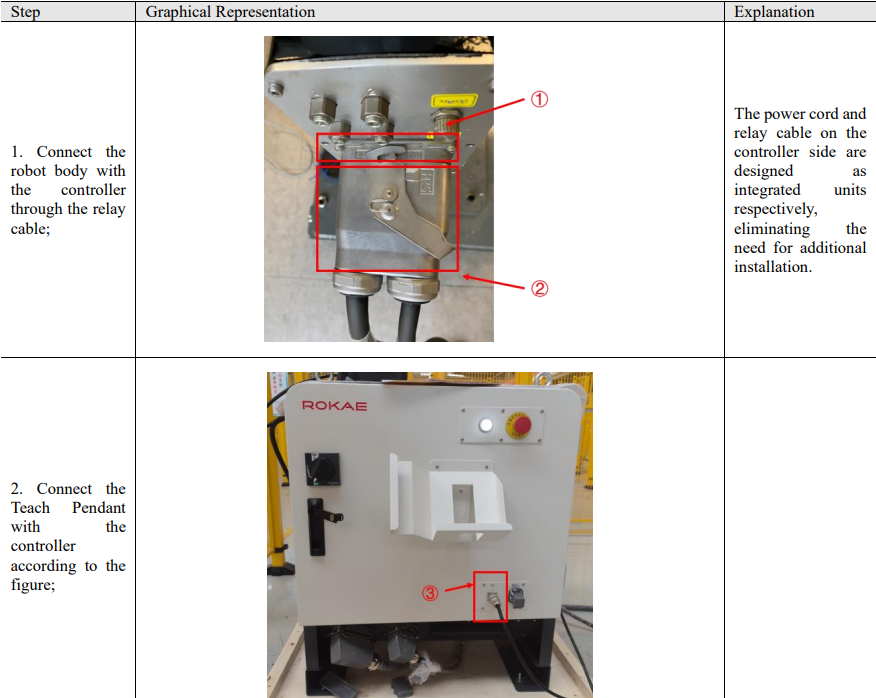
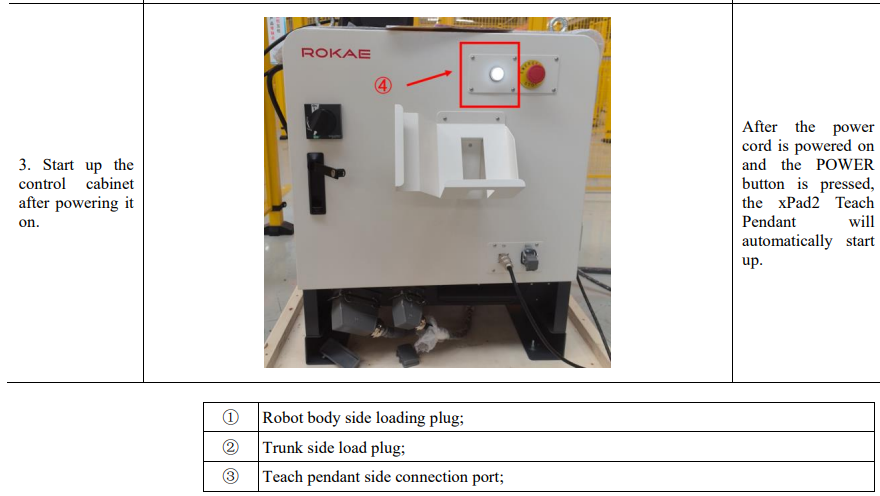

5.4 Collaborative robot system composition
5.4.1 ER and ER PRO
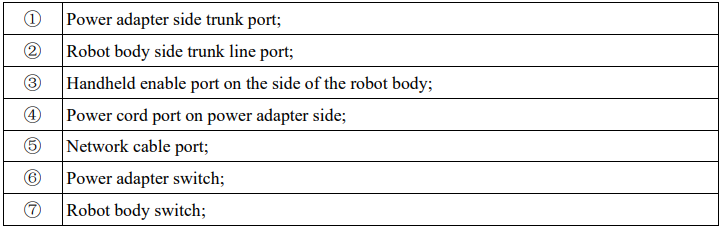
ER and ER PRO series are designed without a controller, and their system composition is shown in the figure below.
Attention: ER series robots do not support xPad2 Teach Pendant
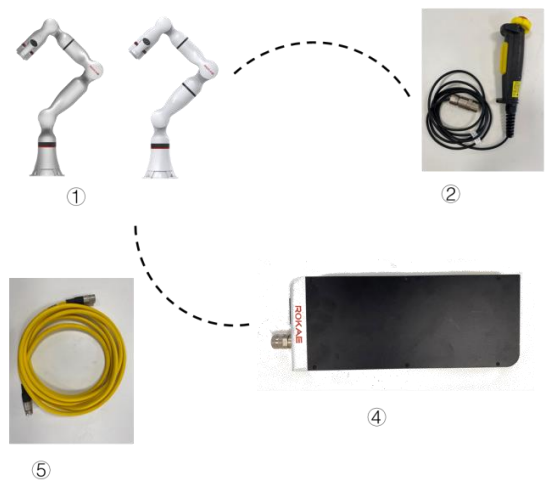
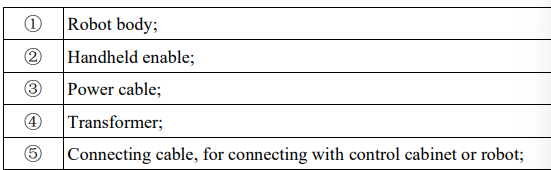
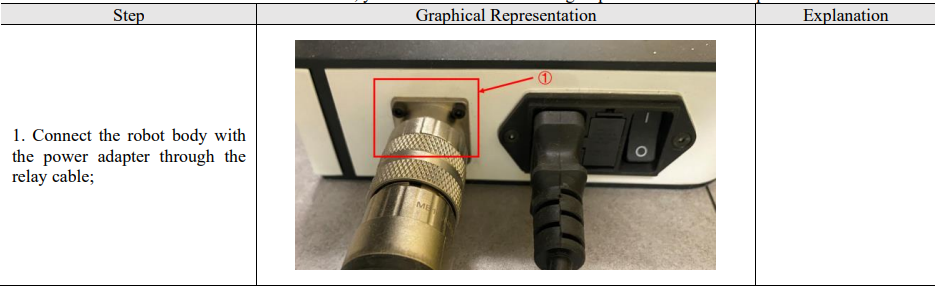
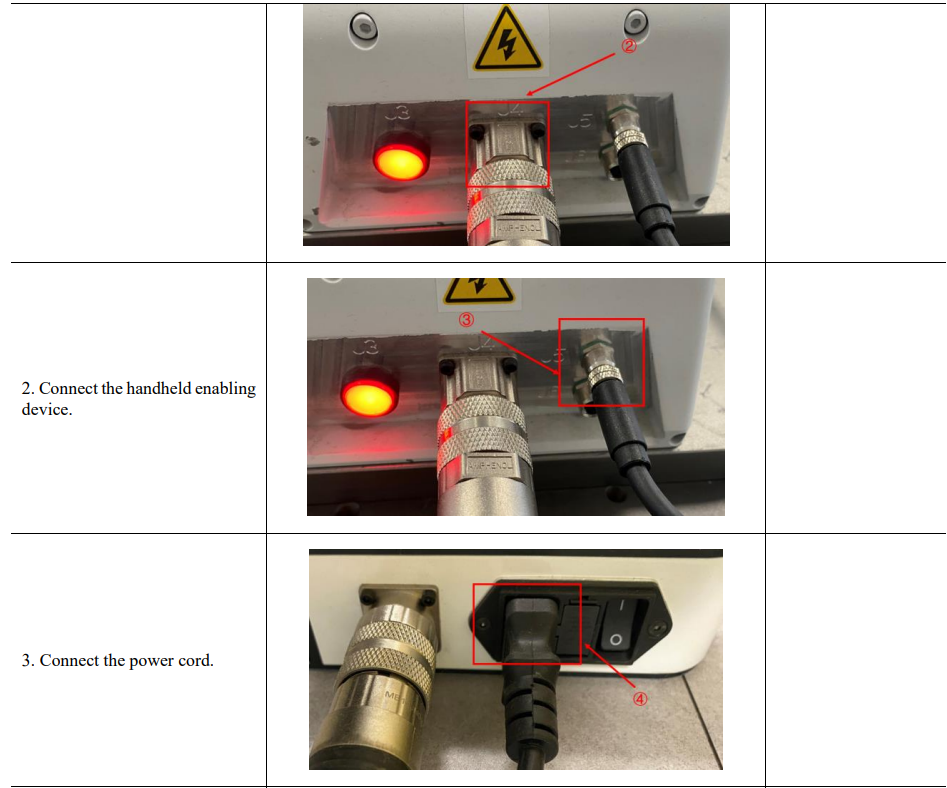
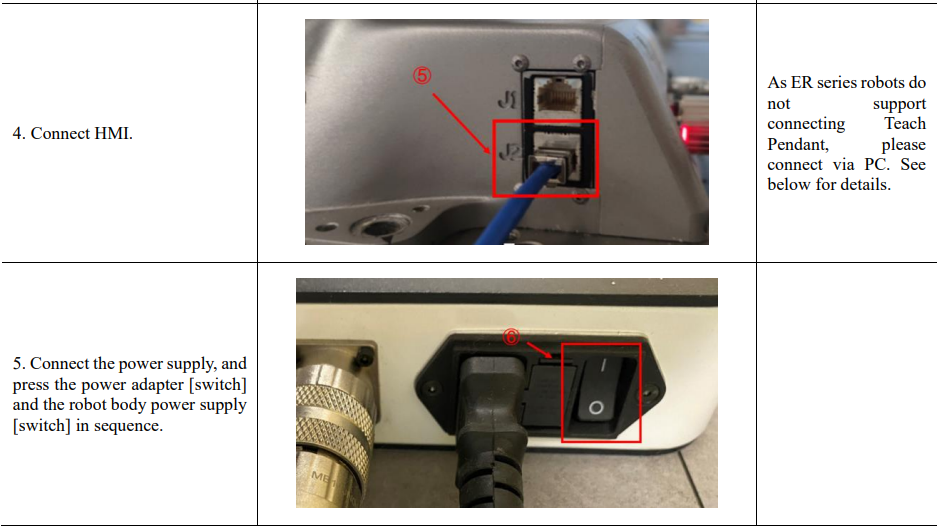
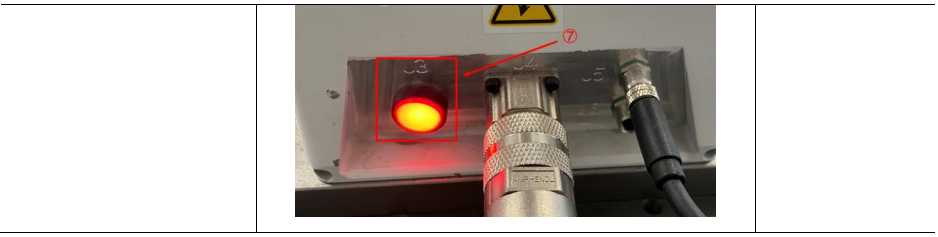
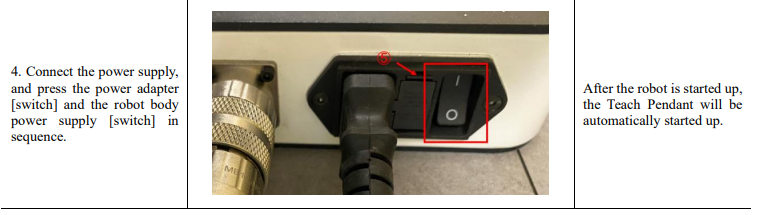
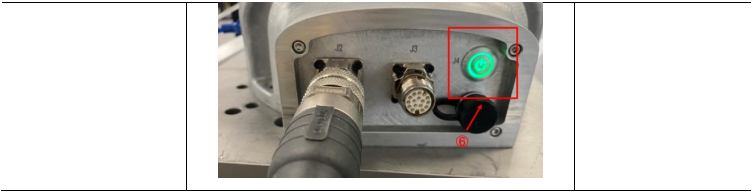
For ER series robots, you can refer to the following steps for connection and power-on
5.4.2 CR and SR
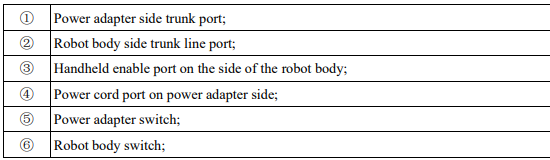
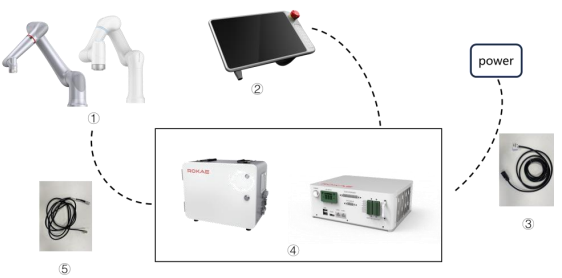
CR and SR series collaborative robots are designed without a controller, and their system composition is shown in the figure below.
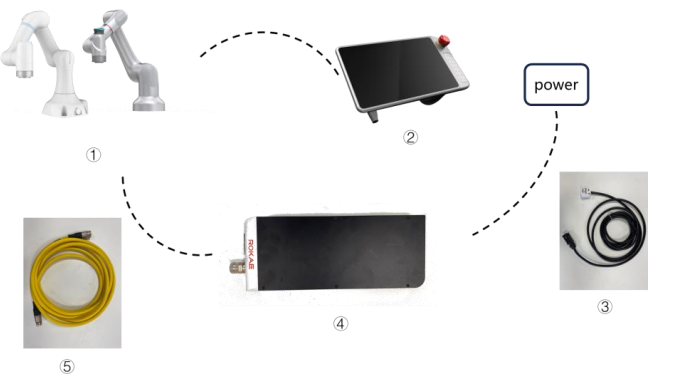
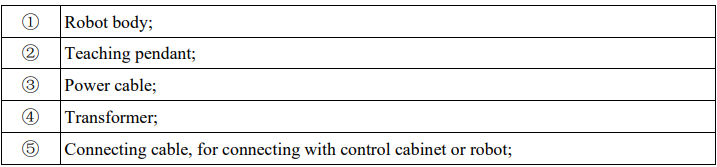
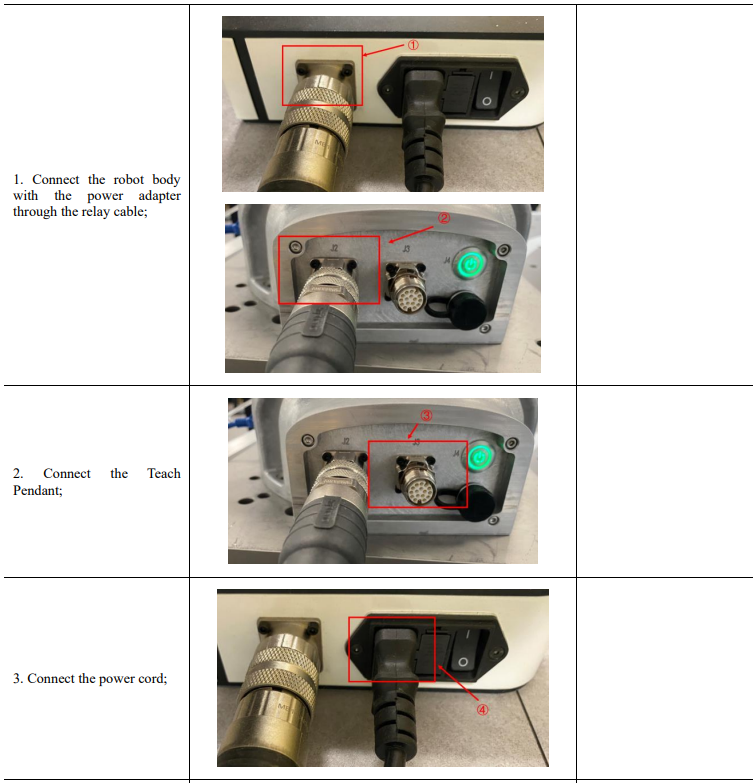
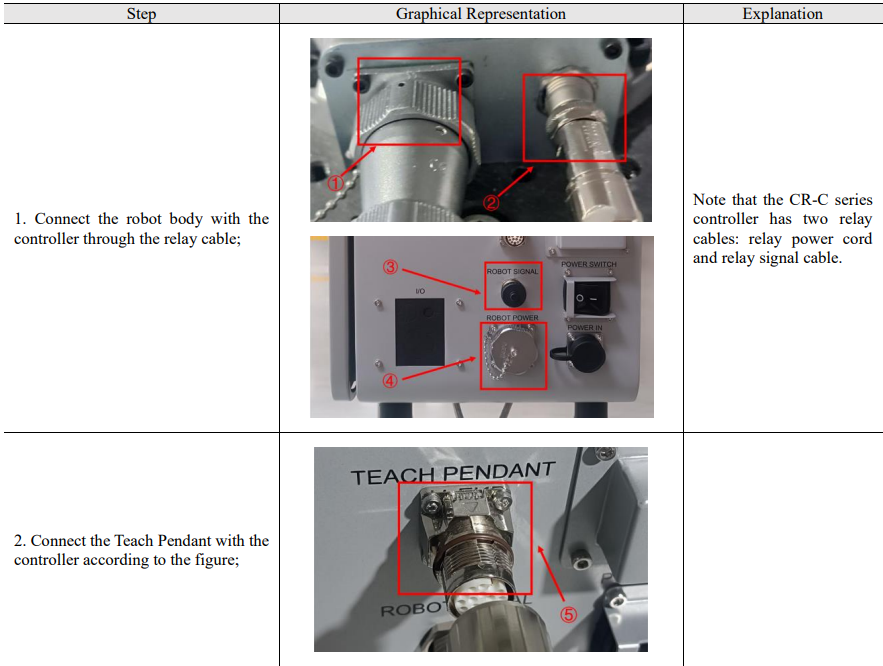
For CR series robots, you can refer to the following steps for connection and power-on. SR series is similar to CR series in connection and power-on

5.4.3 CR-C and SR-C
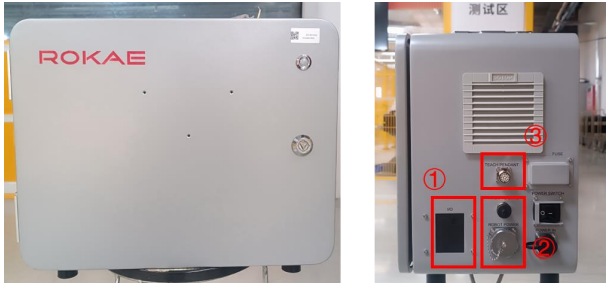
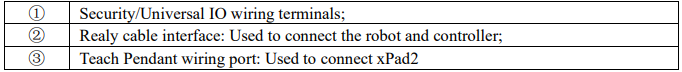
CR and SR series collaborative robots are designed with a controller, and their system composition is shown in the figure below.
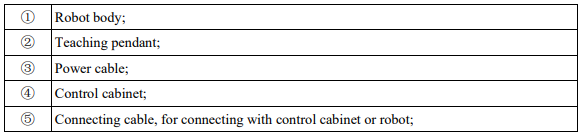
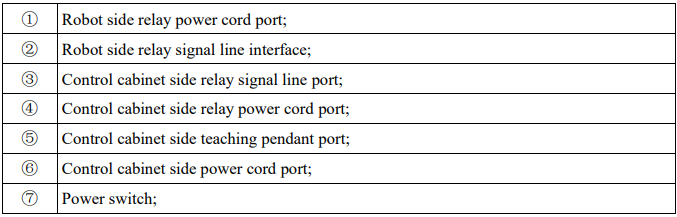
5.4.3.1 SR-C controller and its wiring, power-on and start-up
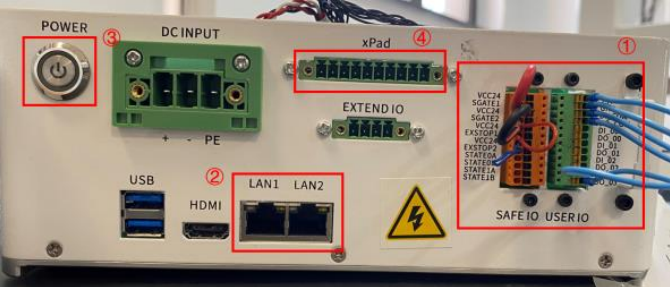
① Security/Universal IO wiring terminals;
② Network interface: including debugging interface and visual interface;
③ POWER switch: Used to control the power on/off state of the robot;
④ Teach Pendant wiring port: used to connect xPad2.
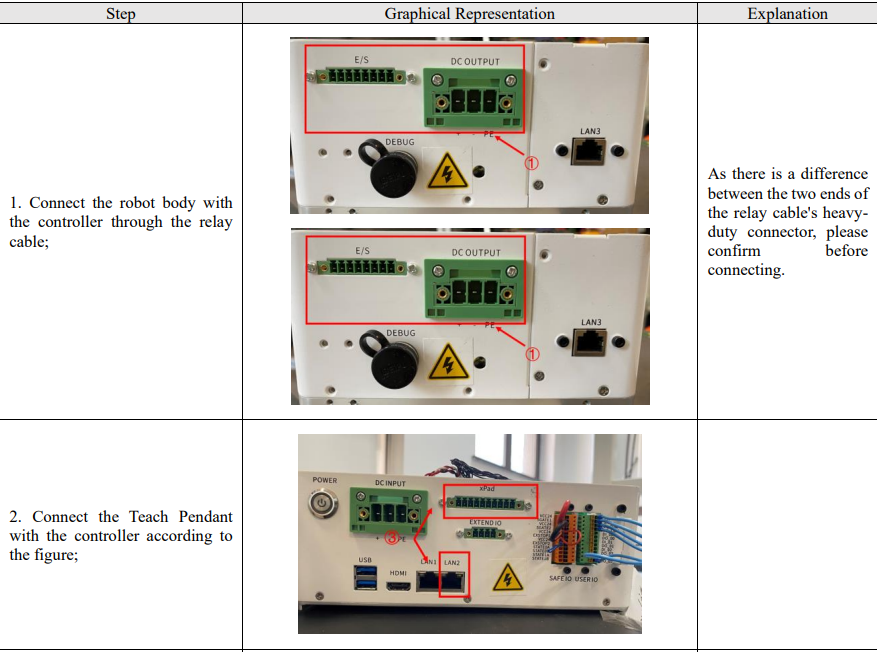
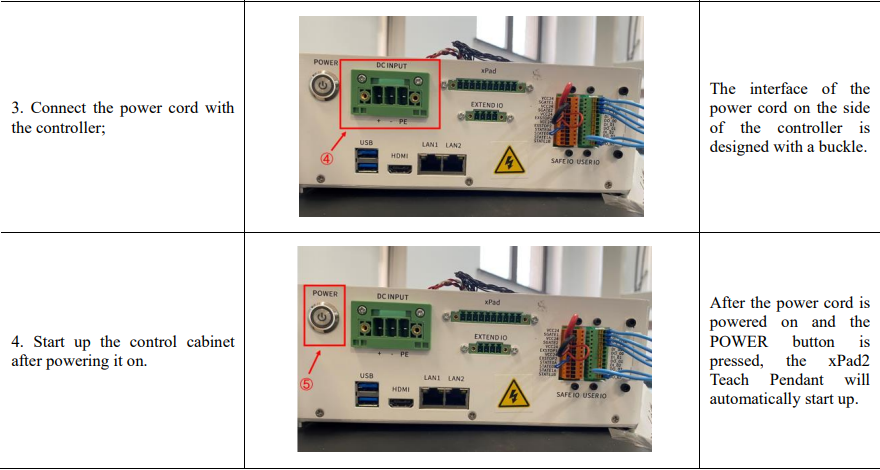

5.4.3.2 CR-C controller and its wiring, power-on, and start-up
5.5 HMI and robot connection
Robot Assist, as the host computer software of the robot, can run on PC, xPad2, and other devices. You can connect the device where the Robot Assist software is located and the robot to the same LAN (local area network) and establish a connection with the connected robot by robot detection, manually entering the controller service address, etc.
5.5.1 xPad2 and robot connection
For the use of the Teach Pendant xPad2, the default network segment of the Teach Pendant is 192.168.1.X. You need to first modify the IP address of the Teach Pendant to be in the same network segment as the robot body, and then connect the xPad2 to the corresponding port of the robot;
5.5.1.1 Hardware connection
5.5.1.2 Connection configuration
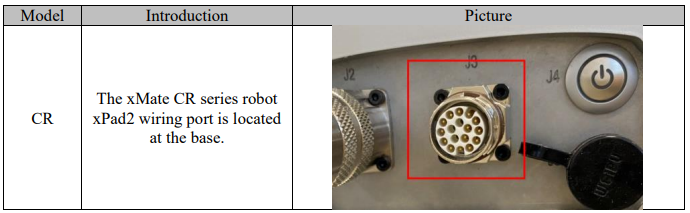
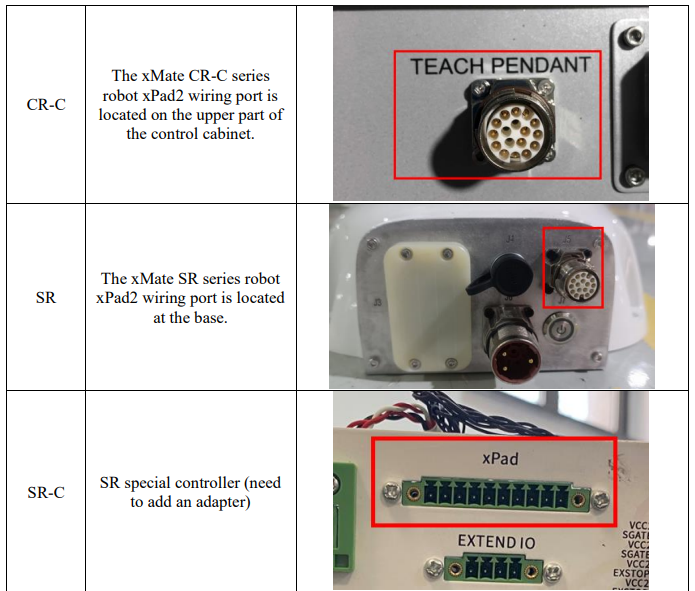
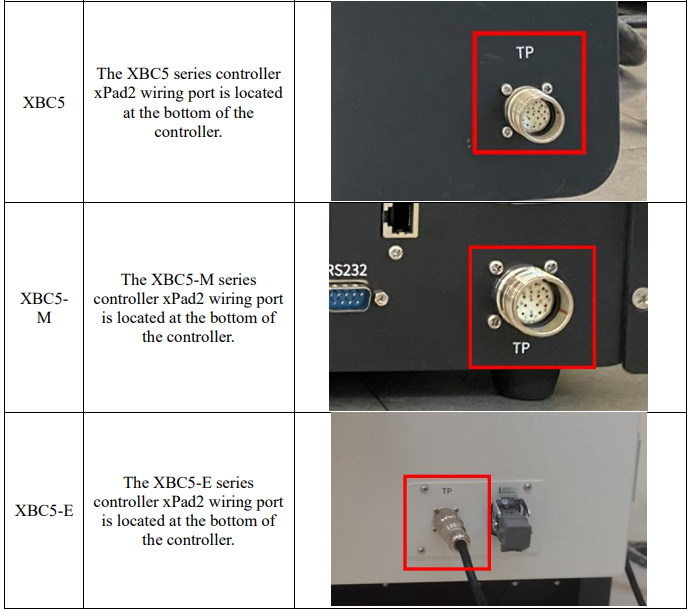
After the hardware connection is completed and the robot is started up, xPad2 will be automatically started up and start its built-in Robot Assist software.
5.5.2 PC and robot connection
5.5.2.1 Hardware connection
5.5.2.1.1One-to-one HMI and robot connection
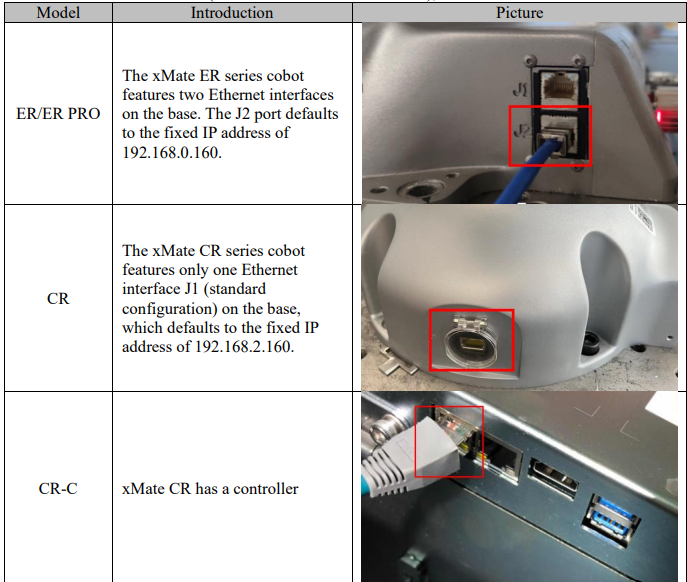
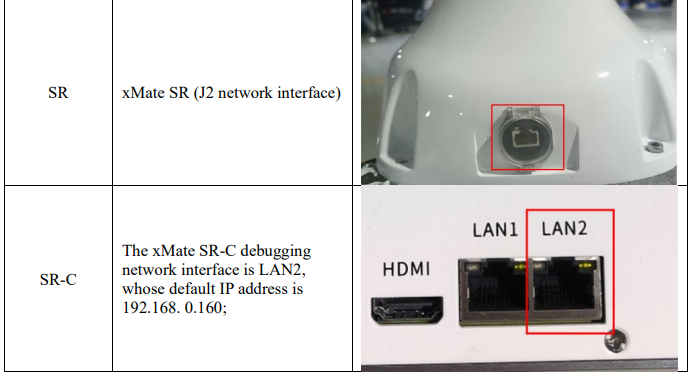
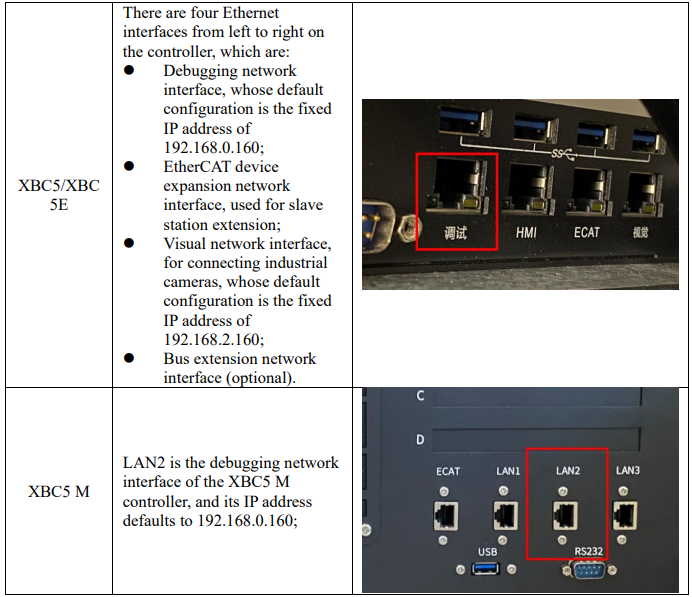
When using a PC on which Robot Assist is running to debug a robot, the PC can be directly connected to the robot via network cable (table+illustration concretization);
5.5.2.1.2One-to-multiple HMI and robot connection
When switching between multiple robots, these robots can be connected to the same LAN, and the PC on which Robot Assist is running will detect the robots available for connection on the same network segment;
5.5.2.1.3Wireless connection
For scenarios where a wired connection is not convenient (such as on AGVs), the robot can be connected to a wireless router via the reserved network interface (the network interface on the xMate cobot base; and the visual/debugging network interface of industrial robot controller) on the robot controller and then to the HMID wirelessly.
5.5.2.2 Connection configuration
5.5.2.2.1Direct cable connection
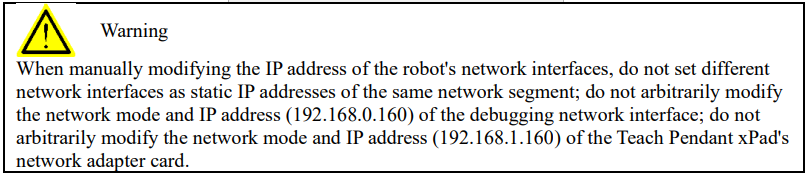
Both the robot base and the controller feature one network interface that defaults as the debugging network interface with the fixed IP address of 192.168.0.160. This IP address is the same for all robots and is not recommended to be modified arbitrarily. The PC on which Robot Assist is running can be connected to the network interface directly via a network cable to control the robot.
5.5.2.2.2External network interface connection
External network interface connection supports two types of settings: obtain an IP address automatically or assign a static IP address.
Obtain an IP address automatically — After the network interface J1 of cobots or the visual network interface of industrial robots is set to DHCP mode, and the robot is connected via the network interface to a router with DHCP, which automatically assigns an IP address to the robot, the robot can then be detected and connected via robot detection.
Assign a static IP address — After the network interface J1 of cobots or the vision network interface of industrial robots is set to the IP address in the required network segment, and the robot is connected via the network interface to a router, the robot can be visited and controlled via the robot's IP address.
5.5.2.2.3 Direct cable connection of devices such as PC
Both the robot base and the controller feature one network interface that defaults as the debugging network interface with the fixed IP address of 192.168.0.160. This IP address is the same for all robots and is not recommended to be modified arbitrarily. The PC on which Robot Assist is running can be connected to the network interface directly via a network cable to control the robot.
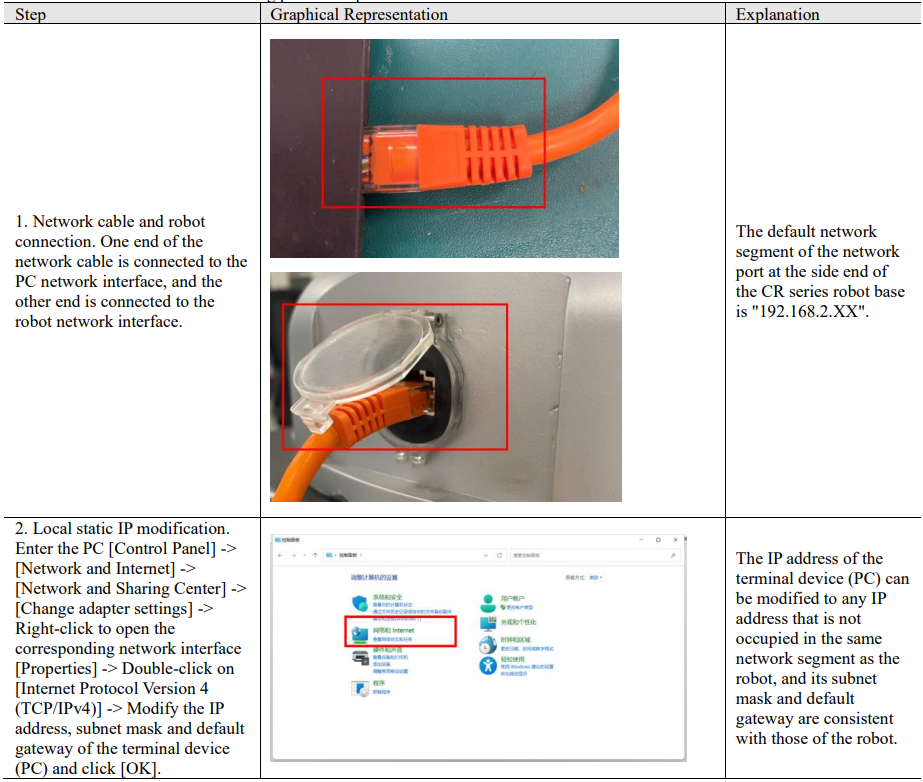
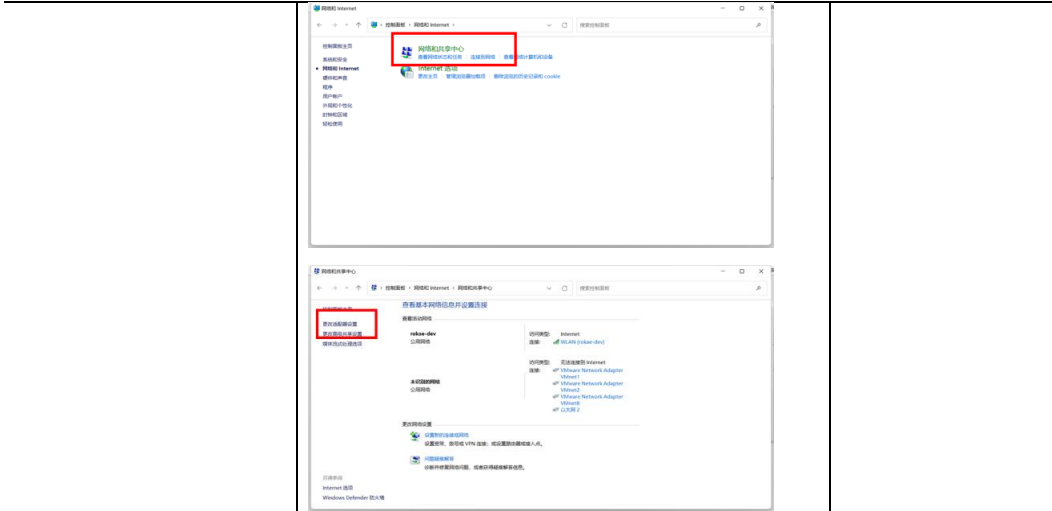
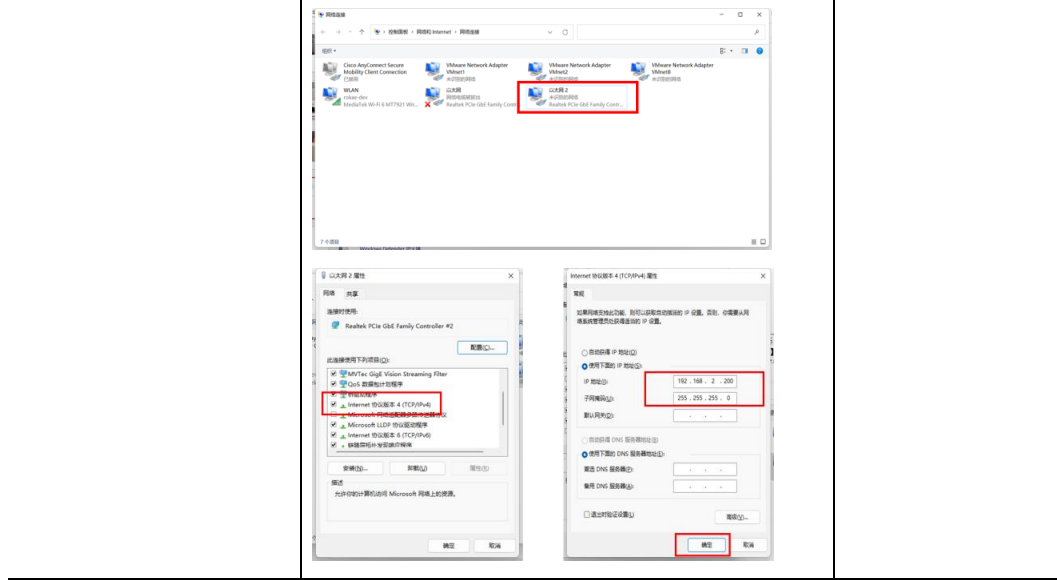
When using a mobile device such as a PC to connect to a robot, it is necessary to ensure that the LAN port address of the mobile device is in the same network segment as the robot. Regarding the modification method of PC (win11) static IP and robot (CR series) connection, you can refer to the following process steps:
5.5.2.2.4 Wireless connection of devices such as PC
After the network interface J1 of cobots or the visual network interface of industrial robots is set to DHCP mode, and the robot is connected via the network interface to a router with DHCP, which automatically assigns an IP address to the robot, the robot can then be detected and connected via robot detection.
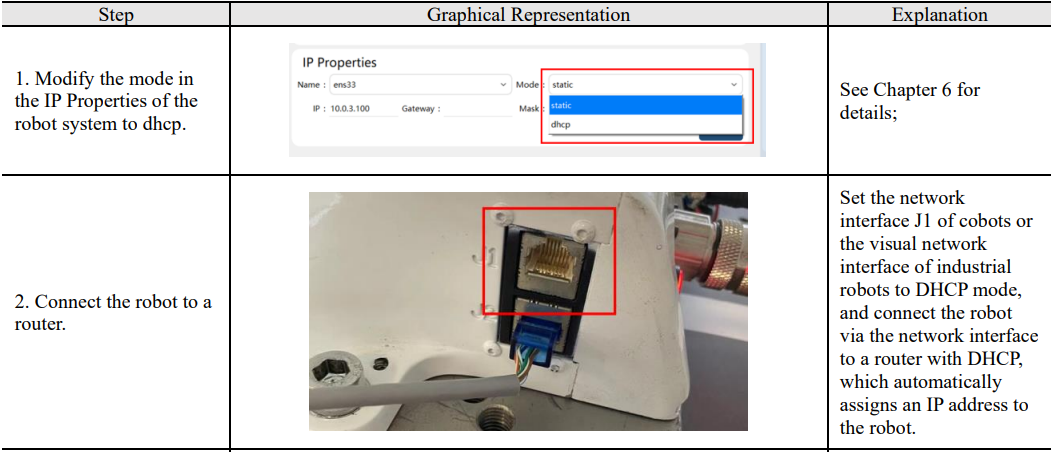
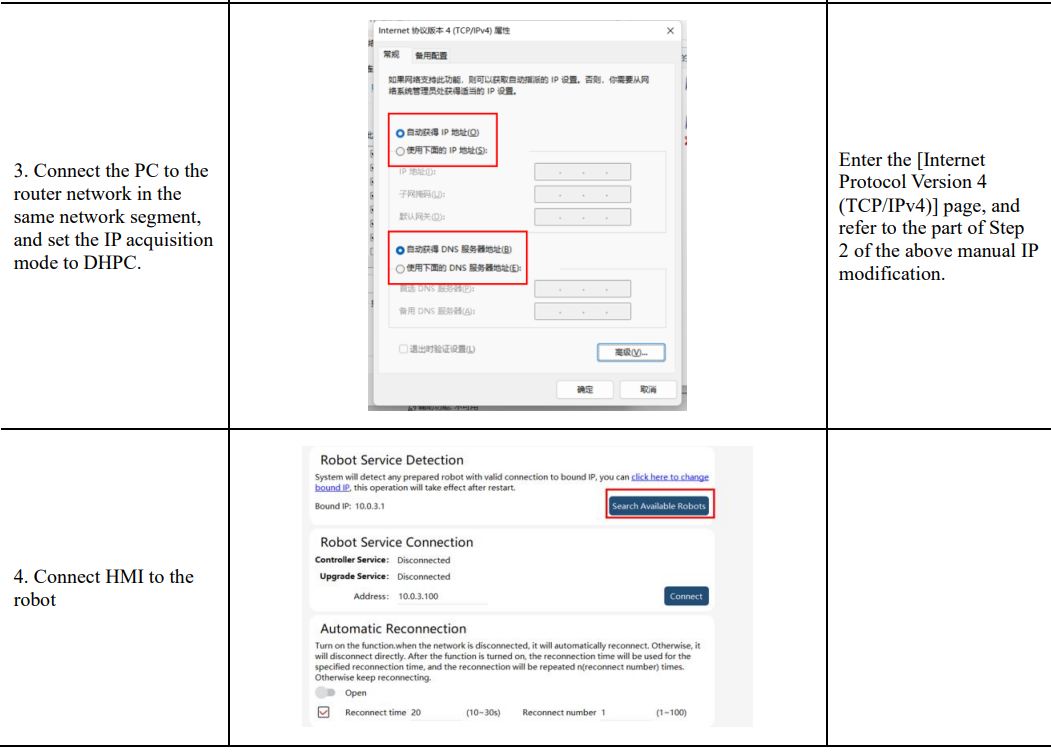
5.5.2.2.5 IP address modification
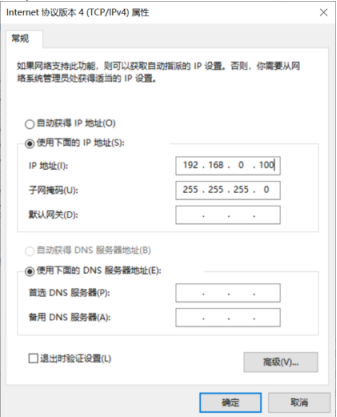
Using the Windows 10 operating system as an example, connect one end of the Ethernet cable to the robot's J2 interface and the other end to the terminal device (PC); click on the "Start > Control Panel" menu on the terminal device (PC), and select "Network and Sharing Center" (the "Network and Sharing Center" window will pop up); click on "Local Area Connection" in the "Network and Sharing Center" window (the "Local Area Connection Status" interface will appear); click on "Properties" in the "Local Area Connection Status" interface, (the "Local Area Connection Properties" interface will appear); double-click on "Internet Protocol Version 4 (TCP/IPv4)" in the "Local Area Connection Properties" interface, (the "Internet Protocol Version 4 (TCP/IPv4) Properties" interface will appear); and select "Use the following IP address" in the "Internet Protocol Version 4 (TCP/IPv4) Properties" interface, modify the IP address, subnet mask, and default gateway of the terminal device (PC), and confirm the changes. (The IP address of the terminal device (PC) can be modified to any IP address that is not occupied in the same network segment as the robot, and its subnet mask and default gateway are consistent with those of the robot)
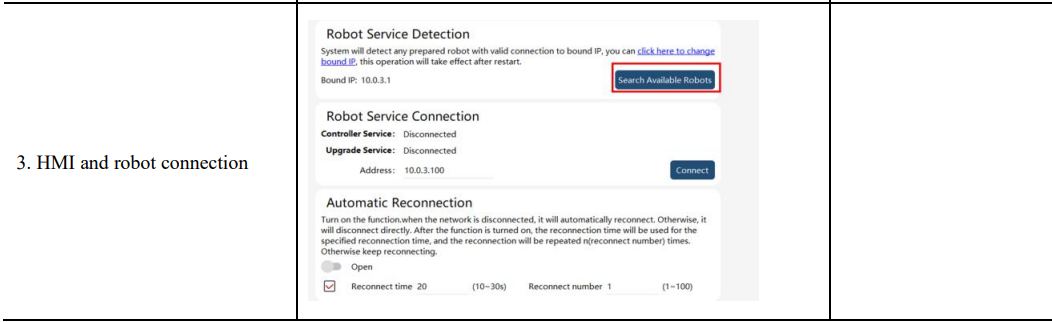
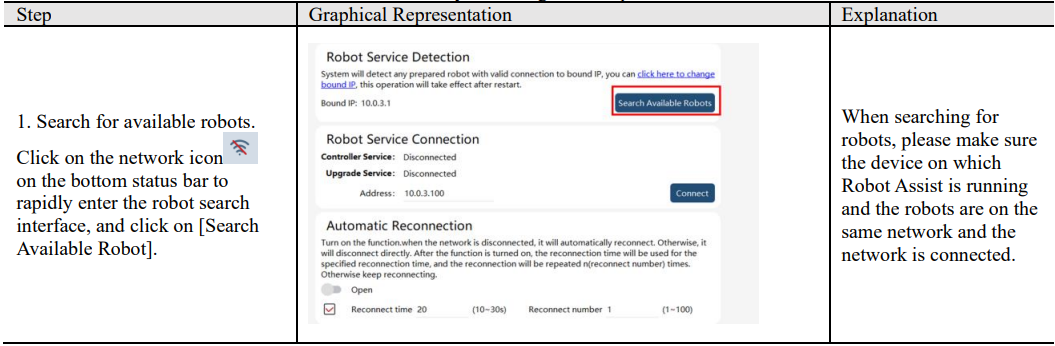
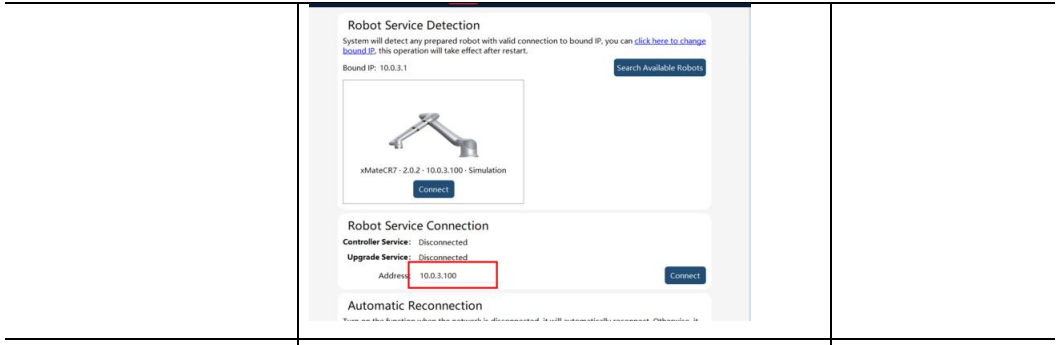
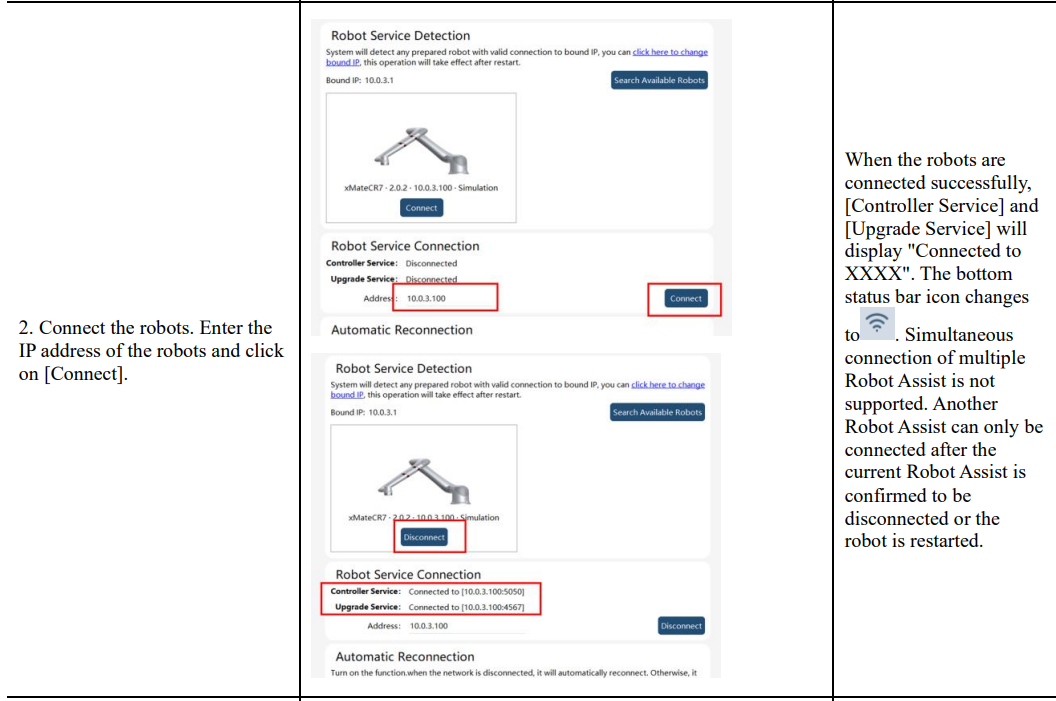
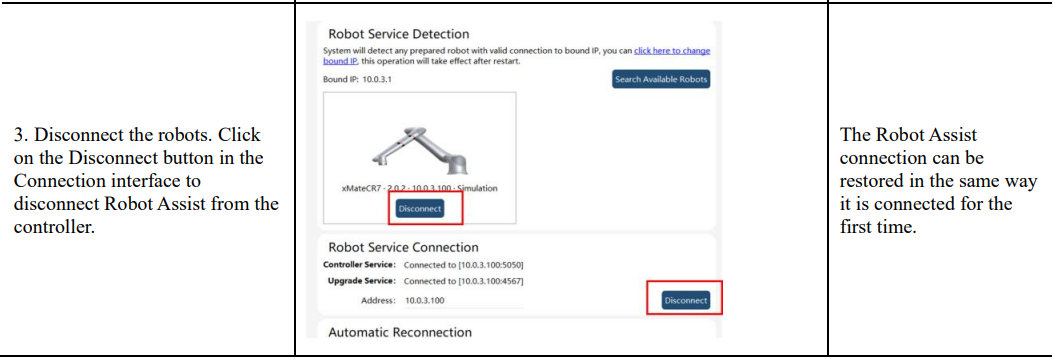
5.5.3 Robot detection and connection
HMI can detect and display all robots available on the same network segment for connection. You can detect and connect robots by following these steps.
No comments to display
No comments to display