
4. Equipment Installation
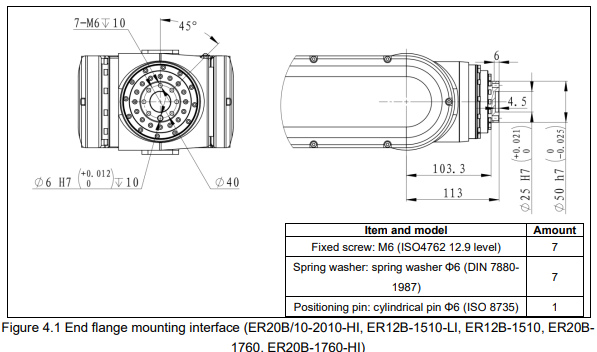
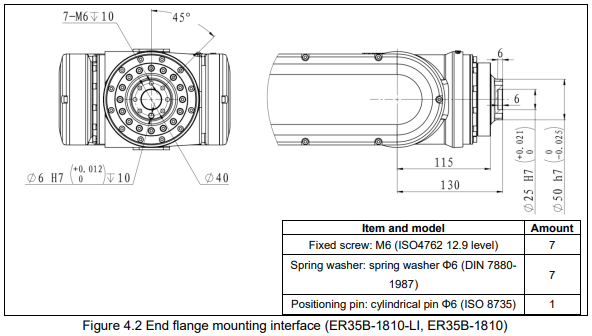
4.1. End flange mounting interface
This section describes the mounting face dimension of the end flange. Consider the depth of the screw holes and pin holes sufficiently before choose the length of the bolts and pins. Antirust measures of screws, grippers, etc., should be considered as well.
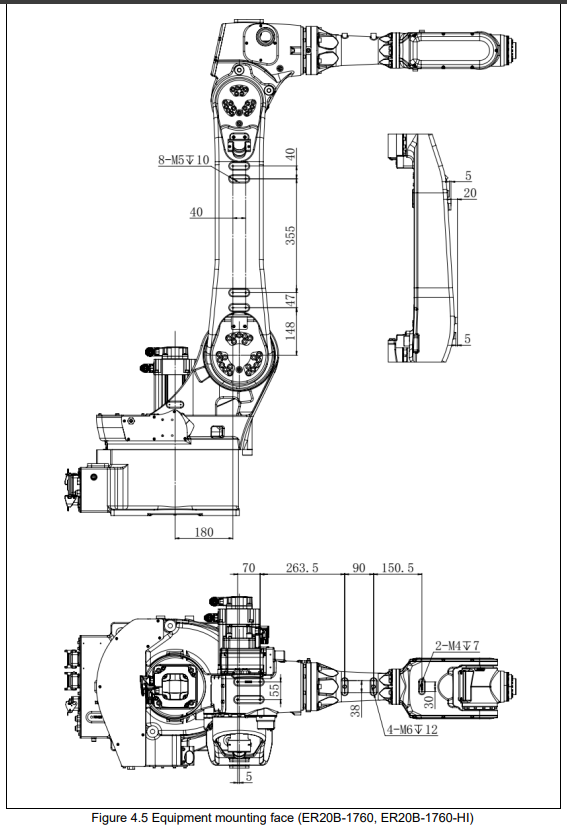
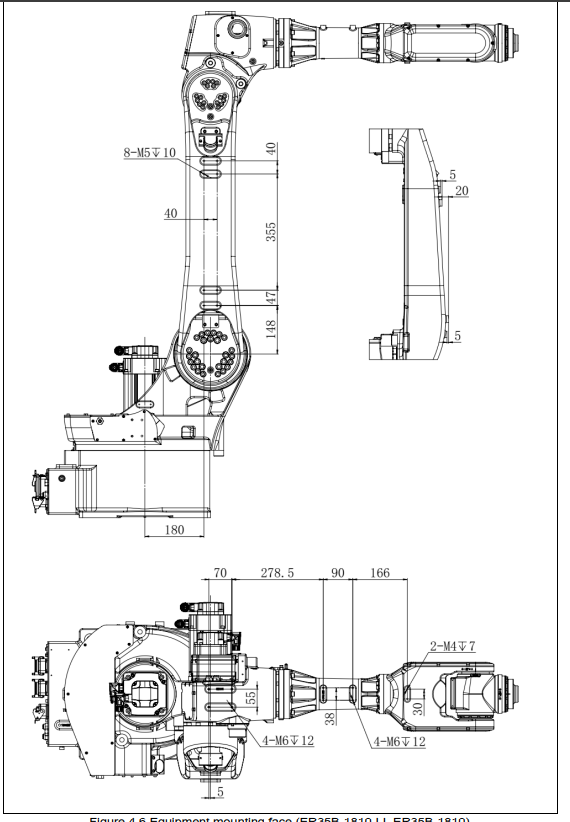
4.2. Equipment mounting face
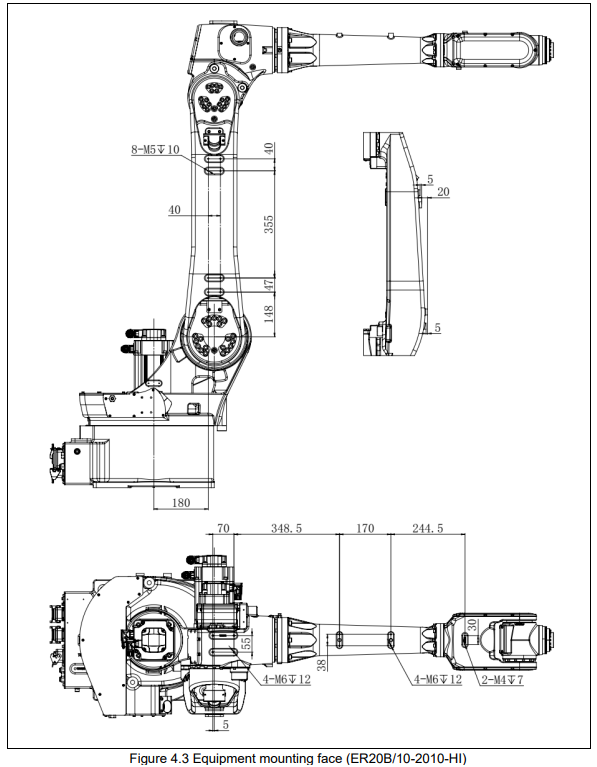
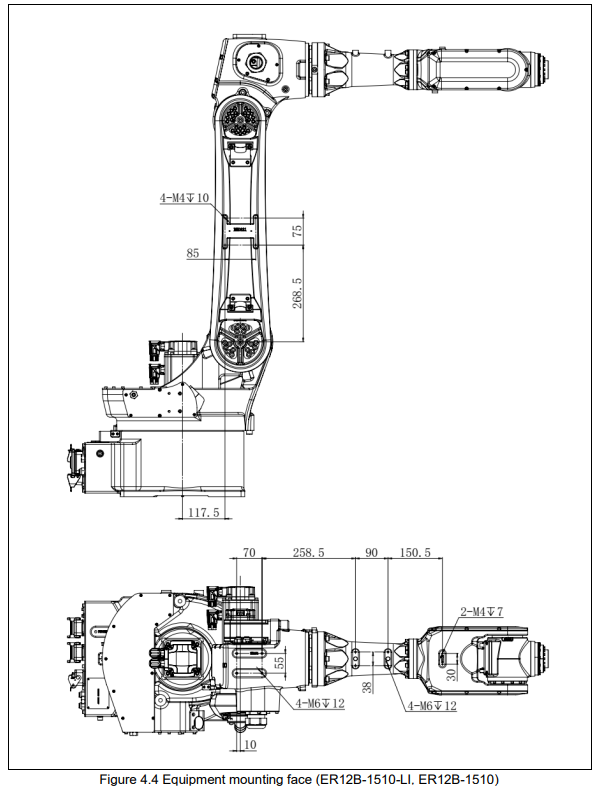
The figure indicates the locations of the screw holes for equipment installation. The robot has external device mounting threaded holes located on the top of the small arm component.
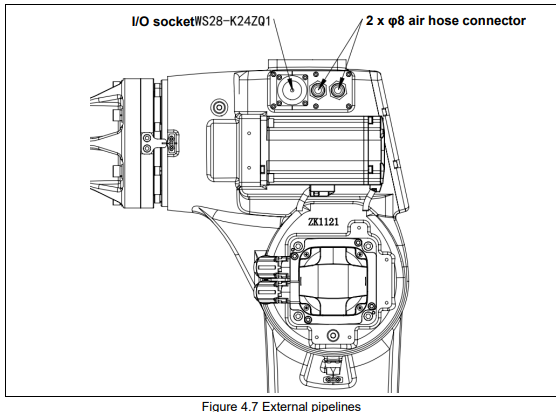
4.3. External pipelines
This series of robots provides pathways for supplying pneumatic or hydraulic pressure to the end effector mechanism.
No comments to display
No comments to display