
5. Check and Maintenance
Before performing any maintenance, be sure to read SAFETY PRECAUTIONS in Chapter 1 and understand the content.
5.1. Daily checks
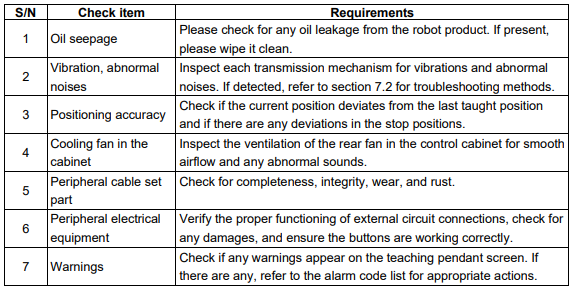
Check the items below before daily operation as occasion demands.
5.2. Periodic checks and maintenance
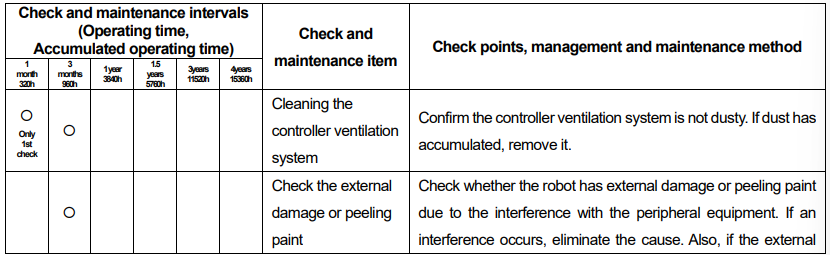
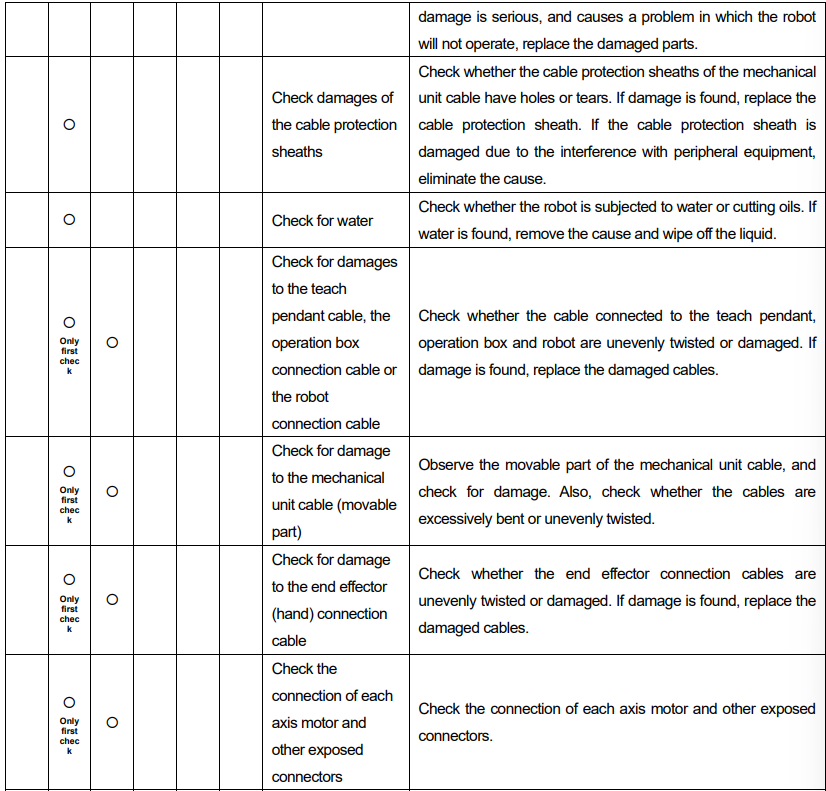
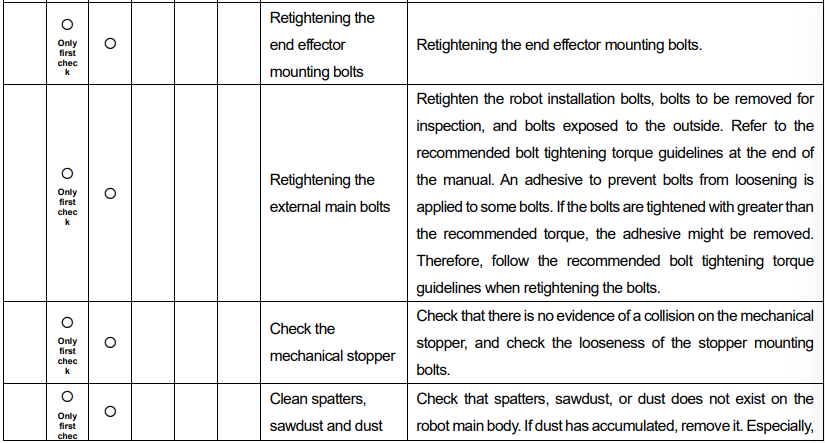
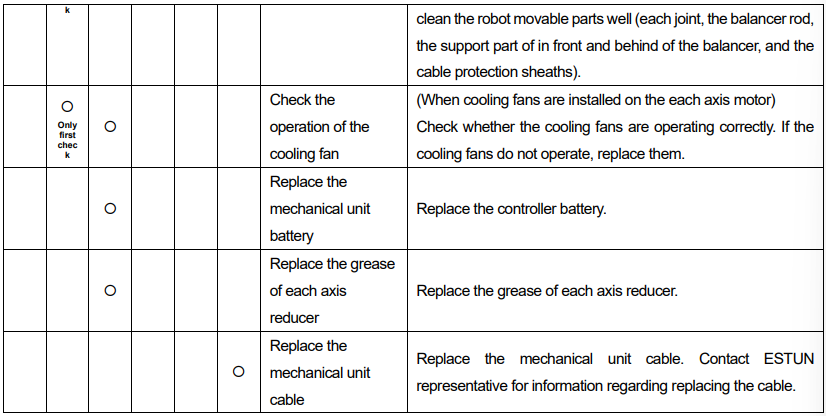
Perform maintenance and repairs at approximate intervals based on the specified operating cycle or cumulative operating time. By following the regular maintenance steps, the robot's optimal performance can be maintained. Users can carry out scheduled inspections and maintenance according to the table below, or they can contact ESTUN's professionals for service.
5.3. Adjustment of drive belts
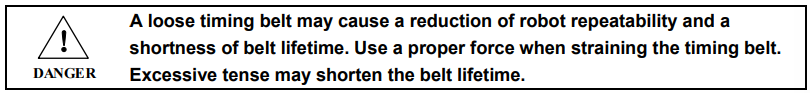
J5-axis of this series of robots is drove by timing belt. The belt tense tends to reduce after a period of operation. This section describes how to strain the belt.
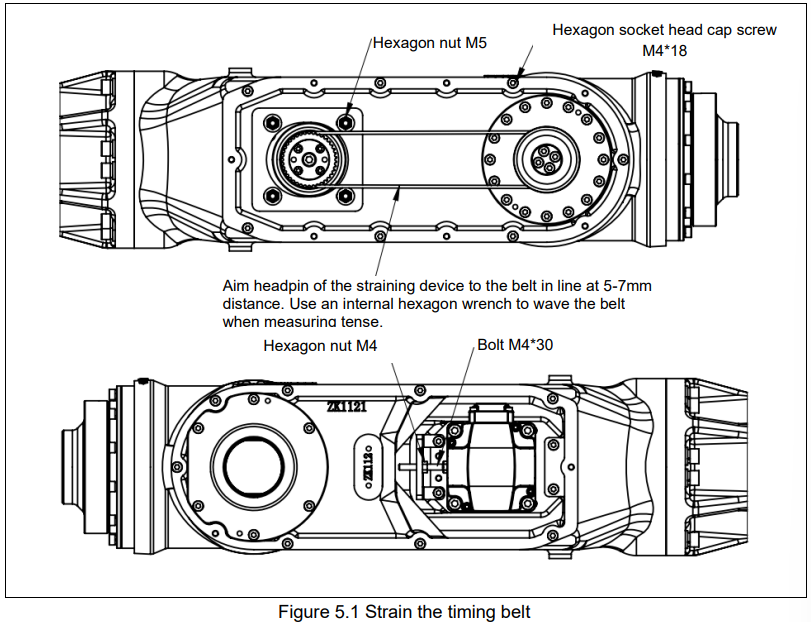
Procedures of straining J5-axis timing belt are shown below:
1. Remove the hexagon socket head cap screws M4×8 from the left and right cover plates of the forearm, and place the cover plates in the designated storage area.
2. Loosen the hexagon nut M5 that secures the J5 axis motor.
3. Adjust the adjustment device on the left side of the motor, primarily adjusting the M4×30 bolt to ensure that the bolt head is tightly against the J5 axis motor flange.
4. Test the tension of the timing belt on the side of the belt and adjust it to an appropriate tension (refer to the specific range in the table below).
5. Tighten the hexagon nut M5 to secure the J5 axis motor, and also tighten the hexagon nut M4 that secures the bolt.
6. Attach the left and right cover plates to the wrist connection body using hexagon socket head cap screws M4×8. Apply a uniform layer of Loctite 5910 silicone adhesive to the cover plates, and tighten the screws symmetrically.
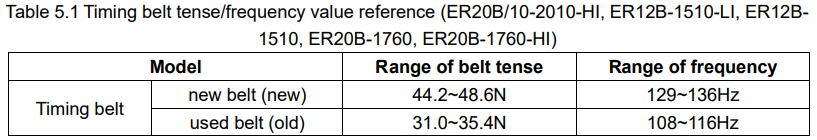
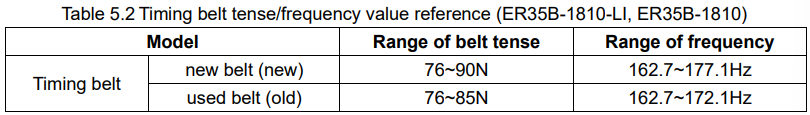
It is preferable to measure the frequency (Hz) to determine the tension of the timing belt. When measuring using a frequency meter, there is no need to adjust the internal parameters of the tension meter. Before reinstalling an old belt, inspect each pulley for any deformations and check the timing belt for any abnormalities. If any issues are found, promptly replace the pulley and timing belt.
5.4. Replacement of batteries
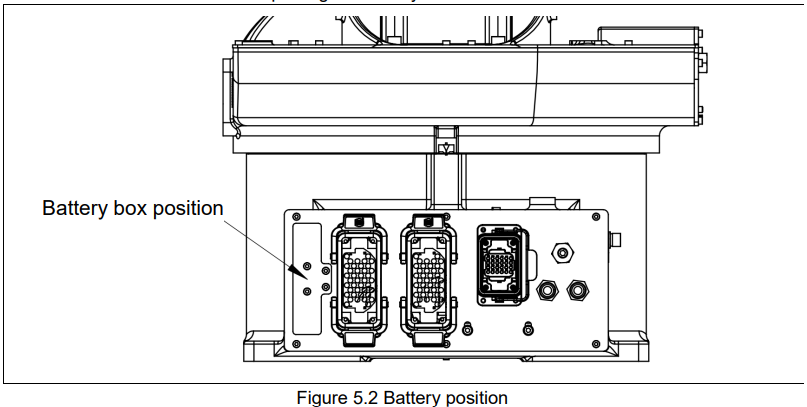
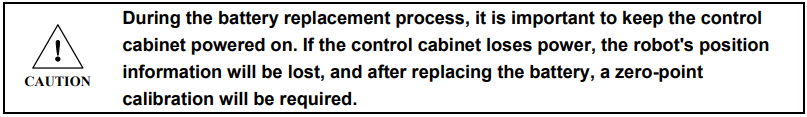
The position data of each axis is preserved by the backup batteries. The batteries need to be replaced every 1 year. Also use the following procedure to replace when the backup battery voltage drop alarm occurs.
Procedure of replacing the battery is shown below.
1. Press the emergency stop button to stop the robot motion.
2. Remove the plug cover on the robot base.
3. Take out the old batteries from the battery case.
4. Insert new batteries into the battery case while observing the correct direction.
5. Re-mount the cover after replacing the battery.
5.5. Robot greasing
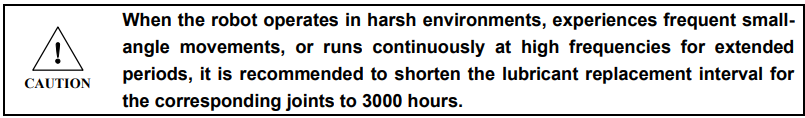
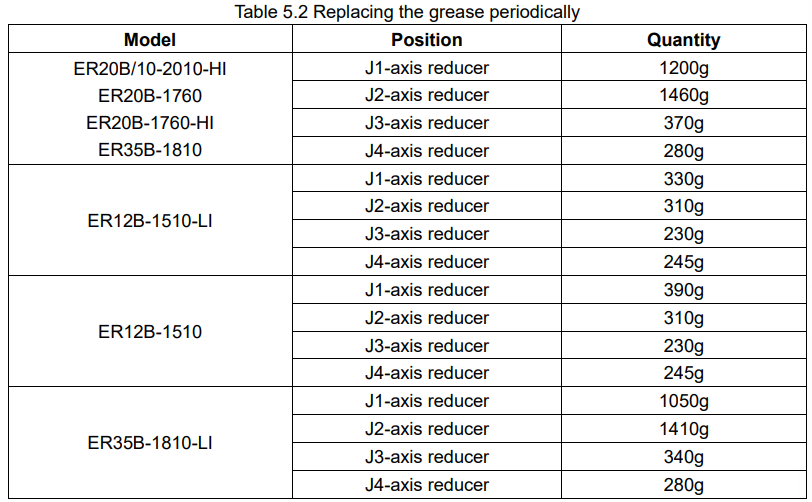
For the J1~J4 axes' oil chambers in this series of robots, the grease and oil should be replaced at intervals of every 1 year or when the cumulative operating time reaches 5,000 hours, whichever is shorter. The lubricant types and grease quantities for each joint are listed in the table below.
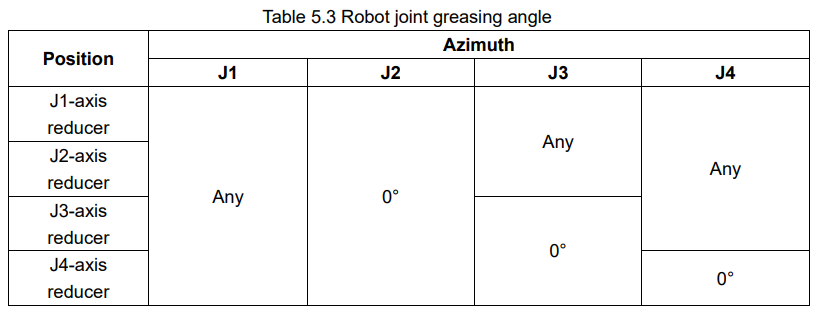
The following table provides the recommended azimuth angles for lubricant replacement or replenishment operations. Please note that users should not attempt to replace the lubricant at the robot wrist themselves.
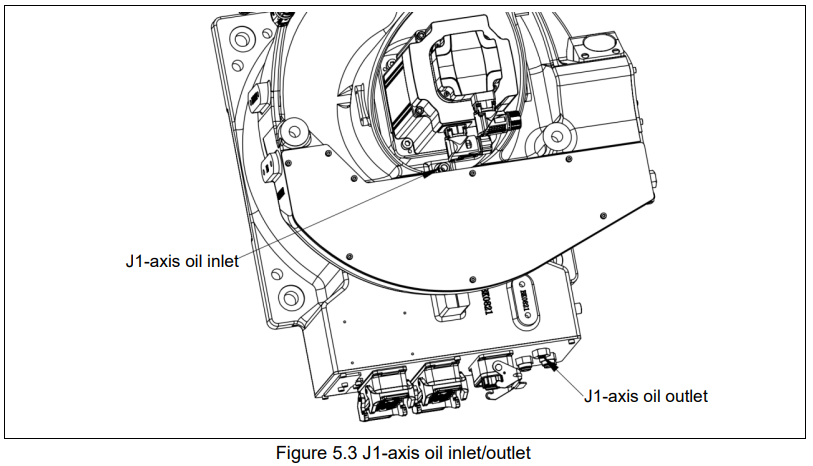
5.5.1. Position of oil inlet/outlet on each axis
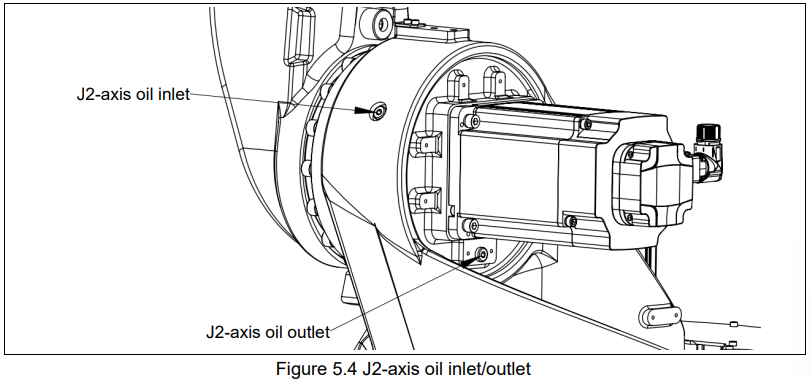
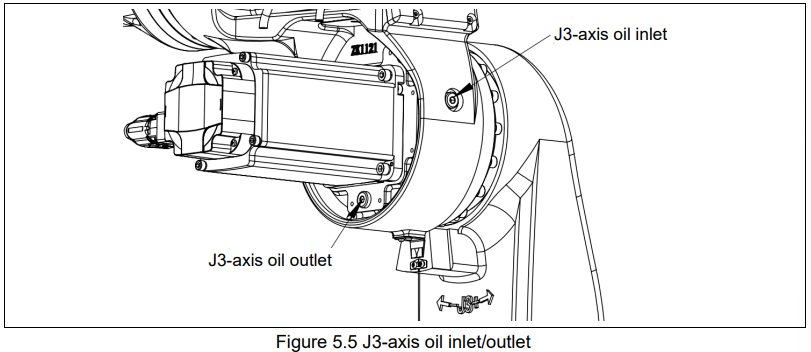
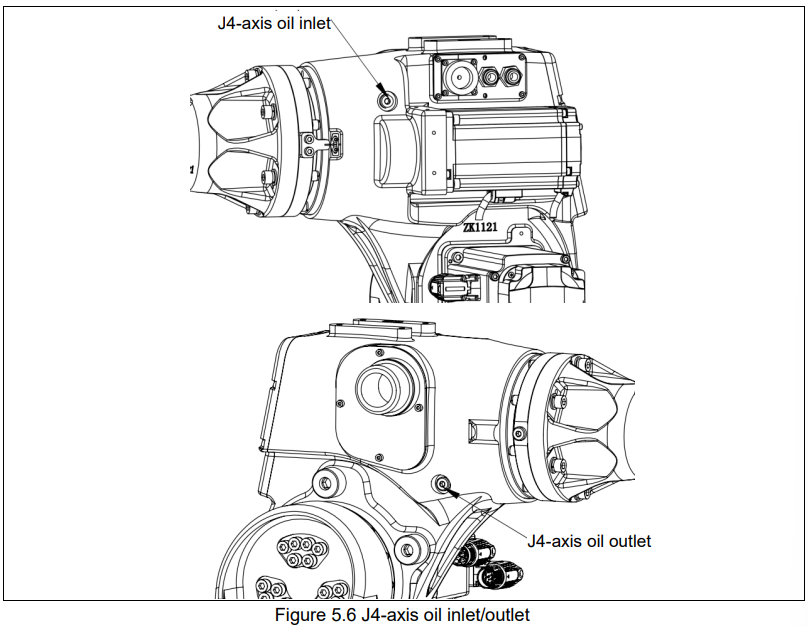
In this series of robots, under normal operating conditions, the J5 and J6 axes reducers do not require lubricant replenishment (except for cases involving reducer replacement). However, under severe conditions such as high duty cycle, high-speed movements, and heavy loads, regular lubricant replacement is necessary. For inquiries regarding lubricant replacement, please contact ESTUN.
5.6. Oil leakage inspection
Maintenance Area
Insert a cloth or similar material into the gaps of each joint to check for any oil leakage from the oil seals.
If oil leakage is observed, please wipe it clean.
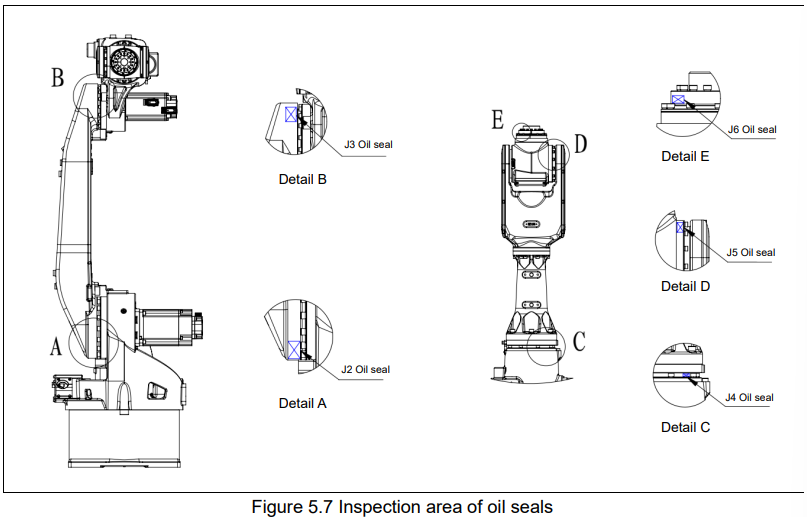
⚫ Depending on the operating conditions and surrounding environment, oil may leak from the outer lip of the oil seals. When accumulated oil forms droplets, it may drip during certain movements. Prior to operating the robot, please wipe off any oil accumulation on the underside of the oil seals.
⚫ Additionally, if the temperature during operation is excessively high, the internal pressure in the joint chambers may increase. In such cases, after the operation, please open the oil filling port once to restore the internal pressure. (Do not open or close the oil filling port while the machine is in a cooled state)
⚫ If oil leakage persists even after frequent wiping, please refer to 7.2 Troubleshooting.
No comments to display
No comments to display