
8. Fully Closed Loop Operation
With a fully-closed system, the encoder on the motor is used in conjunction with an external encoder (external to the motor) is used to detect the position of the load. This is also known as dual encoder feedback. Below is a block diagram of Fully-Closed Loop Operation.
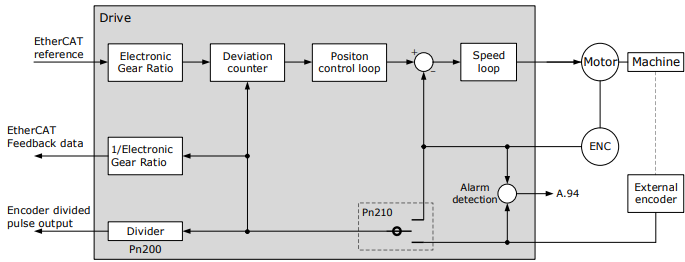
This setup can be useful in some high-precision positioning applications where there is compliance or backlash between the motor and the load.
However, due to the separation of encoders the system may suffer from looseness or twisting of mechanical parts which can cause vibration or oscillation, resulting in unstable positioning.
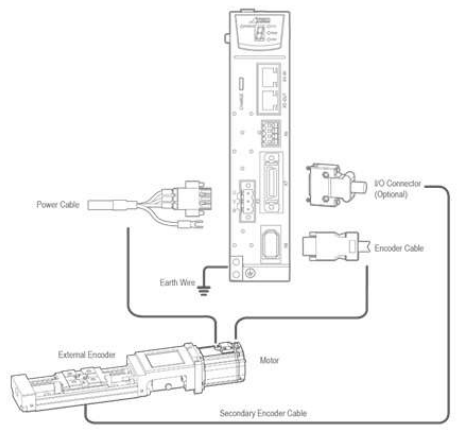
Careful commissioning of fully-closed loop setup is essential for good performance.
8.1 Commissioning Procedure
The commissioning procedure for the Drive for fully-closed loop control is given below.
Step 1 Complete the wiring and connection of the Drive and Motor and connect to the machine.
Step 2 Ensure Pn210.0 is set to 0 to use the encoder on the motor (semi-closed loop control).
Step 3 Using the Jog operation, move the movable part on the machine side to an appropriate position, and then confirm the Motor's motion in forward rotation and reverse rotation. For details on Jog operation, refer to the section 6.4.3 Jog Motion.
Step 4 Change Pn210.0 to 1 to include the external encoder in the control (fully-closed loop control).
Step 5 Using the Jog operation again to confirm the Motor's motion in forward rotation and reverse rotation.
Step 6 Resolve the following alarms and reset the system.
If alarms A90 (Phase A Disconnected), A91 (Phase B Disconnected), A92 (Phase C Disconnected) alarms occur, check the wiring of the external encoder.
If alarm A93 (Encoder Communications Error) occurs, contact Trio or the Authorized Distributor.
If alarm A94 (Position Deviation Overflow) occurs, check the settings of Pn210, Pn212, Pn213 and Pn214. Also, check the wiring of the external encoder, and check if the mechanical connection structure is loose, slippery or has a large gap
Step 7 Check the settings of parameters Pn210.3, Pn212, and Pn213
Check count direction of external encoder is the same as the main encoder. Pn210.3 can be used to change the count direction of the external encoder.
Set Pn212 to change the resolution of the external encoder.
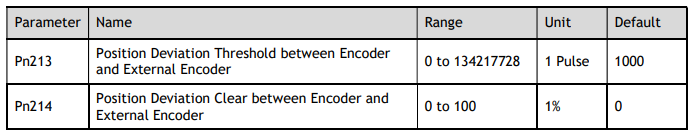
Set Pn213 to change Position Deviation Threshold between main encoder and external encoder
Step 8 Try to use the Program Jog operation to confirm the Motor’s motion. For more detail on Program Jog refer to section 6-15 Program Jog Motion.
Step 9 Refer to Step 6 to resolve possible alarms until the alarm no longer occurs.
Step 10 Once the servo can operate using the Program Jog function the system is ready for use.
8.2 Enable External Encoder
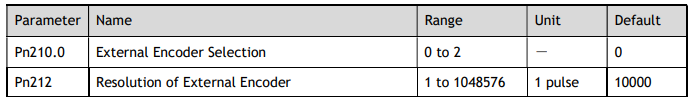
Set Pn210.0=1 or 2 to enable the external encoder:
Set Pn210.0 to 1, representing that the external encoder is enabled for the fully-closed loop
control.
Set Pn210.0 to 2, representing that the external encoder is enabled for the counting only.
In addition, set the parameter Pn212 (Resolution of External Encoder) to specify the resolution of the external encoder, indicating the numbers of AB quadrature pulse edges emitted by the external encoder after one rotation of the Motor (one quadrature pulse has four edges, that is, the pulse numbers × 4).
8.3 Motor Direction and Machine Movement
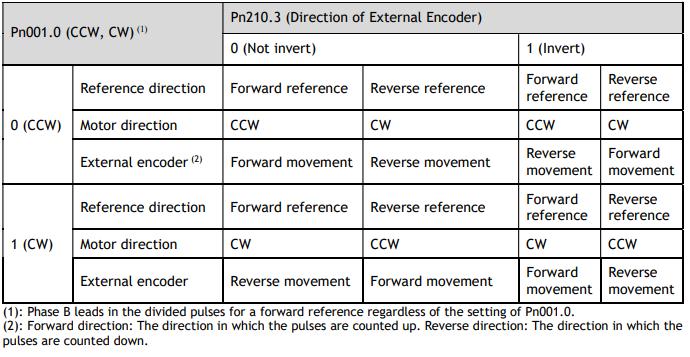
For fully-closed loop operation the Motor direction and the machine movement direction must configured.
The table below shows the relationship between Pn001.0, Pn210.3 and direction.
8.4 Alarm Detection Settings
This setting is used to detect the difference between the feedback position of the Motor encoder and the feedback load position of the external encoder for fully-closed loop control.
If the detected difference exceeds the threshold, an A94 alarm (Position Deviation Overflow) will be generated.
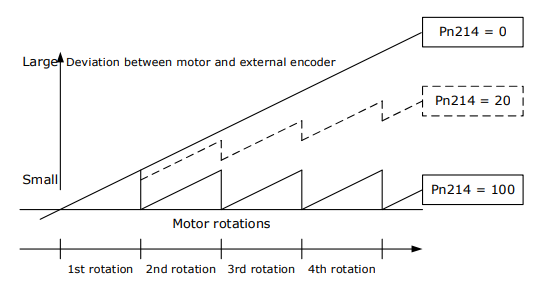
In addition, a coefficient of deviation between the Motor and the external encoder per Motor rotation can be set (Pn214). This setting can be used to prevent the Motor from running out of control due to damage to the external encoder or to detect belt slippage.
If Pn214 is set to 0, the external encoder value will be read as it is.
If Pn214 is set to to 20, the second rotation will start with the deviation for the first Motor rotation multiplied by 0.8.
No comments to display
No comments to display