
9. Appendix
9.1 EtherCAT Communications
9.1.1 Introduction
EtherCAT is a real-time Industrial Ethernet technology originally developed by Beckhoff Automation. The EtherCAT protocol which is disclosed in the IEC standard IEC61158 is suitable for hard and soft real-time requirements in automation technology, in test and measurement and many other applications.
The EtherCAT master sends a telegram that passes through each node. Each EtherCAT slave device reads the data addressed to it “on the fly” and inserts its data in the frame as the frame is moving downstream.
The frame is delayed only by hardware propagation delay times. The last node in a segment (or drop line) detects an open port and sends the message back to the master using Ethernet technology’s full duplex feature.
9.1.2 Specification
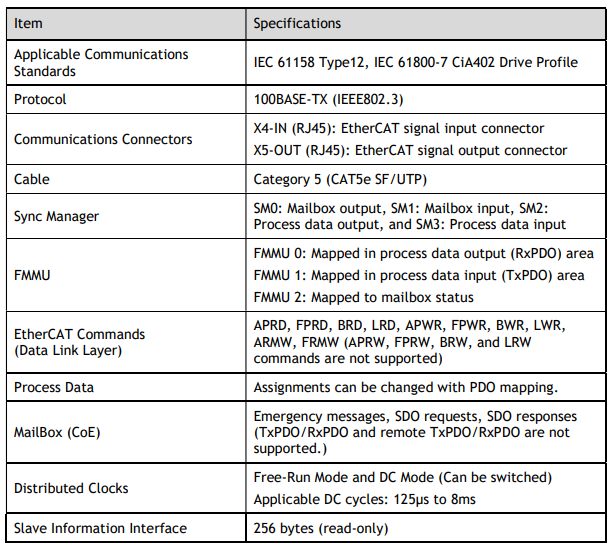
The specifications for EtherCAT communication are as follows.
9.1.3 EtherCAT Slave Information
The drive publishes network accessible properties via an EtherCAT Slave Information (ESI) file. This is an XML based file which is used by the network master. For the DX4 this information is already built into Motion Perfect and the Trio controllers.
The ESI file for the DX4 is available on the Trio website and has the name:
TRIO_DX4_V***.xml
NOTE: The asterisks (***) indicate the version number.
9.1.4 EtherCAT State Machine
A state machine is used to manage the communications states between the master and slave applications, shown in Figure 9-1. Normally, the state of the slave responds based on requests from the master.
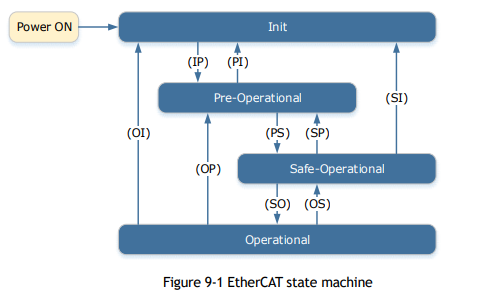
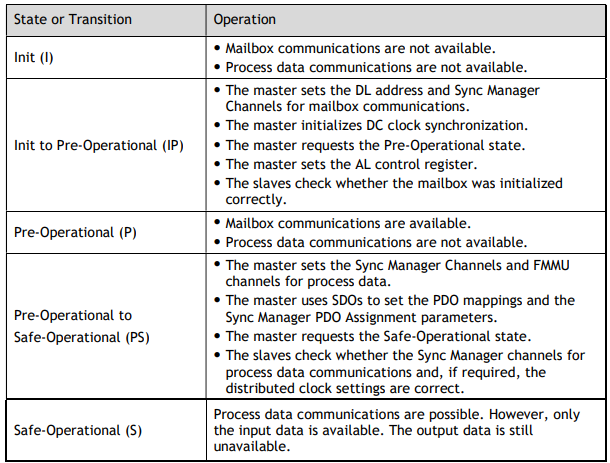
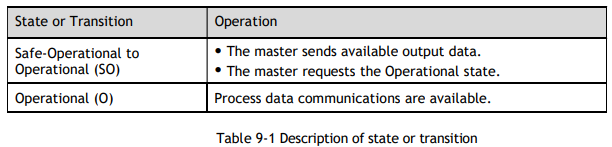
Table 9-1 lists the state transition and initialization process.
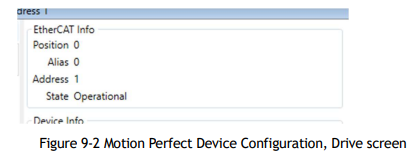
The state of the drive can be seen in the EtherCAT Info frame in the device configuration screen within Motion Perfect. The image below shows a drive in the ‘Operational’ state.
9.1.5 Communications between master and slave
Process Data Object (PDO)
PDO is used to transfer cyclic data. This is data that is transferred between the master and slave every network cycle. Typically, this is data required for operation of the drive; Control Word, Status Word, Set Point, etc…
Service Data Object (SDO)
SDO is used to transfer non-cyclic data, such as communication parameter configuration, and Servo running parameter configuration. The CoE service type includes Emergency Message, SDO request and SDO response.
Emergency Message
When an alarm occurs in the Drive, the CoE service can trigger an emergency message to inform the user of the error code. The Motion Coordinator response to the emergency message can be set by the ECAT_MODE system parameter in the controller.
Distributed Clock (DC)
The synchronization of EtherCAT communications is based on a mechanism called a distributed clock. With the distributed clock, all devices are synchronized with each other by sharing the same reference clock. The slave devices synchronize the internal applications to the Sync0 events that are generated according to the reference clock.
The figure below shows a timing chart for DC synchronization.
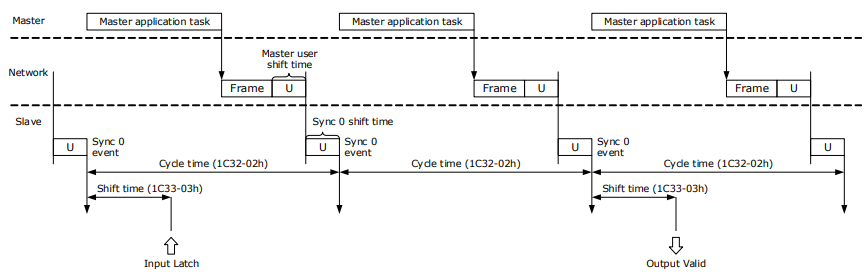
NOTE: Only the object 1C33-03h can be set.
9.1.6 Relevant Settings
For correct operation using EtherCAT ensure the parameters below are set correctly.

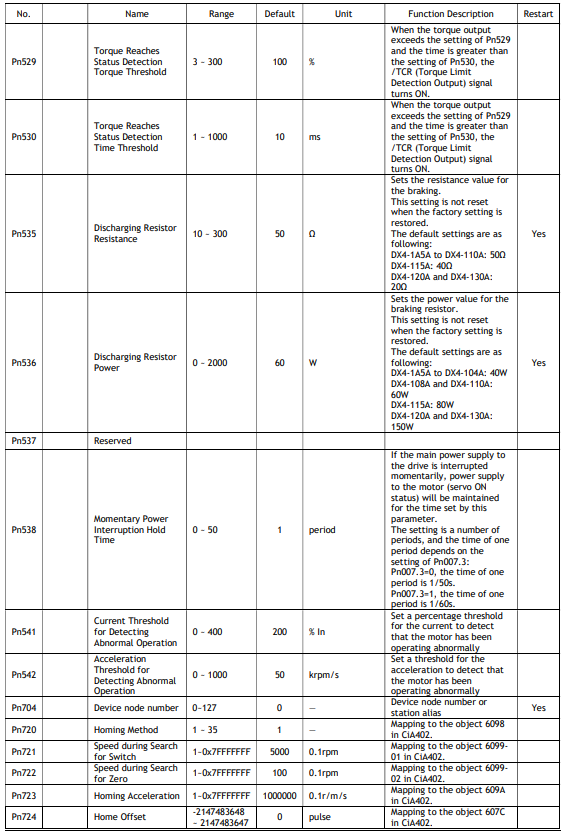
The Device Node Number can be used to force the axis number used by the controller. If the Drive has a non-zero device node number (Pn704) and this node number is unique on the network, then the axis number will be the node number -1. Node number 13 would be axis number 12.
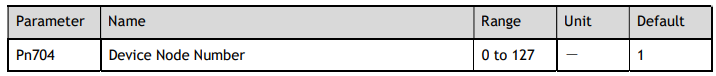
NOTE: Changing the Device Node Number will require the drive to be restarted.
9.1.7 CANopen over EtherCAT Reference Model
The DX4 uses the IEC 61800-7 CiA402 drive profile over EtherCAT which is often referred to as CoE. This defines the behavior of the drive for enable, disable command, error conditions and the set of objects used to configure the operation of the drive and expose status information.
The state of the control word and status word can be seen in the device configuration screen within Motion Perfect. The image below shows an example or a drive in a running state.
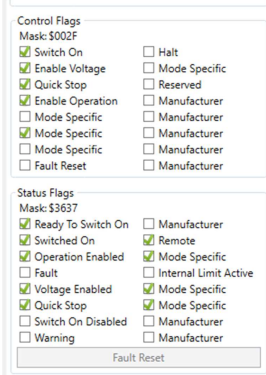 Figure 9-3 Motion Perfect Device Configuration, Motor screen
9.2 Object Dictionary
Group 1000h
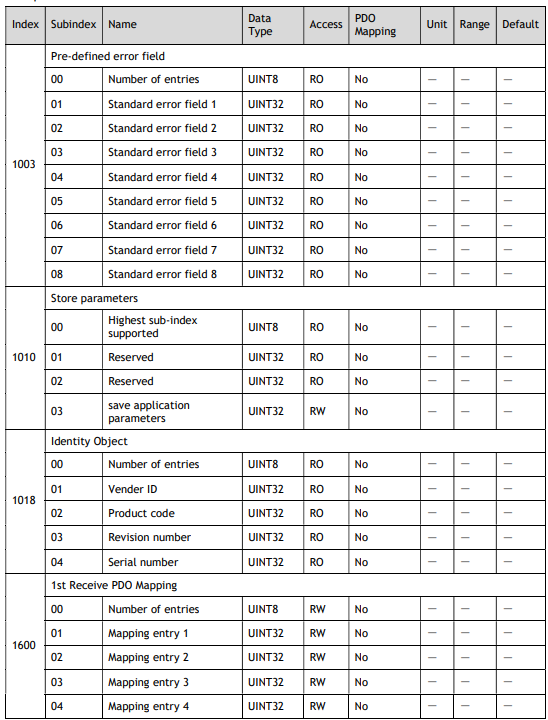
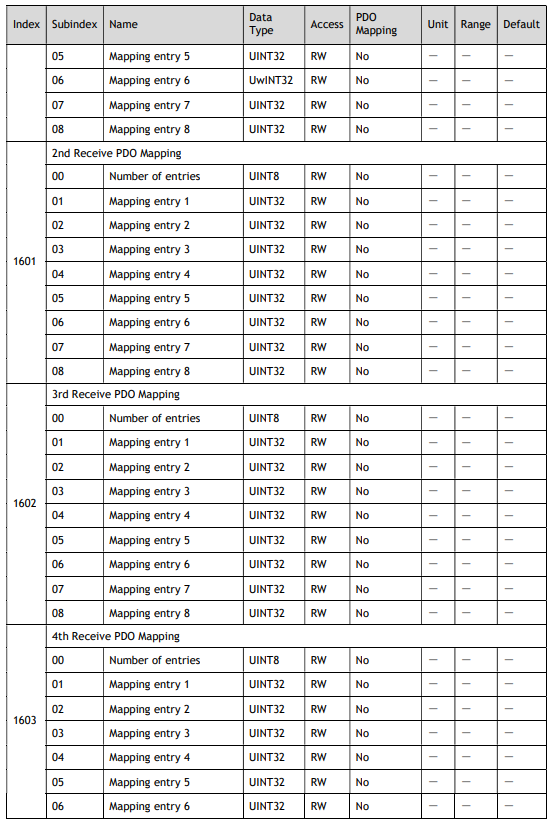
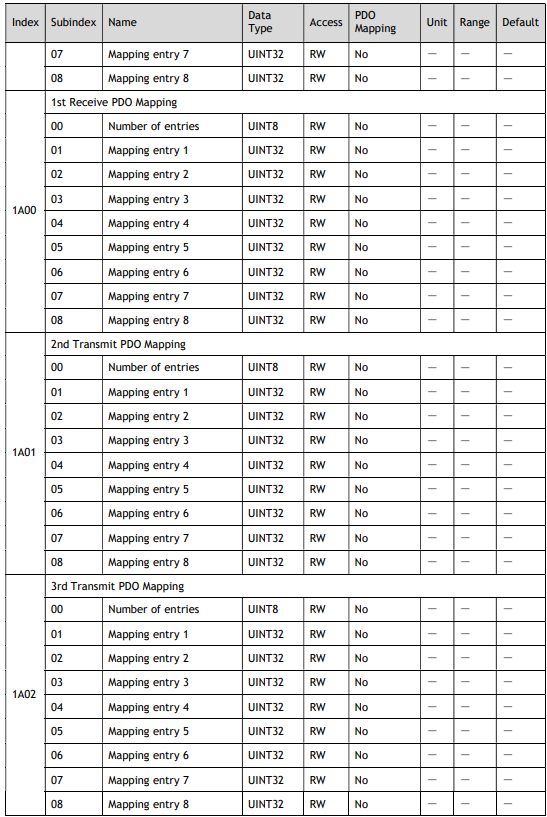
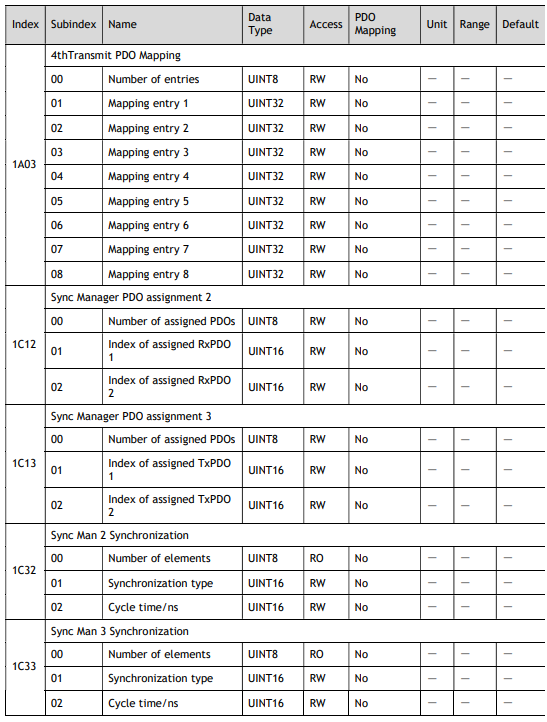
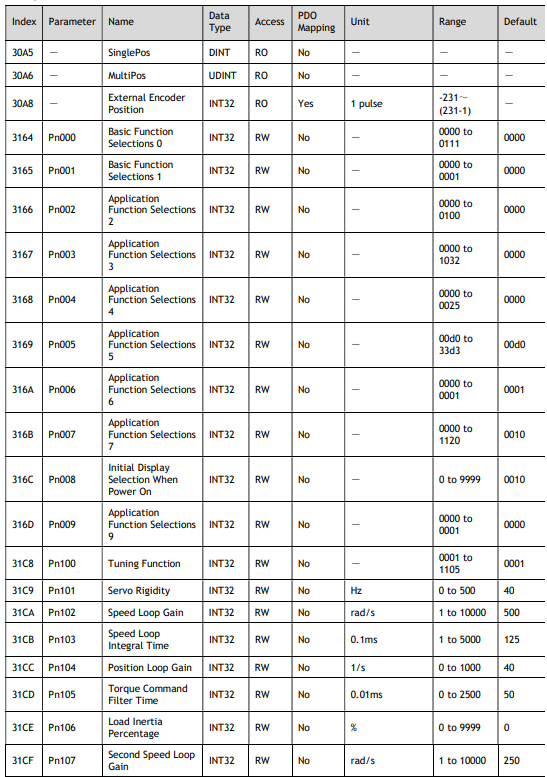
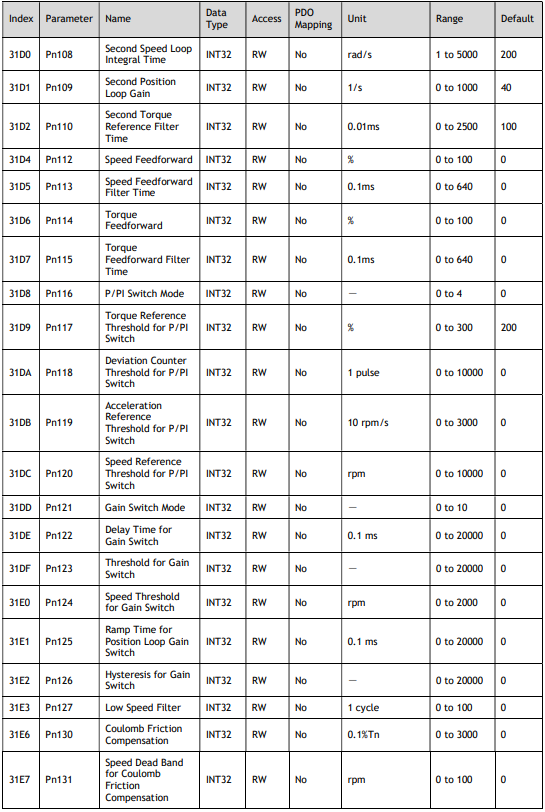
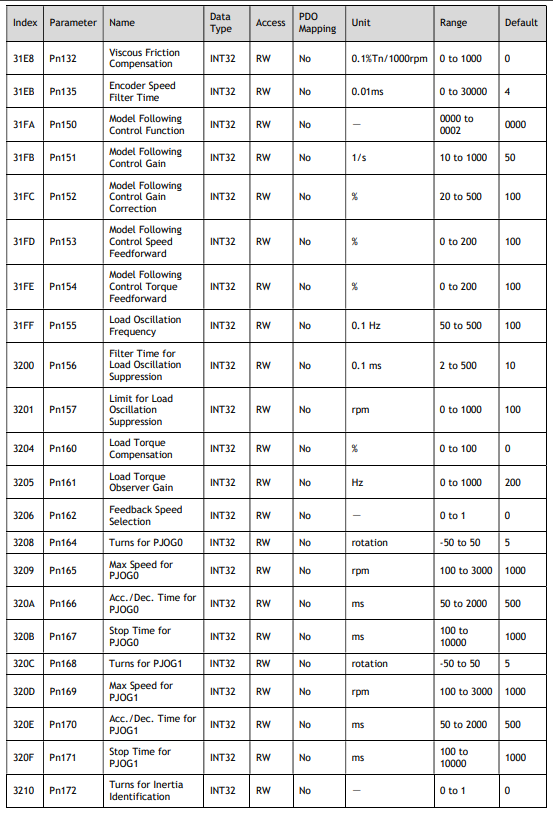
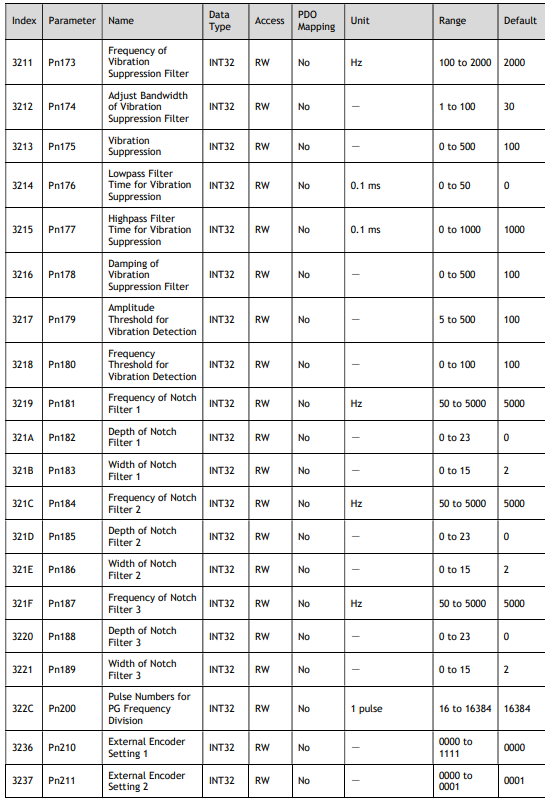
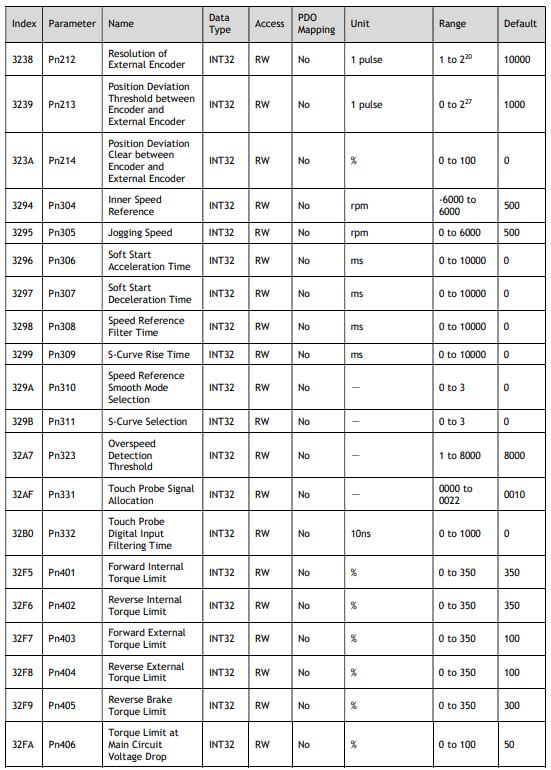
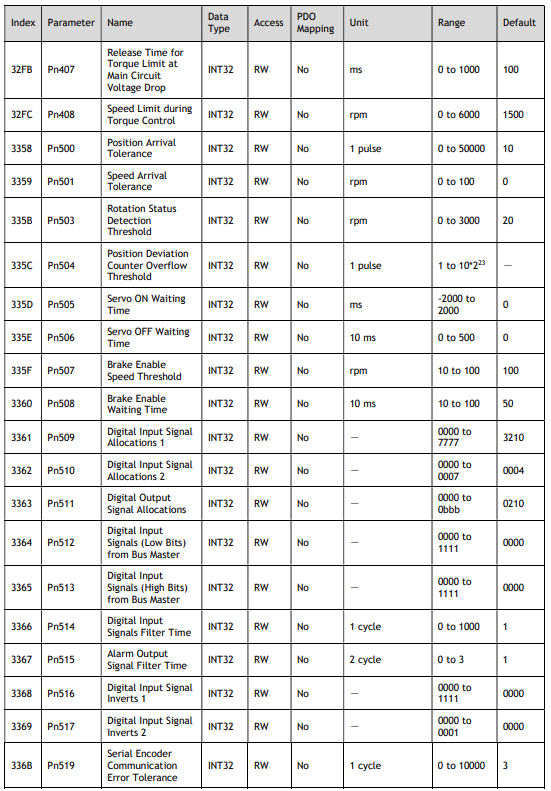
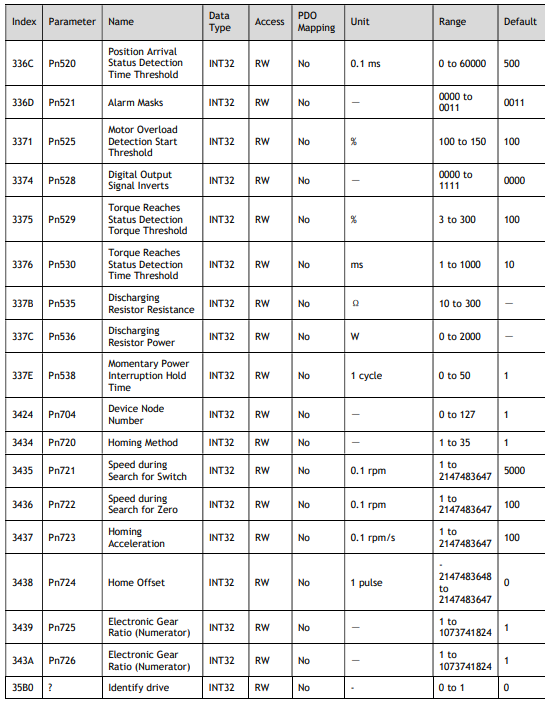
Group 3000h
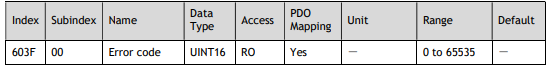
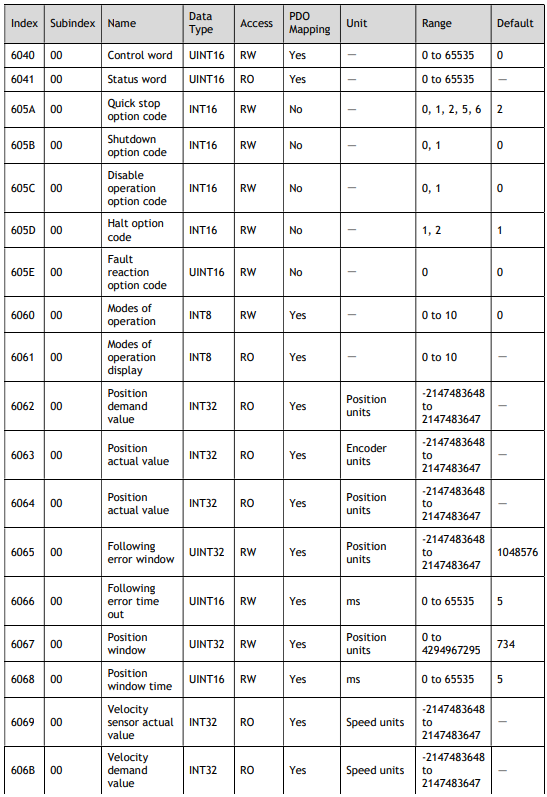
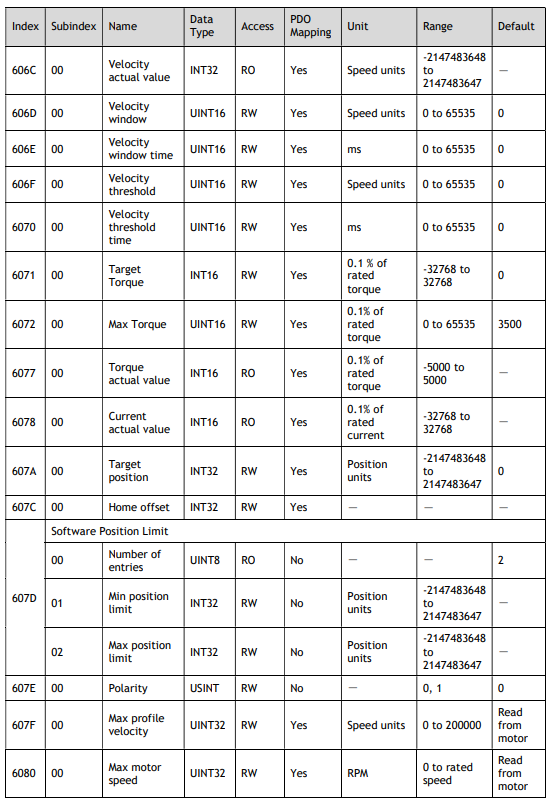
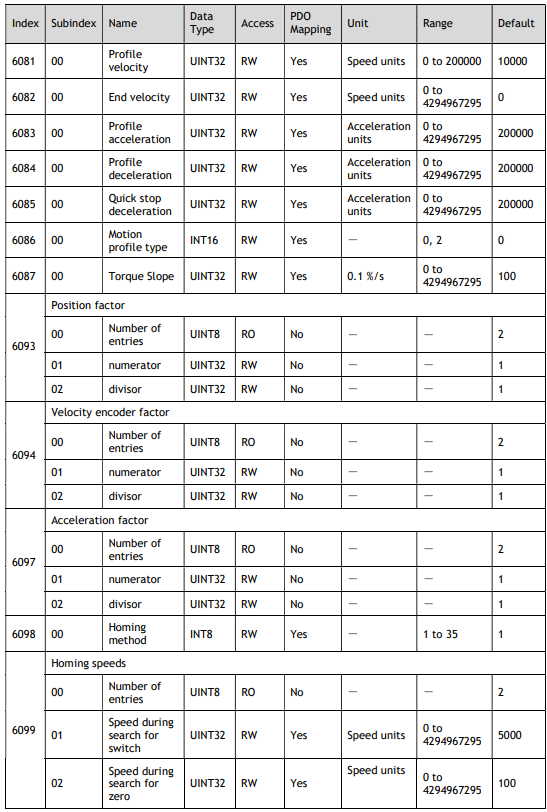
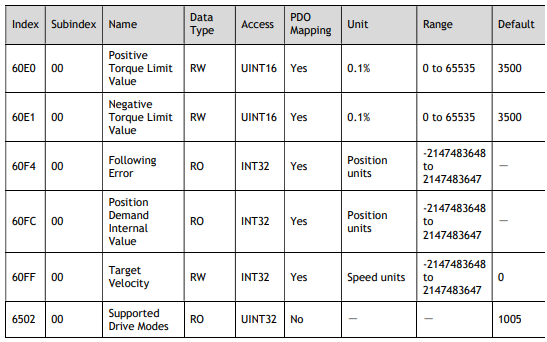
Group 6000h
9.3 Parameter List
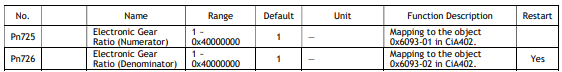
9.3.1 Parameter Table
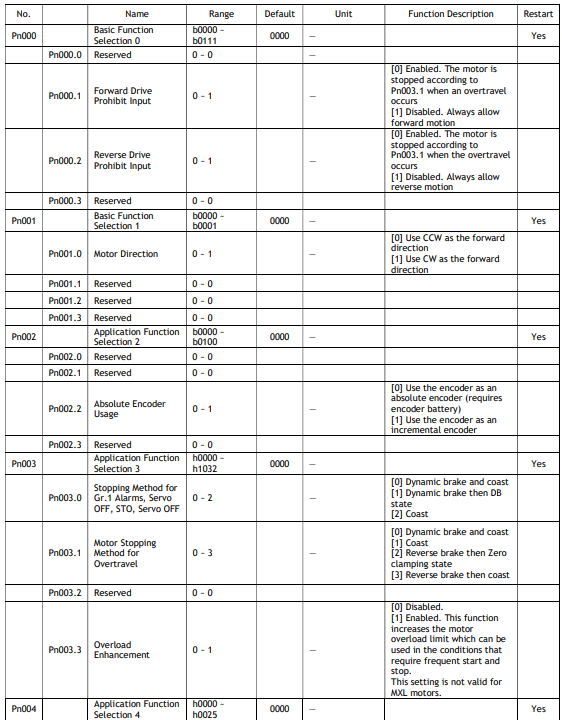
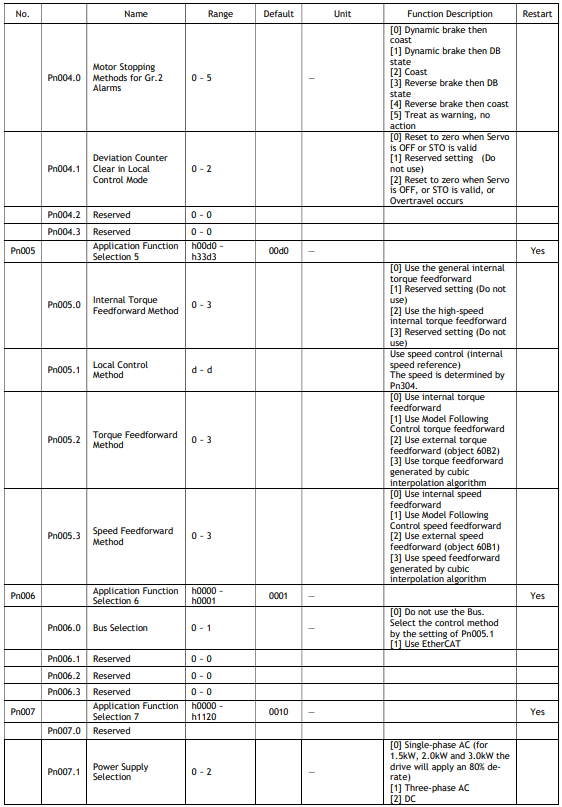
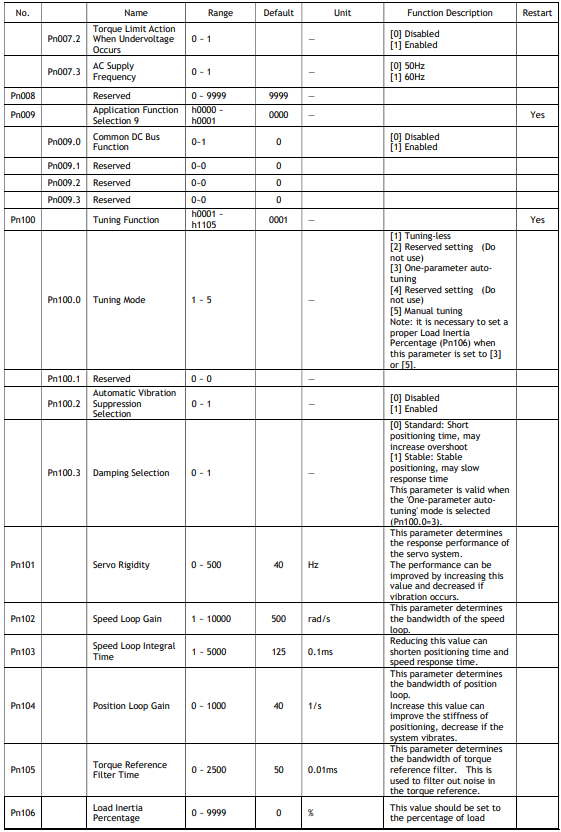
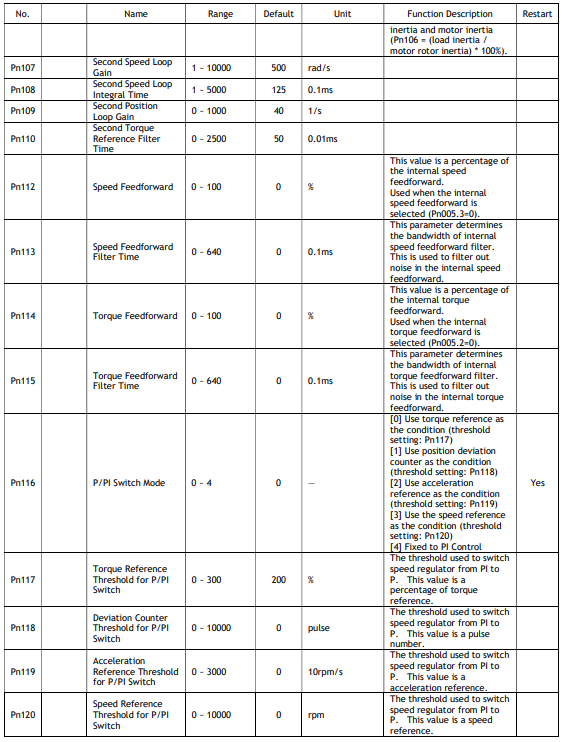
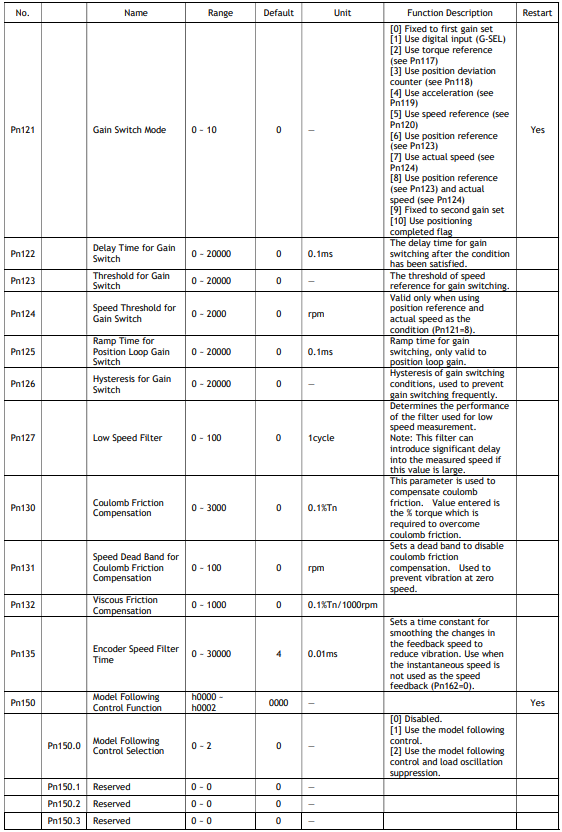
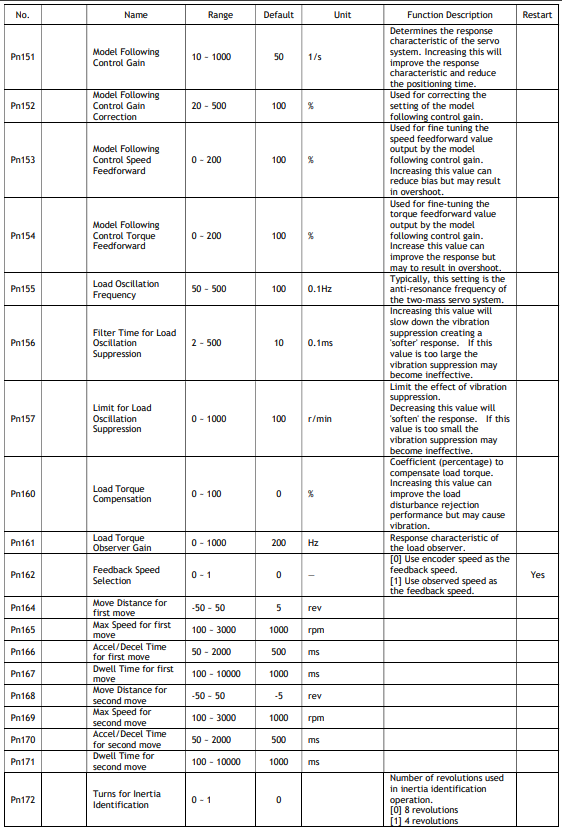
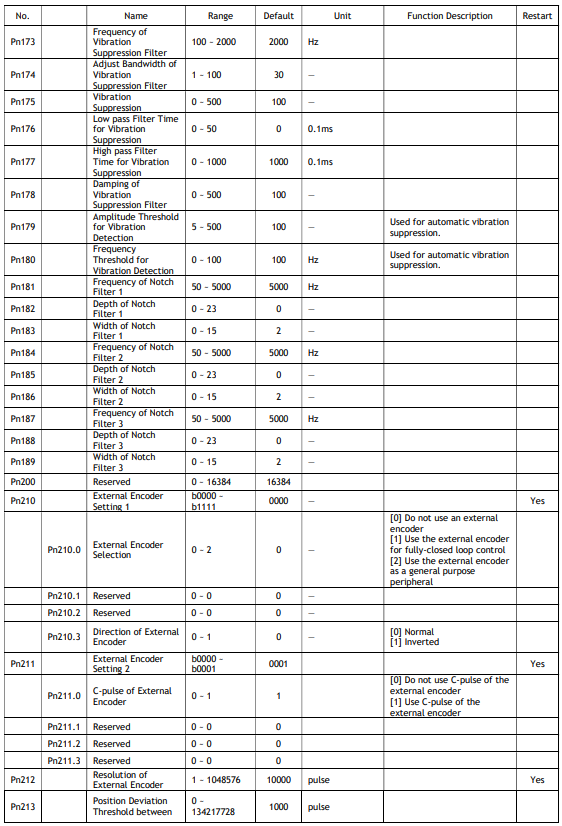
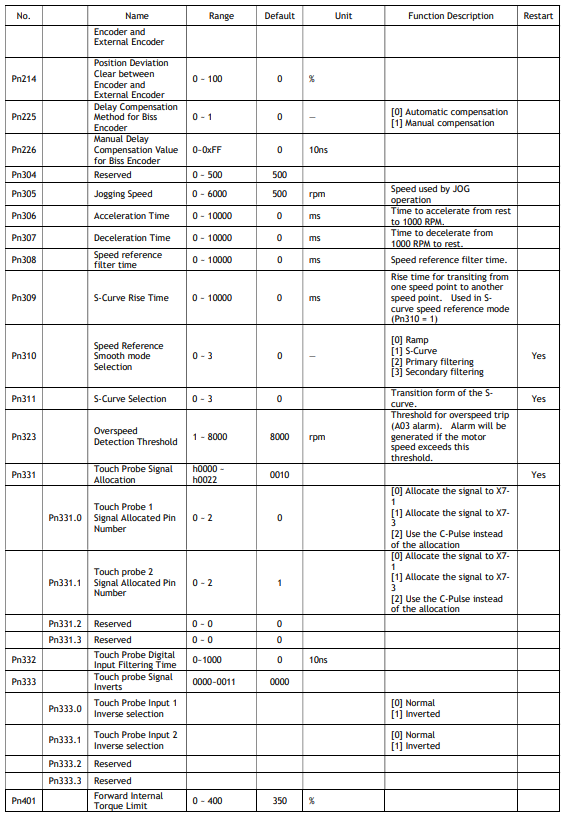
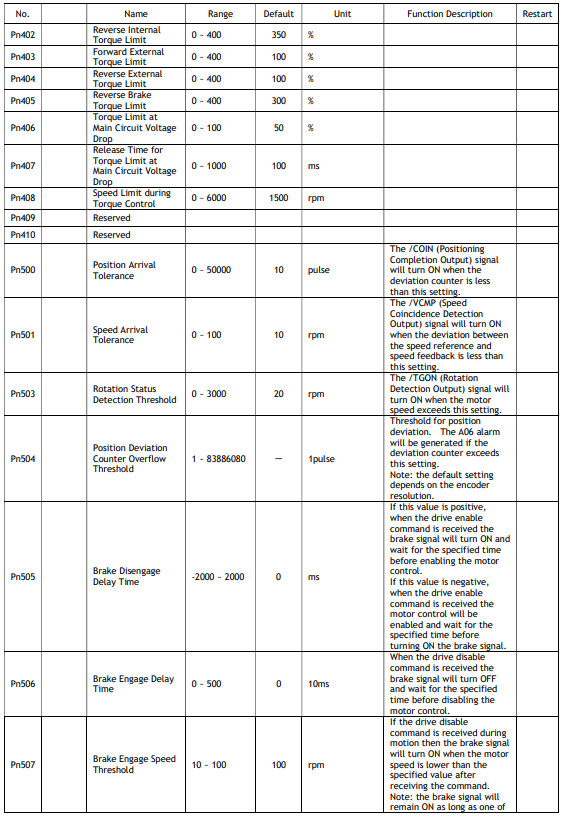
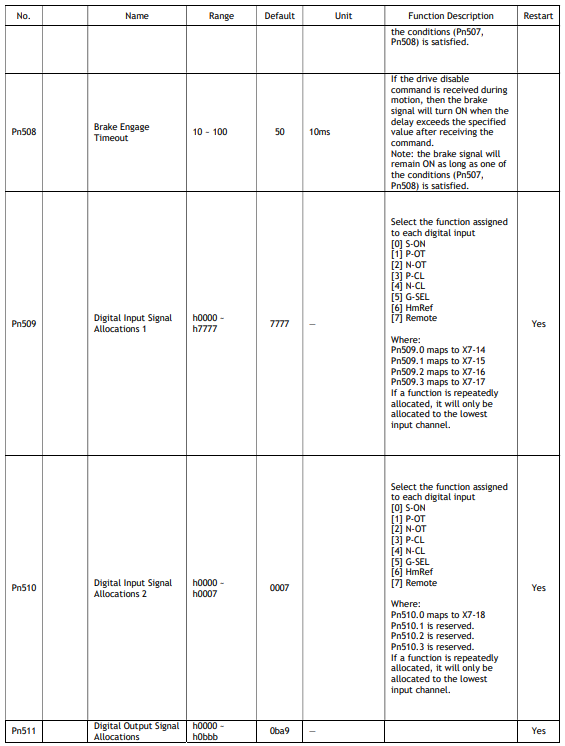
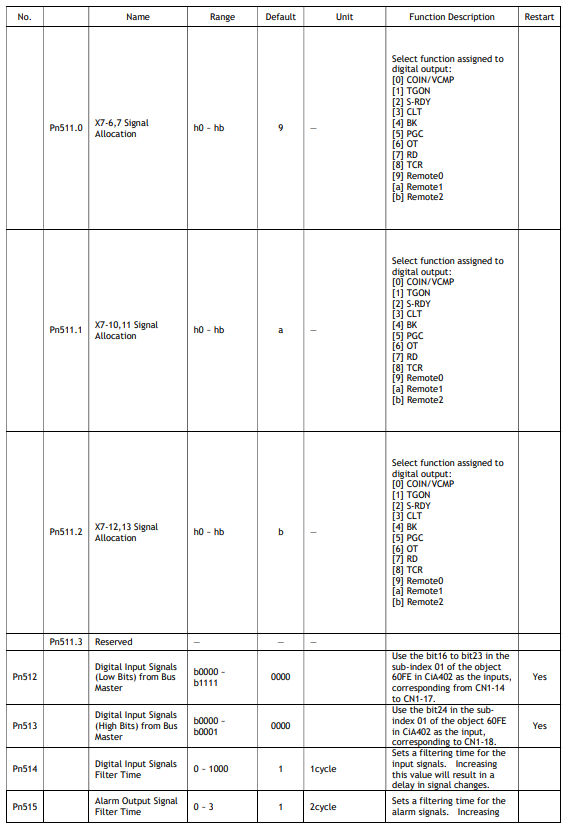
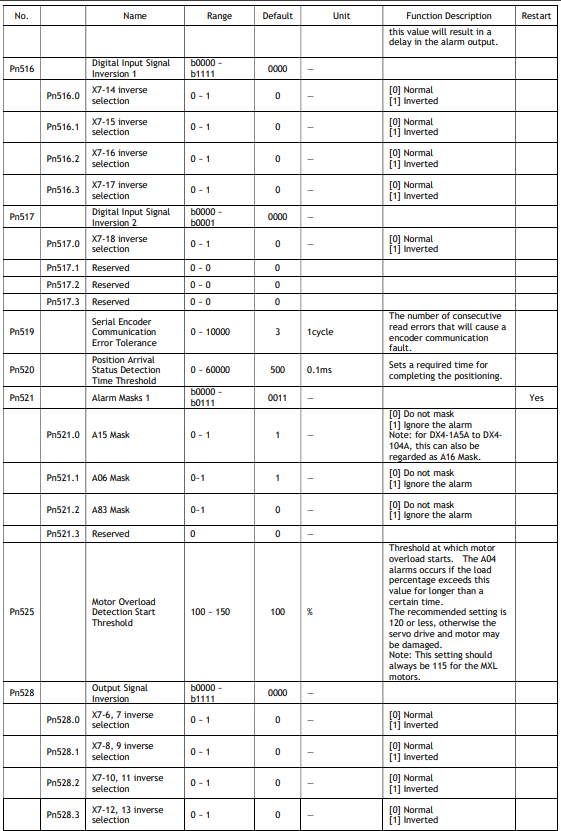
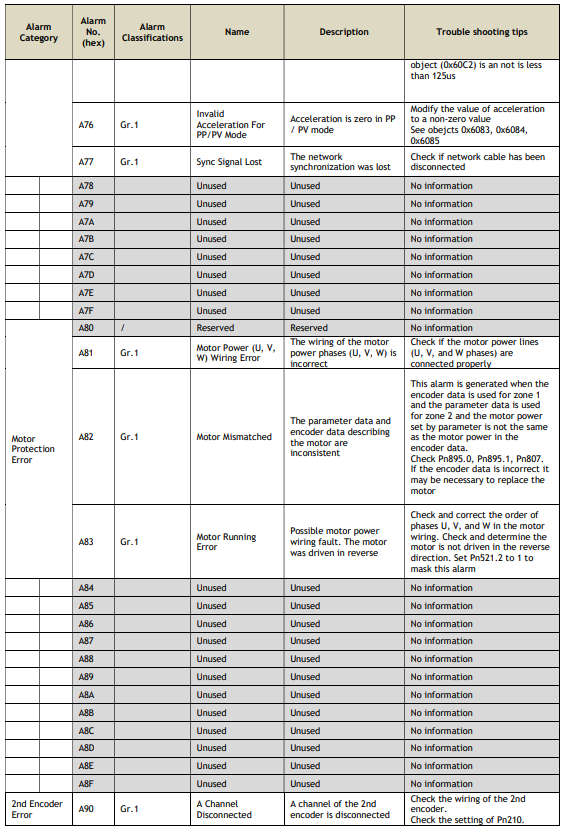
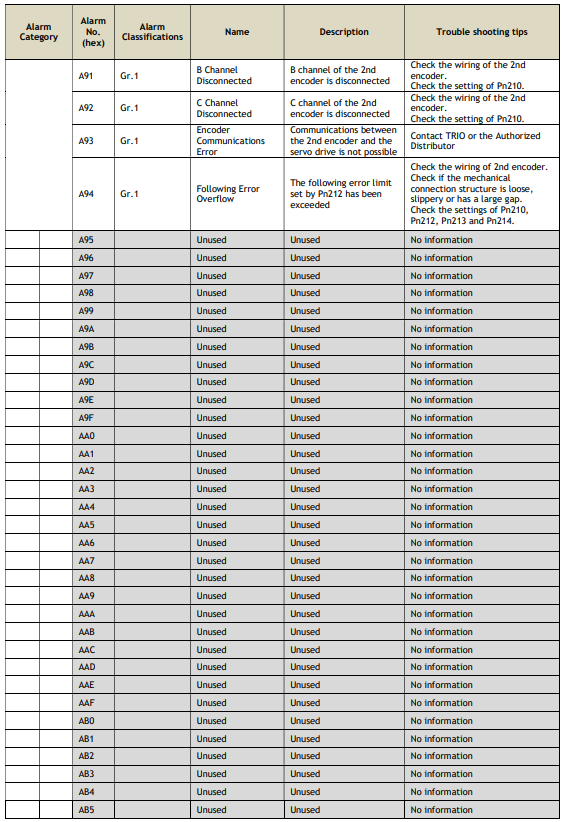
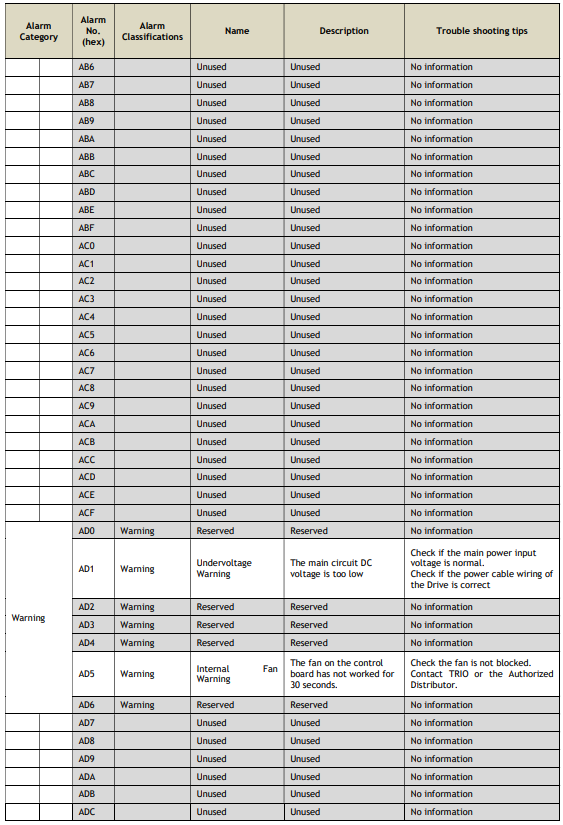
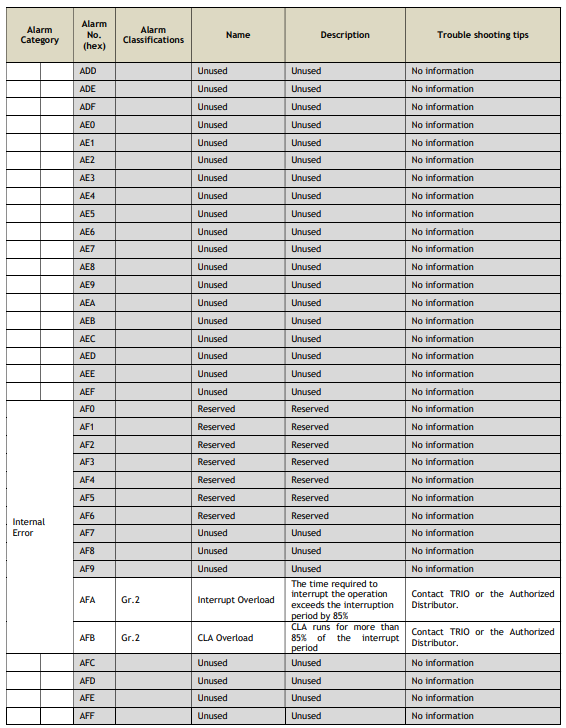
9.4 Alarms Displays
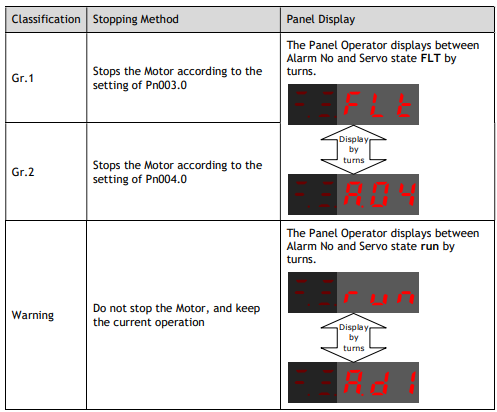
9.4.1 Alarm Classifications
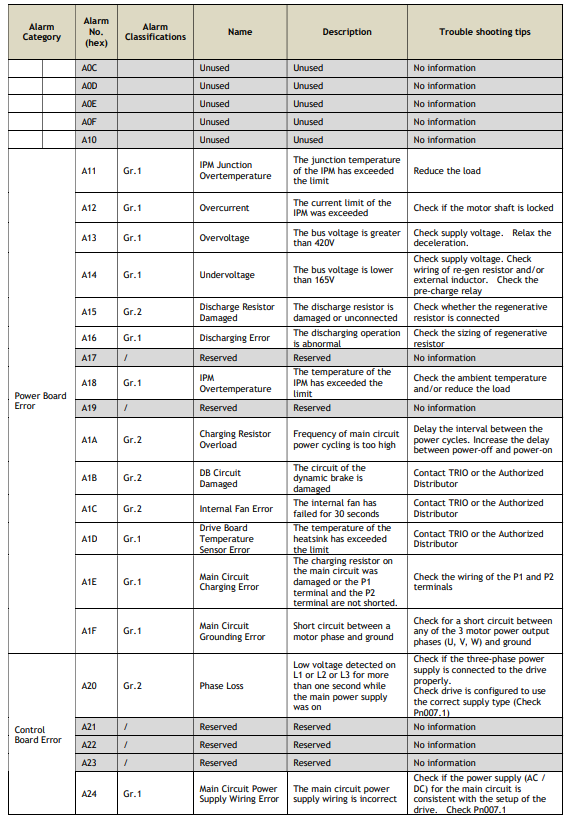
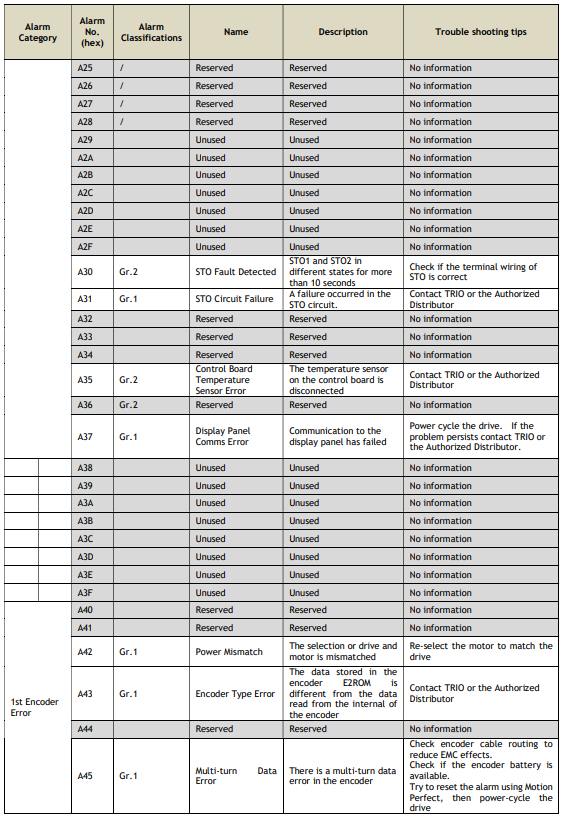
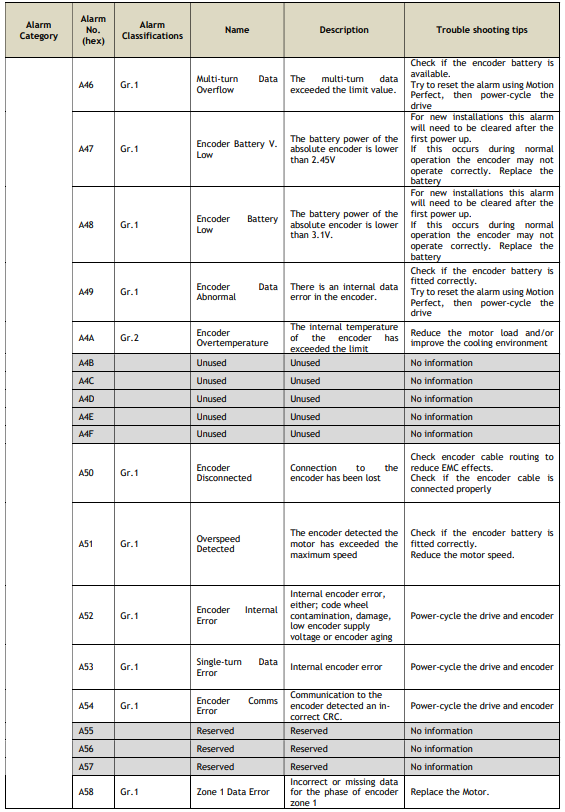
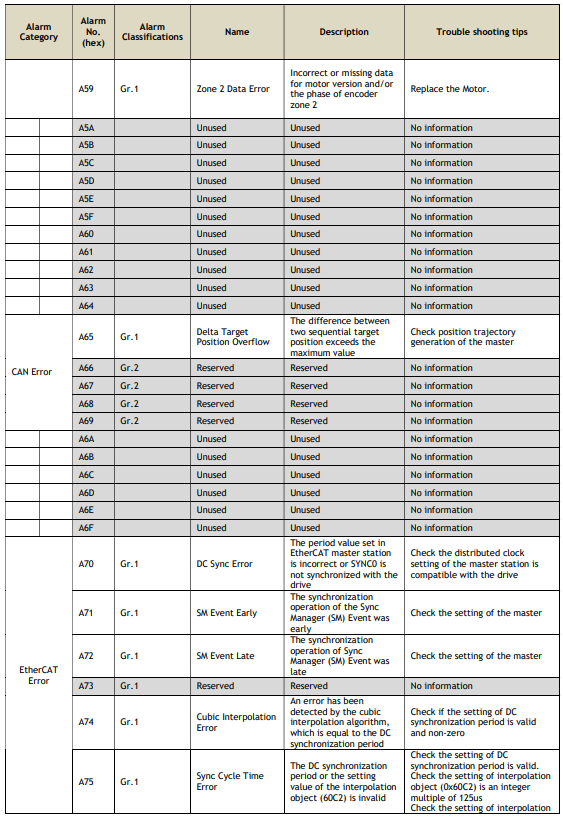
There are three classifications of alarms for the Drive: Gr.1, Gr.2, and Warning. They will affect the display and operation for the Servo System.
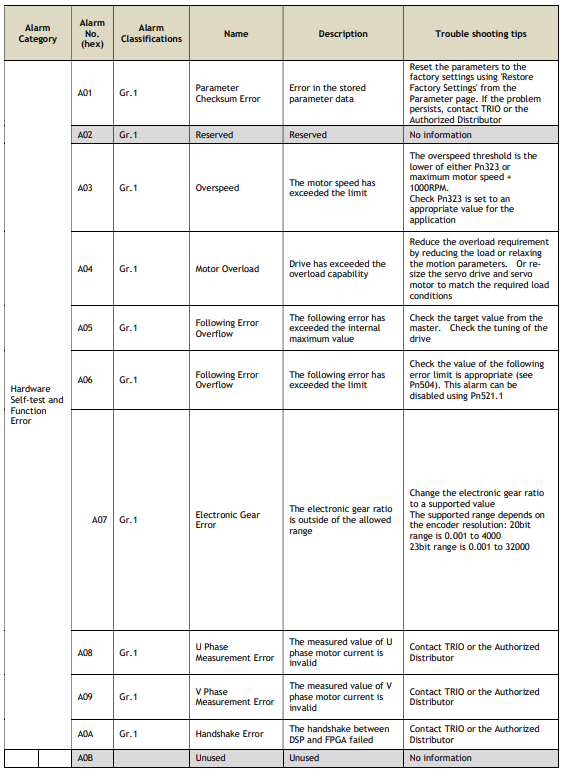
9.4.2 Alarm Table
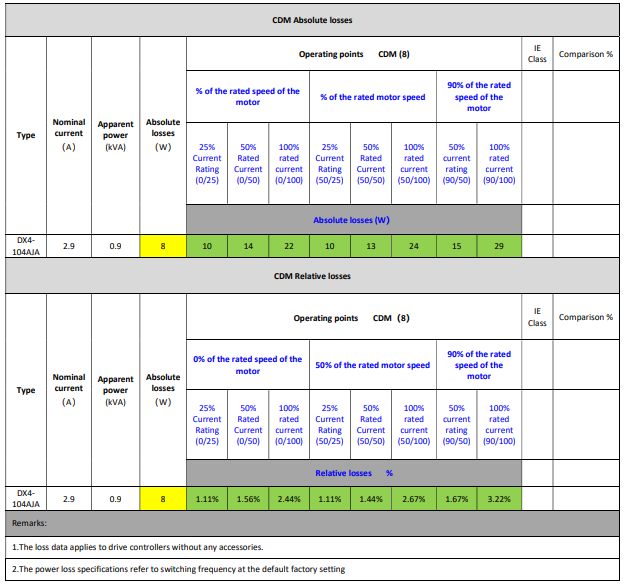
9.5 Power Dissipation Data
9.5.1 DX4-104AJA
No comments to display
No comments to display