
1. INTRODUCTION
Introduction to Programming
MC4XX MOTION COORDINATOR SOFTWARE
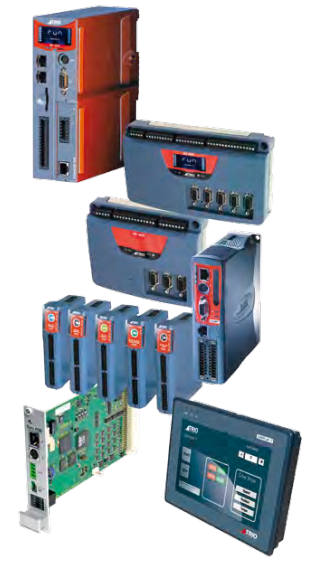
The MC4xx range makes a huge advance in programming as well as with its leading hardware design. This manual is a complete reference work covering all the main programming methods, the programming software and the use of remote access methods for Microsoft Windows® packages.
The system designer is free to choose the motors, drives and IO components that best suit the application. Interface options are provided for traditional servo, stepper and piezo control together with and expanding range of digital fieldbus connected drives and IO devices. The MC4xx range can support any number of axes between 1 and 64 in a modular, expandable and cost effective way. Precise and fast motion control is run by 64 bit software developed independently by Trio, benefitting from over a quarter of a century of experience on thousands of real machines world-wide.
The choices available to the system designer now extends to the choice of programming software. Motion Perfect 3 and the run-time environment in the Motion Coordinator firmware support both TrioBASIC and the industry standard IEC61131-3 programming environment. In addition, there is support for text based languages like HPGL and G-Code within the much extended multi-tasking TrioBASIC. For those applications which need a Windows® PC front-end, the well-established TrioPC Motion ActiveX has been extended and improved and is well suited to high speed connection to the Motion Coordinator via Ethernet. For more everyday user interface requirements, Motion Perfect v3 includes a complete set of visual programming tools for the Trio Uniplay range of
integrated HMIs.
Languages
TrioBASIC has been greatly extended for the MC4xx range. It now includes features such as array variables, string handling, text-file handling and user definable system configuration. The combination of string variable types and the ability to load, save and manipulate text files, is a powerful tool which allows the implementation of text based motion languages like G-Code and HPGL. A new program type, called MC _ CONFIG, is used to store all the user defined system configuration changes. This allows the Motion Perfect project to store the complete configuration as well as application programs and data. A “must have” for project maintainability.
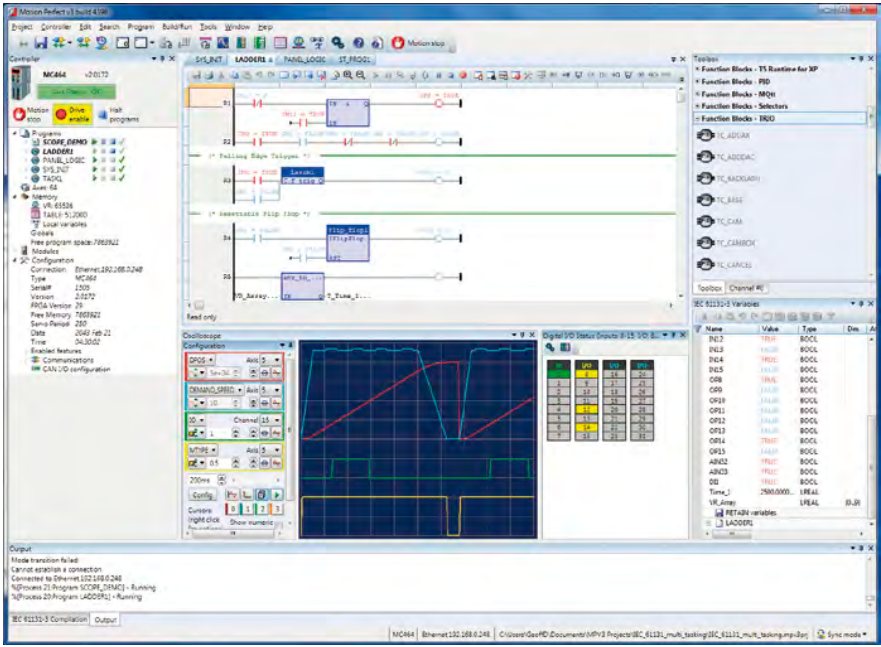
Motion Perfect v3 introduces the option of constructing programs using up to 4 of the IEC61131-3 methods. Ladder (LD), function block (FB), structured text (ST) and sequential function chart (SFC) are all supported through appropriate editor pages and toolbox functions. Only instruction list (IL) is unsupported because its application to motion programming is very limited. All the familiar Trio motion functions are provided as pre-defined function blocks in two special libraries within the MPv3 toolbox.
New to the MC4xx range and Motion Perfect v3 is the Uniplay HMI programming system. Create your HMI pages with the MPv3 graphical editor and store them within the Motion Coordinator as part of the project. The Uniplay HMI downloads the pages from the Motion Coordinator during system startup and interacts with the Motion Coordinator during run-time. Uniplay HMI programming does away with the need for a separate programming tool for the HMI. All the machine programming can therefore be stored in one place; the MPv3 project, thus making long term support and software maintenance easier to control.
Setup and Programming
To program the Motion Coordinator, a PC is connected via an Ethernet link. The dedicated Motion Perfect version 3 Windows® application is normally used to provide a wide range of programming facilities on a PC running Microsoft Windows XP, Vista or Windows 7.
Once connected to the Motion Coordinator, the user has direct access to TrioBASIC which provides an easy, rapid way to develop control programs. All the standard program constructs are provided; variables, loops, input/output, maths and conditions. Extensions to this basic instruction set exist to permit a wide variety of motion control facilities, such as single axis moves, synchronised multi axis moves and unsynchronised multi axis moves as well as the control of the digital I/O. Commands for both 2D and 3D interpolated motion are provided as well as transform algorithms for
different robot geometries such as SCARA and Delta arrangements.
The MC4xx range of controllers feature a multi-tasking operating system which efficiently allows TrioBASIC and IEC 61131- 3 programs to work alongside the motion processing. Multiple TrioBASIC programs plus Ladder Diagram (LD), Function Block (FB), Structured Text (ST) and Sequential
Function Chart (SFC) can be constructed and run simultaneously to make programming complex applications much easier.
Motion Perfect version 3 uses the latest .NET technology to provide a more intuitive and familiar user experience. It gives a seamless programming, compilation and debug environment that can work in real-time with the MC4xx range. TrioBASIC support is backwards compatible with Motion Perfect 2 projects developed on earlier Motion Coordinator platforms. A motion library is provided which enables the familiar Trio Motion Technology commands to be included in IEC 61131-3 programs.
No comments to display
No comments to display