
5. Operation without CANopen
5.1 Trial Operation
5.1.1 Flow of Trial Operation
Make sure that all the wiring has been completed before the trial operation.
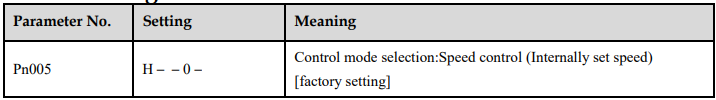
Perform the following three methods of trial operation in order. Instructions are given for speed control mode (standard setting) and position control mode. Unless otherwise specified, the standard parameters for speed control mode (factory settings) are used.
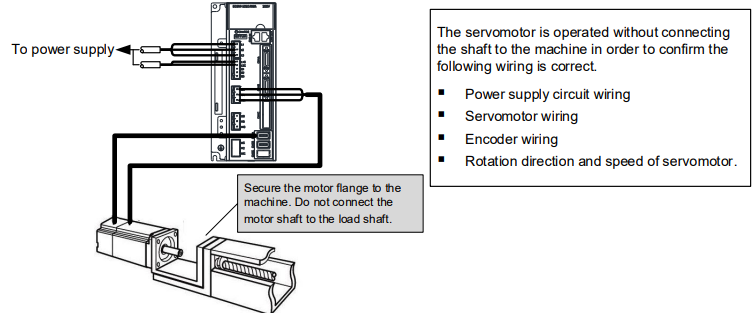
Trial Operation for Servomotor Without Load
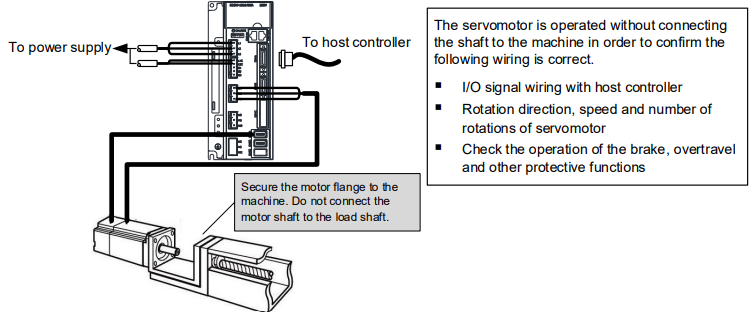
Trial operation for servomotor with host reference
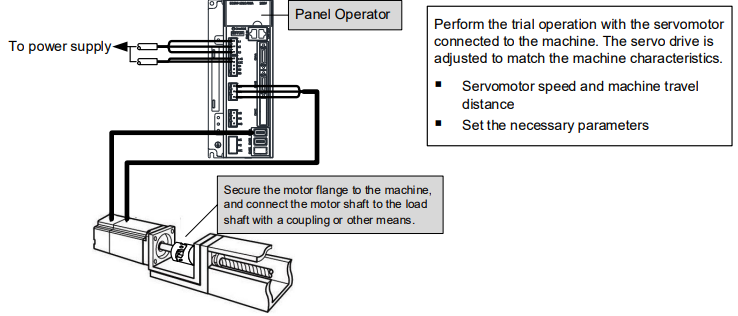
Trial operation for servomotor and machine combined
Procedure for the trial operation
Step 1 Installation
Install the servomotor and servo drive according to the installation conditions. (Do not connect the servomotor to the machine because the servomotor will be operated first under the no-load condition for checking.)
Step 2 Wiring
Connect the power supply circuit (L1, L2 and L3), servomotor wiring (U, V, W), I/O signal wiring (CN1 □), and encoder wiring (CN2□). But during Trial Operation for Servomotor Without Load, disconnect the CN1□ connector.
Step 3 Turn the power ON
Turn the power ON. Using the panel operator to make sure that the servo drive is running normally. If using a servomotor equipped with an absolute encoder, please perform the setup for the absolute encoder.
Step 4 Perform the JOG operation
Perform the JOG operation with the servomotor alone under the no-load condition.
Step 5 Connect input signals
Connect the input signals (CN1□) necessary for trial operation to the Servodrive.
Step 6 Check input signals
Use the internal monitor function to check the input signals. Turn the power ON, and check the emergency stop, brake, overtravel, and other protective functions for the correct operation.
Step 7 Input the Servo-ON signal
Input the Servo-ON signal, and turn ON the servomotor.
Step 8 Input reference
Input the reference necessary for control mode, and check the servomotor for correct operation.
Step 9 Protective operation
Turn the power OFF, and connect the servomotor to the machine.
If using a servomotor equipped with an absolute encoder, set up the absolute encoder and make the initial settings for the host controller to match the machine’s zero position.
Step 10 Set necessary parameters
Using the same procedure as you did to input a reference in step 8,operate the servomotor via the host controller and set the parameter to make sure the machine’s travel direction, travel distance, and travel speed allcorrespond to the reference.
Step 11 Run
The servomotor can now be operated. Adjust the servo gain if necessary.
----End
5.1.2 Trial Operation for Servomotor Without Load
In this section, confirm the cable connections of the main circuit power supply, servomotor and encoder.
Incorrect wiring is generally the reason why servomotors fail to operate properly during the trial operation.
Confirm the wiring, and then conduct the trial operation for servomotor without load according to the following steps.
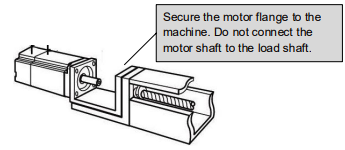
Step 1 Secure the servomotor.
Secure the servomotor flange to the machine in order to prevent the servomotor frommoving during the operation.
Do not connect the servomotor shaft to the machine. The servomotor may tip over during rotation.
Step 2 Check the power supply circuit, servomotor, and encoder wiring.
With the I/O signal connector (CN1□) disconnected, check the power supply circuit and Servomotor wiring.
See the section 3.1 Main Circuit Wiring for the details about the wiring of the main circuit.
Step 3 Turn ON the control power supply and main circuit power supply.
If the power is correctly supplied, the panel operator display on the front panel of the Servodrive will appear as shown on the left. The display on the left indicates that forward run prohibited (P-OT) and reverse run prohibited (N-OT).
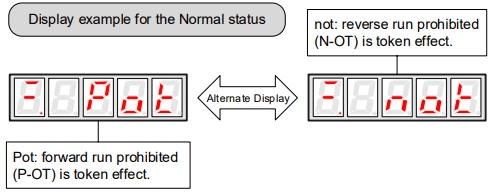
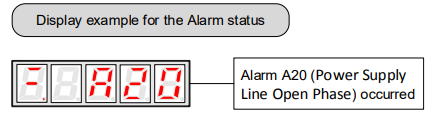
If an alarm display appears, the power supply circuit, servomotor wiring, or encoder wiring is incorrect. If an alarm is displayed, turn OFF the power, find the problem, and correct it.
Step 4 When using a servomotor with a brake, release the brake first before driving the servomotor.
Step 5 Use the panel operator to operate the servomotor with utility function Fn002 (JOG Operation).
Check the Servomotor rotates in the forward direction by pressing [▲] key, and reverse direction by pressing [▼] key.
The operation is completed when the operation is performed as described below and no alarm occurs.
Complete the Fn002 (JOG Mode Operation) and turn OFF the power.
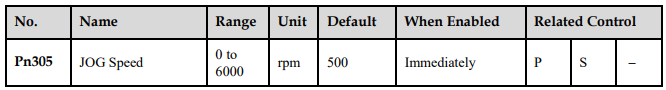
The servomotor speed can be changed using the Pn305 (JOG Speed). The factory setting for JOG speed is 500 rpm
You can operate the panel operator instead of the host controller for Jog operation of the Servomotor.
Moreover, the signal of P-OT and N-OT are invalid during the Jog operation.
----End
5.1.3 Trial Operation for Servomotor without Load from Host Controller
Check that the servomotor move reference or I/O signals are correctly set from the host controller to the servo drive.
Also check the wiring and polarity between the host controller and servo drive, and the servo drive operation settings are correct. This is the final check before connecting the servomotor to the machine.
Operating Procedure in Position Control Mode (Pn005=H――1-)
The following circuits are required: External input signal circuit or equivalent.
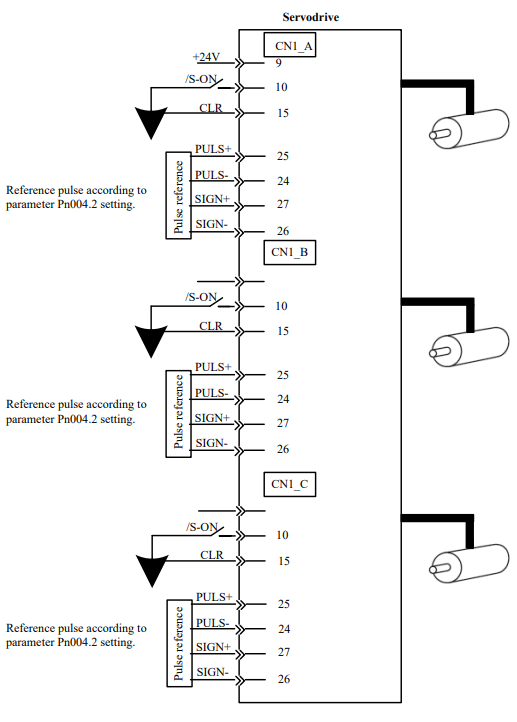
Step 1 Match the reference pulse form with the pulse output form from the host controller. Set the reference pulse form with Pn004.2.
Step 2 Set the reference unit and electronic gear ratio so that it coincides with the host controller setting. Set the electronic gear ratio with Pn201 (or Pn203)/Pn202.
Step 3 Turn the power and the servo ON input signal ON.
Step 4 Send the slow speed pulse reference for the number of servomotor rotation easy to check (for example, one servomotor revolution) from the host controller in advance. Set the servomotor speed to100rpm for the reference pulse speedbecause such speed is safe.
Step 5 Check the number of reference pulses input to the servo drive by the changed amount before and after the Un013 and Un014 (input reference pulsecounter)[pulse] were executed. See the section 4.4 Operation in Monitor for the details about how it is displayed.
Step 6 Check whether the actual number of servomotor rotations Un009, Un010 coincides with the number of input reference pulses. See the section 4.4 Operation in Monitor for the details about how it is displayed.
Step 7 Check that the servomotor rotation direction is the same as the reference.
Check the input pulse polarity and input reference pulse form.
Step 8 Input the pulse reference with the large number of servomotor rotation from the host controller to obtain the constant speed. Set the servomotor speed to 100rpm for the reference pulse speed because such speed is safe.
Step 9 Check the reference pulse speed input to the servo drive using the Un008in Monitor Mode.(input reference pulse speed)[rpm].
See the section 4.4 Operation in Monitor for the details about how it is displayed.
Step 10 Check the servomotor speed using the Un000 in Monitor Mode. (servomotor speed) [rpm]. See the section 4.4 Operation in Monitor for the details about how it is displayed.
Step 11 Check the rotation of the Servomotor.
To change the servomotor rotation direction without changing the input reference pulse form, see the section 5.3.2 Rotation Direction. Perform the operation from step 8 again after the servomotor rotation direction is changed.
Step 12 When the pulse reference input is stopped and servo OFF status is entered, the trial operation for servomotor without load in position control mode is complete.
----End
5.1.4 Trial Operation with the Servomotor Connected to the Machine
Follow the procedure below to perform the trial operation.
Step 1 Turn the power ON, and make the settings for the mechanical configuration related to protective functions such as overtravel and brake.
See the section 5.3 Basic Funtions Setting.
When a servomotor with brake is used, take advance measures to prevent vibration due to gravity acting on the machine or external forces before checking the brake operation. Check that both servomotor and brake operations are correct.
Step 2 Set the necessary parameters for the control mode used. Refer to the sections 5.5 Speed Control and 5.6 Position Control according to the control method.
Step 3 Connect the servomotor to the machine with the coupling,etc.,while the power is OFF.
Step 4 Check that the servo drive is servo OFF status and then turn ON the power to the machine (host controller). Check again that the protective function in step 1 operates normally. See the section 5.3 Basic Funtions Setting. For the following steps, take advanced measures for an emergency stop so that the servomotor can stop safely when an error occurs during operation.
Step 5 Perform trial operation with the servomotor connected to the machine, following each section in 5.1.2 Trial Operation for Servomotor Without Load. Check that the trial operation is completed according to the trial operation for servomotor without load. Also, check the settings for machine such as reference unit.
Step 6 Check the parameter settings for control mode used in step 2. Check that the servomotor rotates matching the machine operating specifications.
Step 7 Adjust the servo gain and improve the servomotor response characteristics, if necessary. The servomotor will not be broken in completely during trial operation. Therefore, let the system run for a sufficient amount of time to ensure that it is properly broken in.
----End
5.1.5 Trial Operation for Servomotor with Brakes
Holding brake operation of the servomotor can be controlled with the brake interlock output (/BK) signal of the servo drive.
When checking the brake operation,take advance measures to prevent vibration due to gravity acting on the machine or external forces. Check the servomotor operation and holding brake operation with the servomotor separated from the machine.If both operations are correct, connect the servomotor to the machine and perform trial operation.
5.2 Control Method Setting
The control modes supported by the ED3M series Servodrives are described below.
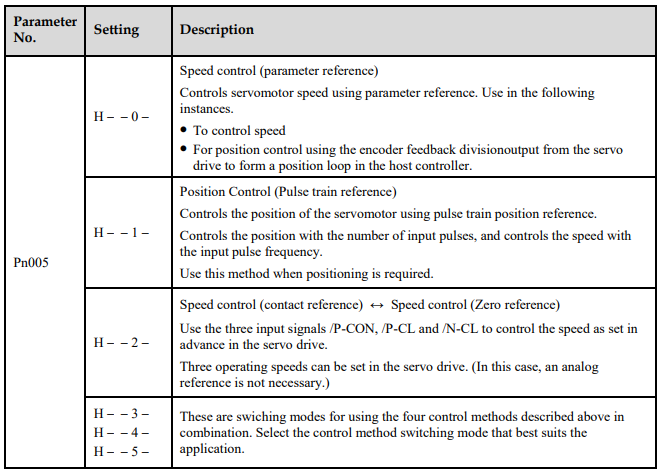
5.3 Basic Funtions Setting
5.3.1 Servo ON
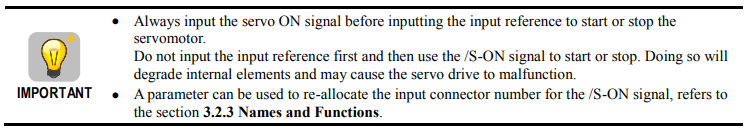
This sets the servo ON signal (/S-ON) that determines whether the Servomotor power is ON or OFF.
/S-ON Signal
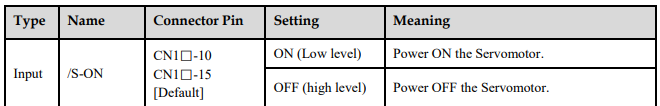
/S-ON Selection
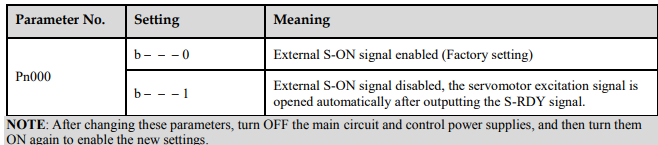
A parameter can be always used to set the servo ON condition. This eliminates the need to wire /S-ON, but care must be taken because the servo drive can operate as soon as the power is turned ON.
5.3.2 Rotation Direction
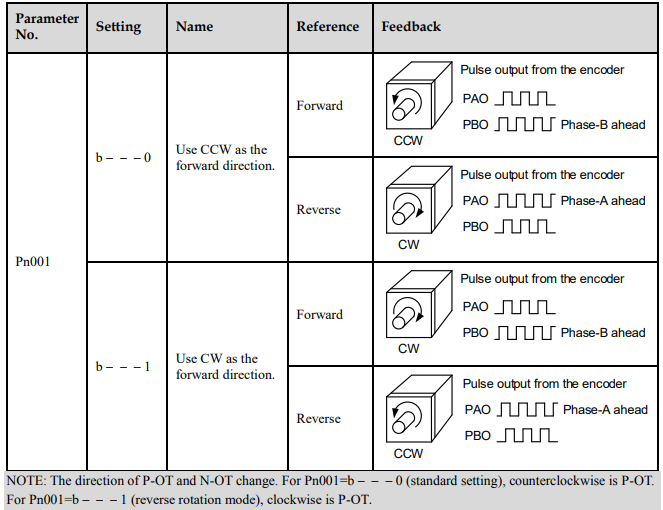
The rotation direction of the servomotor can be switched without changing the reference pulse to the servo drive or the reference voltage polarity.
This causes the rotation the servo motor shaft is rotating to change. The output signal polarity, such as the encoder pulse output and the analog monitor signal from the servo drive do not change.
The standard setting for “forward rotation” is counterclockwise as viewed from the servomotor load end.
5.3.3 Overtravel
The overtravel limit function forces movable machine parts to stop if they exceed the allowable range of motion and turn ON a limit switch.
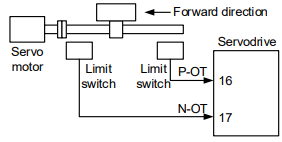
Overtravel Connection
To use the overtravel function, connect the following overtravel limit switch to the corresponding pin number of servo drive CN1□ connector correctly.
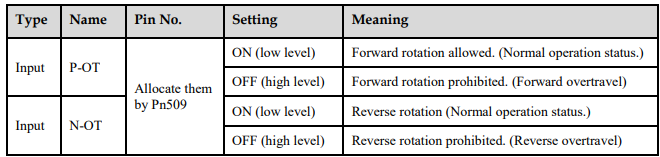
Connect limit switches as shown below to prevent damage to the devices during linear motion.
Rotation in the opposite direction is possible during overtravel.
For example, reverse rotation is possible during forward overtravel.
Overtravel Selection
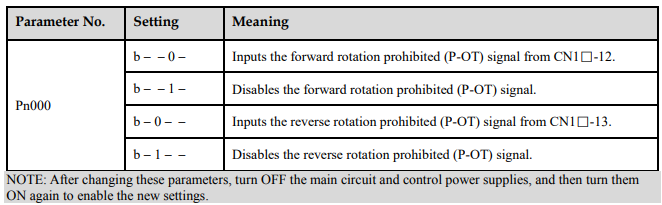
A parameter can be set to disable the overtravel signal. If the parameter is set, there is no need to wire the overtravel input signal.
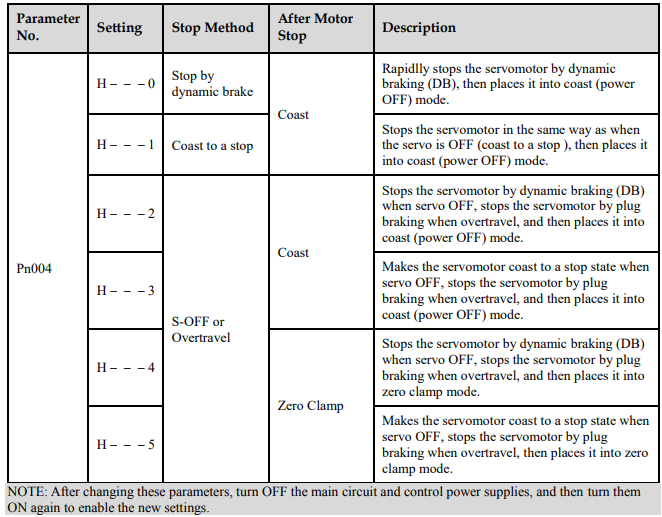
Stop Method
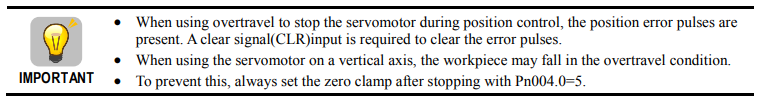
This is used to set the stop method when an overtravel(P-OT,N-OT)signal is input while theservomotor is operating.
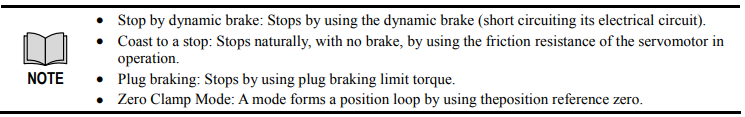
Dynamic brake is an emergency stop function, and one of the general methods to cause a servomotor sudden stop.
Dynamic brake suddenly stops a servomotor by shorting its electrical circuit. If the servomotor is frequently started and stopped by turning the power ON/OFF or using the servo ON signal(/S-ON), the DB circuit will also be repeatedly operated, degrading the servo drive’s internal elements.
Use the speed input reference and position reference to control the starting and the stopping of the
servomotor.
Stop Torque for Overtravel
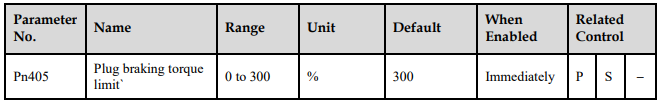
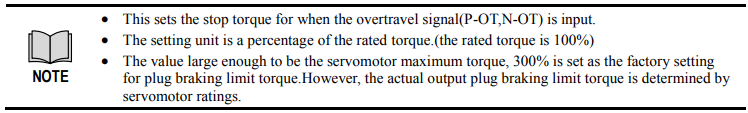
5.3.4 Holding Brakes Setting
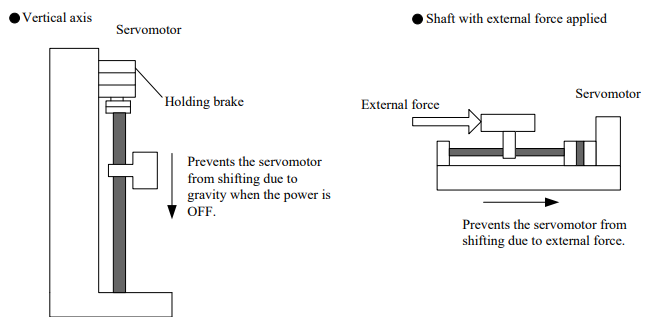
The holding brake is used when the servo drive controls a vertical axis.
A servomotor with the brake option helps prevent movable parts from shifting due to gravity when power is removed from the servo drive.(Refer to the section 5.1.5 Trial Operation for Servomotor with Brakes.)
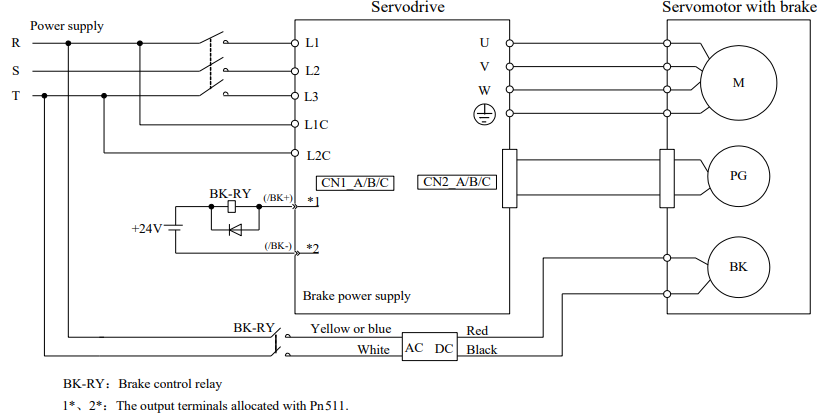
Wiring Example
Use the servo drive sequence output signal /BK and the brake power supply to form a brake ON/OFF circuit. The following diagram shows a standard wiring example.
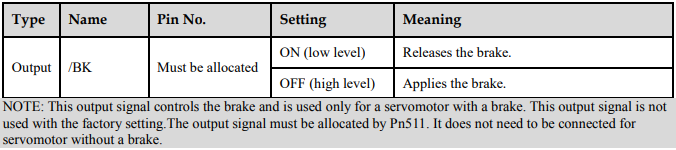
Brake interlock output
/BK Allocation
Brake interlock output (/BK) is not used with the factory setting.The output signal must be allocated.
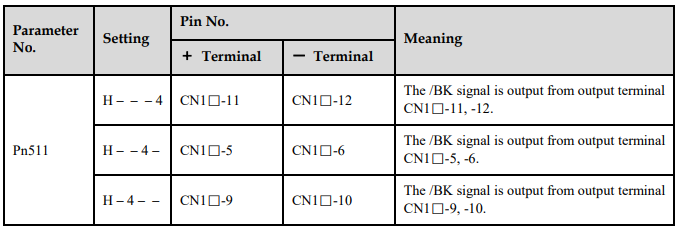
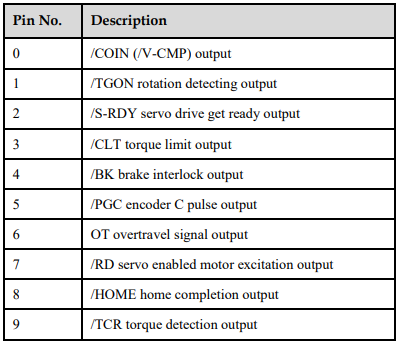
Parameter Pn511 description is as following:
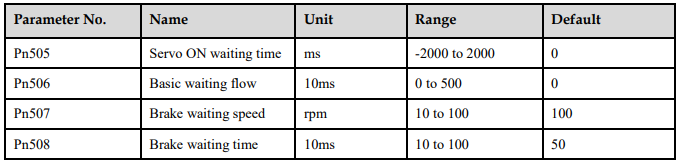
Relevant parameters are as following:
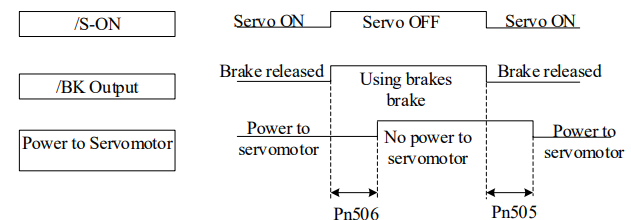
Brake ON/OFF Setting for Servomotor Stop
The /BK signal is output at the same time as the servo is turned OFF in the default setting. The servo OFF timing can be changed with a parameter.
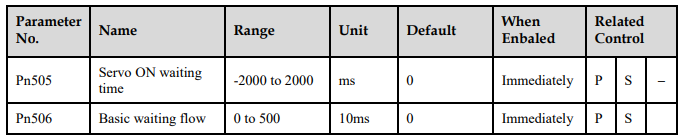
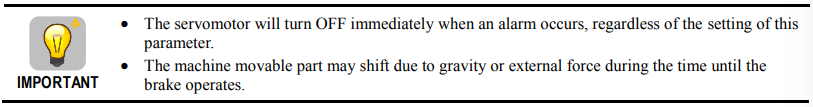
When using the servomotor to control a vertical axis, the machine movable parts may shift slightly depending on the brake ON/ OFF timing due to gravity or an external force. By using this parameter to delay turning the servo ON/ OFF, this slight shift can be eliminated.
For details on brake operation while the servomotor is operating, refer to Brake ON/OFF Setting for
Servomotor Running.
Brake ON/OFF Setting for Servomotor Running
The following parameters can be used to change the /BK signal output conditions when a stop reference is output during servomotor operation due to the servo OFF or an alarm occuring.
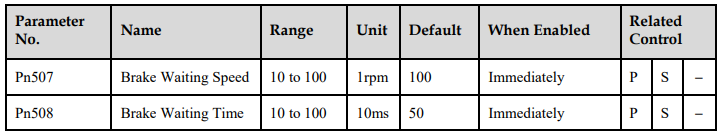
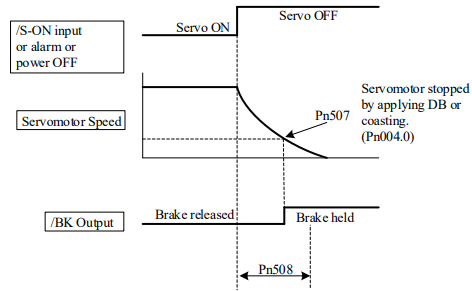
The /BK signal goes to high level(brake ON) when either of the following conditions is satisfied:
When the servomotor speed falls below the level set in Pn507 after servo OFF.
When the time set in Pn508 is exceeded after servo OFF.
5.4 Absolute Encoders
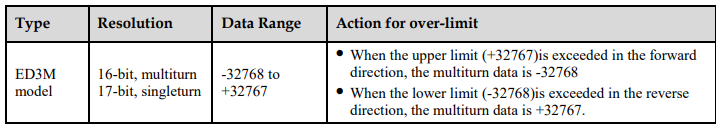
The absolute position can be read by the MODBUS protocol. In the actual control, the MODBUS protocol can read the initial position when the servomotor is stopped (S-OFF), then the real-time position during the servomotor is running can be found from the number of PG divided output pulses.
5.4.1 Absolute Encoder Selection
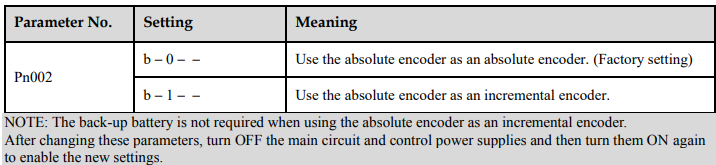
An absolute encoder can also be used as an incremental encoder.
5.4.2 Handling Battery
In order for the absolute encoder to retain position data when the power is turned OFF, the data must be backed up by a battery.
Please purchase the special cable and battery case mabe by Estun if an absolute encoder is used.
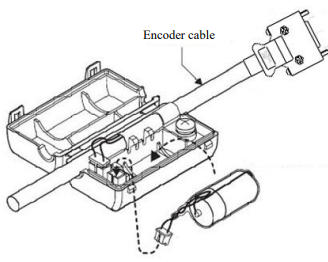
Install the battary to the encoder cable:
Step 1 Open the shell of the battery case.
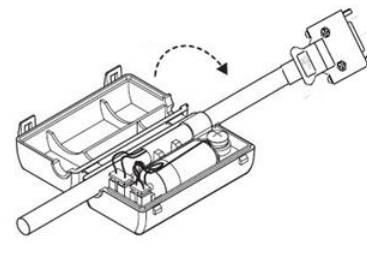
Step 2 Install the battery according to the following diagram.
Step 3 Cover the shell of the battery case.
----End
5.4.3 Replacing Battery
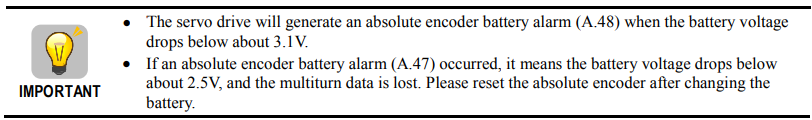
The servo drive will generate an absolute encoder battery alarm (A.48) when the battery voltage drops below about 3.1V.
Battery Replacement Procedure is as following.
Step 1 Replace the battery with only the servo drive control power supply turned ON.
Step 2 After replacing the battery, using the panel operator with utility function Fn011 to cancel the absolute encoder battery alarm (A.48).
Step 3 Turn ON the servo drive power back again. If it operates without any problems, the battery replacement has been completed.
----End
5.4.4 Absolute Encoder Setup (Fn010, Fn011)
Setting up the absolute encoder in the following cases.
When starting the machine for the first time,set Pn002.2 to 0.
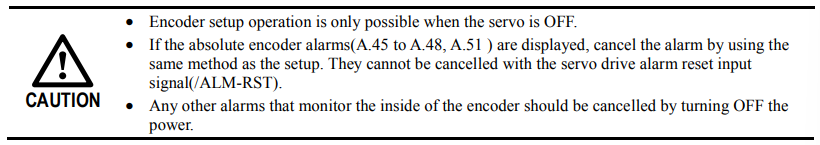
When an encoder error alarm (A.45 to A.48, A.51) is generated.
Use the panel operator in the servo drive for setup.
5.5 Speed Control
5.5.1 Parameter Setting
5.5.2 Soft Start
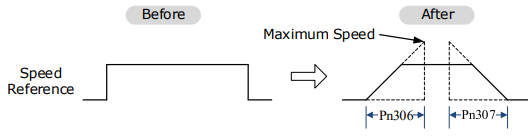
The soft start function converts the stepwise speed reference inside the servo drive to a consistent rate of acceleration and deceleration.
Pn310 can be used to select the soft start form:
: Slope; 1: S curve; 2: 1st-order filter; 3: 2nd-order filter
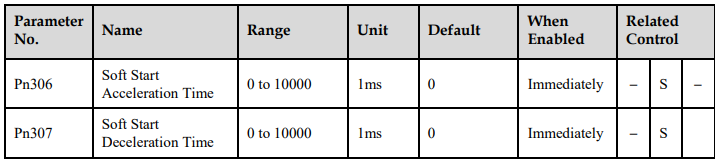
The soft start function enables smooth speed control when inputting a stepwise speed reference or when selecting internally set speeds. Set both Pn306 and Pn307 to “0” for normal speed control.
Set these parameters as follows:
Pn306: The time interval from the time the servomotor starts until the servomotor is 1000rpm.
Pn307: The time interval from the time the servomotor is 1000rpm until it stops.
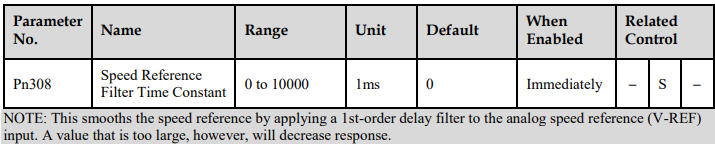
5.5.3 Speed Reference Filter Time Constant
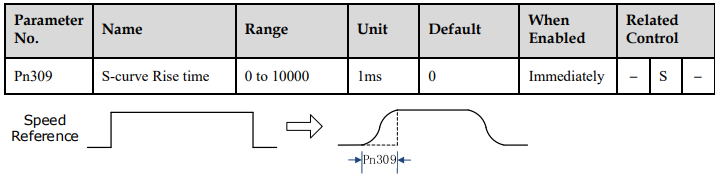
5.5.4 S-curve Risetime
5.5.5 Speed coincidence output
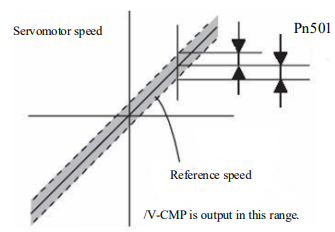
The speed coincidence (/V-CMP) output signal is output when the actual servomotor speed during speed control is the same as the speed reference input. The host controller uses the signal as an interlock.
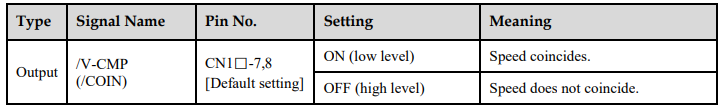
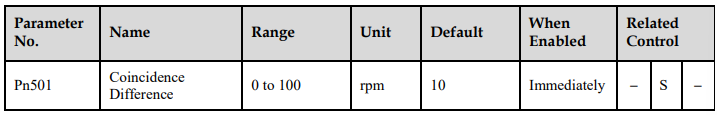
The /V-CMP signal is output when the difference between the speed reference and actual servomotor speed is less than Pn501.
For example, the /V-CMP signal turns ON at 1900 to 2100rpm ifthe Pn501 parameter is set to 100 and the reference speed is 2000rpm
5.5.6 Speed control (contact reference)
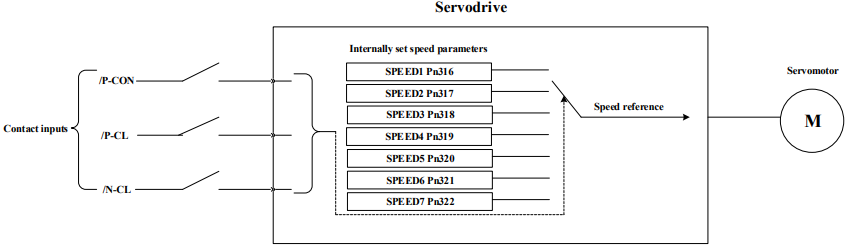
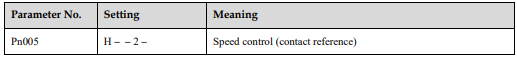
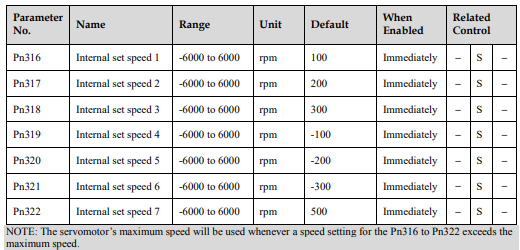
The function of internally set speed selection allows speed control operation by externally selecting an input signal from among seven servomotor speed setting made in advance with parameters in the servo drive. The speed control operations within the three settings are valid. There is no need for an external speed or pulse generator.
Parameter setting
Control Method Switching
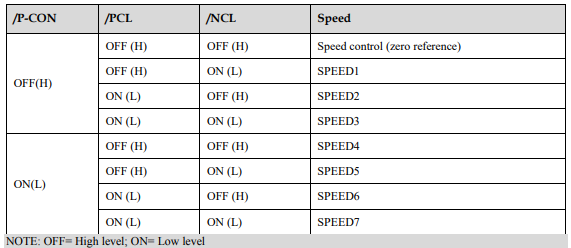
Use ON/OFF combinations of the following input signals to operate with the internally set speeds.
When Pn005.1=2: Selects the internally set speed (contact reference) ↔ Speed control (zero reference)
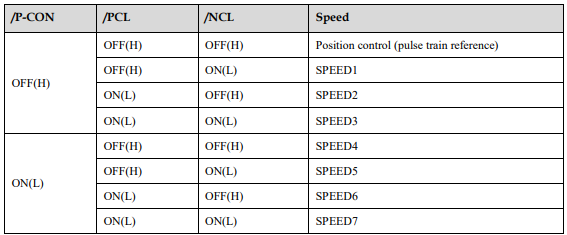
When Pn005.1 = 3, /P-CON, /PCL, /NCL = OFF (H), switches to position control (pulse train reference)
5.6 Position Control
5.6.1 Parameter Setting
Control Method Selection
Set the following parameters for position control using pulse trains.
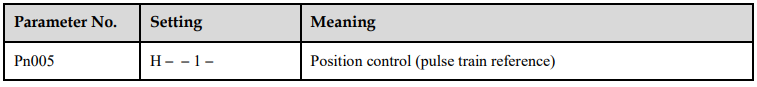
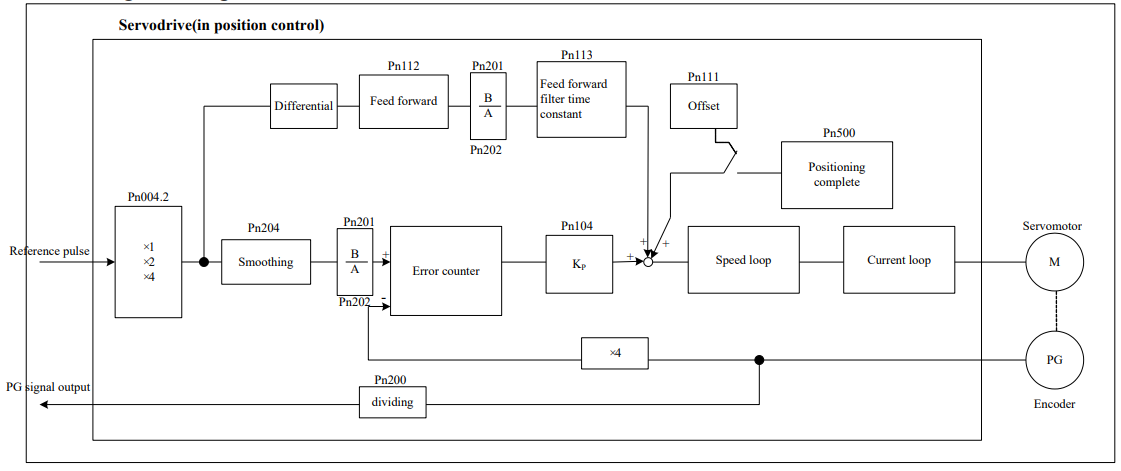
A block diagram for position control is shown as below.
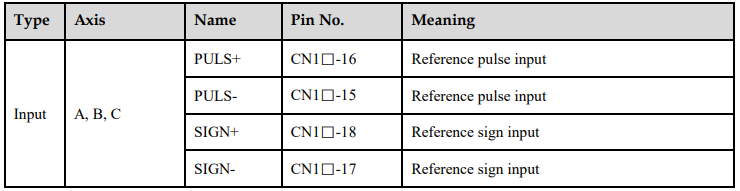
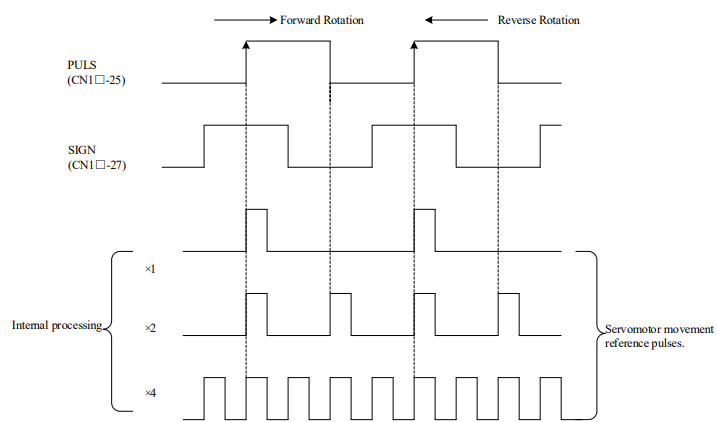
Setting a reference pulse sign
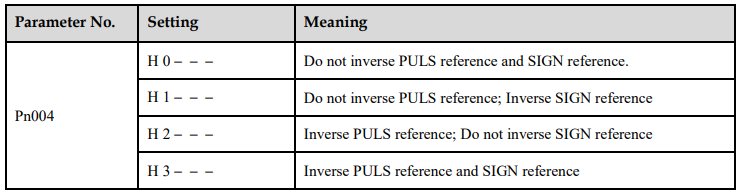
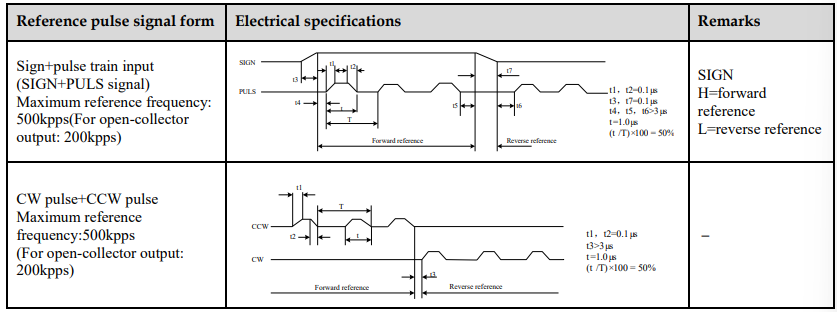
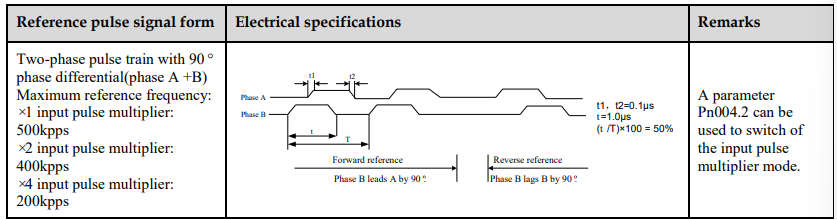
Set the input form for the servo drive using parameter Pn004.2 according to the host controller specifications.
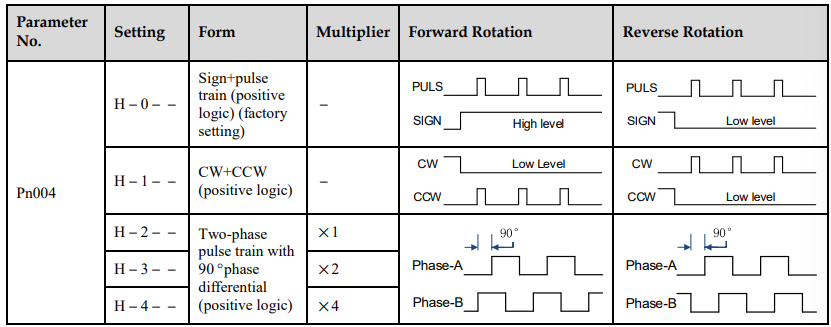
The input pulse multiplier can be set for the two-phase pulse train with 90° phase differential reference pulse form.
Inverse PULS and SIGN reference
Reference Pulse Input Signal Timing
5.6.2 Clear Setting
Setting the Clear Signal
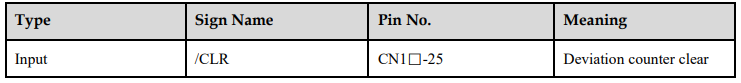
When the /CLR signal is set to low level, clear deviation counter:
The error counter inside the Servodrive is set to“0”
Position loop operation is disabled.
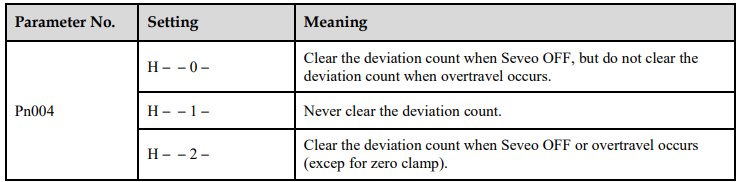
Setting the Clear Signal Mode
In position control mode, pulses will be still presented in the servo drive when servo OFF, thus it should be cleared when servo drive is turned ON. Setting Pn004 to choose whether clearing the pulses automatically when servo OFF.
5.6.3 Electronic Gear Setting
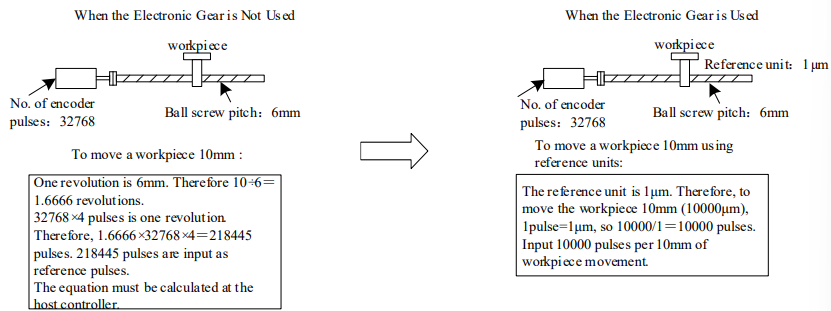
Electronic Gear
The electronic gear enables the workpiece travel distance per input reference pulse from the host controller to be set to any value.
One reference pulse from the host controller, i.e., the minimum position data unit, is called a reference unit.
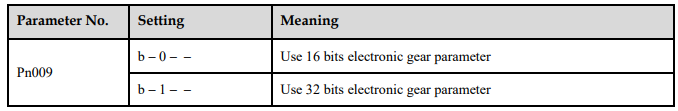
Relevant Parameters
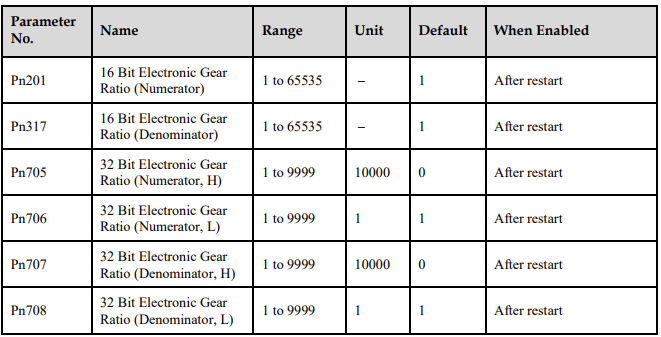
The deceleration ratio of the servomotor and the load shaft is given as n/m where m is the rotation of the servomotor and n is the rotation of the load shaft.
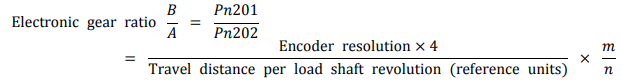
When 32 bit electronic gear function is enabled,
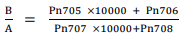
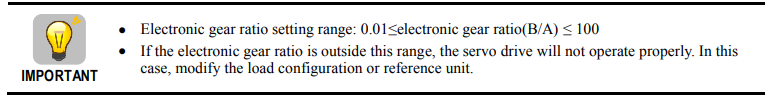
If the ratio is outside the setting range, reduce the fraction (both numerator and denominator) until you obtain integers within the range.
Note that do not change the electronic gear ratio (B/A)
Procedure for Setting the Electronic Gear Ratio
Use the following procedure to set the electronic gear ratio.
Step 1 Check machine specifications.
Check the deceleration ratio, ball screw pitch and pulley diameter.
Step 2 Check the number of encoder pulses.
Check the number of encoder pulses for the servomotor used.
Step 3 Determine the reference unit used.
Determine the reference unit from the host controller, considering the machine specifications and positioning accuracy.
Step 4 Calculate the travel distance per load shaft revolution.
Calculate the number of reference units necessary to turn the load shaft one revolution based on the previously determined reference units.s
Step 5 Calculate the electronic gear ratio.
Use the electronic gear ratio equation to calculate the ratio (B/A).
Step 6 Set parameters.
Set parameters using the calculated values.
----End
Electronic Gear Ratio Setting Examples
The following examples show electronic gear ratio settings for different load configurations.
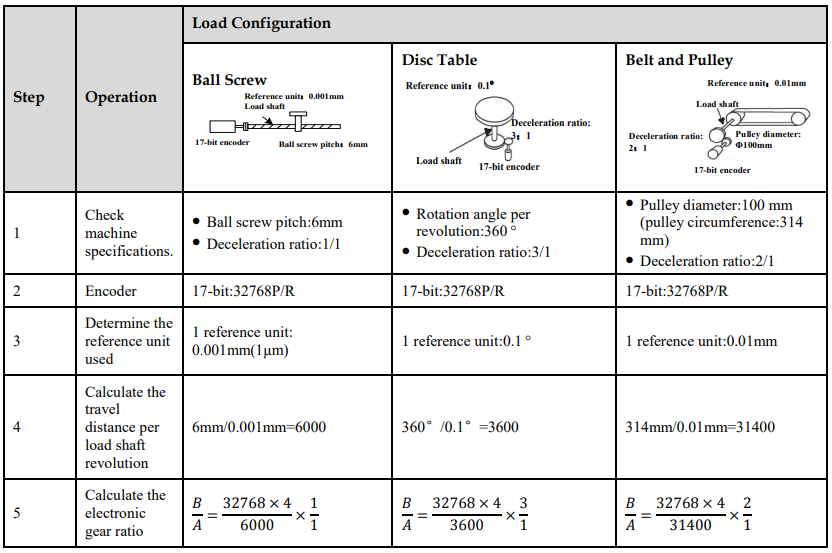
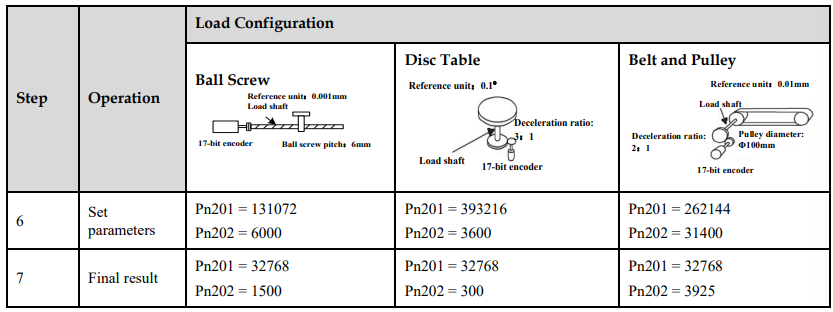
Reduce the fraction (both numerator and denominator) if the calculated result will not be within the setting range.
For example, reduce the above numerators and denominators by four or other numbers to obtain the final results in step 7 and complete the settings.
Electronic Gear Ratio Equation
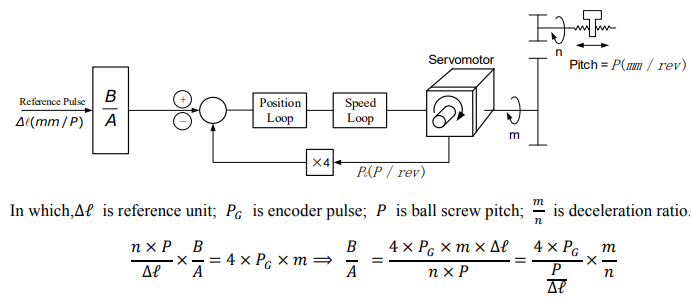
Set A and B by Pn202 and Pn201.
5.6.4 Smoothing
A filter can be applied in the servo drive to a constant-frequency reference pulse.
Selecting a Position Reference Filter
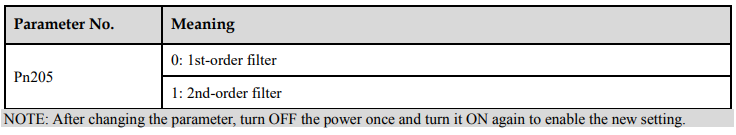
Relevant Parameters
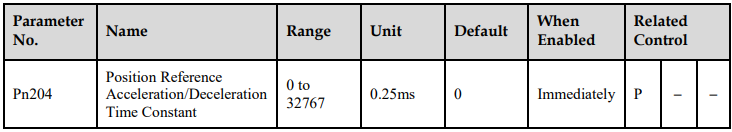
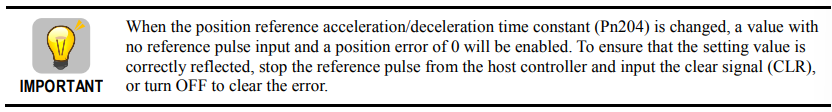
This function provides smooth servomotor operation in the following cases.
When the host controller that outputs a reference that cannot perform acceleration/deceleration processing.
When the reference pulse frequency is too low.
When the reference electronic gear ratio is too high (i.e., 10× or more)
5.6.5 Low Frequency Vibration Suppression
Function Description
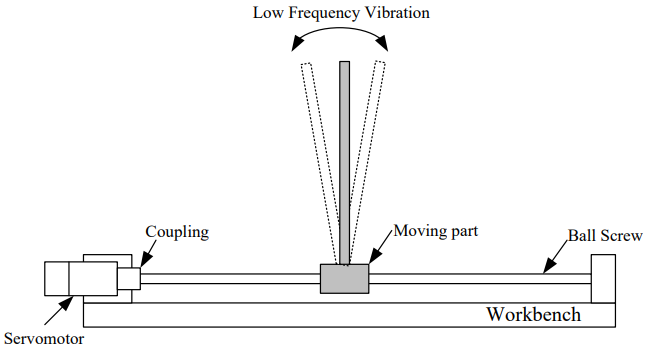
For the low rigidity load, low frequency vibration will occur continually at the front end of the load during fast acceleration or fast deceleration. The vibration may delay positioning time and affect the productive efficiency.
The function of low frequency vibration suppression is embedded in the Servodrives by calculating the load position and compensating.
Applicable Range
Low frequency vibration suppression function is enabled in both speed control mode and position control mode.
Low frequency vibration suppression function is disabled or can not reach the expected effect in the following conditions.
Vibration is pricked up due to an external force.
Vibration frequency is between5.0Hz to 50.0Hz.
There is mechanical clearance at the mechanical connection part.
The time for movement is less than one vibration period.
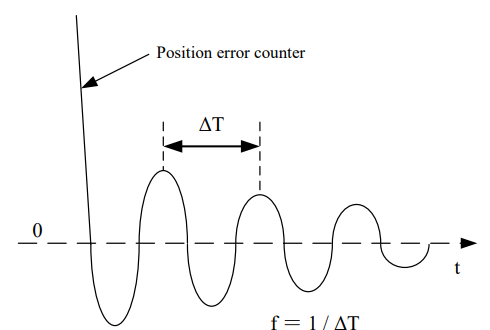
Measuring Vibration frequency
Write the frequency data measured(unit:0.1Hz) directly to Parameter Pn411, if the vibration frequency can be measured by an instrument (such as a laser interferometer).And it also can be measured indirectly by communication software ESView or FFT analsis function.
Ralated Parameters
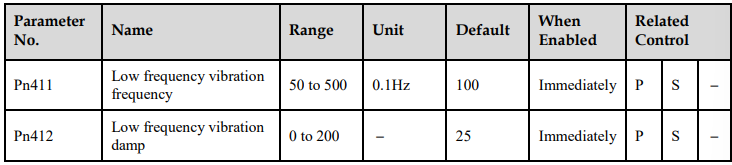
Writing the frequency data to parameter Pn411 can adjust Pn411 slightly to obtain the best suppression effect.
If the servomotor stopped with continuous vibration, Pn412(Do not change in general) should be increased properly.
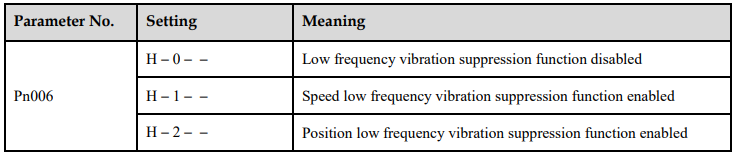
Parameter Pn411 and Pn412 are enabled when Pn006.2=1 or 2(Setting validation: after restart).
5.6.6 Positioning Completion Output Signal
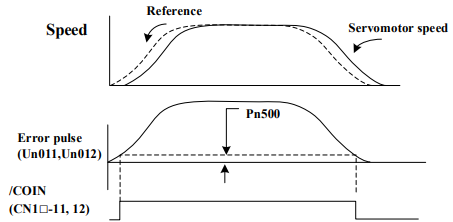
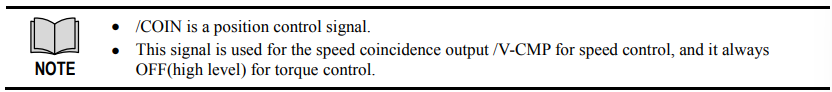
This signal indicates that servomotor movement has been completed during position control. Use the signal as an interlock to confirm that positioning has been completedat the host controller.
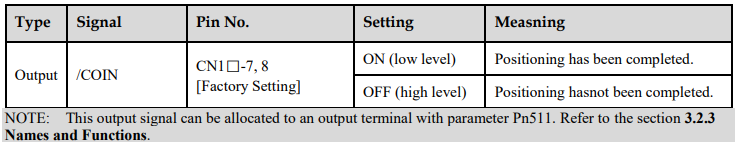
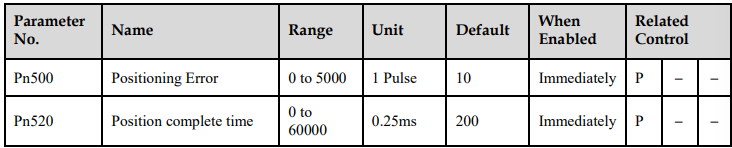
The positioning completion (/COIN) signal is output when the difference (position error pulse) between the number of reference pulses output by the host controller and the travel distance of the servomotor is less than the value set in this parameter and the stabilization time is more than the value of Pn520.
Set the number of error pulses in reference unit (the number of input pulses defined using the electronic gear).
Too large a value at this parameter may output only a small error during low-speed operation that will cause the /COIN signal to be output continuously.
The positioning error setting has no effect on final positioning accuracy.
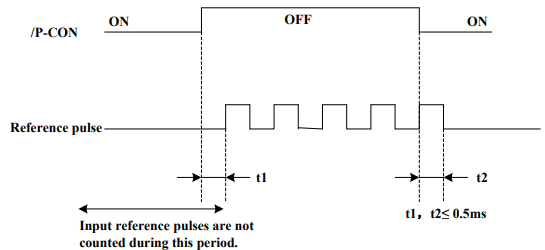
5.6.7 Reference Pulse Inhibit Function(INHIBIT)
Function Description
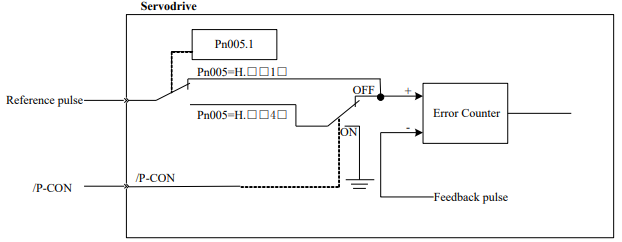
This function inhibits the servo drive from counting input pulses during position control.
The servomotor remains locked (clamped) while pulses are inhibited
Parameter Setting
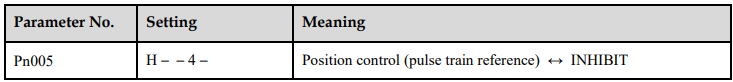
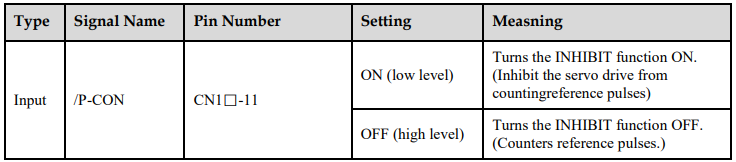
Inhibit(INHIBIT) switching condition: /P-CON signal ON (low level)
Signal Setting
5.6.8 Position Control (contact reference)
Position control under contact reference (parameter Pn005.1=5). In this mode, servo drive can position with a single axes without a host controller.
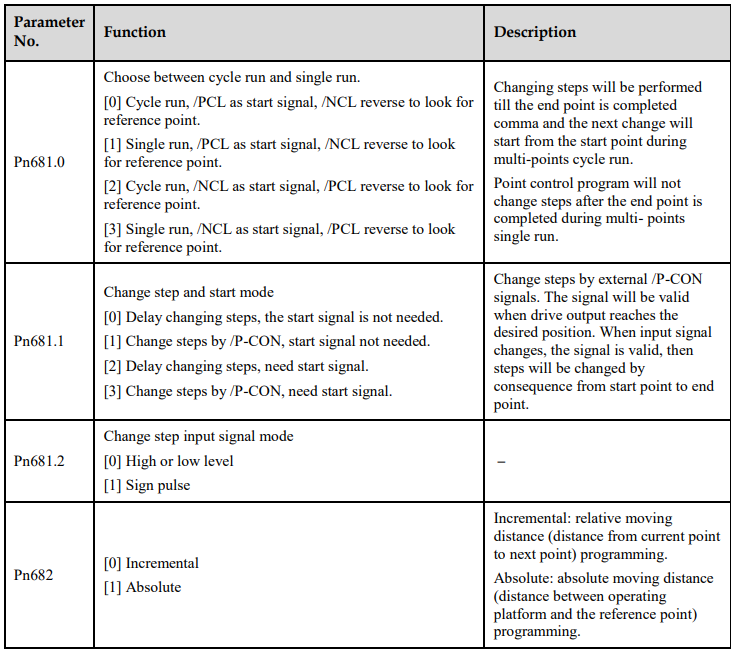
There are 16 position control points with each being able to set move distance, running speed, constants for position reference filter time, and the stop time when positioning completed. Two speeds (1. speed moving toward distance switch “speed of looking for reference point”. 2. Speed moving away from distance switch “moving speed.”) of reference points could be set as:
Two position modes: 1. Absolute position mode 2. Relative position mode
Two running modes: 1. Circling mode 2. Non-circling mode
Two step switching method: 1. Delay step switching 2. /P-CON signal switching
Method of looking for reference points: 1. Forward direction 2. Reverse direction
Offset Adjustment
Offset of each points has two correspondent parameters: one unit of the parameter is [x 10000 reference pulse] and the other is [x 1 reference pulse]. Setting range of both parameters is: (-9999----+9999), while offset value equals sum of those two values.
For example: No.0 offset correspond to parameter Pn600 [x 10000 reference pulse] and Pn601[x 1 reference pulse]. Set Pn600 = 100, Pn601=-100.
No. 0 offset value = Pn600 × 10000 reference pulse +Pn601 × 1 reference pulse = 100x10000 reference pulse + (−100) x1 reference pulse = 999900 reference pulse
With the same principle, we can conclude: in order to get the same results, we also can set Pn600 = 99, Pn601 = 9900
Thus, we can see when the two parameters are not zero; we can get same result by two ways: one is to set the two parameters both negative or both positive, or one negative the other positive.
Speed
Speed mentioned here refers to the steady speed during which the motor is running, which is similar to the pulse frequency given from the external pulse reference in position control.However, this speed has nothing to do with the electronic gear; it is the actual speed of the motor.
Position reference filter time constant
Same as position reference filter time constant Pn204 in common position control.
Time for change steps after desired position reached
Apply internal delay to change steps to a valid value in parameter Pn681.1.
Time for change steps outputs from positioning completed signal CON/, from Servo ON, or from the time when reference point is found till the Servo performs the program to control position of the point. Such period of time depends on step changing time required by a point number among start point in program.
When running point control program, if error counter is set as “not clear error counter when Servo OFF”, then the error counter might flood. If it does not flood, then the servo drive will probably run at the max. running speed when Servo ON again. PLEASE PAY ATTENTION TO THE SAFETY OF INSTRUMENT.
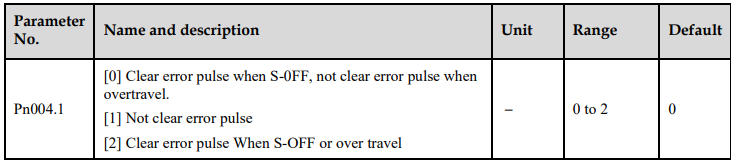
Looking for the reference point
Looking for the reference point is for establishing a zero physical point of the operating platform, which is used as zero point in the coordinates during point position control. And users may choose to find a reference point either in forward or reverse side.
How to find a reference point
Mount a limit switch in the forward or reverse side.Find a reference point in the forward direction after connecting to /PCL and in the reverse direction after connecting to /NCL. When the operating platform bumps into the limit the switch, the motor will first stop according to the way set by Pn004.0, and then rotate again against limit the switch. When the operating platform leaves the limit switch and the motor reaches the position of first photo encoder Phase C pulse,then position of operating platform is set to be the zero point of the coordinates.
How to find Relevant parameters of reference point
Speed towards limit switch is called “speed of looking for reference point “, and the moving speed away from limit switch is called “ moving speed”. These two speeds could be set by the following parameters:
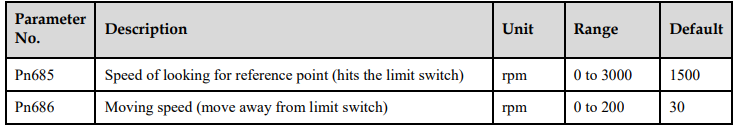
Usually, the set speed of the reference point (Pn685) is high, and the moving speed (Pn686) is low. Note:
if moving speed is too high, precision of finding a reference point would be affected.
When looking for a reference point, /PCL and /NCL are no longer programmed to limit external current.
Relevant parameter
5.6.9 Internal Homing Function
The servomotor always needs to operate at a fixed position. This position is normally regarded as the zero position. When the host controller is turned on, the zero position adjustment is required before processing. This zero position will be regarded as the reference point. ESTUN servo drives can perform this function by the homing function.
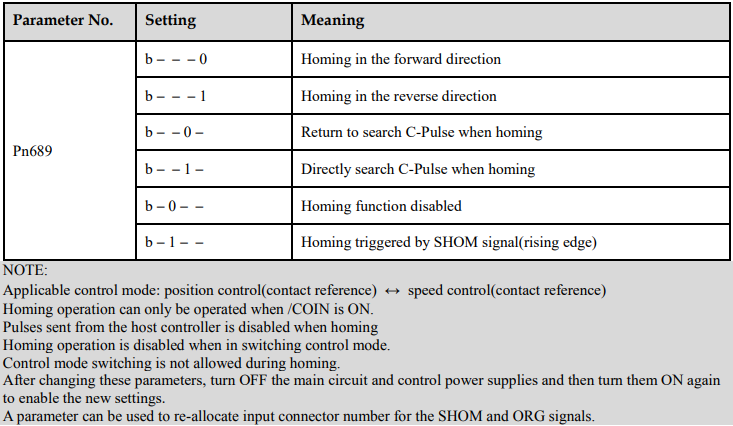
Homing Mode Setting
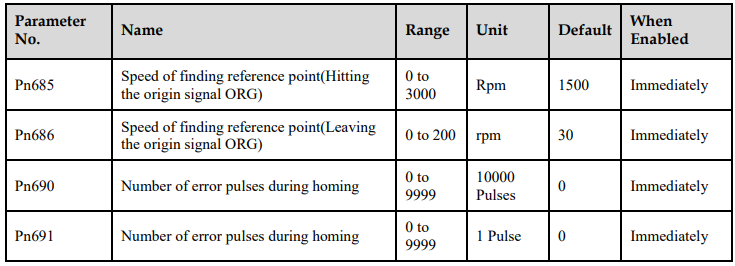
Relevant Parameters
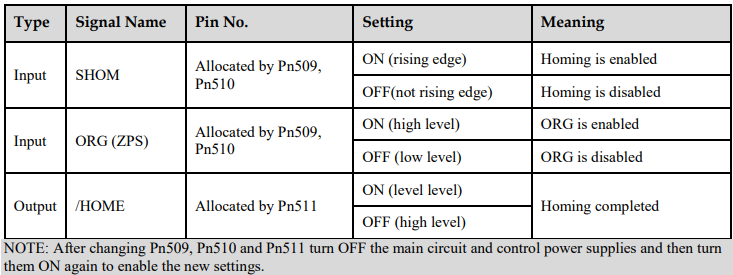
Input Signal Setting
Homing Operation Description
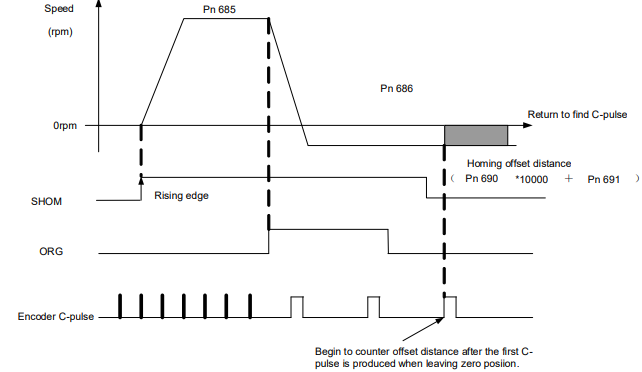
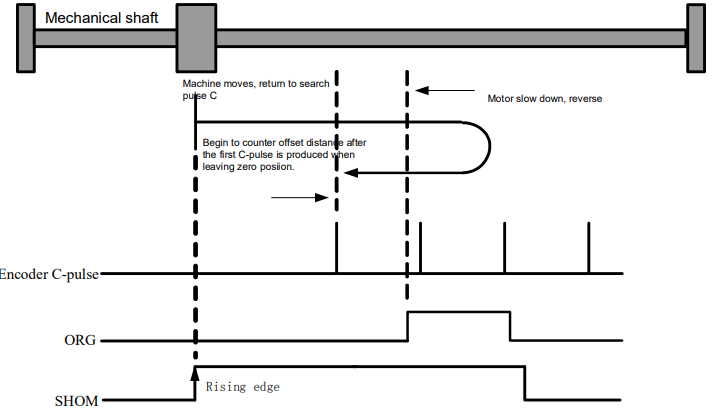
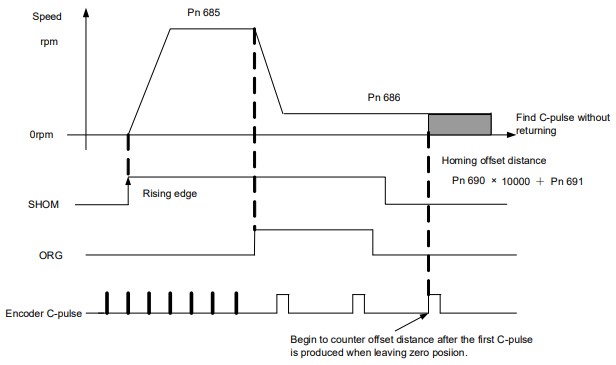
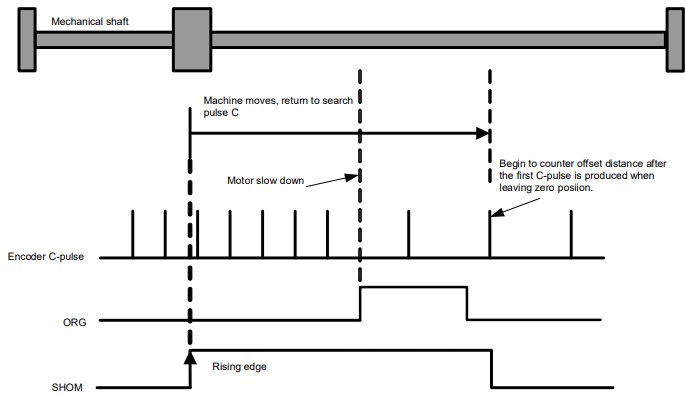
Please set Pn689 according to the actual operation in position control mode. When starting the homing function, the servomotor will run at the speed of Pn685 when detecting the rising edge of SHOM signal; the servomotor will run at the speed of Pn686 according to the setting of Pn689.1 when detecting the valid ORG signal.
When input ORG and the encoder C-Pulse is detected, the servo drive will begin to calculate the number of homing offset pulses. When offset pulses is completed, the servomotor stops and outputs homing completion signal /HOME, then homing control is completed.
Pn685 (Hitting the origin signal (ORG)) is usually set at high speed, Pn686 (Leaving the origin signal ORG) is usually set at low speed.
Please be attention that if Pn686 is setting too high, the precision of mechanical zero position will be affected.
After hitting the origin signal ORG, the motor will return to find C-pulse; the figure is shown as below:
Corresponding position:
After hitting the origin signal ORG, the motor will find C-pulse directly; the figure is shown as below:
Corresponding position:
5.7 Torque Limit
The Servodrive provides internal torque limit/external torque limit for limiting output torque to protect the machine.
5.7.1 Internal Torque Limit
Maximum torque is always limited to the values set in the following parameters.
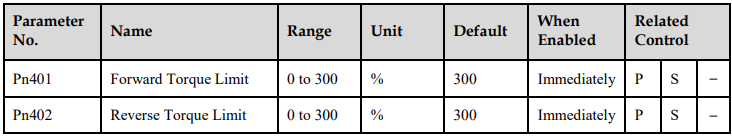
The setting unit is a percentage of rated torque.
The maximum torque of the servomotor is used, even though the torque limit is set higher than the maximum torque of the servomotor. (as is the case with the 300% factory setting)
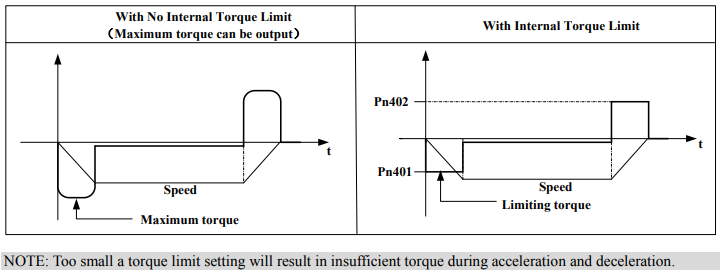
5.7.2 External Torque Limit
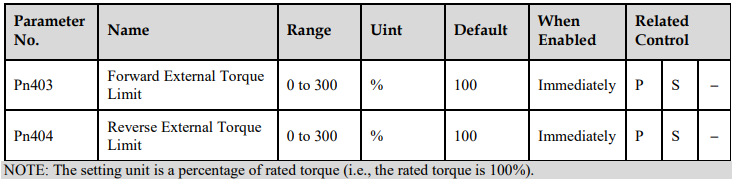
This function allows the torque to be limited at specific times during machine operation, for example, during press stops and hold operations for robot workpieces.
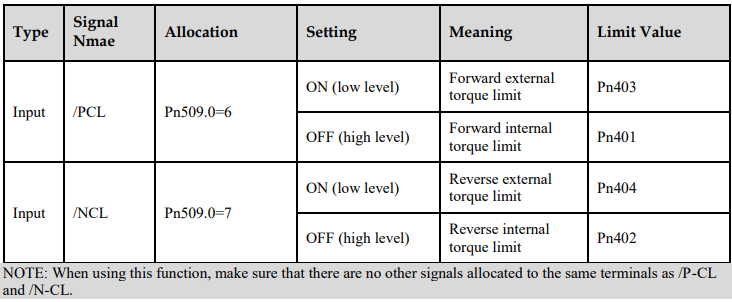
An input signal is used to enable the torque limits previously set in parameters.
Relevant Parameters
Input Signals
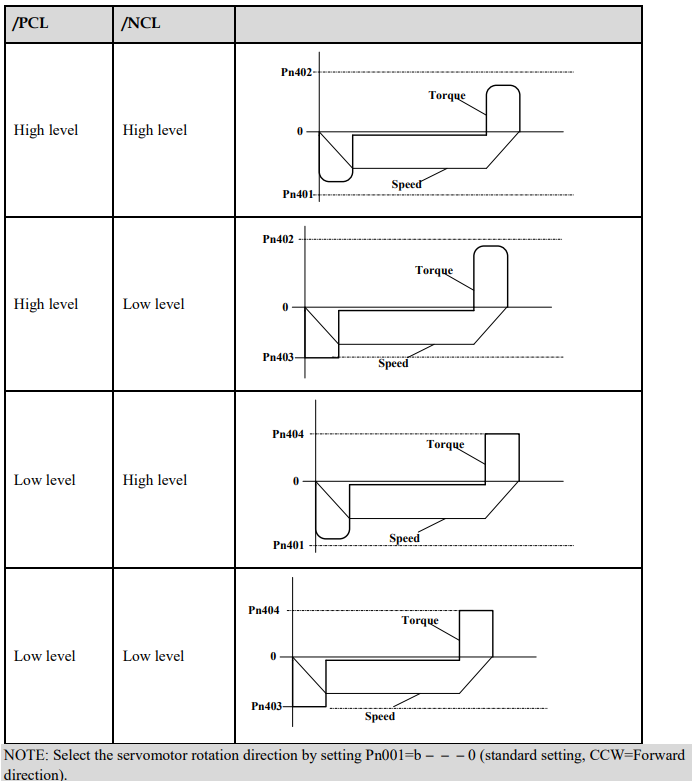
Changes in Output Torque during External Torque Limiting
For example: External torque limit (Pn401, Pn402) set to 300%
5.8 Other Output Signals
5.8.1 Servo alarm output
The following diagram shows the right way to connect the Alarm Output.
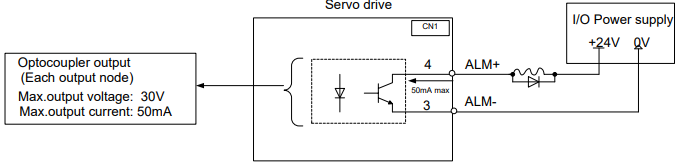
An external +24V I/O power supply is required since there is no +24V power source available inside the servo drive.


ALM outputs a signal when the servo drive is detected in an abnormal state
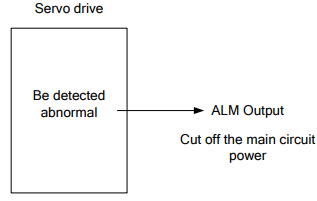
Normally, the external circuit consists of /ALM should be able to switch off the power of servo drive.
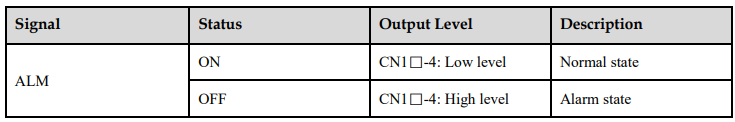
When “servo alarm(ALM)” happens, always remove alarm reasons first , and then turn the input signal "/ALM-RST" to ON position to reset alarm status.
5.8.2 Others
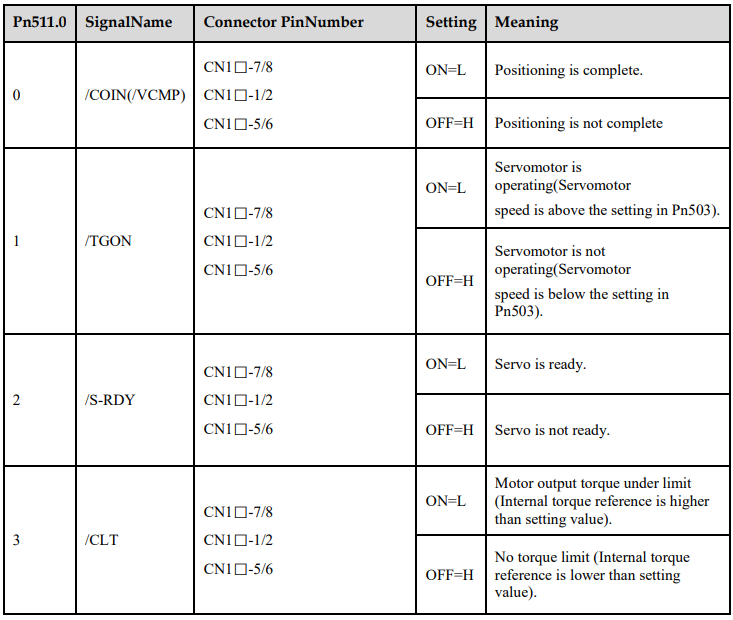
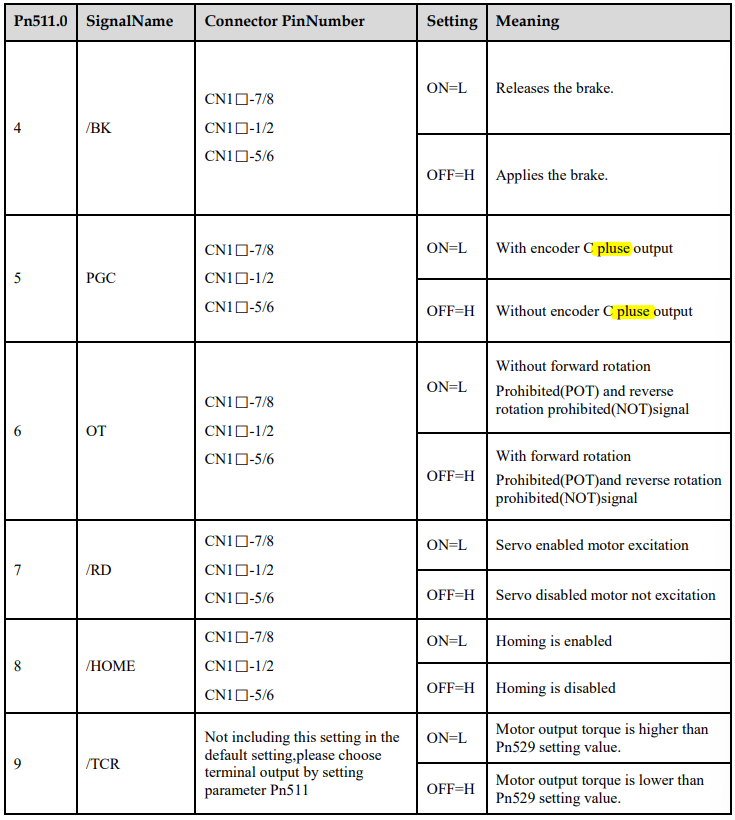
Set Pn511.9 to allocate the desired output signal.
5.9 Online Autotuning
5.9.1 Function Description
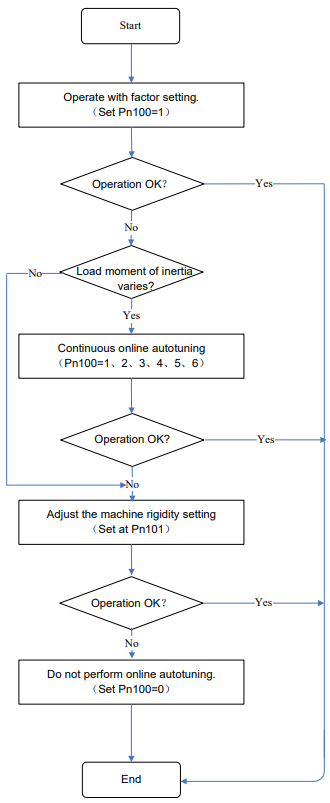
Online autotuning calculates the load moment of inertia during operation of the servo drive and sets parametersso that the servo gains are consistent with the machine rigidity.
Online autotuning may not be effective in the following cases:
The motor high speed is lower than 100 rpm.
The motor acceleration or deceleration is lower than 5000rpm/s.
Load rigidity is low and mechanical vibration occurs easily or friction is high.
The speed load moment is changed greatly.
Mechanical gas is very large.
If the condition meets one of the above cases or the desired operation cannot be achieved by the online autotuning, set the value in Pn106 (Load inertia percentage) and performthe adjustment manually
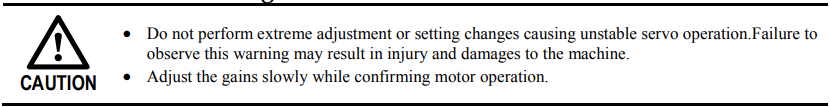
5.9.2 Online Autotuning Procedure
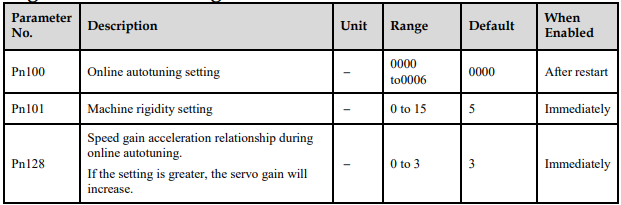
5.9.3 Setting Online Autotuning
5.9.4 Machine Rigidity Setting for Online Autotuning
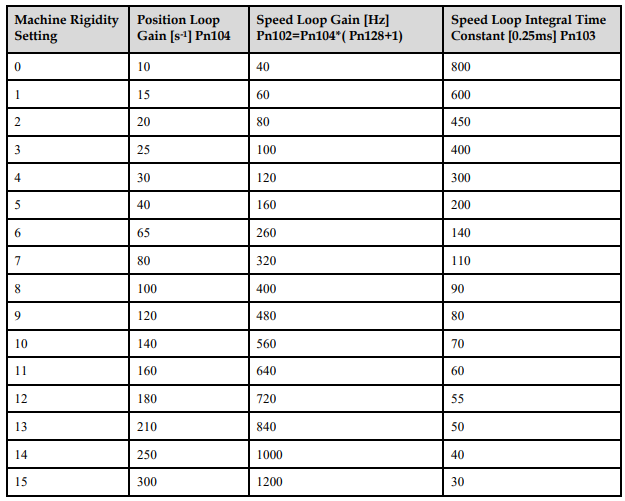
There are 16 machine rigidity settings for online autotuning, When the machine rigidity setting is selected, the servo gains (speed loop gain, speed loop integral time constant, position loop gain) are determined automatically. The factory setting for the machine rigidity setting is 5.
No comments to display
No comments to display