
4.INSTALL EQUIPMENT
4.1. END FLANGE MOUNTING INTERFACE
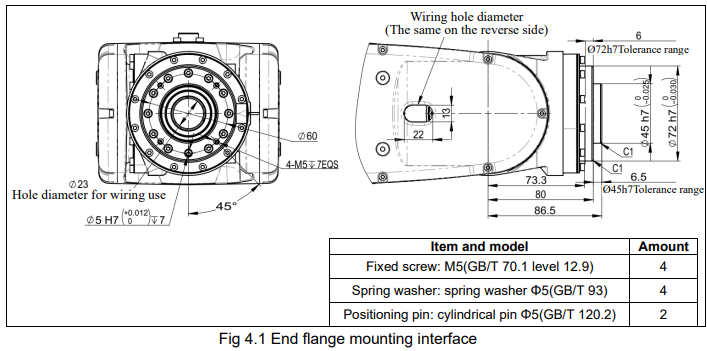
This section describes the mounting face dimension of the end effector. Consider the depth of the screw holes and pin holes sufficiently before choose the length of the bolts and pins. Antirust measures of screws, grippers, etc., should be considered as well.
4.2. EQUIPMENT MOUNTING SURFACE
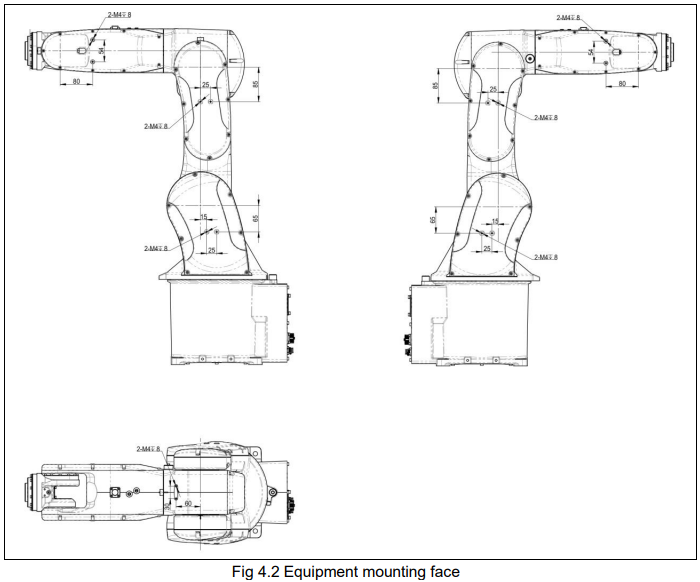
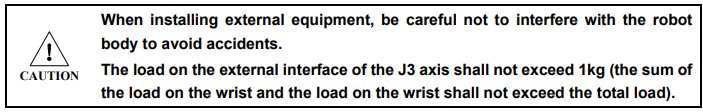
The figure shows the positions of the screw holes for device installation. The robot reserves threaded holes for external device installation on the top of the forearm part.
When installing robot, strictly observe precautions listed below to cause no deformation in the base.
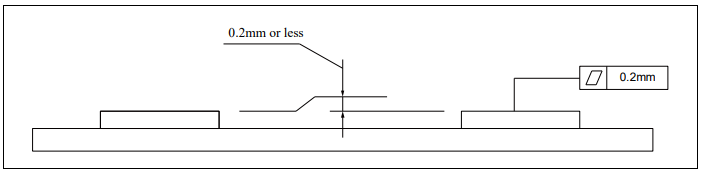
(1) The flatness of the robot installation panel (4 sheets) should be within 0.2mm.
(2) The relative height error of the installation surface of the robot installation panel (4 sheets) should be within 0.2mm (±0.1mm).
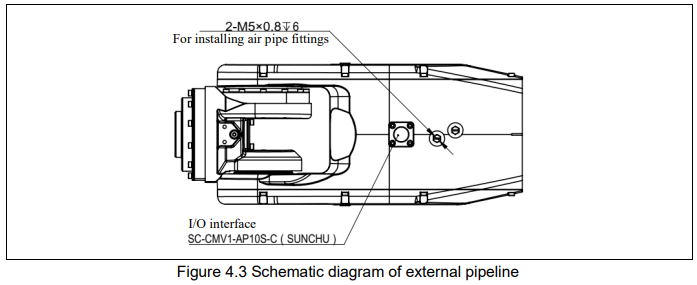
4.3. EXTERNAL PIPELINE
The mini-series robots provide access to the end effector for supply of air or hydraulic pressure.
No comments to display
No comments to display