
4. Conversion factors (factor group)
Servo controllers will be used in a huge number of applications: As direct drive, with gear or for linear drives. To allow an easy parameterization for all kinds of applications, the servo controller can be parameterized in such a way that all values like the demand velocity refer to the driven side of the plant. The necessary calculation is done by the servo controller
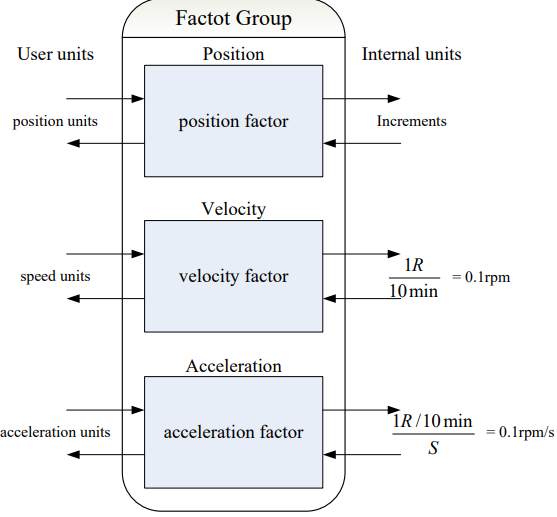
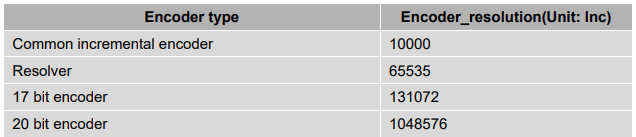
The default setting of the Factor Group is as follows:
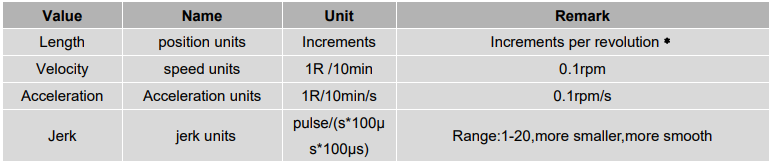
﹡: Common incremental encoder: 10000P/R
Resolver: 65536P/R
17 bit incremental encoder: 131072P/R
17 bit absolute encoder: 131072P/R
20 bit absolute encoder: 1048576P/R
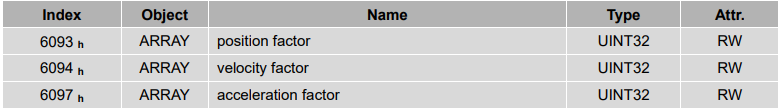
4.2 Position factor
The object position factor converts all values of length of the application from Position units into the internal unit increments (encoder resolution equals 1 Revolution). It consists of numerator and divisor:
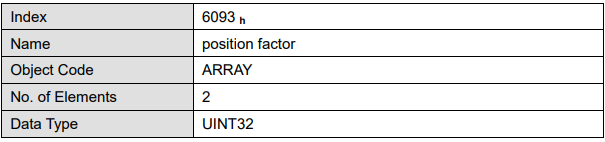
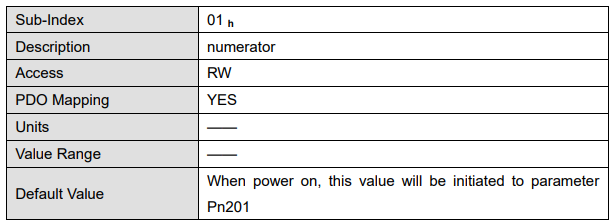
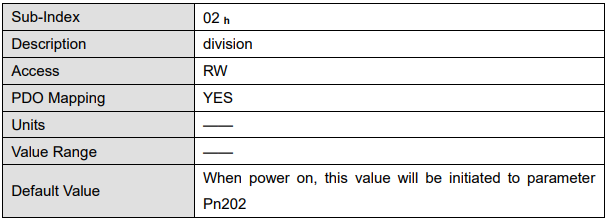
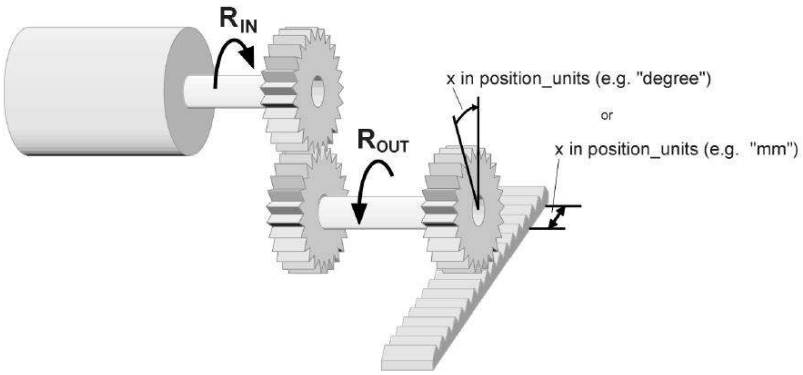
To calculate the position factor the following values are necessary:
gear_ratio Ratio between revolutions on the driving side (RIN) and revolutions on the driven side (ROUT).
feed_constant Ratio between revolutions on the driven side (ROUT) and equivalent motion in position_units
(e.g. 1 rev = 360°)
The calculation of the position_factor is done with the following equation:
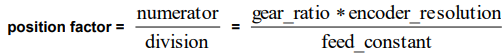
Note:
4.3 Velocity factor
The object velocity factor converts all speed values of the application from speed_units into the internal unit revolutions 0.1rpm. It consists of numerator and divisor
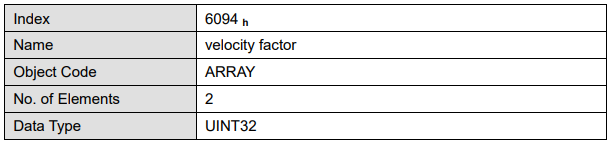
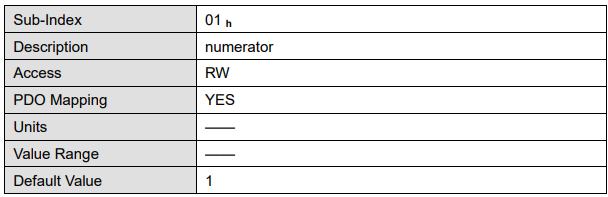
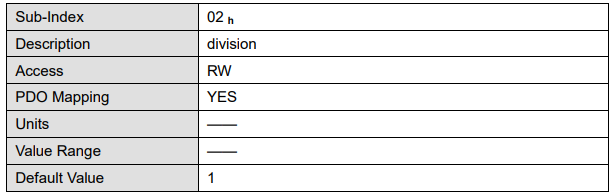
In principle the calculation of the velocity factor is composed of two parts: A conversion factor from internal units of length into position_units and a conversion factor from internal time units into user defined time units (e.g. from seconds to minutes). The first part equals the calculation of the position_factor. For the second part another factor is necessary for the calculation:
time_factor_v Ratio between internal and user defined time units. (z.B. 1 min = 1/10 10 min)
gear_ratio Ratio between revolutions on the driving side (RIN) and revolutions on the driven side (ROUT).
feed_constant Ratio between revolutions on the driven side (ROUT) and equivalent motion in position_units (e.g. 1 R = 360°)
The calculation of the velocity factor is done with the following equation:
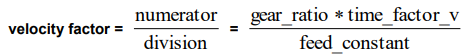
4.4 Acceleration factor
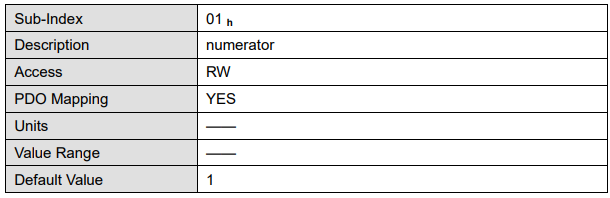
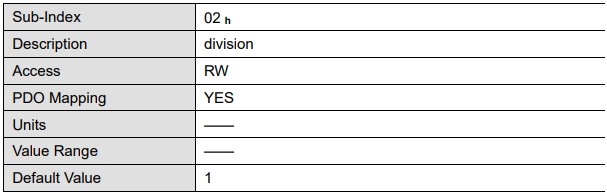
The object acceleration_factor converts all acceleration values of the application from acceleration_units into the internal unit(0.1rpm)。It consists of numerator and divisor:
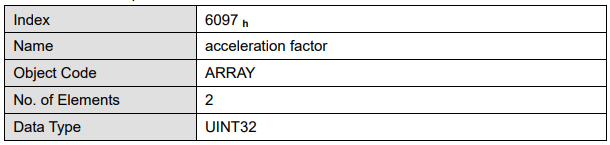
The calculation of the acceleration_factor is also composed of two parts: A conversion factor from internal units of length into position_units and a conversion factor from internal time units squared into user defined time units squared (e.g. from seconds2 to minutes2). The first part equals the calculation of the position_factor. For the second part another factor is necessary for the calculation
time_factor_a Ratio between internal time units squared and user defined time units squared
(z.B.: 1min2 = 1min*min = 60s*1min =60/10 10min/s)
gear_ratio Ratio between revolutions on the driving side (RIN) and revolutions on the driven side (ROUT).
feed_constant Ratio between revolutions on the driven side (ROUT) and equivalent motion in position_units (e.g. 1 R = 360°)
The calculation of the acceleration_factor is done with the following equation:
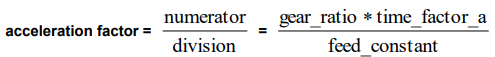
No comments to display
No comments to display